
- Posts: 22010
- Thank you received: 3
Rods "Spaceship" Scratch built Plasma Cutter build
- tommylight
-

- Offline
- Administrator
-

Less
More
9 years 9 months ago #85524
by tommylight
Replied by tommylight on topic Rods "Spaceship" Scratch built Plasma Cutter build
Just a stab in the dark, but what are the chances of Step and Dir wires being reversed?
Please Log in to join the conversation.

9 years 9 months ago #85547
by rodw
Well they were right when I turned the connector over to access the terminal screws on the stepper drive end! But totally wrong when I plugged it in! Funny that! Thanks Tommy.
I've still not got properly working yet, I inverted the phases to get it moving the right way and now when jogging, the axis alternates direction every time I jog it.
Its 7:00am here already I am sweating like a pig in my garage, I think it will be a hot day! I'll look at it again this evening. It will be something silly. I think the direction can be inverted in the .ini file, but not sure how. This is what I have now.
Replied by rodw on topic Rods "Spaceship" Scratch built Plasma Cutter build
tommylight wrote: Just a stab in the dark, but what are the chances of Step and Dir wires being reversed?
Well they were right when I turned the connector over to access the terminal screws on the stepper drive end! But totally wrong when I plugged it in! Funny that! Thanks Tommy.
I've still not got properly working yet, I inverted the phases to get it moving the right way and now when jogging, the axis alternates direction every time I jog it.
Its 7:00am here already I am sweating like a pig in my garage, I think it will be a hot day! I'll look at it again this evening. It will be something silly. I think the direction can be inverted in the .ini file, but not sure how. This is what I have now.
Code:
# Joint 3
[JOINT_3]
#********************
TYPE = LINEAR
HOME = 0.0
FERROR = 10.0
MIN_FERROR = 1.0
MAX_VELOCITY = 3000
MAX_ACCELERATION = 750
# The values below should be 25% larger than MAX_VELOCITY and MAX_ACCELERATION
# If using BACKLASH compensation STEPGEN_MAXACCEL should be 100% larger.
STEPGEN_MAXVEL = 31.25
STEPGEN_MAXACCEL = 937.50
P = 1000.0
I = 0.0
D = 0.0
FF0 = 0.0
FF1 = 1.0
FF2 = 0.0
BIAS = 0.0
DEADBAND = 0.0
MAX_OUTPUT = 0.0
# these are in nanoseconds
DIRSETUP = 500
DIRHOLD = 500
STEPLEN = 1500
STEPSPACE = 1500
STEP_SCALE = 1000
MIN_LIMIT = -87
MAX_LIMIT = 0.1
HOME_OFFSET = 0.0
HOME_SEARCH_VEL = 10
HOME_LATCH_VEL = 5
HOME_FINAL_VEL = 10
HOME_USE_INDEX = NO
HOME_SEQUENCE = 0
HOME_IS_SHARED = 1
Please Log in to join the conversation.
- tommylight
-
- Offline
- Administrator
-
Less
More
- Posts: 22010
- Thank you received: 3
9 years 9 months ago #85550
by tommylight
Replied by tommylight on topic Rods "Spaceship" Scratch built Plasma Cutter build
Oh there's your problem !!! 
That is a quote from Mythbusters.
You have max_vwlocity at 3000mm/sec, that is 180000mm/minute!!! Do you intend on having Z axis fly off when joging?
Also tje dir setup and dir hold are way to short, but may be ok, depending on the drives, i would set them at 2000 on all axis.
Regards,
Tom
That is a quote from Mythbusters.
You have max_vwlocity at 3000mm/sec, that is 180000mm/minute!!! Do you intend on having Z axis fly off when joging?
Also tje dir setup and dir hold are way to short, but may be ok, depending on the drives, i would set them at 2000 on all axis.
Regards,
Tom
Please Log in to join the conversation.
9 years 9 months ago #85552
by rodw
Tommy, thanks, I knew I would have done something silly but ran out of time before working hours.
Surely 18 m/min is not too much to ask from a NEMA23 on a 5mm pitch ball screw!
I did a lot of cutting and pasting between axes. The 18 m/min is right for the gantry axis. It actually tested good for 21 m/min but I backed it off a bit. I'd say its about 6 times too fast for the Z....
The timings have been OK at that so far but I'll keep an eye on it.
Replied by rodw on topic Rods "Spaceship" Scratch built Plasma Cutter build
tommylight wrote: Oh there's your problem !!!
That is a quote from Mythbusters.
You have max_velocity at 3000mm/sec, that is 180000mm/minute!!! Do you intend on having Z axis fly off when joging?
Also tje dir setup and dir hold are way to short, but may be ok, depending on the drives, i would set them at 2000 on all axis.
Regards,
Tom
Tommy, thanks, I knew I would have done something silly but ran out of time before working hours.
Surely 18 m/min is not too much to ask from a NEMA23 on a 5mm pitch ball screw!
I did a lot of cutting and pasting between axes. The 18 m/min is right for the gantry axis. It actually tested good for 21 m/min but I backed it off a bit. I'd say its about 6 times too fast for the Z....
The timings have been OK at that so far but I'll keep an eye on it.
Please Log in to join the conversation.
9 years 9 months ago #85560
by rodw
Replied by rodw on topic Rods "Spaceship" Scratch built Plasma Cutter build
Well, time got away tonight sorting out a computer network issue on the 800 metre wireless link from my house to my son-in-law that he was complaining was not working. I eventually found out that I could log in to the wireless module on his roof which told me that the link was up. It has not been touched since it was installed well over 5 years ago and its still in perfect order!
My stepper motors and larger power supply arrived today, so very happy about that. Very prompt service from steppers online ex. China.
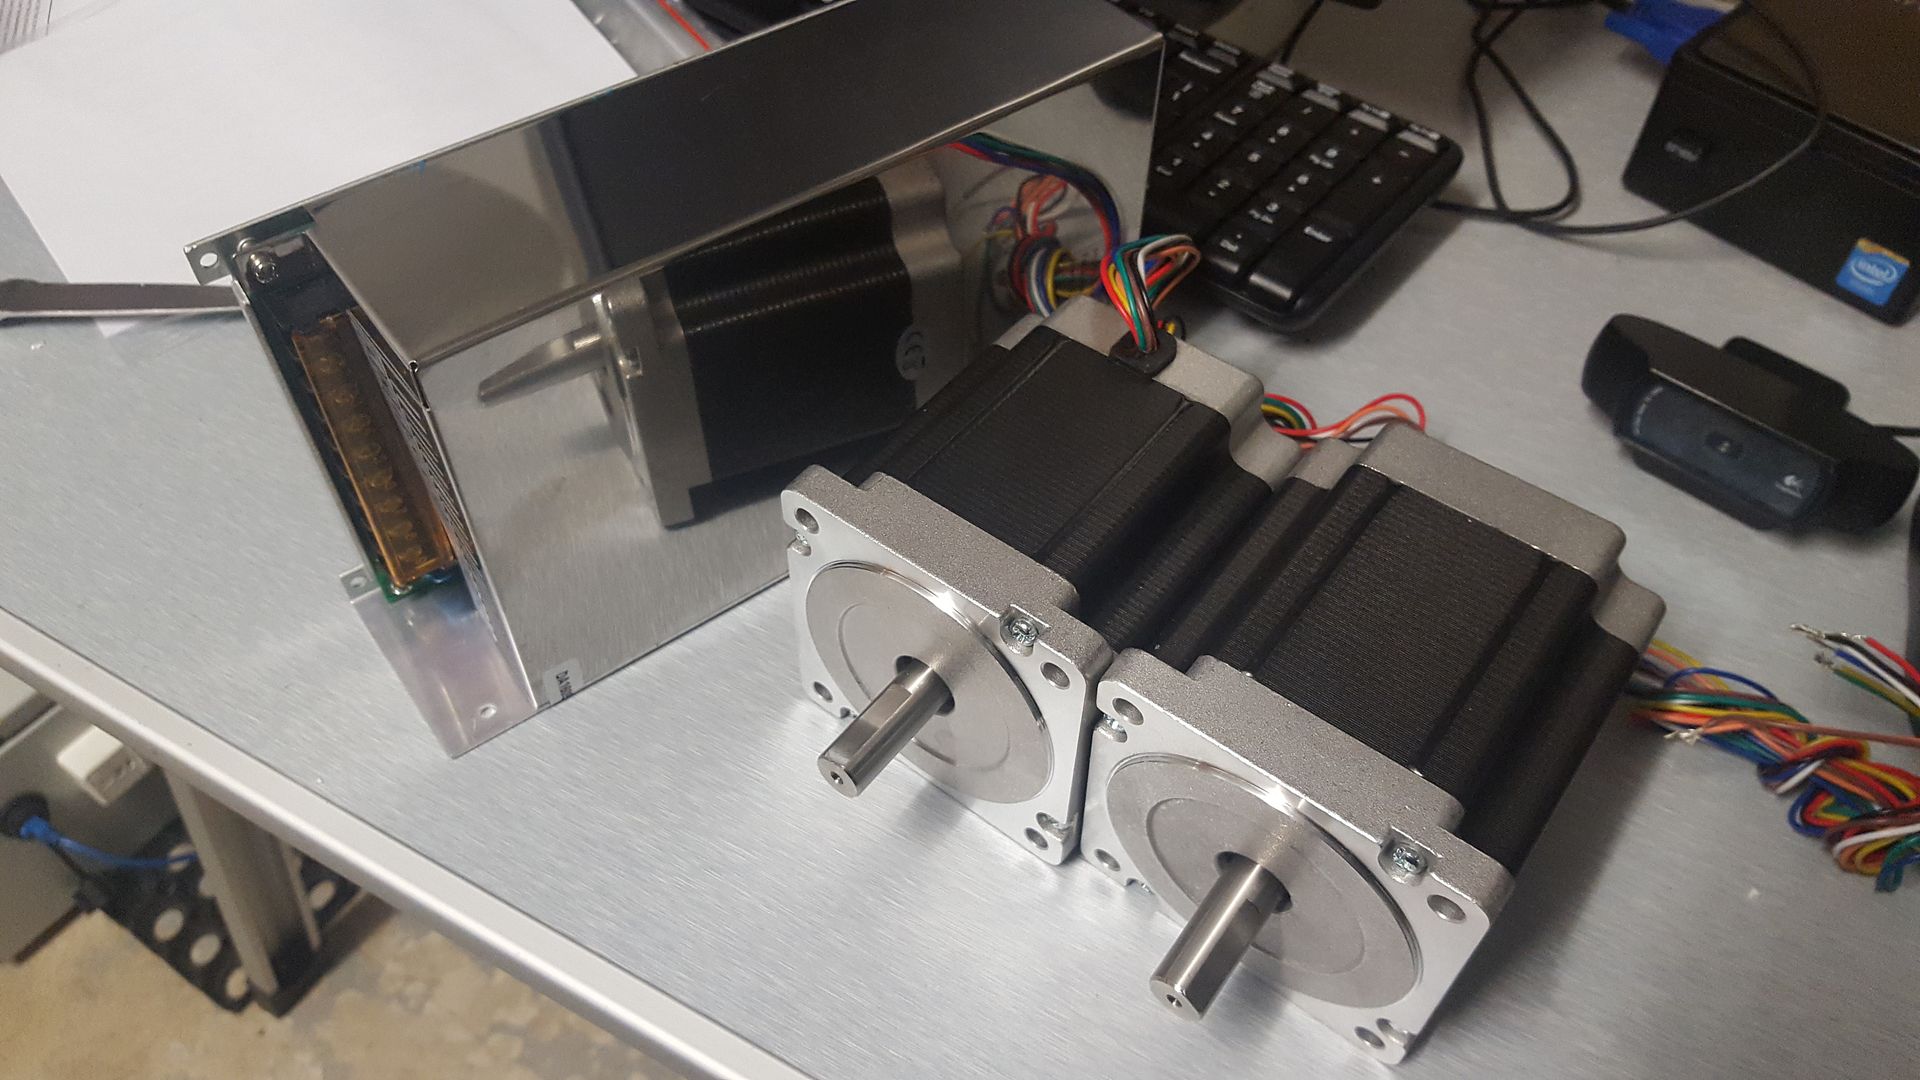
I think the power supply will just fit in where my 7 amp supply is now so squeezing it in will be easier than I was expecting. I will use the existing smaller power supply to run my Arduino based rotary table which has been waiting to be put in an enclosure for a couple of years. Its a pretty cool bit of Arduino coding as all the config is stored in EEPROM so there is no need to edit the code itself. But I should stick on topic I guess. But here is how Scott in Canada used my Arduino Sketch to index his rotary table on a mill that did not support a 4th axis. Very cool, just moved the tool past a proximity sensor wired in place of a press button switch on the Arduino to make it index.
This is what really started my CNC journey. I shorted a wire and blew up a Gecko stepper controller when testing it out. I replaced my Gecko with a 4 axis kit complete with cheap breakout board for not much more than the Gecko. So now I'm using these drives on my plasma table, I think I'll end up buying a Gecko again for the Rotary table!
I'll tackle the misconfigured HAL tomorrow.
My stepper motors and larger power supply arrived today, so very happy about that. Very prompt service from steppers online ex. China.
I think the power supply will just fit in where my 7 amp supply is now so squeezing it in will be easier than I was expecting. I will use the existing smaller power supply to run my Arduino based rotary table which has been waiting to be put in an enclosure for a couple of years. Its a pretty cool bit of Arduino coding as all the config is stored in EEPROM so there is no need to edit the code itself. But I should stick on topic I guess. But here is how Scott in Canada used my Arduino Sketch to index his rotary table on a mill that did not support a 4th axis. Very cool, just moved the tool past a proximity sensor wired in place of a press button switch on the Arduino to make it index.
This is what really started my CNC journey. I shorted a wire and blew up a Gecko stepper controller when testing it out. I replaced my Gecko with a 4 axis kit complete with cheap breakout board for not much more than the Gecko. So now I'm using these drives on my plasma table, I think I'll end up buying a Gecko again for the Rotary table!
I'll tackle the misconfigured HAL tomorrow.
Please Log in to join the conversation.
- tommylight
-
- Offline
- Administrator
-
Less
More
- Posts: 22010
- Thank you received: 3
9 years 9 months ago #85562
by tommylight
Replied by tommylight on topic Rods "Spaceship" Scratch built Plasma Cutter build
Hi Rod,
18m is all good, but you had it at 180m!
I had a plasma cutter that was happy up until 36m/minute, but even that is way to much for a machine.
Geckos are nice and i have plenty of them, but found Lam Technologies at near the same price but way better, and imdestructable, i did test them and they will not die even at reverse power supply polarity. And working microstepping up to 25600 pulses per revolution, smooth like silk.
Regards,
Tom
Please Log in to join the conversation.
9 years 9 months ago #85563
by rodw
Replied by rodw on topic Rods "Spaceship" Scratch built Plasma Cutter build
Tommy, thanks, It was Gremlins as I had it working earlier. Unlike you old hands, I have to read the manual for every setting and had no time. But I appreciated your help as it will save me some time when I get to review it all. I looked at the Lam Technologies stuff but they were hard to find down under. It did look very impressive.
The OMC steppers I'm using are much easier to source as we are so close to China and they hold some stock in my country. On my next build, I will probably use servo motors and step up one more level. I'd probably source them from China. I think there is an opportunity in Australia for a reasonably priced plasma table as there seems to be nothing under $20-$30k. I've got CAD files for every part so the next one would be all cut for me and after tapping a few holes it would go together in no time. But then again, the spaceship might not take off into that orbit.
So far, I am so happy with the quality of the build. Everything is really precise and accurate except for a little bit of sideways slop in the magnetic mount (which I think I have a simple solution for).
The only thing I've had second thoughts about is that as it currently stands, the rails mount to the table legs and therefore it might be very hard to get them square as the legs will need to be perfectly aligned. I might revisit that so they mount to a lateral beam but I can't change the mounting rails.now I've ordered them as they are hundreds of $ each.
Please Log in to join the conversation.
9 years 9 months ago #85651
by rodw
Replied by rodw on topic Rods "Spaceship" Scratch built Plasma Cutter build
Its been annoying that I've had to spend the last 3 nights sorting out network issues but I finally found 5 minutes to look at the problems Tommy diagnosed earlier.
So after slowing the Z axis down top a more leisurely pace, both up and down arrows were moving in identical direction. I realised it had to be a wiring fault and quickly found the loose wire.
Now I've got a homing issue on the Z axis which has a shared limit/home switch at the upper limit of travel
I get a "Hit limit in home state 7" error. This stumped me for a while until I realised that i had forgotten to add.
Now it looks like I've shared the home switch with the wrong limit switch as I had to hit estop as the Z axis hit its upper hard stop. I thought I just have to swap the Z axis limit switches around between min and max but that did not work. Its too late now so I'll revisit it over the weekend.
Here's what I've got in HAL.
So after slowing the Z axis down top a more leisurely pace, both up and down arrows were moving in identical direction. I realised it had to be a wiring fault and quickly found the loose wire.
Now I've got a homing issue on the Z axis which has a shared limit/home switch at the upper limit of travel
I get a "Hit limit in home state 7" error. This stumped me for a while until I realised that i had forgotten to add.
Code:
HOME_IGNORE_LIMITS = 1
Now it looks like I've shared the home switch with the wrong limit switch as I had to hit estop as the Z axis hit its upper hard stop. I thought I just have to swap the Z axis limit switches around between min and max but that did not work. Its too late now so I'll revisit it over the weekend.
Here's what I've got in HAL.
Code:
# --- MIN-Z ---
net min-z <= hm2_7i76e.0.7i76.0.0.input-07-not
# --- MAX-Z ---
net max-z <= hm2_7i76e.0.7i76.0.0.input-08
net Z-home => joint.3.home-sw-in
net min-z => joint.3.neg-lim-sw-in
net max-z => joint.3.pos-lim-sw-in
Please Log in to join the conversation.
9 years 9 months ago #85652
by rodw
Replied by rodw on topic Rods "Spaceship" Scratch built Plasma Cutter build
Now I see that Z-home has no prior value so I'm guessing joint.3.home-sw-in needs to be set to be the same as min-z
Please Log in to join the conversation.
9 years 9 months ago #85669
by rodw
I'm glad I went to bed when I did last night. Just a stupid error.
How on earth can an axis home itself if HAL does not have a home switch?
I had not sent the home switch input anywhere, so this did the trick.
I think that means I have both Y & Z axes working so i need to wire up my NEMA 34 steppers and get on with the dual joint axis.
I'm a bit annoyed at my laser cutter. I gave him some files nearly 2 weeks ago and earlier this week he said he could not fold the gantry ends in 10mm aluminium as it would crack (I think that is risk limiting jargon for might crack).
Anyway, I reworked the gantry ends in 6mm and that took hours as I had to rework another 2 parts. in the end, I got it done, but cursed my inexperience with 3D design software! I'll probably weld in some gussets to stop the ends from twisting but I have not bothered about them until I know where all the wiring done!
Replied by rodw on topic Rods "Spaceship" Scratch built Plasma Cutter build
rodw wrote: Now I see that Z-home has no prior value so I'm guessing joint.3.home-sw-in needs to be set to be the same as min-z
I'm glad I went to bed when I did last night. Just a stupid error.
How on earth can an axis home itself if HAL does not have a home switch?
I had not sent the home switch input anywhere, so this did the trick.
Code:
net Z-home hm2_7i76e.0.7i76.0.0.input-08 => joint.3.home-sw-in
I think that means I have both Y & Z axes working so i need to wire up my NEMA 34 steppers and get on with the dual joint axis.
I'm a bit annoyed at my laser cutter. I gave him some files nearly 2 weeks ago and earlier this week he said he could not fold the gantry ends in 10mm aluminium as it would crack (I think that is risk limiting jargon for might crack).
Anyway, I reworked the gantry ends in 6mm and that took hours as I had to rework another 2 parts. in the end, I got it done, but cursed my inexperience with 3D design software! I'll probably weld in some gussets to stop the ends from twisting but I have not bothered about them until I know where all the wiring done!
Please Log in to join the conversation.
Time to create page: 5.285 seconds