Puma 6 axis Robotic Arm with Mesa 7i80/7i40

More
2 years 5 days ago - 2 years 2 days ago #313340 by jonesmg1
I have been using LinuxCNC for a long time for my Mill and Lathe setup and parallel controlled stepper motors but this new project is making me a little crazy (it was straight forward on my other machines). 

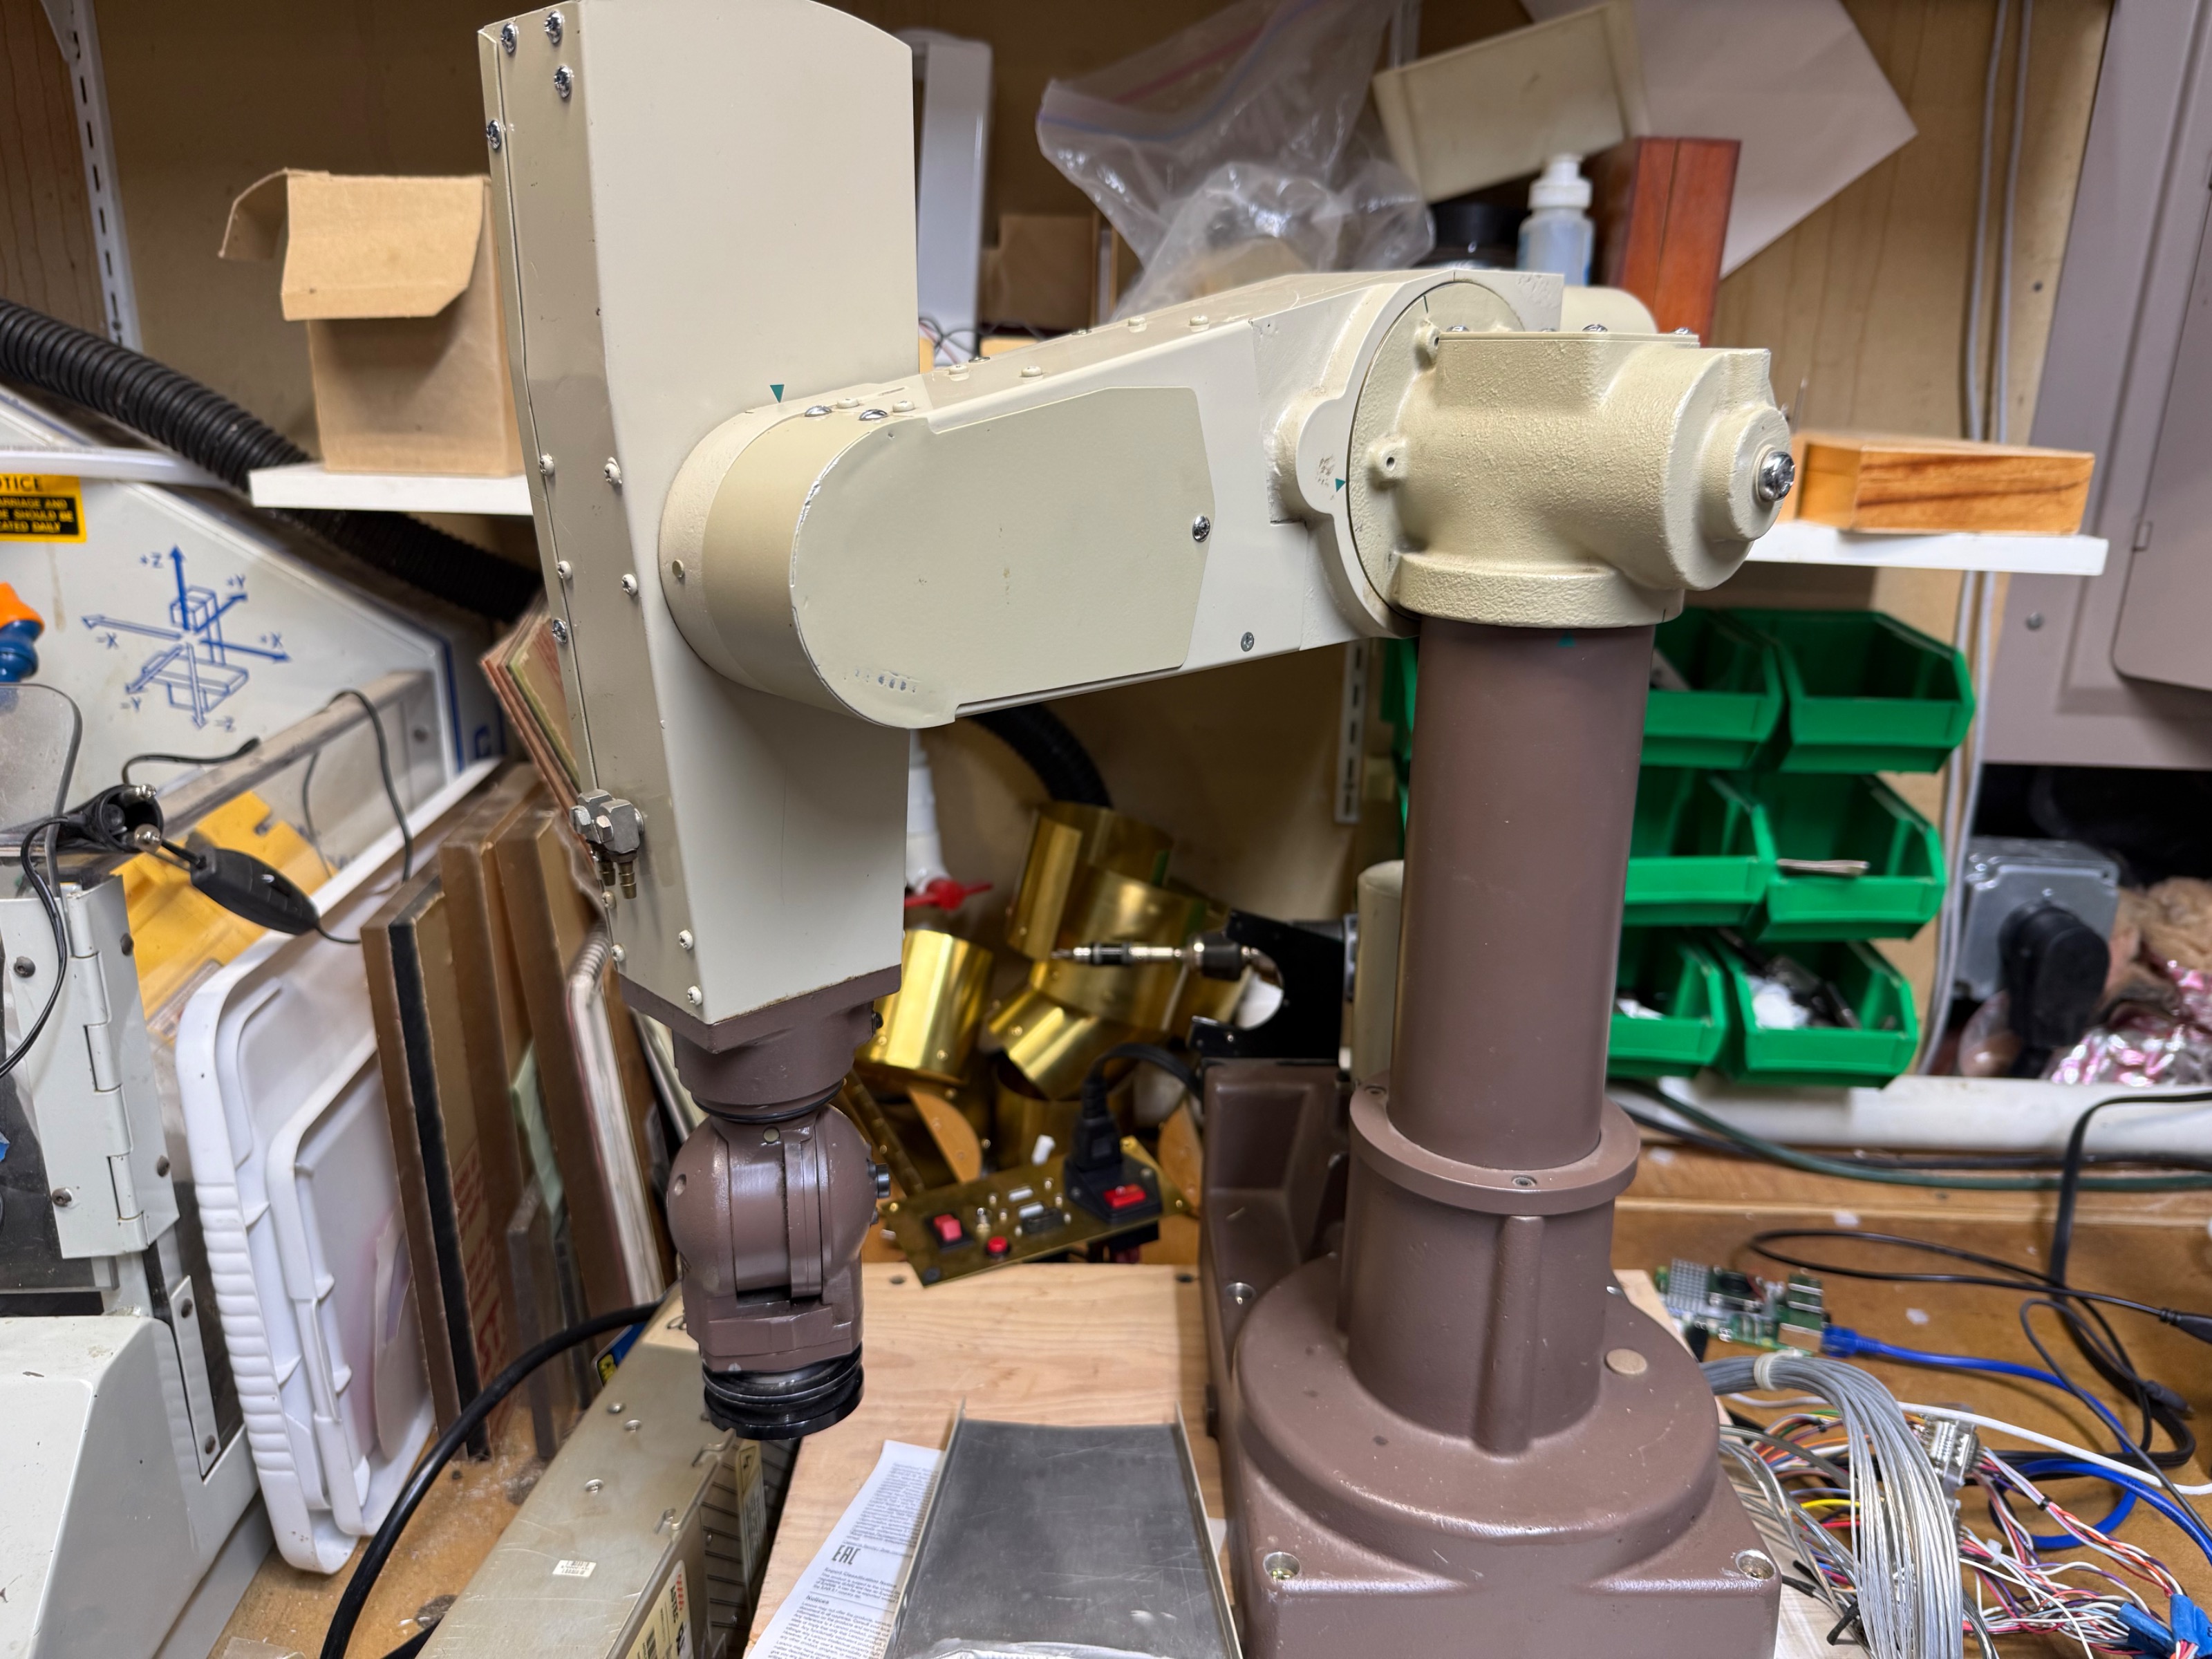
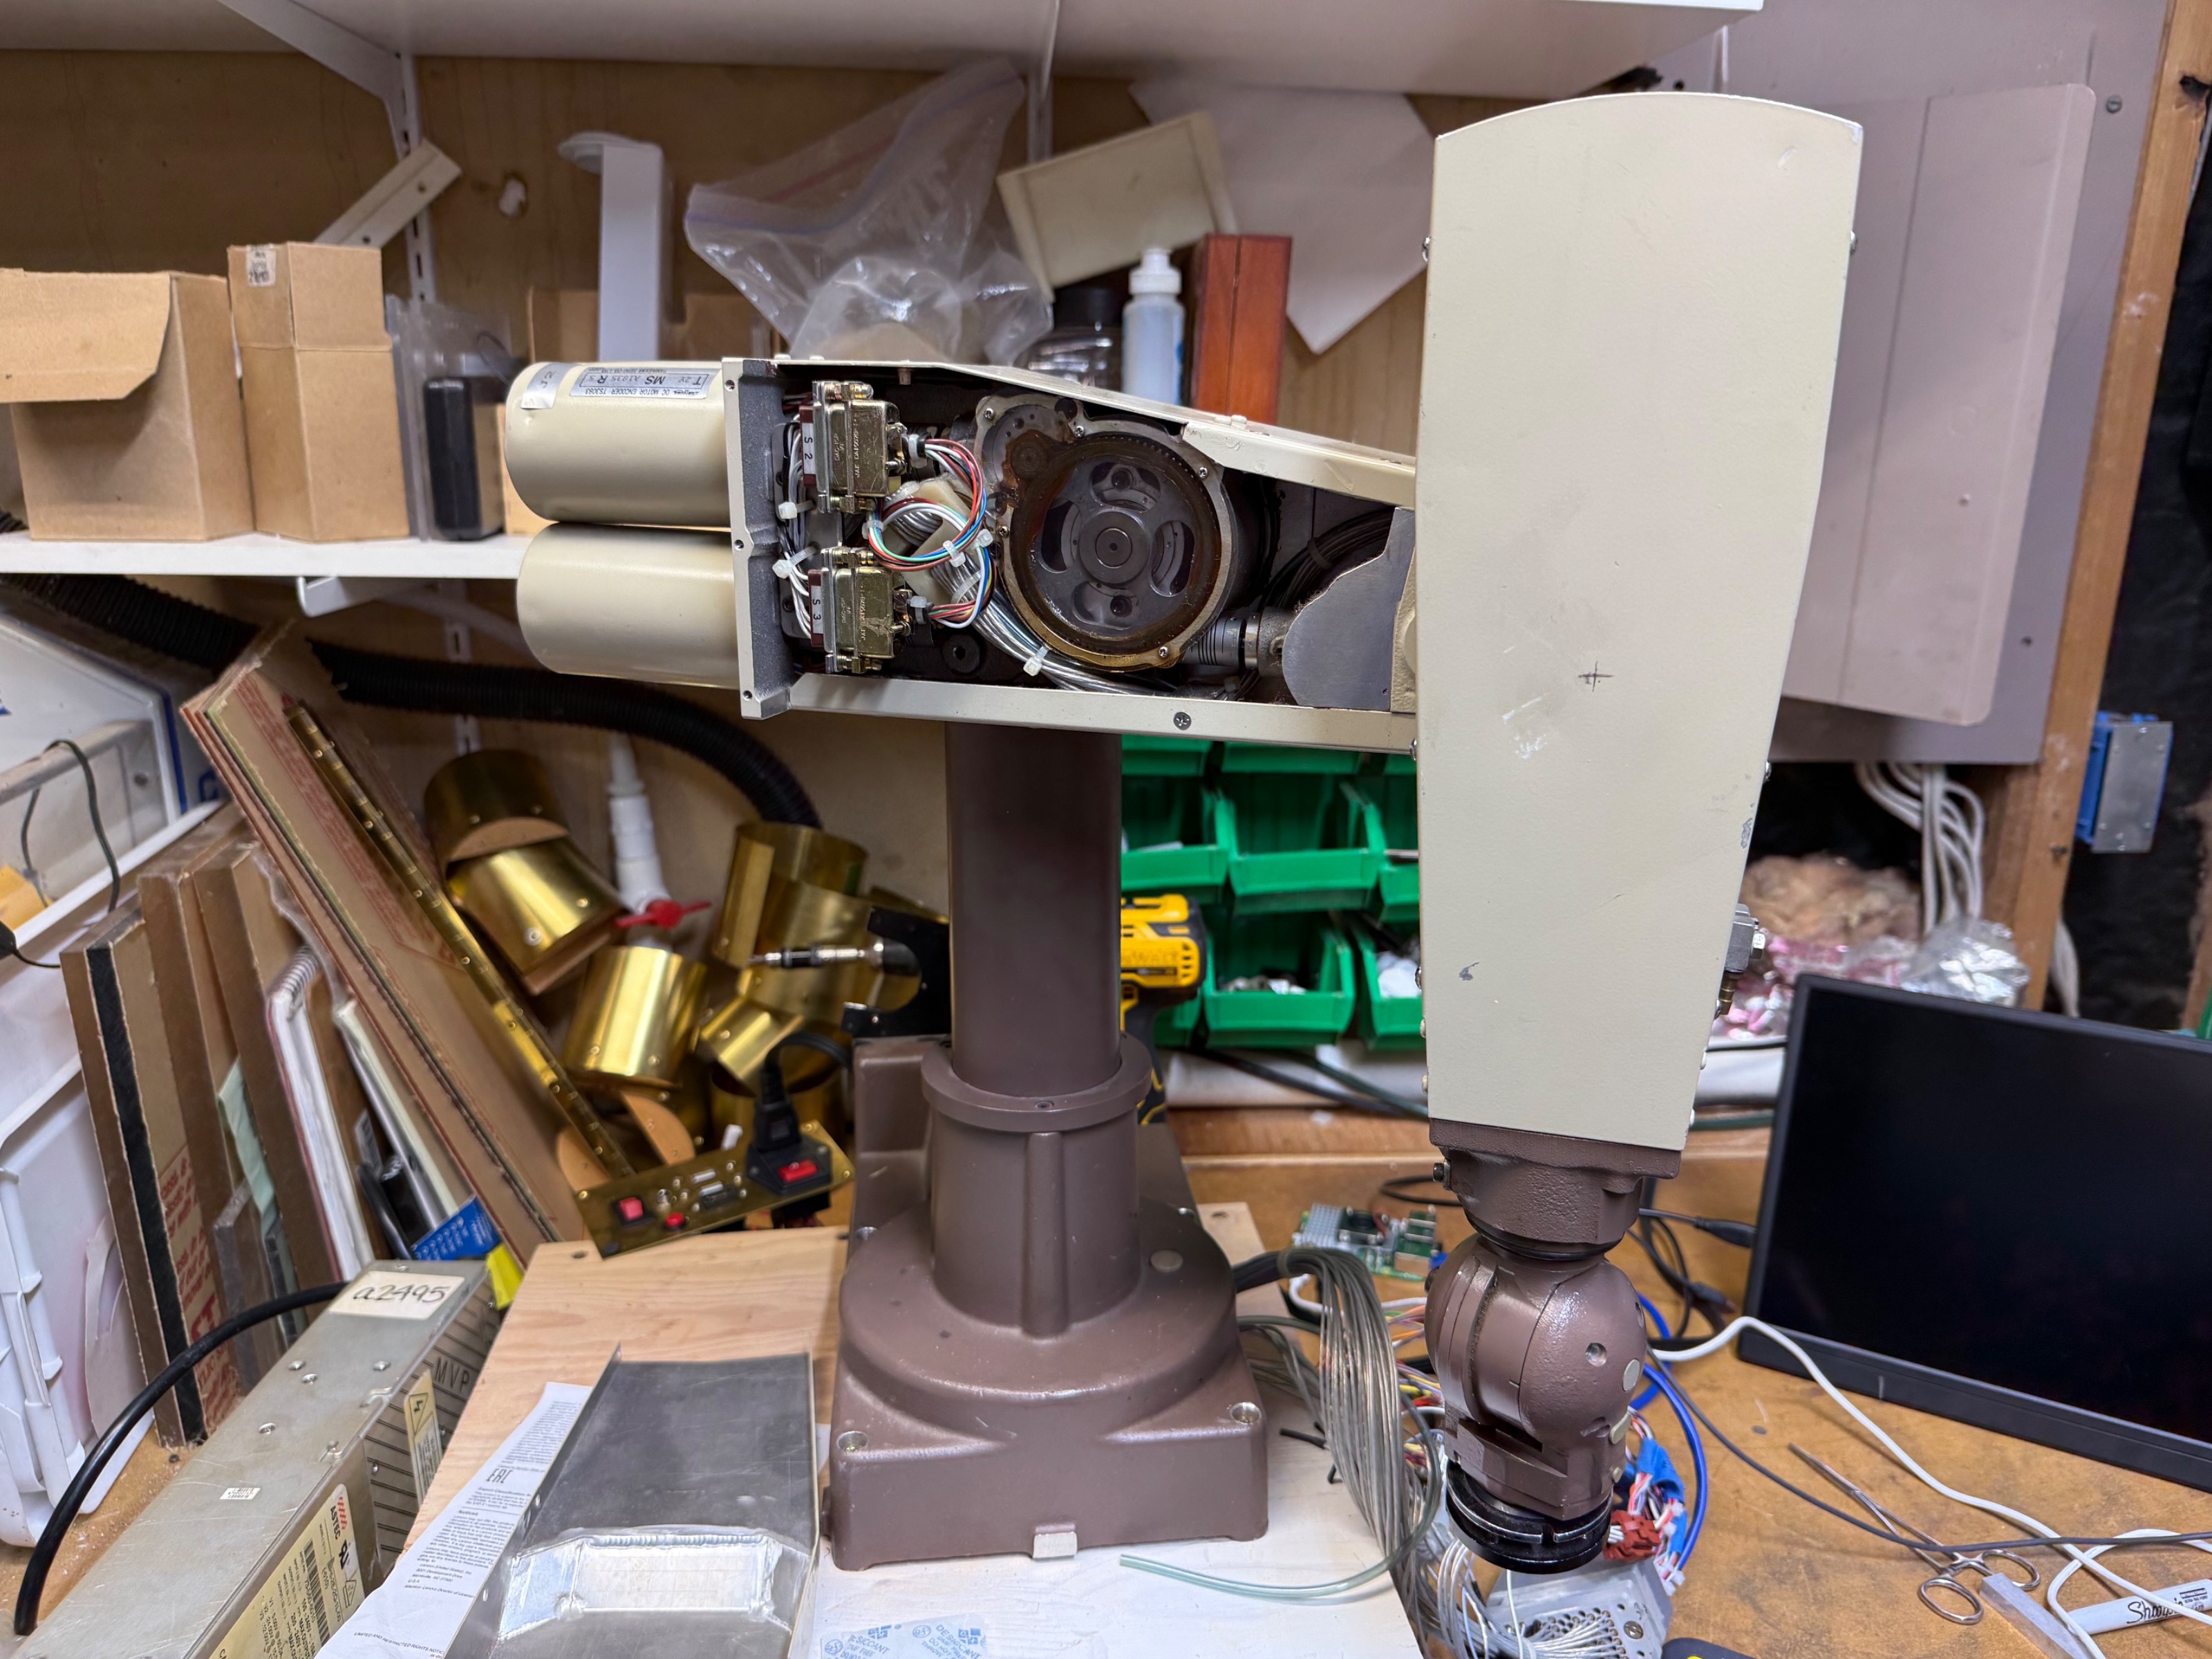
I was given (in an incomplete state) a Kawasaki Robotics/PUMA 200 arm which has a Mesa 7i80 controller with 7i40 daughter cards running the servo motors.  

CORRECTION:   I believe this is more appropriately identified as a PUMA 260 arm - if that makes a difference

I have things "moving" generally with INI and HAL files from the previous owner and of the axes respond generally to control (I don't know enough about servos with LinuxCNC/mesa  but I am having all kinds of issues with Joint #1 the "shoulder" joint (the rotation, waist pillar joint in the center is Joint 0).  With a higher P value (200-300ish) the motors will hold it in position and move it up (positive direction) but when I reverse direction it stutters, pops up a follow error and estops.  I can very slowly/carefully/intermittently move the joint down but it eventually errors out.   I have a feeling that there needs to be some kind of asymmetric control of the positive/negative direction for this joint due to gravity/weight of the mechanism. 

I'm not even sure where to start here (I've been combing through some of the documentation leveraging my previous knowledge of LinuxCNC - which is a little rusty to begin with) or what questions to ask.   

Does anyone have a similar setup who would be willing to share their configuration, or maybe help me formulate some intelligent questions and find the answers. 

Thank you, 

Michael Jones
Last edit: 2 years 2 days ago by jonesmg1.

Please Log in or Create an account to join the conversation.
More
2 years 4 days ago #313405 by Deckerjwd
so I'm not familiar with PUMA 200, but most robots have brakes, i have had all kinds of trouble with them. I would look at them and any counterbalance system. if it has a counterbalance and the brake is on often you can get it to move up but not back down.

Please Log in or Create an account to join the conversation.
More
2 years 3 days ago #313469 by jonesmg1


The system does have brakes which I have disabled (the joint free drops when it gets the follow error)

it doesn’t have a physical counterbalance that I can tell, maybe the gearbox has some sort of clutch?  

When idle, the motors are able to hold the joint in place even if I push on it.

I have a feeling that there’s something off  between the motors and encoders.   When it moves, it seems to be miscalculating the actual vs expected travel - but that’s just gut feeling.   It sometimes errors moving up, but not always.. it always errors moving down.  

Please Log in or Create an account to join the conversation.

More
2 years 2 days ago #313481 by tommylight
Check encoder PPR, make sure the scaling is correct, then we can move to tuning.
In the meantime, upload the config files here so we can have a look, just in case something is off.

Please Log in or Create an account to join the conversation.

More
2 years 2 days ago #313506 by jonesmg1
Here's the files.   I'll work on verifying the encoders shortly.  

File Attachment:

File Name: SMAB-LinuxCNC.zip
File Size:8.04 KB

Please Log in or Create an account to join the conversation.

More
2 years 2 days ago #313515 by PCW
One thing you might try is setting the PID MAX_OUTPUT to say 9.5 (95% of full scale)
As the 7I40 cannot have 100% duty cycle (the high side MOSFET bootstrap
requires a continuous PWM signal)

Please Log in or Create an account to join the conversation.

Time to create page: 0.252 seconds
Powered by Kunena Forum
