Hi all,
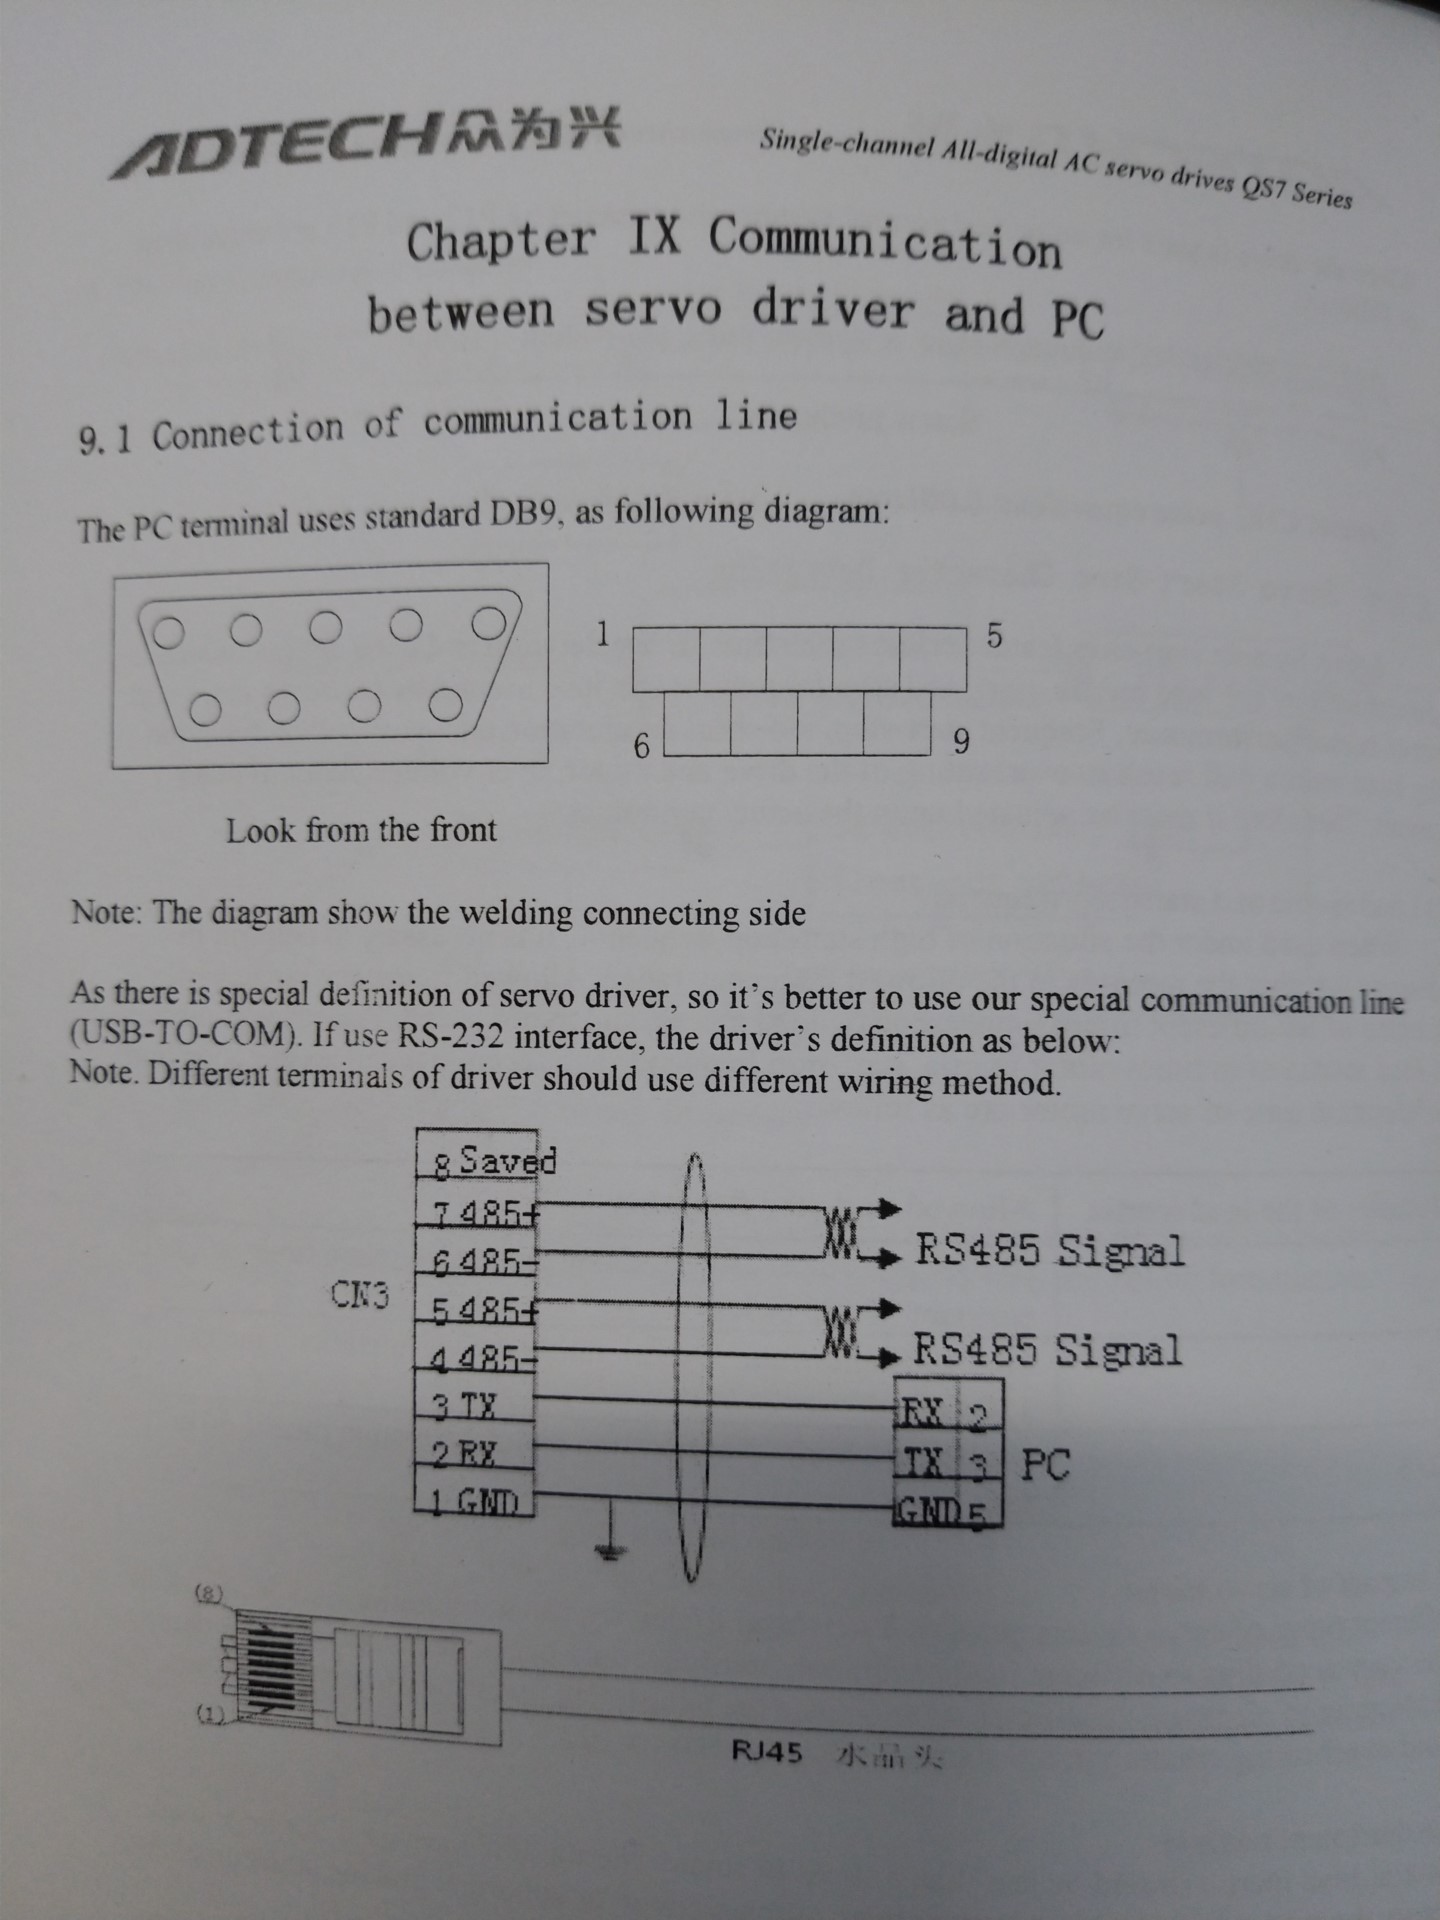
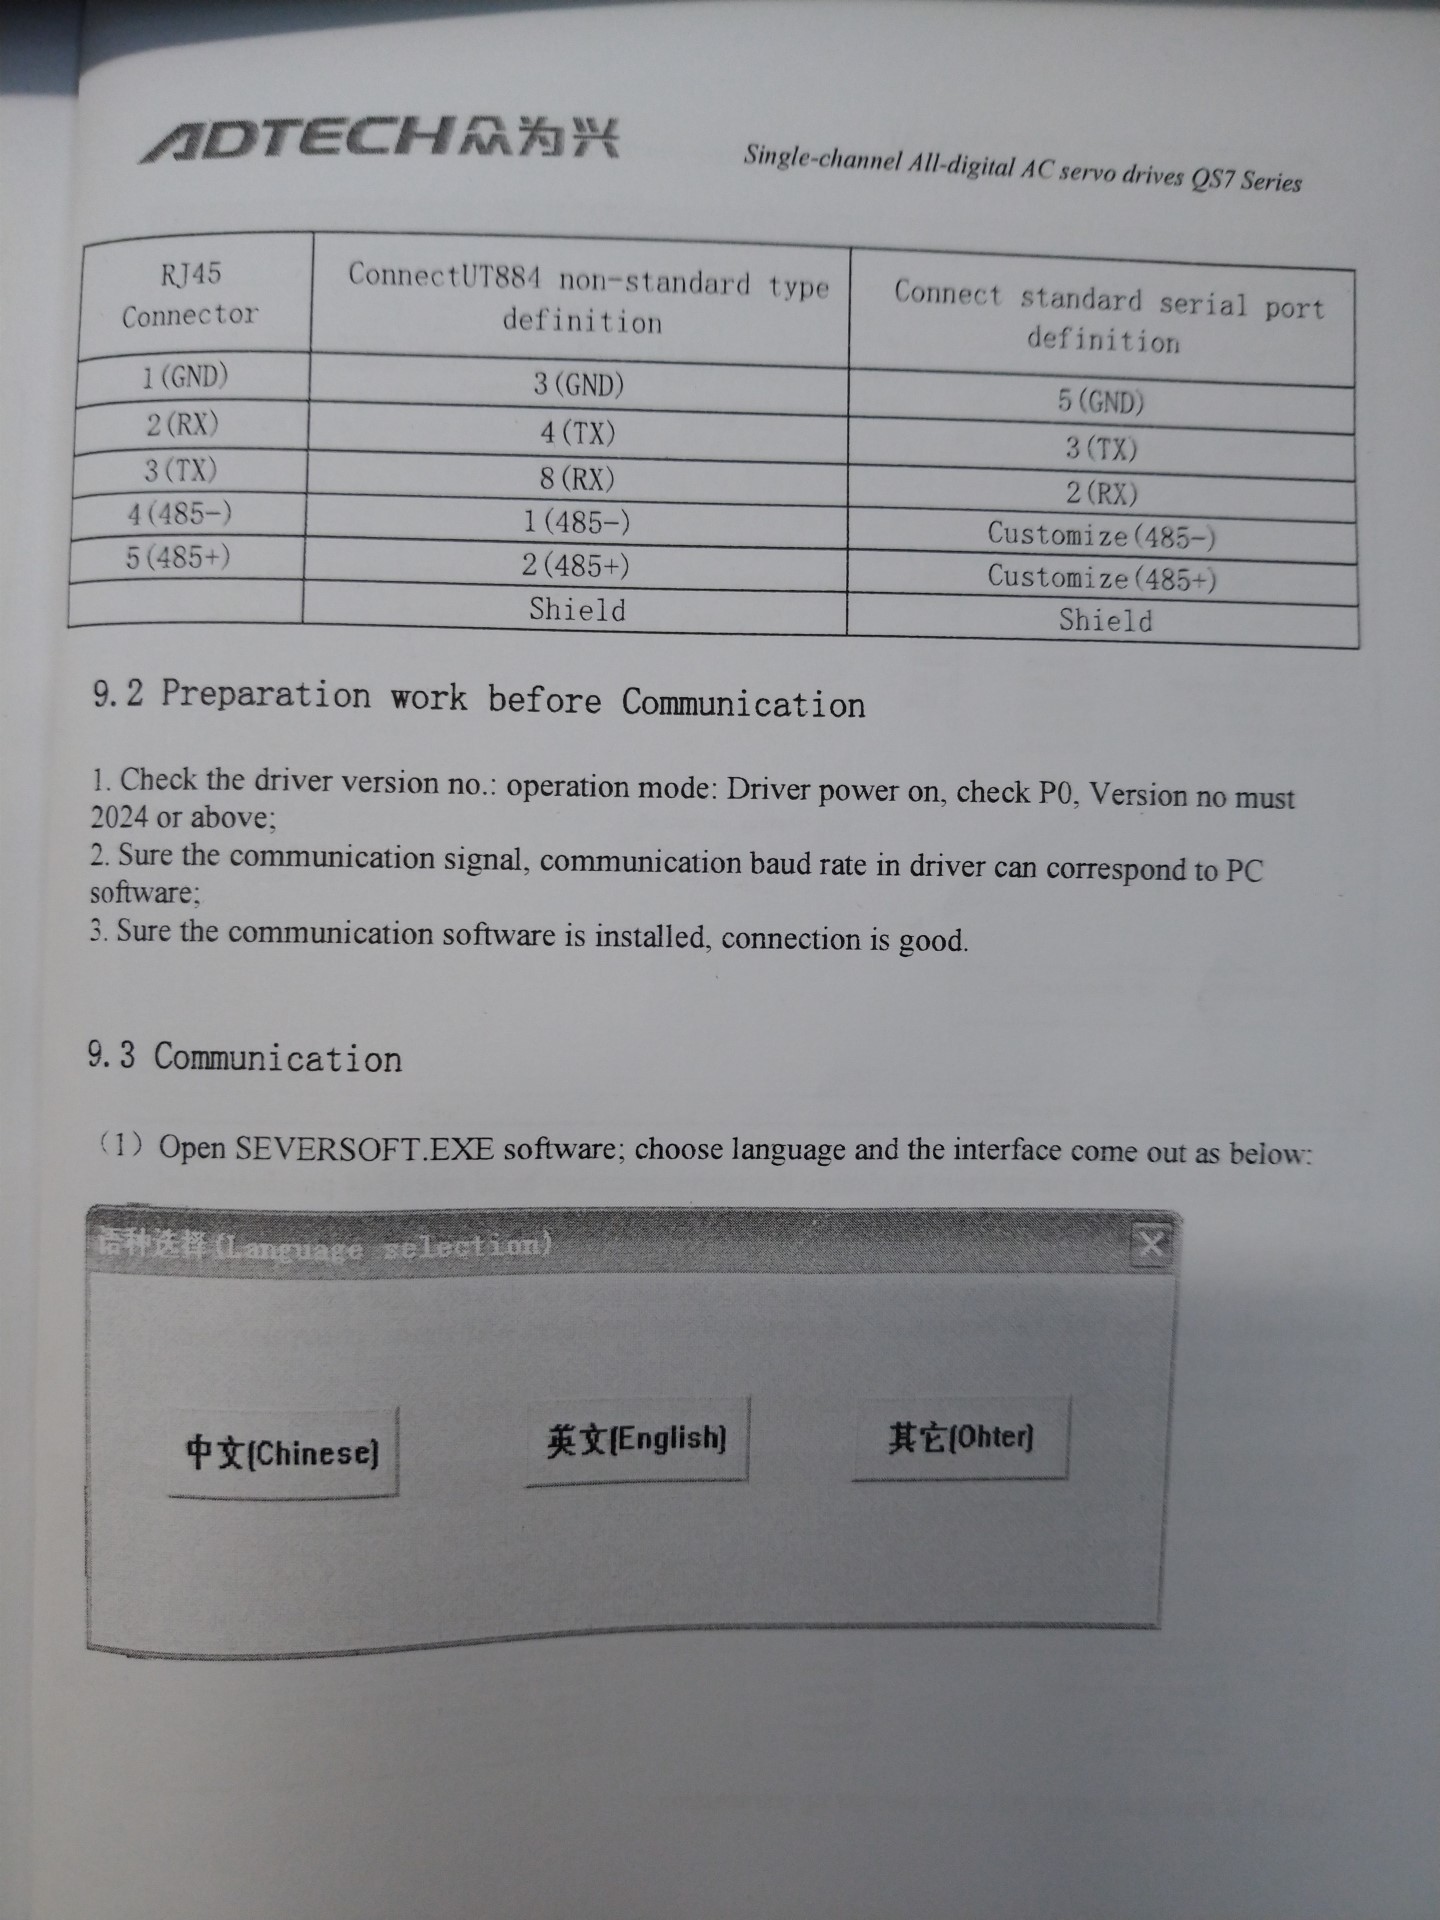
I have been trying to use MB2HAL to get a motor current feedback from a servo drive through the modbus rtu protocol but I dont see any HAL pins being created in the LinuxCNC when I open the HAL meter. Do I have to create the pins manually? If yes then how do I do it?
What I have done so far is:
1. I added this line
Code:
MB2HAL = modbus.hal
into the [HAL] section of the main machine configuration .ini file
2. I created modbus.hal file in the same directory and a put this line into it
Code:
loadusr -W mb2hal config = mb2hal_config_file.ini
3. I created the mb2hal_config_file.ini file in the same directory and I put my modbus transaction configuration into it. It is possible I configured the transaction incorrectly but I thought that I would at least be able to see hal pin for the modbus transaction.
Here I attach my modbus configuration .ini file
Here is a link to the servo drive modbus protocol manual:
pdf.directindustry.com/pdf/adtech-shenzh...n/114531-657678.html
I really spent a lot of time trying to solve the problem but I don't know much about HAL and how it works. I would be grateful if somebody could help me solve this problem.