How to completely disable PID on a MESA 5i25 / 7i76 setup...

More
9 years 1 month ago #99165 by Jan Weber
Hi everyone,

I try to set up a LinuxCNC retrofit of a Deckel FP2NC CNC mill. I use drivers with internal closed loop. The encoders are connected to the drivers (Benezan Speedcube).

I am looking for the correct settings of the PID parameters in the pncconf wizard.
Is it possible to completely disable the internal closed Loop of the LinuxCNC software?

Jan

Please Log in or Create an account to join the conversation.
More
9 years 1 month ago #99166 by PCW
No, the stepgen uses PID to correct for small timing differences in the hardware and LinuxCNC
If you are not closing the loop back to LinuxCNC (via encoders feedback to LinuxCNC)
then the PID settings are preset correctly (FF1=1.00, P = 1000, everything else = 0)

Please Log in or Create an account to join the conversation.
More
9 years 1 month ago #99170 by Jan Weber
Thanks a lot for your quick response. I will try the settings as soon as I am back home in the workshop.

Jan

Please Log in or Create an account to join the conversation.

More
9 years 1 month ago #99318 by scubawarm
I got confused in this exchange. As I believe I'm in the same situation, and have wondering the same thing.

Jan said the encoders are connected to the drivers.

Is that not the same as "If you are not closing the loop back to LinuxCNC (via encoders feedback to LinuxCNC)"

Coming up with the parameters and thus double loop correction has me lost.

Please Log in or Create an account to join the conversation.

More
9 years 1 month ago #99338 by PCW
In the step/direction configuration, there is no need to come up with
PID parameters (pncconf's default parameters are fine), and there is
no double loop (there is no external feedback coming to LinuxCNC)

Only in the rather special case where you have step/direction drives and have encoder
feedback to LinuxCNC need the PID loop be tuned

Please Log in or Create an account to join the conversation.

More
9 years 1 week ago #100693 by Jan Weber
I still had Problems with my MESA-Setup, because it looked like I didn“t disable the PID-controller.
The reason for my servo-drivers showing error as soon as the motors startet moving was something else:

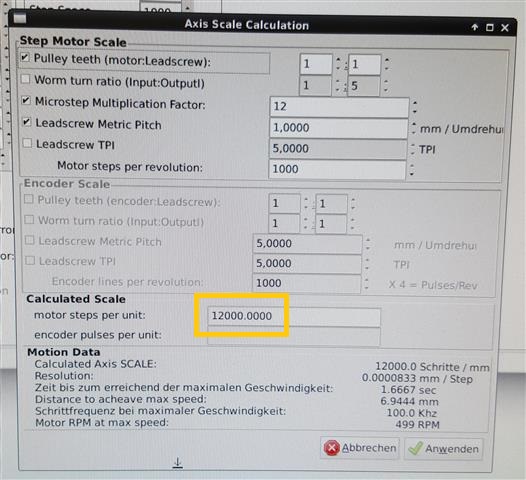
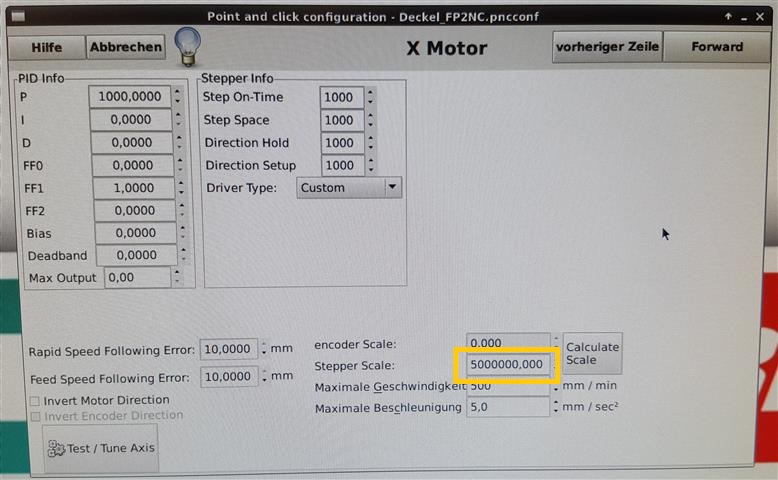
The scale calculation of the stepconf-wizard is obviously faulty. I entered my data in the fields so the result should be 12.000 steps per revolution for my test setup.

The wizard enters a value of 5.000.000 in the .ini-file as the steper scale. This is why the motors start moving with acceleration parameters far beyond the possible limits.


Can someone crosscheck this with his machine?

Jan

Please Log in or Create an account to join the conversation.

Moderators: cmorley
Time to create page: 0.076 seconds
Powered by Kunena Forum
