
Search Results (Searched for: )
- Aciera
21 Nov 2025 15:23
seems that you are telling it to load 'io.hal' somewhere but don't have that file in your config.
Replied by Aciera on topic Probe basic launch issue
twopass:CANNOT FIND FILE FOR:io.hal
seems that you are telling it to load 'io.hal' somewhere but don't have that file in your config.
- Tinker
21 Nov 2025 15:01
Replied by Tinker on topic Probe basic launch issue
So i was able to get PB to launch and then i tried to do the modifications that were recomended on the start screen. I modified my HAL and INI files and now have the following error report..
Error report created by /usr/lib/tcltk/linuxcnc/show_errors.tcl:
Print file information:
RUN_IN_PLACE=no
LINUXCNC_DIR=
LINUXCNC_BIN_DIR=/usr/bin
LINUXCNC_TCL_DIR=/usr/lib/tcltk/linuxcnc
LINUXCNC_SCRIPT_DIR=
LINUXCNC_RTLIB_DIR=/usr/lib/linuxcnc/modules
LINUXCNC_CONFIG_DIR=
LINUXCNC_LANG_DIR=/usr/lib/tcltk/linuxcnc/msgs
INIVAR=inivar
HALCMD=halcmd
LINUXCNC_EMCSH=/usr/bin/wish8.6
LINUXCNC - 2.9.4
Machine configuration directory is '/home/kris/linuxcnc/configs/my_mill'
Machine configuration file is 'my_mill.ini'
INIFILE=/home/kris/linuxcnc/configs/my_mill/my_mill.ini
VERSION=1.1
PARAMETER_FILE=probe_basic.var
TPMOD=
HOMEMOD=
TASK=milltask
HALUI=halui
DISPLAY=probe_basic
COORDINATES=X Y Z
KINEMATICS=trivkins coordinates=XYZ
Starting LinuxCNC...
Starting LinuxCNC server program: linuxcncsvr
Loading Real Time OS, RTAPI, and HAL_LIB modules
Starting LinuxCNC IO program: iov2
Starting HAL User Interface program: halui
linuxcnc TPMOD=tpmod HOMEMOD=homemod EMCMOT=motmod
twopass:invoked with <> options
twopass:found ./main.hal
twopass:CANNOT FIND FILE FOR:io.hal
twopass:CANNOT FIND FILE FOR:io.hal
Shutting down and cleaning up LinuxCNC...
iov2: exiting
Removing HAL_LIB, RTAPI, and Real Time OS modules
Removing NML shared memory segments
Debug file information:
Note: Using POSIX realtime
2139
Stopping realtime threads
Unloading hal components
Note: Using POSIX realtime
Info report created by linuxcnc_info:
The file: /tmp/linuxcnc_info.txt
can be posted to a forum or a web site like:
pastebin.com
in order to provide information about the linuxcnc
system and configuration.
Date: Fri Nov 21 08:56:05 AM CST 2025
UTC Date: Fri Nov 21 02:56:05 PM UTC 2025
this program: /usr/bin/linuxcnc_info
uptime: 08:56:05 up 3 min, 1 user, load average: 1.44, 0.72, 0.30
lsb_release -sa: Debian Debian GNU/Linux 13 (trixie) 13 trixie
linuxcnc: /usr/bin/linuxcnc
pwd: /home/kris/linuxcnc/configs/my_mill
USER: kris
LOGNAME: kris
HOME: /home/kris
EDITOR:
VISUAL:
LANGUAGE:
TERM: dumb
COLORTERM:
DISPLAY: :0.0
DESKTOP: lightdm-xsession
display size: 1920x1080 pixels (509x286 millimeters)
PATH: /usr/bin:/home/kris/linuxcnc/configs/my_mill/bin:/usr/bin:/usr/local/bin:/usr/bin:/bin:/usr/local/games:/usr/games
uname items:
nodename -n: debian
kernel-name -s: Linux
kernel-vers -v: #1 SMP PREEMPT_RT Debian 6.12.48-1 (2025-09-20)
machine -m: x86_64
processor -p: unknown
platform -i: unknown
oper system -o: GNU/Linux
/proc items:
cmdline: BOOT_IMAGE=/boot/vmlinuz-6.12.48+deb13-rt-amd64 root=UUID=5efc6035-1184-4e51-acb6-e99aeeac4490 ro quiet isolcpus=3
model name: Intel(R) N100
cores: 4
cpu MHz: 1744.606
parport:
serial:
Versions:
gcc: gcc (Debian 14.2.0-19) 14.2.0
python: Python 3.13.5
git: not_in_PATH
git commit: NA
tcl: 8.6
/usr/bin/linuxcnc_info: line 159: wish: command not found
tk:
glade: not_in_PATH
linuxcnc_var all:
LINUXCNCVERSION: 2.9.4
LINUXCNC_AUX_GLADEVCP: /usr/share/linuxcnc/aux_gladevcp
LINUXCNC_AUX_EXAMPLES: /usr/share/linuxcnc/aux_examples
REALTIME: /usr/lib/linuxcnc/realtime
RTS: uspace
HALLIB_DIR: /usr/share/linuxcnc/hallib
PYTHON: /usr/bin/python3
dpkg -l '*linuxcnc*':
Desired=Unknown/Install/Remove/Purge/Hold
| Status=Not/Inst/Conf-files/Unpacked/halF-conf/Half-inst/trig-aWait/Trig-pend
|/ Err?=(none)/Reinst-required (Status,Err: uppercase=bad)
||/ Name Version Architecture Description
+++-===================-============-============-=====================================================================
un linuxcnc <none> <none> (no description available)
un linuxcnc-dev <none> <none> (no description available)
un linuxcnc-doc <none> <none> (no description available)
ii linuxcnc-doc-en 1:2.9.4-2 all motion controller for CNC machines and robots (English documentation)
un linuxcnc-doc-es <none> <none> (no description available)
un linuxcnc-doc-fr <none> <none> (no description available)
un linuxcnc-sim <none> <none> (no description available)
un linuxcnc-sim-dev <none> <none> (no description available)
ii linuxcnc-uspace 1:2.9.4-2 amd64 motion controller for CNC machines and robots
ii linuxcnc-uspace-dev 1:2.9.4-2 amd64 PC based motion controller for real-time Linux
Error report created by /usr/lib/tcltk/linuxcnc/show_errors.tcl:
Print file information:
RUN_IN_PLACE=no
LINUXCNC_DIR=
LINUXCNC_BIN_DIR=/usr/bin
LINUXCNC_TCL_DIR=/usr/lib/tcltk/linuxcnc
LINUXCNC_SCRIPT_DIR=
LINUXCNC_RTLIB_DIR=/usr/lib/linuxcnc/modules
LINUXCNC_CONFIG_DIR=
LINUXCNC_LANG_DIR=/usr/lib/tcltk/linuxcnc/msgs
INIVAR=inivar
HALCMD=halcmd
LINUXCNC_EMCSH=/usr/bin/wish8.6
LINUXCNC - 2.9.4
Machine configuration directory is '/home/kris/linuxcnc/configs/my_mill'
Machine configuration file is 'my_mill.ini'
INIFILE=/home/kris/linuxcnc/configs/my_mill/my_mill.ini
VERSION=1.1
PARAMETER_FILE=probe_basic.var
TPMOD=
HOMEMOD=
TASK=milltask
HALUI=halui
DISPLAY=probe_basic
COORDINATES=X Y Z
KINEMATICS=trivkins coordinates=XYZ
Starting LinuxCNC...
Starting LinuxCNC server program: linuxcncsvr
Loading Real Time OS, RTAPI, and HAL_LIB modules
Starting LinuxCNC IO program: iov2
Starting HAL User Interface program: halui
linuxcnc TPMOD=tpmod HOMEMOD=homemod EMCMOT=motmod
twopass:invoked with <> options
twopass:found ./main.hal
twopass:CANNOT FIND FILE FOR:io.hal
twopass:CANNOT FIND FILE FOR:io.hal
Shutting down and cleaning up LinuxCNC...
iov2: exiting
Removing HAL_LIB, RTAPI, and Real Time OS modules
Removing NML shared memory segments
Debug file information:
Note: Using POSIX realtime
2139
Stopping realtime threads
Unloading hal components
Note: Using POSIX realtime
Info report created by linuxcnc_info:
The file: /tmp/linuxcnc_info.txt
can be posted to a forum or a web site like:
pastebin.com
in order to provide information about the linuxcnc
system and configuration.
Date: Fri Nov 21 08:56:05 AM CST 2025
UTC Date: Fri Nov 21 02:56:05 PM UTC 2025
this program: /usr/bin/linuxcnc_info
uptime: 08:56:05 up 3 min, 1 user, load average: 1.44, 0.72, 0.30
lsb_release -sa: Debian Debian GNU/Linux 13 (trixie) 13 trixie
linuxcnc: /usr/bin/linuxcnc
pwd: /home/kris/linuxcnc/configs/my_mill
USER: kris
LOGNAME: kris
HOME: /home/kris
EDITOR:
VISUAL:
LANGUAGE:
TERM: dumb
COLORTERM:
DISPLAY: :0.0
DESKTOP: lightdm-xsession
display size: 1920x1080 pixels (509x286 millimeters)
PATH: /usr/bin:/home/kris/linuxcnc/configs/my_mill/bin:/usr/bin:/usr/local/bin:/usr/bin:/bin:/usr/local/games:/usr/games
uname items:
nodename -n: debian
kernel-name -s: Linux
kernel-vers -v: #1 SMP PREEMPT_RT Debian 6.12.48-1 (2025-09-20)
machine -m: x86_64
processor -p: unknown
platform -i: unknown
oper system -o: GNU/Linux
/proc items:
cmdline: BOOT_IMAGE=/boot/vmlinuz-6.12.48+deb13-rt-amd64 root=UUID=5efc6035-1184-4e51-acb6-e99aeeac4490 ro quiet isolcpus=3
model name: Intel(R) N100
cores: 4
cpu MHz: 1744.606
parport:
serial:
Versions:
gcc: gcc (Debian 14.2.0-19) 14.2.0
python: Python 3.13.5
git: not_in_PATH
git commit: NA
tcl: 8.6
/usr/bin/linuxcnc_info: line 159: wish: command not found
tk:
glade: not_in_PATH
linuxcnc_var all:
LINUXCNCVERSION: 2.9.4
LINUXCNC_AUX_GLADEVCP: /usr/share/linuxcnc/aux_gladevcp
LINUXCNC_AUX_EXAMPLES: /usr/share/linuxcnc/aux_examples
REALTIME: /usr/lib/linuxcnc/realtime
RTS: uspace
HALLIB_DIR: /usr/share/linuxcnc/hallib
PYTHON: /usr/bin/python3
dpkg -l '*linuxcnc*':
Desired=Unknown/Install/Remove/Purge/Hold
| Status=Not/Inst/Conf-files/Unpacked/halF-conf/Half-inst/trig-aWait/Trig-pend
|/ Err?=(none)/Reinst-required (Status,Err: uppercase=bad)
||/ Name Version Architecture Description
+++-===================-============-============-=====================================================================
un linuxcnc <none> <none> (no description available)
un linuxcnc-dev <none> <none> (no description available)
un linuxcnc-doc <none> <none> (no description available)
ii linuxcnc-doc-en 1:2.9.4-2 all motion controller for CNC machines and robots (English documentation)
un linuxcnc-doc-es <none> <none> (no description available)
un linuxcnc-doc-fr <none> <none> (no description available)
un linuxcnc-sim <none> <none> (no description available)
un linuxcnc-sim-dev <none> <none> (no description available)
ii linuxcnc-uspace 1:2.9.4-2 amd64 motion controller for CNC machines and robots
ii linuxcnc-uspace-dev 1:2.9.4-2 amd64 PC based motion controller for real-time Linux
- Aciera
21 Nov 2025 14:39
Replied by Aciera on topic v2.9 and not the perpendicularity of X and Y
Glad you got it working.
- abs32
21 Nov 2025 13:41
Replied by abs32 on topic v2.9 and not the perpendicularity of X and Y
Внес исправления как написал, скомпилировал, запустил = РАБОТАЕТ! Ай да Пушкин, ай да сукин сын!
Made corrections as written, compiled, launched = WORKS! Oh yes Pushkin,
Made corrections as written, compiled, launched = WORKS! Oh yes Pushkin,
- meister
21 Nov 2025 13:32
Replied by meister on topic Tipps für aktuelle LinuxCNC Hardware gesucht
hatte meine 7i92 auch letzte woche bekommen,
hab nicht viel getestet, aber läuft soweit.
hab nicht viel getestet, aber läuft soweit.
- abs32
21 Nov 2025 13:16 - 21 Nov 2025 13:24
Replied by abs32 on topic v2.9 and not the perpendicularity of X and Y
probably, this is influenced only by that part of ini where the formula XXYYZ and then something like that? -
// Apply inverse matrix transform to the 3 cartesian coordinates
pos->tran.x = invdet * ( (e * i - f * h) * j[0]
+(c * h - b * i) * j[2]
+(b * f - c * e) * j[4]);
pos->tran.y = invdet * ( (f * g - d * i) * j[0]
+(a * i - c * g) * j[2]
+(c * d - a * f) * j[4]);
pos->tran.z = invdet * ( (d * h - e * g) * j[0]
+(b * g - a * h) * j[2]
+(a * e - b * d) * j[4]);
// Pass rest of axes as identity
//if (EMCMOT_MAX_JOINTS > 3) pos->a = j[3];
//if (EMCMOT_MAX_JOINTS > 4) pos->b = j[4];
if (EMCMOT_MAX_JOINTS > 5) pos->c = j[5];
if (EMCMOT_MAX_JOINTS > 6) pos->u = j[6];
if (EMCMOT_MAX_JOINTS > 7) pos->v = j[7];
if (EMCMOT_MAX_JOINTS > pos->w = j[8];
// Apply matrix transform to the 3 cartesian coordinates
j[0] = pos->tran.x * a + pos->tran.y * b + pos->tran.z * c;
j[1] = pos->tran.x * a + pos->tran.y * b + pos->tran.z * c;
j[2] = pos->tran.x * d + pos->tran.y * e + pos->tran.z * f;
j[3] = pos->tran.x * d + pos->tran.y * e + pos->tran.z * f;
j[4] = pos->tran.x * g + pos->tran.y * h + pos->tran.z * i;
// Pass rest of axes as identity
// if (EMCMOT_MAX_JOINTS > 3) j[3] = pos->a;
//if (EMCMOT_MAX_JOINTS > 4) j[4] = pos->b;
if (EMCMOT_MAX_JOINTS > 5) j[5] = pos->c;
if (EMCMOT_MAX_JOINTS > 6) j[6] = pos->u;
if (EMCMOT_MAX_JOINTS > 7) j[7] = pos->v;
if (EMCMOT_MAX_JOINTS > j[8] = pos->w;
?
This is certainly not a one-size-fits-all solution with automatic situation recognition, but for a specific situation
// Apply inverse matrix transform to the 3 cartesian coordinates
pos->tran.x = invdet * ( (e * i - f * h) * j[0]
+(c * h - b * i) * j[2]
+(b * f - c * e) * j[4]);
pos->tran.y = invdet * ( (f * g - d * i) * j[0]
+(a * i - c * g) * j[2]
+(c * d - a * f) * j[4]);
pos->tran.z = invdet * ( (d * h - e * g) * j[0]
+(b * g - a * h) * j[2]
+(a * e - b * d) * j[4]);
// Pass rest of axes as identity
//if (EMCMOT_MAX_JOINTS > 3) pos->a = j[3];
//if (EMCMOT_MAX_JOINTS > 4) pos->b = j[4];
if (EMCMOT_MAX_JOINTS > 5) pos->c = j[5];
if (EMCMOT_MAX_JOINTS > 6) pos->u = j[6];
if (EMCMOT_MAX_JOINTS > 7) pos->v = j[7];
if (EMCMOT_MAX_JOINTS >
pos->w = j[8];// Apply matrix transform to the 3 cartesian coordinates
j[0] = pos->tran.x * a + pos->tran.y * b + pos->tran.z * c;
j[1] = pos->tran.x * a + pos->tran.y * b + pos->tran.z * c;
j[2] = pos->tran.x * d + pos->tran.y * e + pos->tran.z * f;
j[3] = pos->tran.x * d + pos->tran.y * e + pos->tran.z * f;
j[4] = pos->tran.x * g + pos->tran.y * h + pos->tran.z * i;
// Pass rest of axes as identity
// if (EMCMOT_MAX_JOINTS > 3) j[3] = pos->a;
//if (EMCMOT_MAX_JOINTS > 4) j[4] = pos->b;
if (EMCMOT_MAX_JOINTS > 5) j[5] = pos->c;
if (EMCMOT_MAX_JOINTS > 6) j[6] = pos->u;
if (EMCMOT_MAX_JOINTS > 7) j[7] = pos->v;
if (EMCMOT_MAX_JOINTS >
j[8] = pos->w;?
This is certainly not a one-size-fits-all solution with automatic situation recognition, but for a specific situation
- abs32
21 Nov 2025 13:03 - 22 Nov 2025 10:12
Replied by abs32 on topic v2.9 and not the perpendicularity of X and Y
file
- Aciera
21 Nov 2025 13:02
Replied by Aciera on topic v2.9 and not the perpendicularity of X and Y
Attachments missing
- Tinker
21 Nov 2025 12:56
Replied by Tinker on topic Probe basic launch issue
So I installed python3-pyqt5.qtquick and now it works !!!! Thank you sooo much!!
- abs32
21 Nov 2025 12:53
Replied by abs32 on topic v2.9 and not the perpendicularity of X and Y
hal+ini
- Ul
21 Nov 2025 12:52 - 21 Nov 2025 13:26
Replied by Ul on topic Tipps für aktuelle LinuxCNC Hardware gesucht
Habe meine Mesakarten vorgestern erhalten, gestern getestet. Sowohl die 7i92, als auch die 7i98 funktionieren einwandfrei mit originaler Mesa Firmware. Auch die Busschalter funktionieren so, wie sie sollen (inkl. Pegelwandlerfunktion). Die Widerstände an den Pins sind externe pull-up Widerstände.
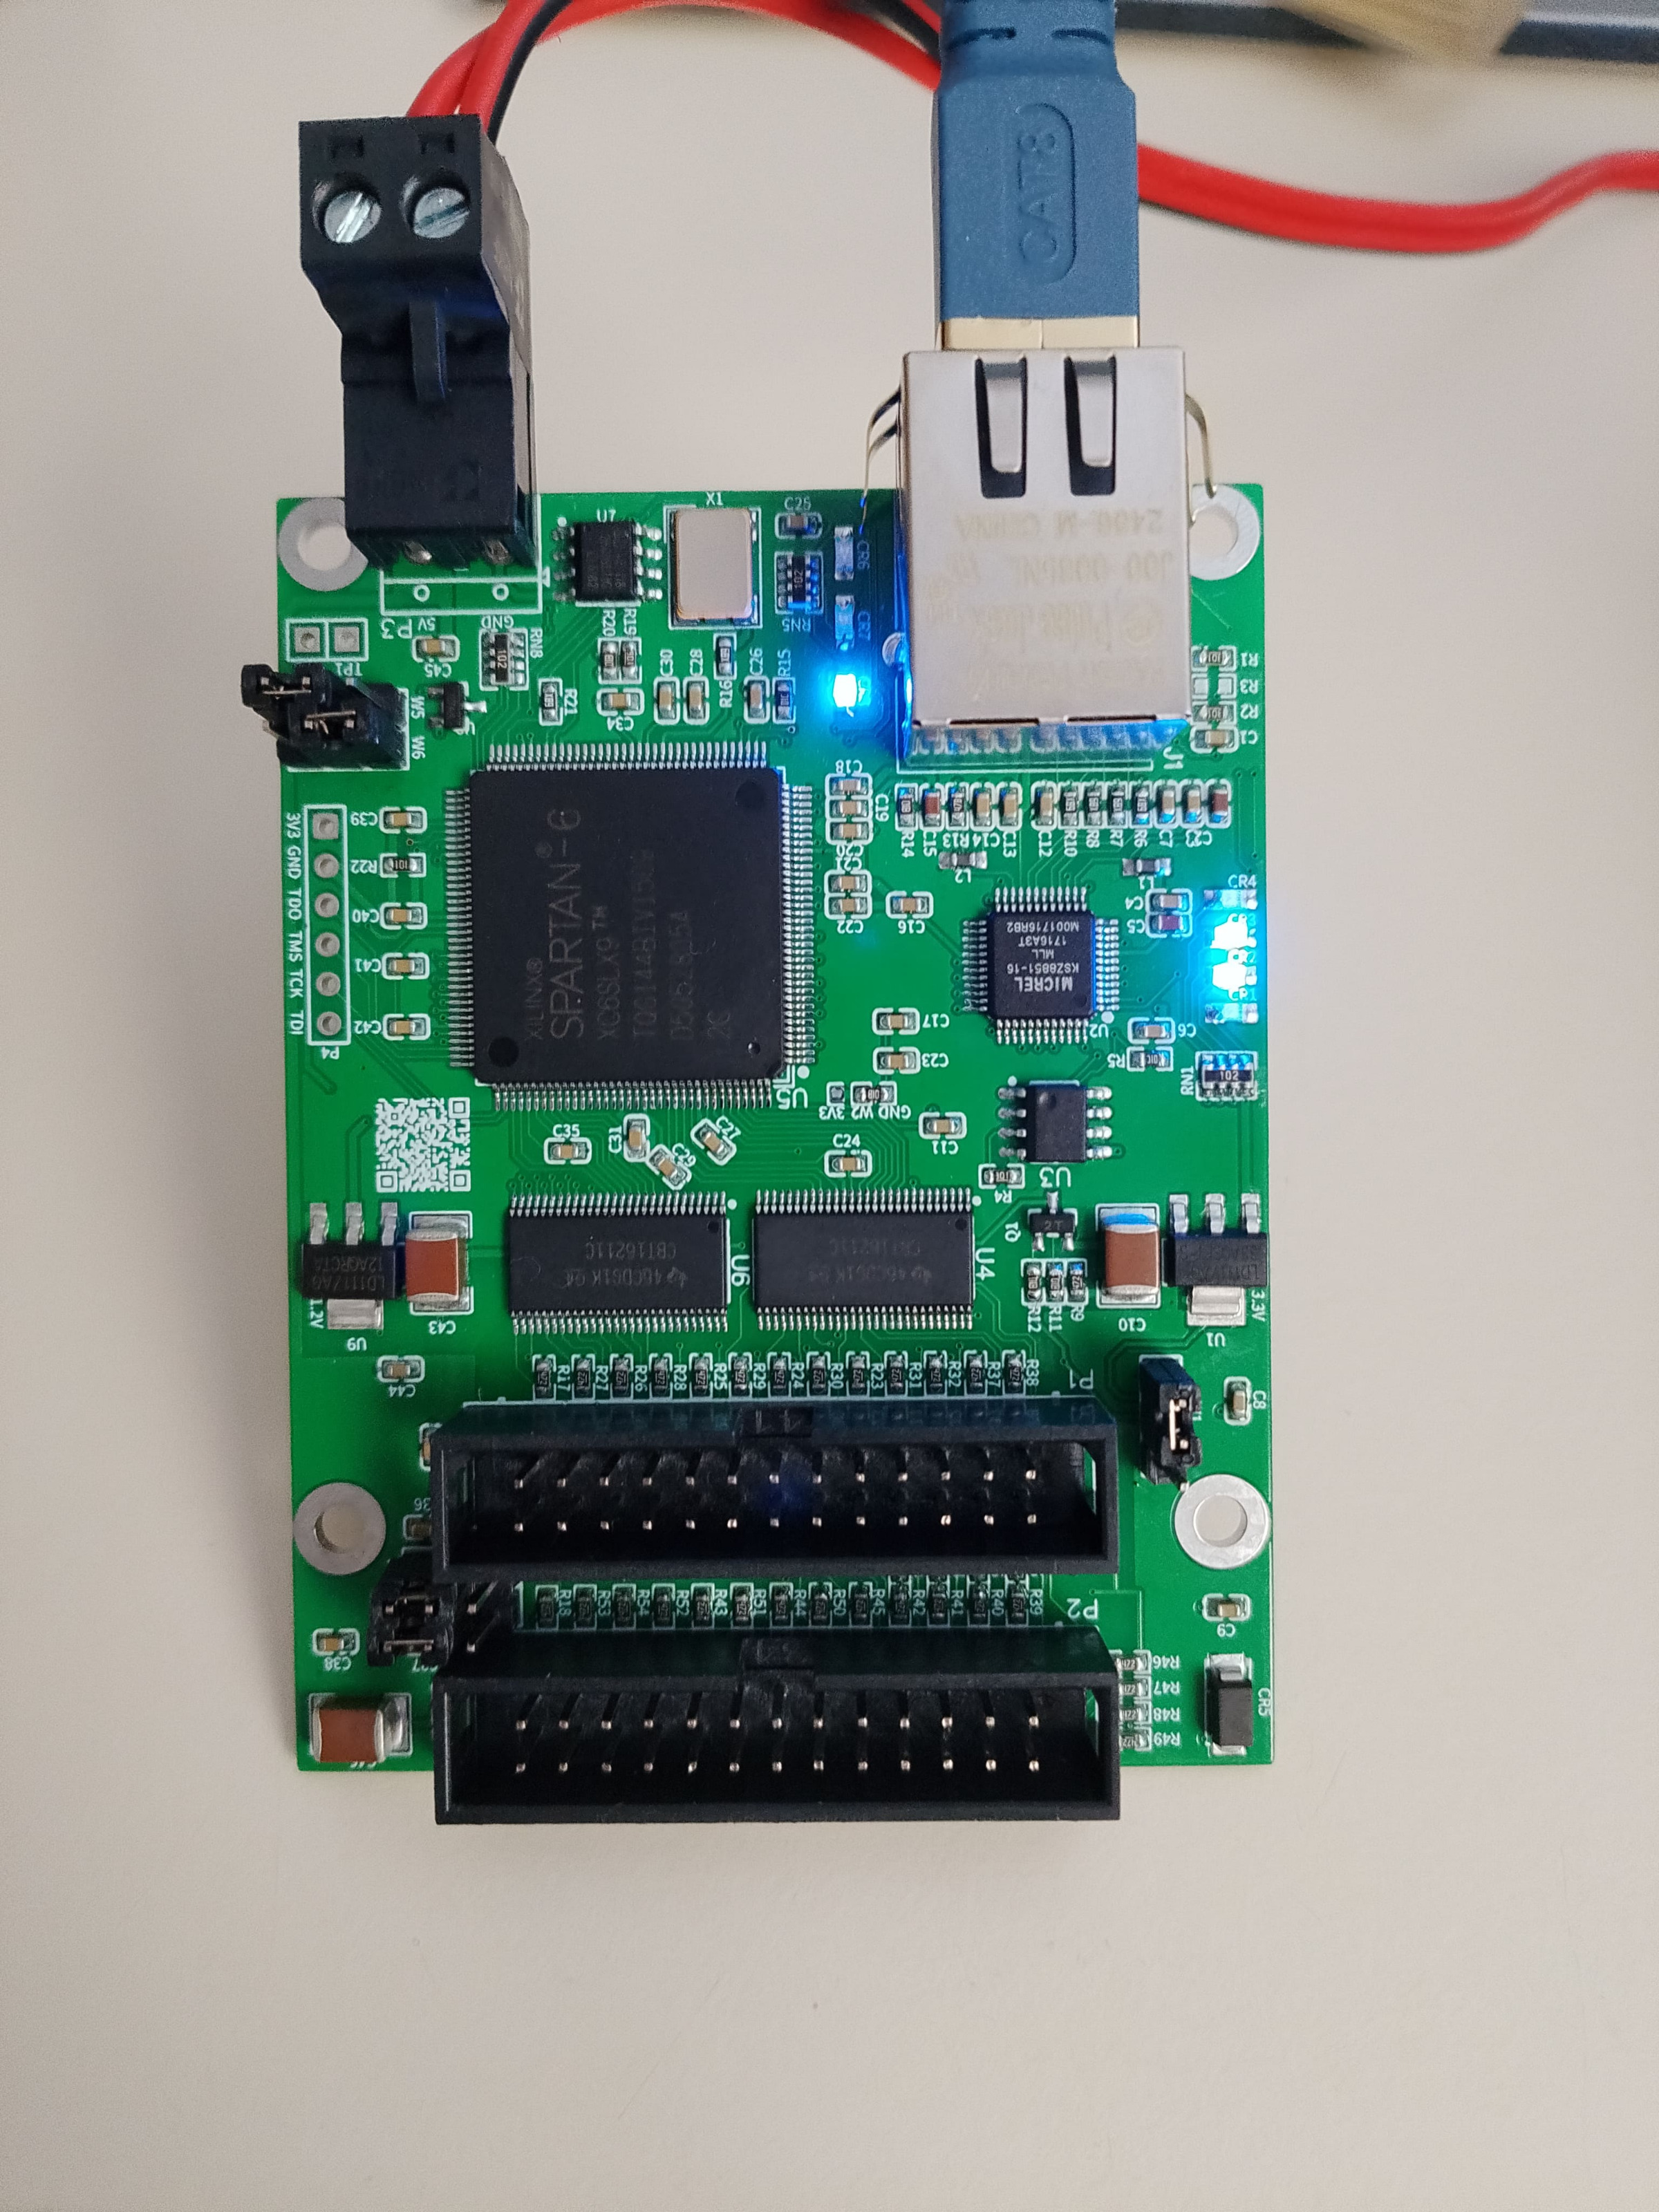
Bei der 7i92 ist es wichtig, die richtige ZIP-Datei herunterzuladen (für die 7i92H oder 7i92TH). 7i92t.zip lässt sich nicht flashen.
Wichtig zu wissen ist, dass der Fallback-Jumper nicht funktioniert.
Falls die Karte vom Raspberry nicht erkannt wird, muss man zuerst die Verbindung über die Konsole herstellen:
sudo ip addr add 10.10.10.11/8 dev eth0
sudo ip link set eth0 up
Ich bin mit dem Kauf jedenfalls so zufrieden, dass ich eine weitere 7i98 bestellt habe, diesmal in 7i92-Größe: de.aliexpress.com/item/1005010164826951.html image missing /media/kunena/emoticons/laughing.png
Bei der 7i92 ist es wichtig, die richtige ZIP-Datei herunterzuladen (für die 7i92H oder 7i92TH). 7i92t.zip lässt sich nicht flashen.
Wichtig zu wissen ist, dass der Fallback-Jumper nicht funktioniert.
Falls die Karte vom Raspberry nicht erkannt wird, muss man zuerst die Verbindung über die Konsole herstellen:
sudo ip addr add 10.10.10.11/8 dev eth0
sudo ip link set eth0 up
Ich bin mit dem Kauf jedenfalls so zufrieden, dass ich eine weitere 7i98 bestellt habe, diesmal in 7i92-Größe: de.aliexpress.com/item/1005010164826951.html image missing /media/kunena/emoticons/laughing.png
- Tinker
21 Nov 2025 12:43
Replied by Tinker on topic Probe basic launch issue
Sorry, I'm a total beginner when it comes to this stuff. I'm at the copy and paste stage and don't really know what I'm looking for on that link...Is there a specific package I should download?
- unknown
21 Nov 2025 12:35
Replied by unknown on topic Probe basic launch issue
Sorry I may have given the wrong package.
Have a look at this one.
packages.debian.org/trixie/amd64/python3-pyqt5.qtquick
Many apologies I was working from memory and apparently my memory was corrupted. I apologise for any time wasted.
Regarding the python errors if yo get a ModuleNotFoundError you can search for the name of the module that is stated as missing .
Have a look at this one.
packages.debian.org/trixie/amd64/python3-pyqt5.qtquick
Many apologies I was working from memory and apparently my memory was corrupted. I apologise for any time wasted.
Regarding the python errors if yo get a ModuleNotFoundError you can search for the name of the module that is stated as missing .
- unknown
21 Nov 2025 12:29
Replied by unknown on topic [SOLVED] Backlash issues on Y-AXIS
When the tech bros talk about realtime they aren't referring to the PREEMPT RT kernel that Linuxcnc requires. That requires setting a couple of extra options in the kernel config. I understand that it can appear confusing.
Whilst I haven't built a 3b distro, I only have access to a 4 and 5 there just might be a chance that the experimental image I've been working may work. When I say work I mean it may boot, as for latency, you may need to add isolcpus 2,3 to command line text. Even then I can't guarantee that latency will be suitable.
The thread I started regarding the experimental image has a link to the image.
Whilst I haven't built a 3b distro, I only have access to a 4 and 5 there just might be a chance that the experimental image I've been working may work. When I say work I mean it may boot, as for latency, you may need to add isolcpus 2,3 to command line text. Even then I can't guarantee that latency will be suitable.
The thread I started regarding the experimental image has a link to the image.
- Tinker
21 Nov 2025 12:27
Replied by Tinker on topic Probe basic launch issue
I installed the sugested files and now I am getting the following error report.
Traceback (most recent call last):
File "/usr/bin/probe_basic", line 8, in <module>
sys.exit(main())
~~~~^^
File "/usr/lib/python3/dist-packages/probe_basic/__init__.py", line 20, in main
qtpyvcp.run_vcp(opts, VCP_CONFIG_FILE)
~~~~~~~~~~~~~~~^^^^^^^^^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/qtpyvcp/__init__.py", line 26, in run_vcp
run(*args, **kwargs)
~~~^^^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/qtpyvcp/app/__init__.py", line 129, in run
launch_application(opts, config)
~~~~~~~~~~~~~~~~~~^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/qtpyvcp/app/launcher.py", line 78, in launch_application
loadWindows(config)
~~~~~~~~~~~^^^^^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/qtpyvcp/app/launcher.py", line 230, in loadWindows
window = _initialize_object_from_dict(window_dict)
File "/usr/lib/python3/dist-packages/qtpyvcp/app/launcher.py", line 210, in _initialize_object_from_dict
return obj(*args, **kwargs)
File "/usr/lib/python3/dist-packages/probe_basic/probe_basic.py", line 35, in __init__
super(ProbeBasic, self).__init__(*args, **kwargs)
~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~^^^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/qtpyvcp/widgets/form_widgets/main_window.py", line 56, in __init__
self.loadUi(ui_file)
~~~~~~~~~~~^^^^^^^^^
File "/usr/lib/python3/dist-packages/qtpyvcp/widgets/form_widgets/main_window.py", line 115, in loadUi
uic.loadUi(ui_file, self)
~~~~~~~~~~^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/__init__.py", line 241, in loadUi
return DynamicUILoader(package).loadUi(uifile, baseinstance, resource_suffix)
~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/Loader/loader.py", line 66, in loadUi
return self.parse(filename, resource_suffix)
~~~~~~~~~~^^^^^^^^^^^^^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 1037, in parse
actor(elem)
~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 828, in createUserInterface
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 273, in createWidget
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 503, in createLayout
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 546, in handleItem
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 503, in createLayout
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 546, in handleItem
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 503, in createLayout
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 546, in handleItem
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 273, in createWidget
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 273, in createWidget
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 503, in createLayout
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 546, in handleItem
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 503, in createLayout
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 546, in handleItem
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 264, in createWidget
self.stack.push(self.setupObject(widget_class, parent, elem))
~~~~~~~~~~~~~~~~^^^^^^^^^^^^^^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 228, in setupObject
obj = self.factory.createQObject(clsname, name, args, is_attribute)
File "/usr/lib/python3/dist-packages/PyQt5/uic/objcreator.py", line 100, in createQObject
factory = self.findQObjectType(classname)
File "/usr/lib/python3/dist-packages/PyQt5/uic/objcreator.py", line 125, in findQObjectType
w = module.search(classname)
File "/usr/lib/python3/dist-packages/PyQt5/uic/Loader/qobjectcreator.py", line 113, in search
module = __import__(mname, {}, {}, (cls,))
File "/usr/lib/python3/dist-packages/widgets/__init__.py", line 3, in <module>
from widgets.lathe_tool_touch_off.lathe_tool_touch_off import LatheToolTouchOff
File "/usr/lib/python3/dist-packages/widgets/lathe_tool_touch_off/lathe_tool_touch_off.py", line 19, in <module>
from qtpy.QtQuickWidgets import QQuickWidget
File "/usr/lib/python3/dist-packages/qtpy/QtQuickWidgets.py", line 13, in <module>
from PyQt5.QtQuickWidgets import *
ModuleNotFoundError: No module named 'PyQt5.QtQuickWidgets'
Traceback (most recent call last):
File "/usr/bin/probe_basic", line 8, in <module>
sys.exit(main())
~~~~^^
File "/usr/lib/python3/dist-packages/probe_basic/__init__.py", line 20, in main
qtpyvcp.run_vcp(opts, VCP_CONFIG_FILE)
~~~~~~~~~~~~~~~^^^^^^^^^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/qtpyvcp/__init__.py", line 26, in run_vcp
run(*args, **kwargs)
~~~^^^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/qtpyvcp/app/__init__.py", line 129, in run
launch_application(opts, config)
~~~~~~~~~~~~~~~~~~^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/qtpyvcp/app/launcher.py", line 78, in launch_application
loadWindows(config)
~~~~~~~~~~~^^^^^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/qtpyvcp/app/launcher.py", line 230, in loadWindows
window = _initialize_object_from_dict(window_dict)
File "/usr/lib/python3/dist-packages/qtpyvcp/app/launcher.py", line 210, in _initialize_object_from_dict
return obj(*args, **kwargs)
File "/usr/lib/python3/dist-packages/probe_basic/probe_basic.py", line 35, in __init__
super(ProbeBasic, self).__init__(*args, **kwargs)
~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~^^^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/qtpyvcp/widgets/form_widgets/main_window.py", line 56, in __init__
self.loadUi(ui_file)
~~~~~~~~~~~^^^^^^^^^
File "/usr/lib/python3/dist-packages/qtpyvcp/widgets/form_widgets/main_window.py", line 115, in loadUi
uic.loadUi(ui_file, self)
~~~~~~~~~~^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/__init__.py", line 241, in loadUi
return DynamicUILoader(package).loadUi(uifile, baseinstance, resource_suffix)
~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~~^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/Loader/loader.py", line 66, in loadUi
return self.parse(filename, resource_suffix)
~~~~~~~~~~^^^^^^^^^^^^^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 1037, in parse
actor(elem)
~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 828, in createUserInterface
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 273, in createWidget
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 503, in createLayout
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 546, in handleItem
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 503, in createLayout
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 546, in handleItem
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 503, in createLayout
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 546, in handleItem
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 273, in createWidget
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 273, in createWidget
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 503, in createLayout
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 546, in handleItem
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 503, in createLayout
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 546, in handleItem
self.traverseWidgetTree(elem)
~~~~~~~~~~~~~~~~~~~~~~~^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 806, in traverseWidgetTree
handler(self, child)
~~~~~~~^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 264, in createWidget
self.stack.push(self.setupObject(widget_class, parent, elem))
~~~~~~~~~~~~~~~~^^^^^^^^^^^^^^^^^^^^^^^^^^^^
File "/usr/lib/python3/dist-packages/PyQt5/uic/uiparser.py", line 228, in setupObject
obj = self.factory.createQObject(clsname, name, args, is_attribute)
File "/usr/lib/python3/dist-packages/PyQt5/uic/objcreator.py", line 100, in createQObject
factory = self.findQObjectType(classname)
File "/usr/lib/python3/dist-packages/PyQt5/uic/objcreator.py", line 125, in findQObjectType
w = module.search(classname)
File "/usr/lib/python3/dist-packages/PyQt5/uic/Loader/qobjectcreator.py", line 113, in search
module = __import__(mname, {}, {}, (cls,))
File "/usr/lib/python3/dist-packages/widgets/__init__.py", line 3, in <module>
from widgets.lathe_tool_touch_off.lathe_tool_touch_off import LatheToolTouchOff
File "/usr/lib/python3/dist-packages/widgets/lathe_tool_touch_off/lathe_tool_touch_off.py", line 19, in <module>
from qtpy.QtQuickWidgets import QQuickWidget
File "/usr/lib/python3/dist-packages/qtpy/QtQuickWidgets.py", line 13, in <module>
from PyQt5.QtQuickWidgets import *
ModuleNotFoundError: No module named 'PyQt5.QtQuickWidgets'
Time to create page: 0.182 seconds