EMCO Compact 5 cnc Turret with dc motor and no feedback

More
7 months 4 weeks ago #343739 by hitchhiker
Hi guys

does someone done a retrofit of the compact 5 cnc with turret with dc motor and NO feedback?

my way would be:

add a pyvcp menu to make move from tool position to tool position.

if i reach tool 1 i set with a button that its now tool1.

every move from tool to tool would lock first back and then drive forward to next position... 

turret can rotate forward free. Backward would lock it.
after locking backward reducing power is needed.

i have here a l298n modul and a mesa 7i92 with bitfile adjusted to have pwm and 2 gpios for setting direction.

i cant find a custom library for it. But is this the correct way to do it or i am complete lost? Its not the issue to set tool 1 manual over buttons.

Forward u would use pwm 100%
Backward pwm 60%
and holding against the pawl about pwm 30%

any ideas or help?

thanks

Please Log in or Create an account to join the conversation.

More
7 months 4 weeks ago #343762 by tommylight


i have here a l298n modul and a mesa 7i92 with bitfile adjusted to have pwm and 2 gpios for setting direction.
You could start by having a look at the "etch a sketch" config included with LinuxCNC, it is for parallel port so needs changing pin names to Mesa, and it is for L298.
Probably doing some timing stuff in hal using timedelay and/or oneshot and maybe flip-flop ....

Please Log in or Create an account to join the conversation.

More
7 months 4 weeks ago - 7 months 4 weeks ago #343765 by hitchhiker
I got it work with a own component to make 1 move from position to position forwaes with lock backward and reduce pwm.

But the turret can only travel to next position in forward.

If i am on tool 5 and i want tool 1.. i need 2 times the move.
Is it possible to do this in the component with a abs function?

what i mean... i must handle the rollover=

presenttoolslots 6
currenttool is 6
calledtool is 1
Turretmoves = calledtool - currenttool = -5
Commandedmoves= presenttoolslots - (abs) turretmoves

next step is the to count every move.
moved = i++
if moved == commandedmoves
toolchange done

Sounds ok?!

I do the coordination of the forward and backward stuff with 2 time delays. On the end i set the pwm value lower to lock agoinst the pawl with lower current to not blow the dc motor.


Thanks
Last edit: 7 months 4 weeks ago by hitchhiker.

Please Log in or Create an account to join the conversation.
More
7 months 4 weeks ago #343797 by tommylight
Are you using the "carousel" component, or any other, or python remap for the tool changer?

Please Log in or Create an account to join the conversation.

More
7 months 4 weeks ago #343799 by hitchhiker
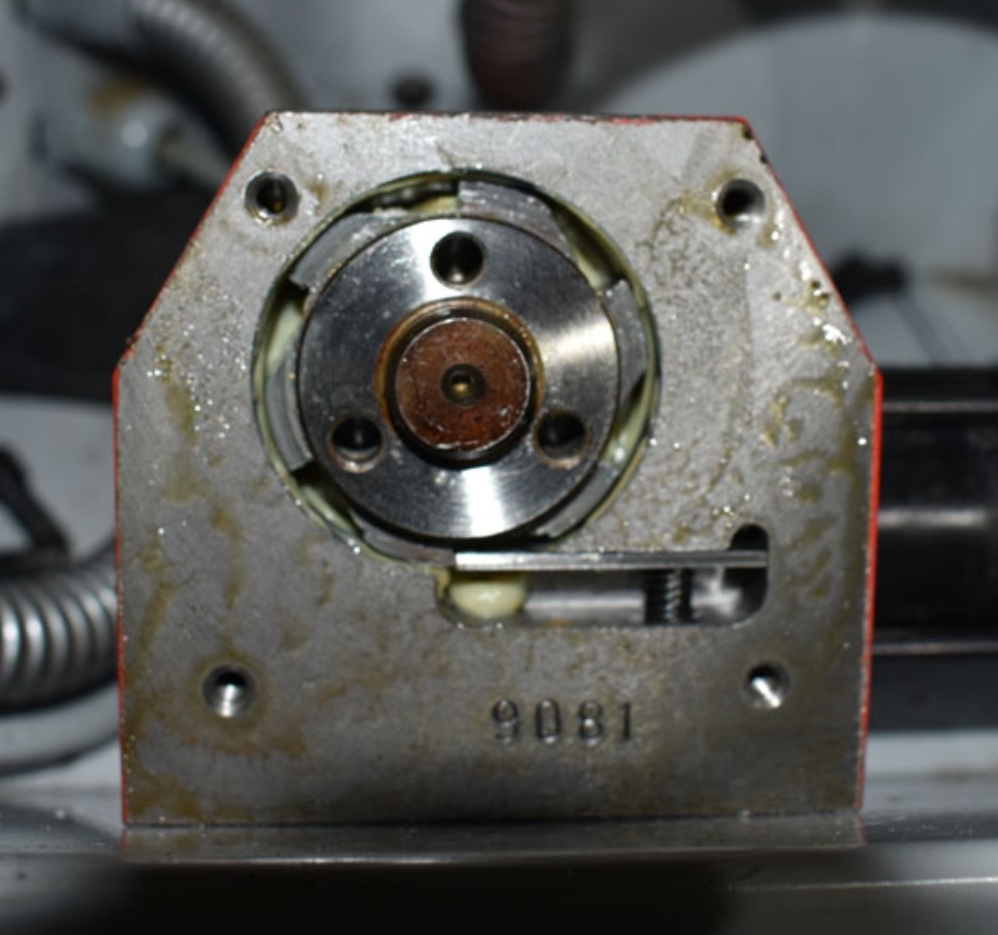
No because i have no feedback! Its only a dc motor and a disc that rotats in one direction and if you drive backward it looks against a pawl.

Here the mechanism


The dc motor drives a planetary gear.. the gear drives a wormgear.. the wormgear rotate the disc where the tools are mounted.


do you have a better solution without any feedback?
its not a issue to drive it to tool one and set it as tool 1.

i had years before mounted a stepper and done it with O Codes.. but the dc motor which was original used is bettee because it hold against the pawl. With stepper there is small small movement on the tool because its not holded against the pawl like the dc motor it does.


Please Log in or Create an account to join the conversation.

More
7 months 4 weeks ago #343813 by tommylight
OK, so the only solution seems to be the timedelay/oneshot version, where it would command the tool change always in the same direction (not sure if ABS component helps), does need a bit of hal wizardry, but i am out of ideas for now on how exactly to achieve that.

Please Log in or Create an account to join the conversation.

Time to create page: 0.081 seconds
Powered by Kunena Forum
