
- Posts: 1111
- Thank you received: 114
parametric blending path
- bkt
- Offline
- Platinum Member
-

Less
More
10 years 1 month ago - 10 years 1 month ago #80456
by bkt
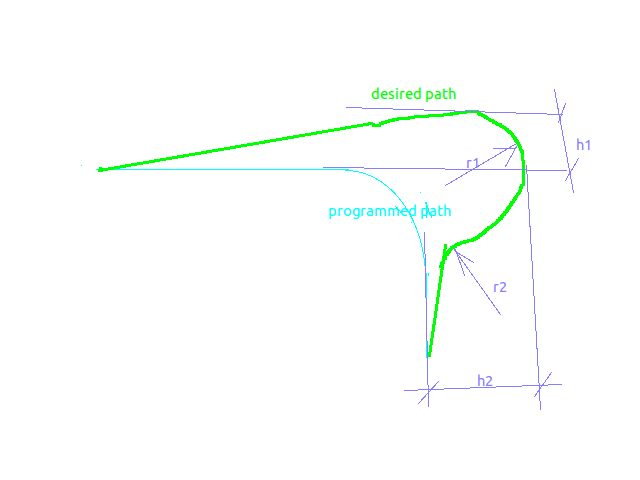
I'm new on these section ... my problem is how to create a custom Gcode or <ocall> that use r1-r2-h1-h2 that the parameter values are employees in a proportional way on the speed ... these because I use lcnc on deltarotary and "S" acceleration curve is not avaiable (using limit3 the result is good but not enought) ... so the other strategy is to change the trajectories in order to dampen the structural vibrations ... In the draw is not indicate the selected plain, is because I need 3d direction...
Is possible these whit Gcode or is better to create custom comp to do these?
Regards
Giorgio
parametric blending path was created by bkt
I'm new on these section ... my problem is how to create a custom Gcode or <ocall> that use r1-r2-h1-h2 that the parameter values are employees in a proportional way on the speed ... these because I use lcnc on deltarotary and "S" acceleration curve is not avaiable (using limit3 the result is good but not enought) ... so the other strategy is to change the trajectories in order to dampen the structural vibrations ... In the draw is not indicate the selected plain, is because I need 3d direction...
Is possible these whit Gcode or is better to create custom comp to do these?
Regards
Giorgio
Last edit: 10 years 1 month ago by bkt.
Please Log in or Create an account to join the conversation.
- bkt
- Offline
- Platinum Member
-
Less
More
- Posts: 1111
- Thank you received: 114
10 years 1 month ago - 10 years 1 month ago #80466
by bkt
Replied by bkt on topic parametric blending path
is impossible to use spiline G5 or G5.1 because I work in Z plane .... G5 in XY plane ...
Where are locate the G5 code in linuxcnc files? ... I think I can modify it for custom Gcode for have spiline in Z plane .....
Regards
giorgio
Where are locate the G5 code in linuxcnc files? ... I think I can modify it for custom Gcode for have spiline in Z plane .....
Regards
giorgio
Last edit: 10 years 1 month ago by bkt.
Please Log in or Create an account to join the conversation.
- andypugh
- Offline
- Moderator
-

Less
More
- Posts: 19899
- Thank you received: 4655
10 years 1 month ago #80577
by andypugh
Replied by andypugh on topic parametric blending path
Have a look for ariasrobo, that is LinuxCNC with S-curve trajectory planning.
To answer the other question, G5 is converted to canonical motion commands in src/emc/rs274ngc/interp_convert.cc at around line 116
To answer the other question, G5 is converted to canonical motion commands in src/emc/rs274ngc/interp_convert.cc at around line 116
The following user(s) said Thank You: bkt
Please Log in or Create an account to join the conversation.
- bkt
- Offline
- Platinum Member
-
Less
More
- Posts: 1111
- Thank you received: 114
10 years 1 month ago #80663
by bkt
Replied by bkt on topic parametric blending path
Tanks a lot ..... I see 2 day ago araisrobot solution and cnc-club solution (Jerk in Lcnc forum??) ...
cnc-club is referred to std. Lcnc ... solution-by-cnc-club ... but is good base to work for convert NewLinuxcnc/JA with S curve capacity ...
Not find araisrobot, code I see only the scara retrofit on youtube .... so I think the best approach to solve the problem is for first, study jerk solution for delta kins, study the example than if is a solution rewrite cnc-club modification for axes and joint too in new Lcnc ...
I work around G5 modification for now... insert jerk decc and acc in ja it seems a long thing ...
regards
giorgio
Please Log in or Create an account to join the conversation.
- Todd Zuercher
- Offline
- Platinum Member
-
Less
More
- Posts: 4793
- Thank you received: 1480
10 years 1 month ago #80669
by Todd Zuercher
Replied by Todd Zuercher on topic parametric blending path
github.com/araisrobo/linuxcnc
But I believe it is based on a much older version of Linuxcnc (before the new trajectory planner)
But I believe it is based on a much older version of Linuxcnc (before the new trajectory planner)
Please Log in or Create an account to join the conversation.
- Todd Zuercher
- Offline
- Platinum Member
-
Less
More
- Posts: 4793
- Thank you received: 1480
10 years 1 month ago #80670
by Todd Zuercher
Replied by Todd Zuercher on topic parametric blending path
It is a lot of work to integrate it, and probably why it hasn't been done. But if someone were to make it work, I have a few of machines I'd love to try it out on, but for the work we do the new trajectory planner is more important to reducing run-times.
Please Log in or Create an account to join the conversation.
Time to create page: 0.371 seconds