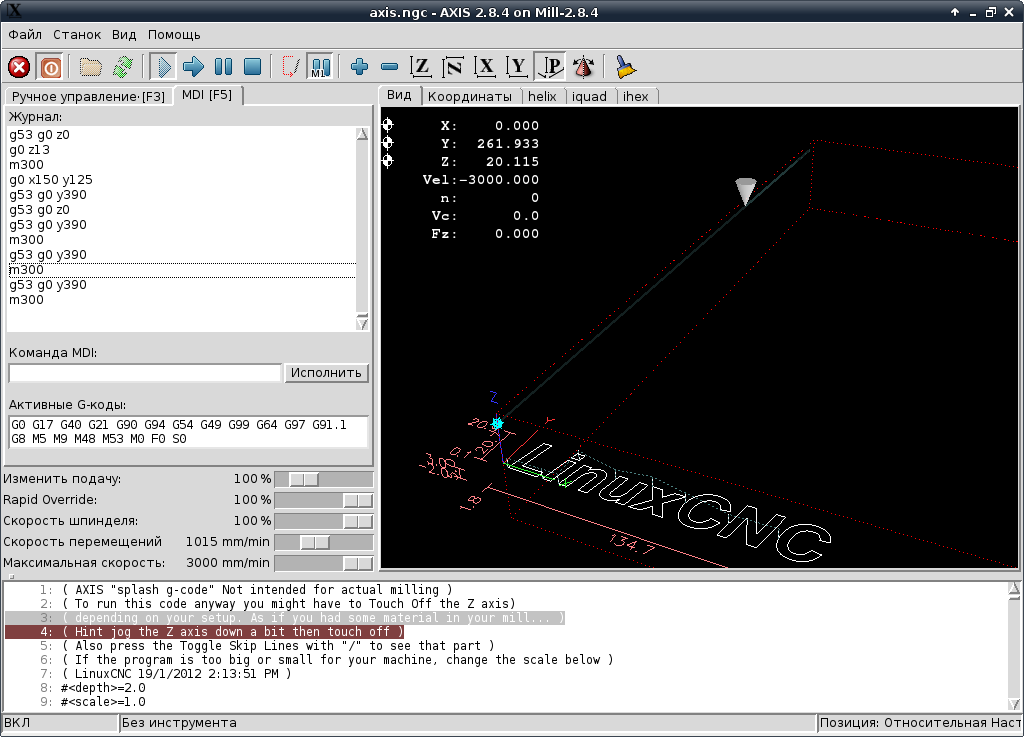
Not really sure where to drop this note, but maybe here is as good as anywhere else.
It might be nice if the velocity displayed in DRO "Vel:" would in some way represent the status of adaptive_feed, so maybe it should gain a negative sign when m52 is enabled and motion.adaptive-feed < 0 causing reverse motion?
I'm not sure what data you'd pull out of linuxcnc.stat() or wherever else to make that happen, so maybe it's more of a core linuxcnc than axis thing.
Does anyone have any suggestions? Am I missing some other place where I might see data about adaptive feeds status displayed? I realize I can fairly easily deal with this in a pyvcp panel...
-Dave