
- Posts: 59
- Thank you received: 10

Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.

Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.

Please Log in or Create an account to join the conversation.
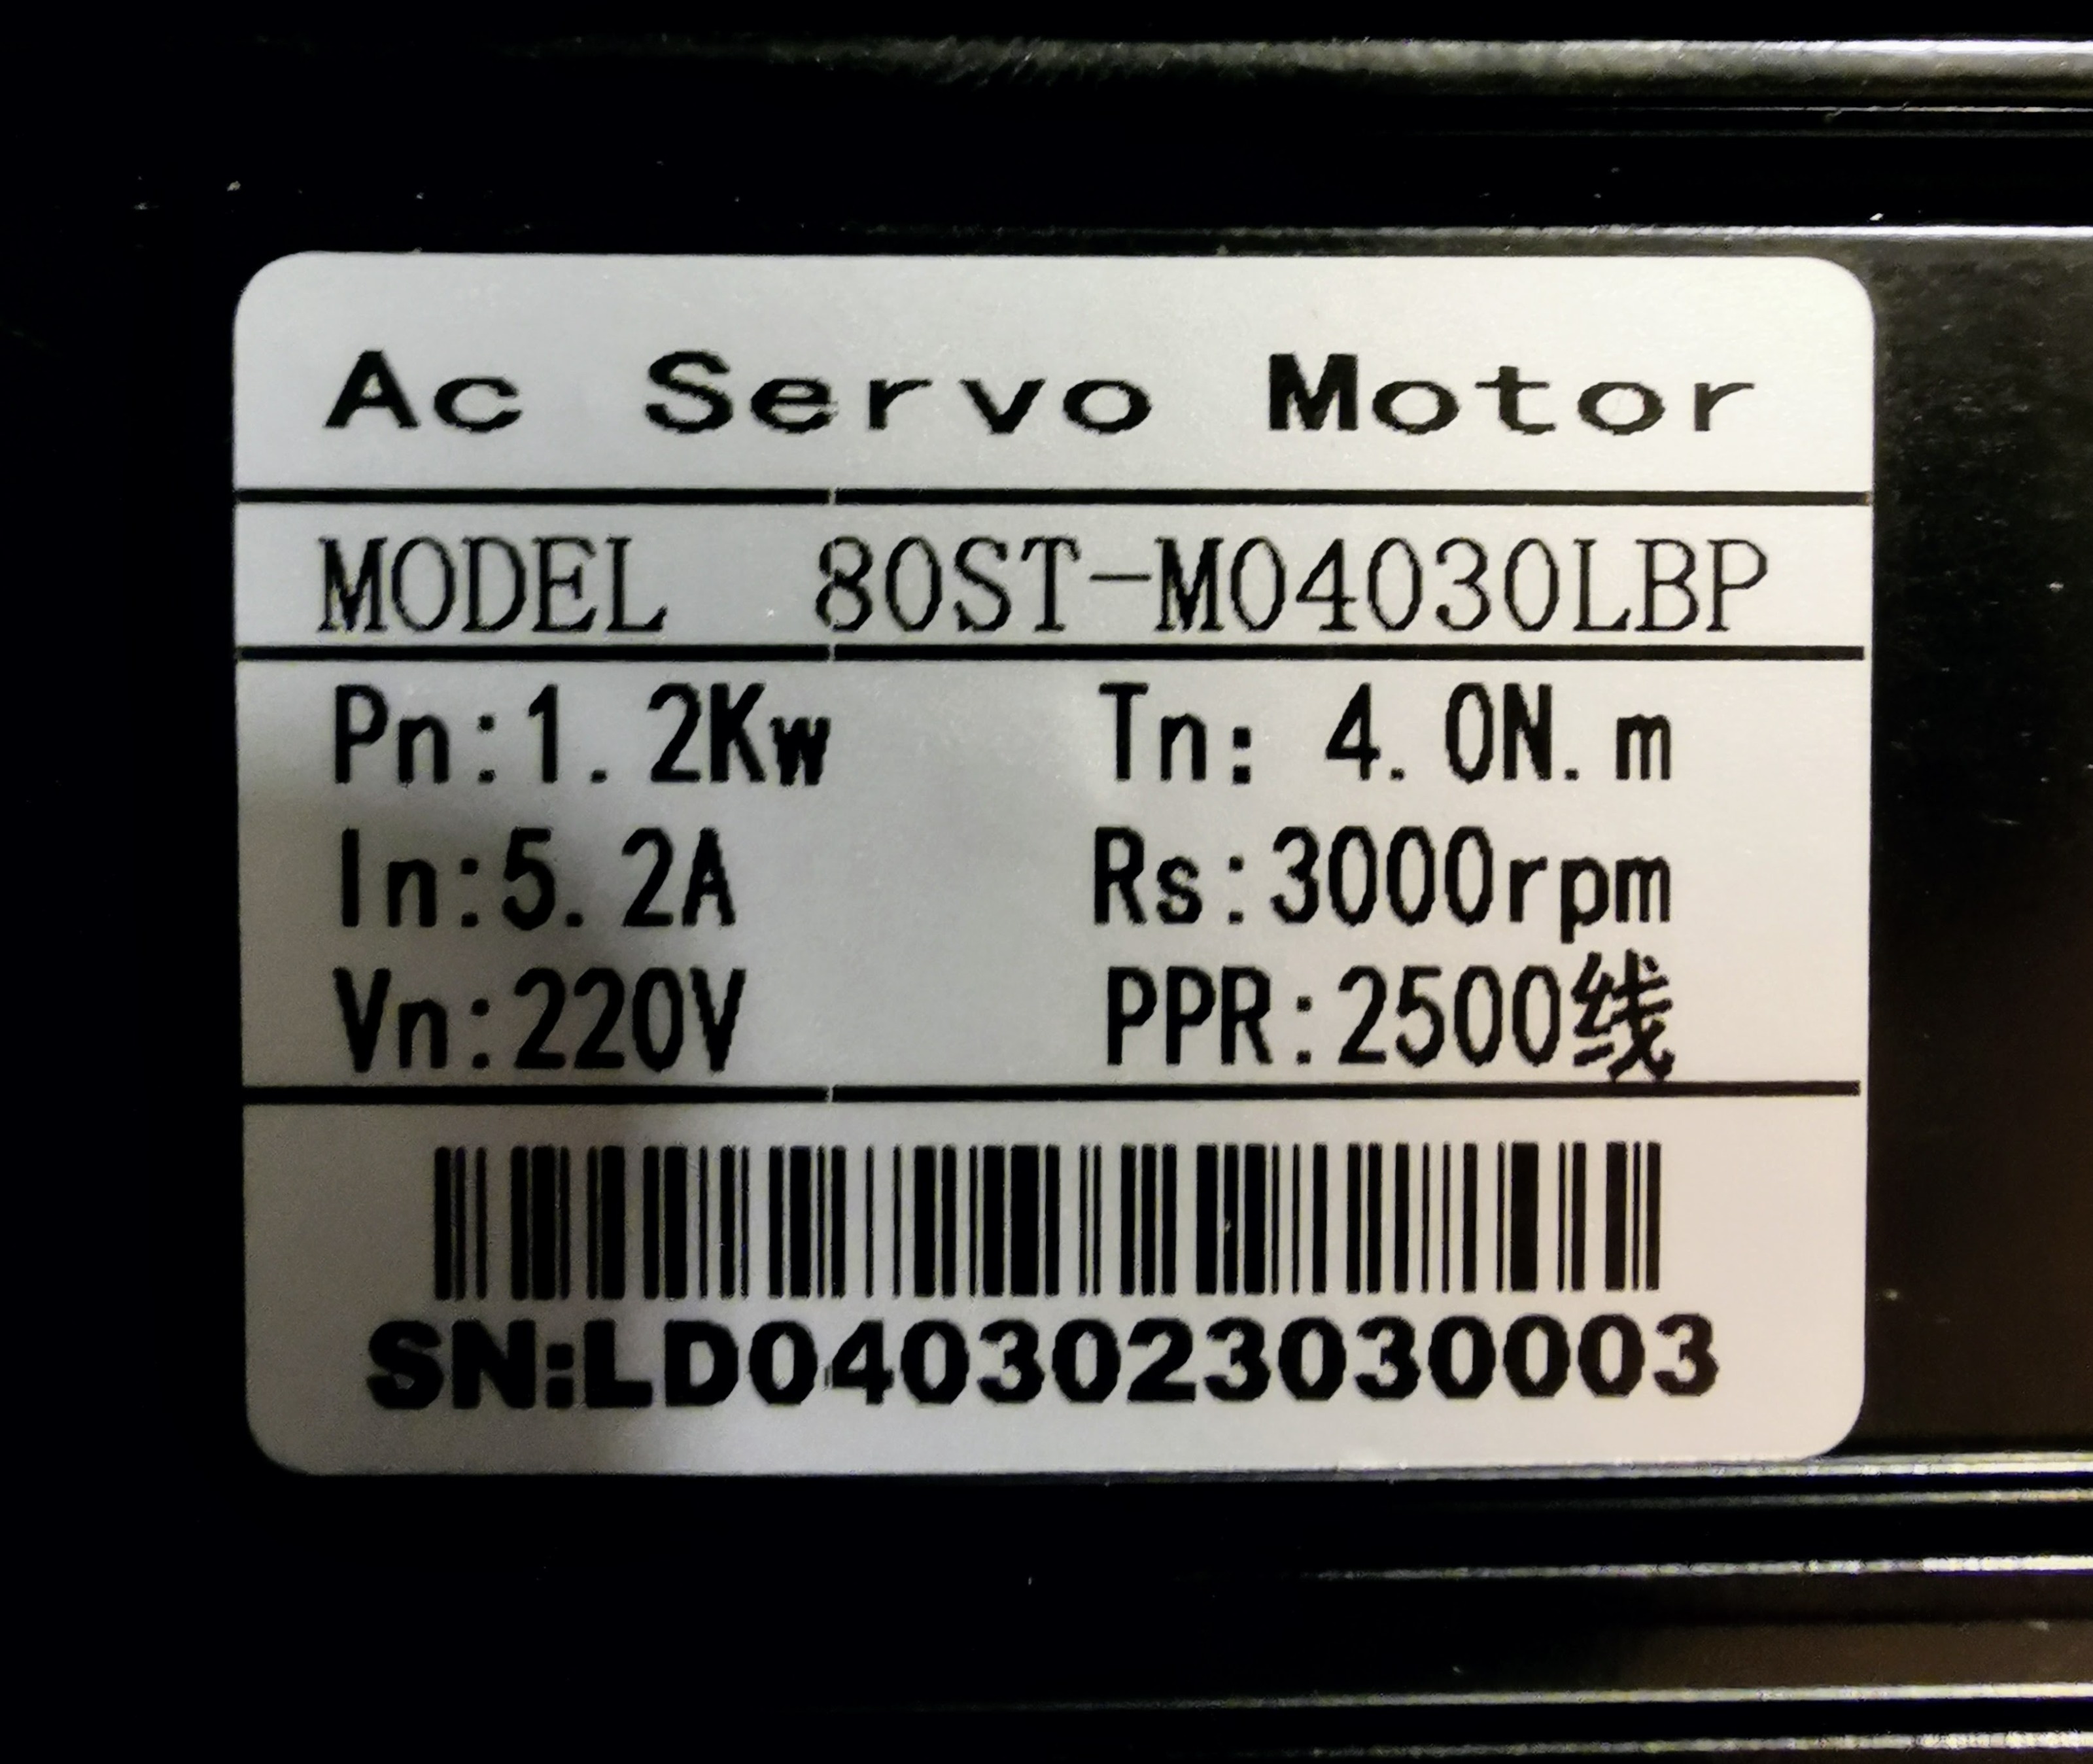
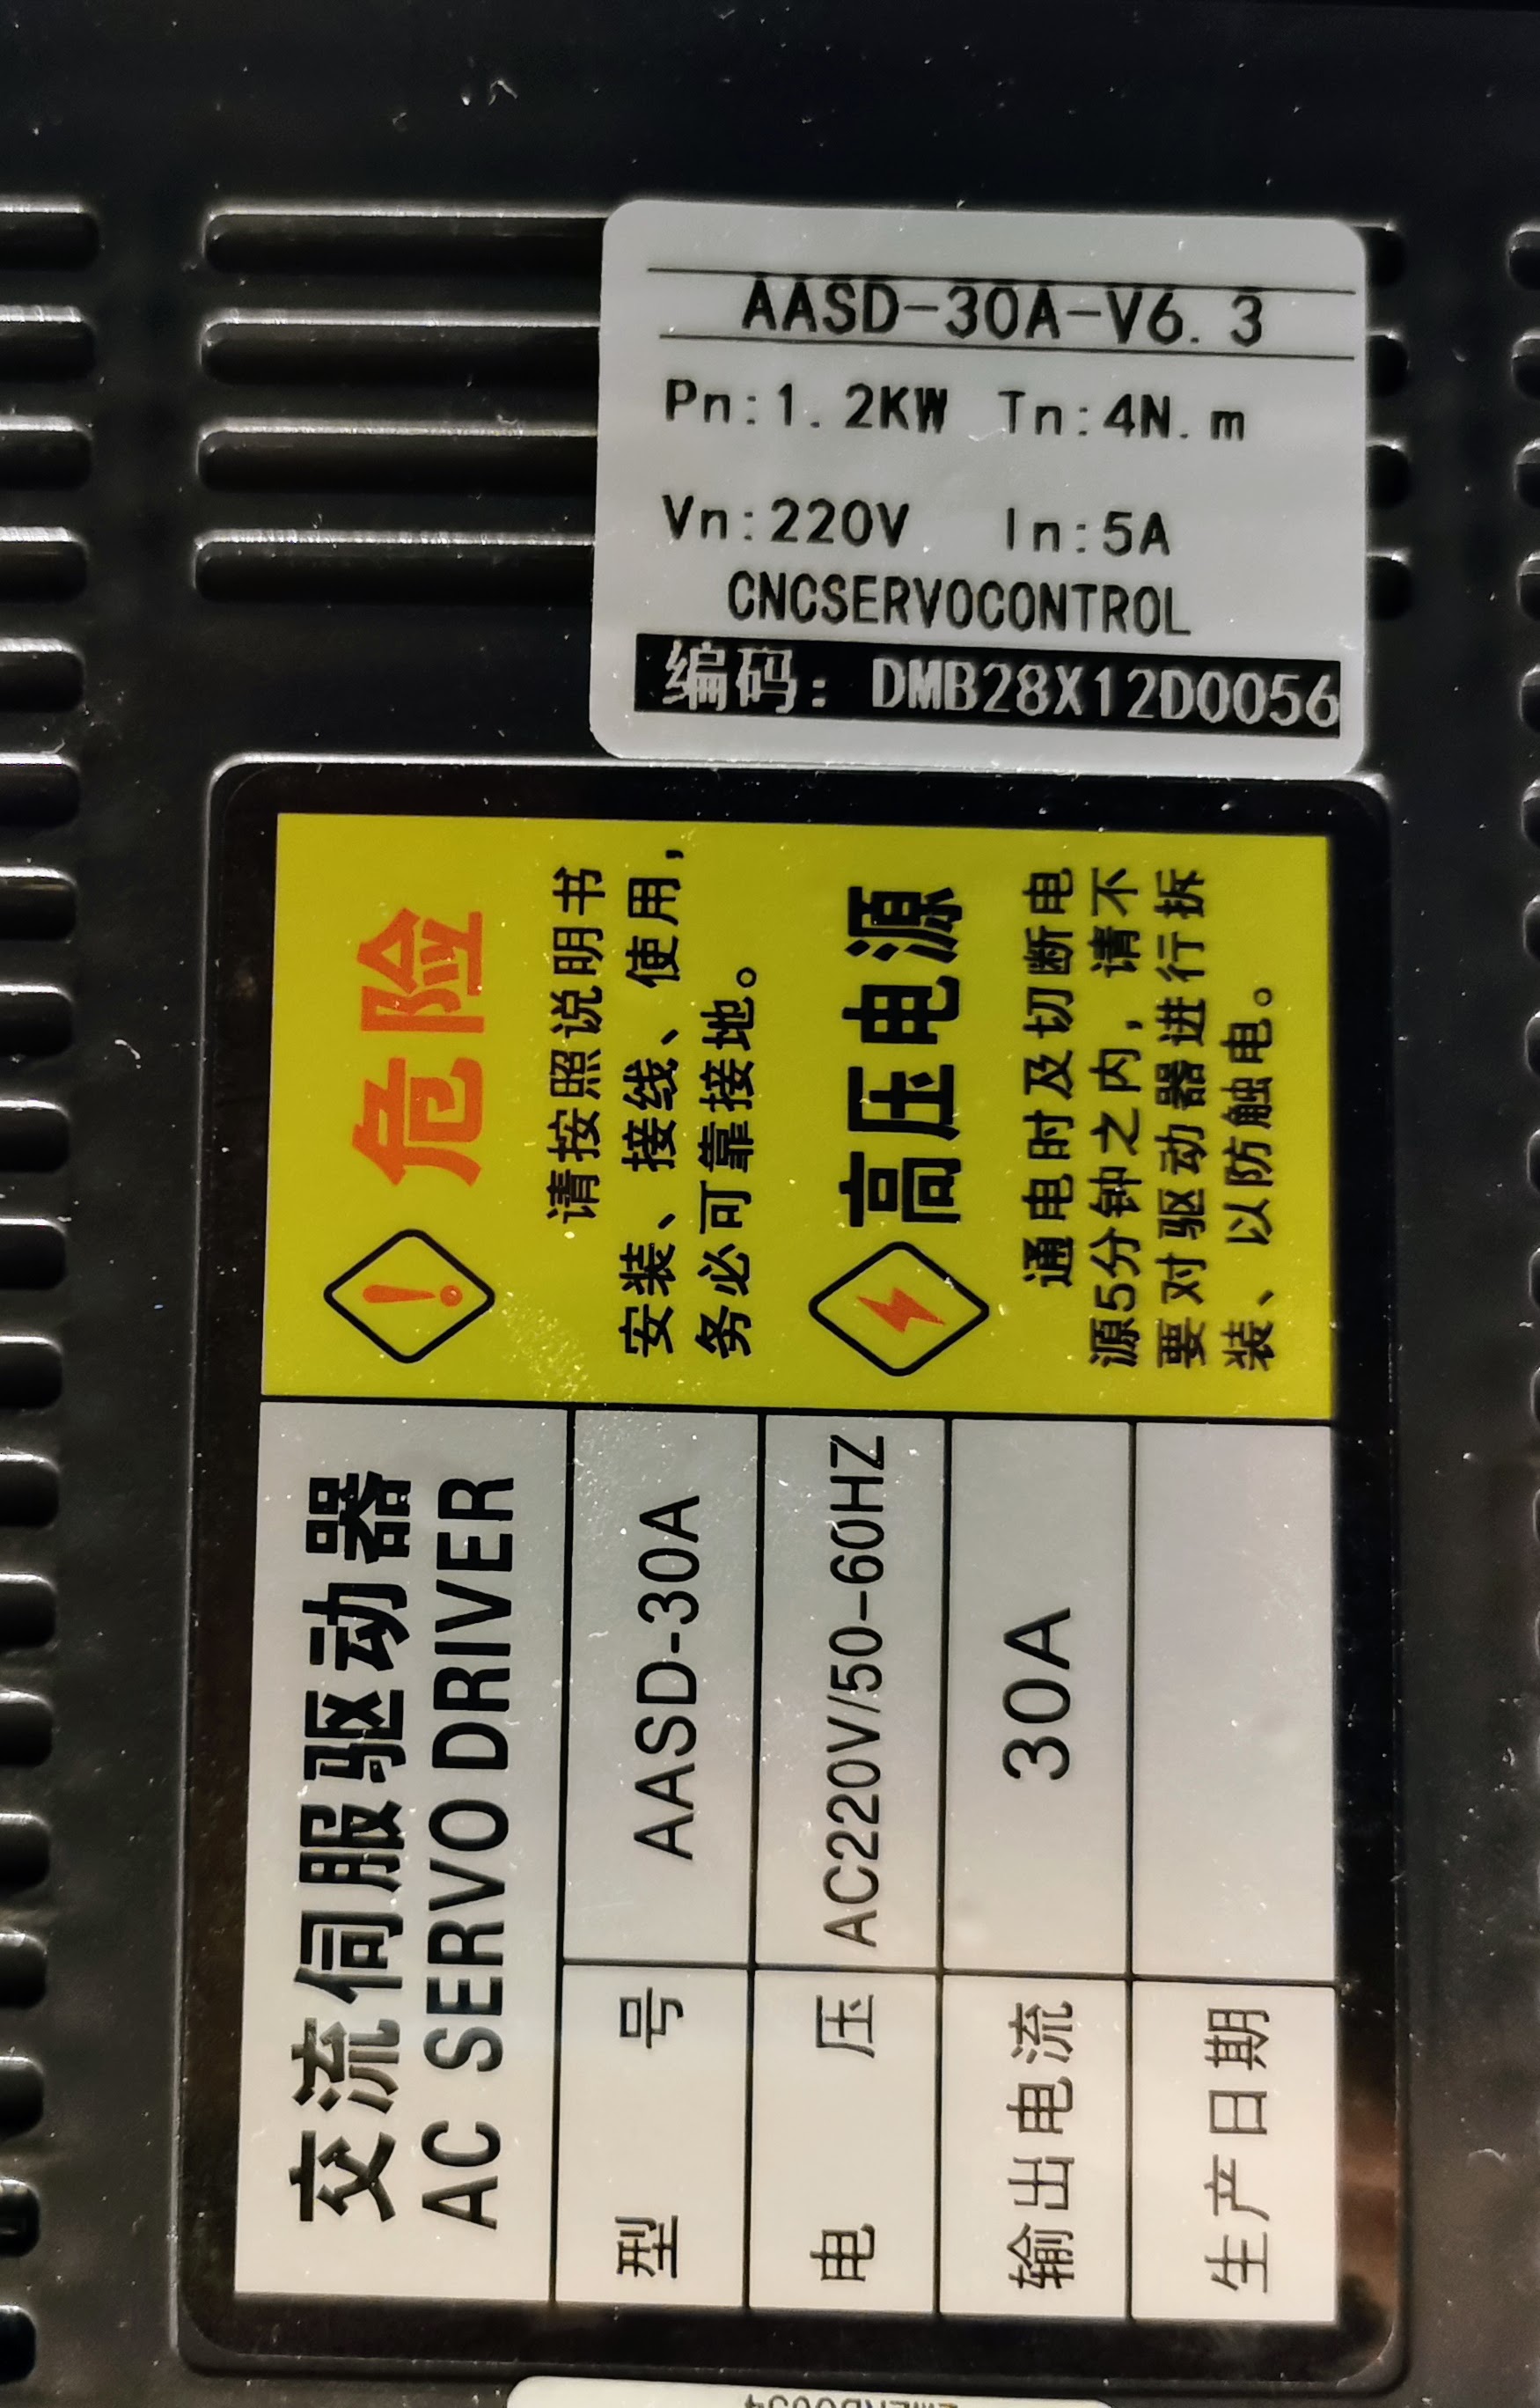
Yes, I utilized the LinuxCNC HAL oscilloscope and observed all the relevant signals: A, B, and Index. However, what's intriguing is that the motor speed appears to be inconsistent, even when using the jog function (Fn002). For instance, if I set the speed to 100 RPM, the displayed speed value fluctuates between 85 and 125 RPM. This is why the encoder pulses also vary in length.You have feedback the encoder the servo?
In this scenario, I am able to slightly rotate the motor shaft (more easily in a counterclockwise direction than clockwise), but I am unable to trigger the Al-04 error. During this process, the display value of Dn002 increases to between 70 and 80 and then stabilizes, regardless of the amount of force applied. Additionally, when observing the same Dn002 value during the motor's operation at 100 RPM, the value also rises to 74, but this is immediately followed by the Al-04 error code.Maybe the problem is in point 3?
What happens at 0 speed and applied axle force?
Please Log in or Create an account to join the conversation.
