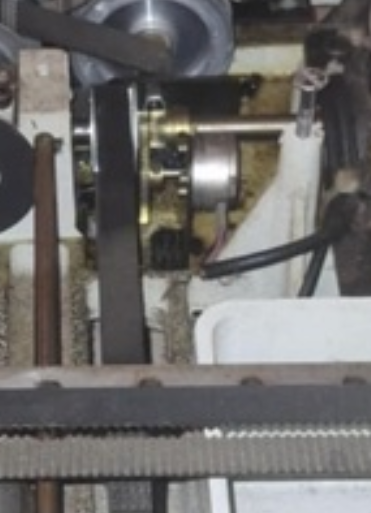
Toyota embroidery machine - retrofit

More
1 year 4 months ago #329669 by Aciera

Does the pot have hard stops?
How many turns does it take to hit those stops, if any?
How many degrees can it turn, if it does less than 1 turn?
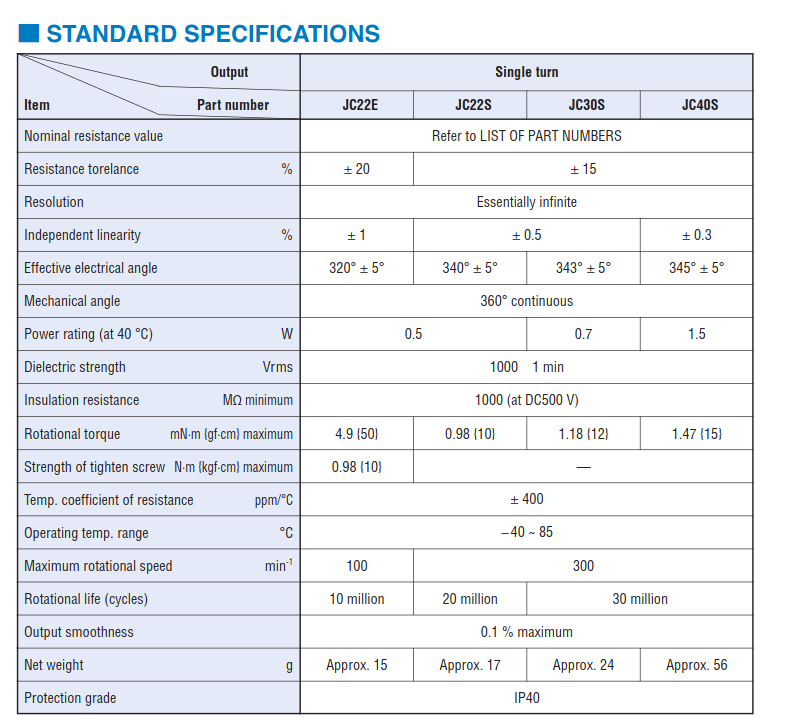


www.alldatasheet.com/datasheet-pdf/view/862058/COPAL/JC30S.html


Please Log in or Create an account to join the conversation.
More
1 year 4 months ago #329670 by Aciera

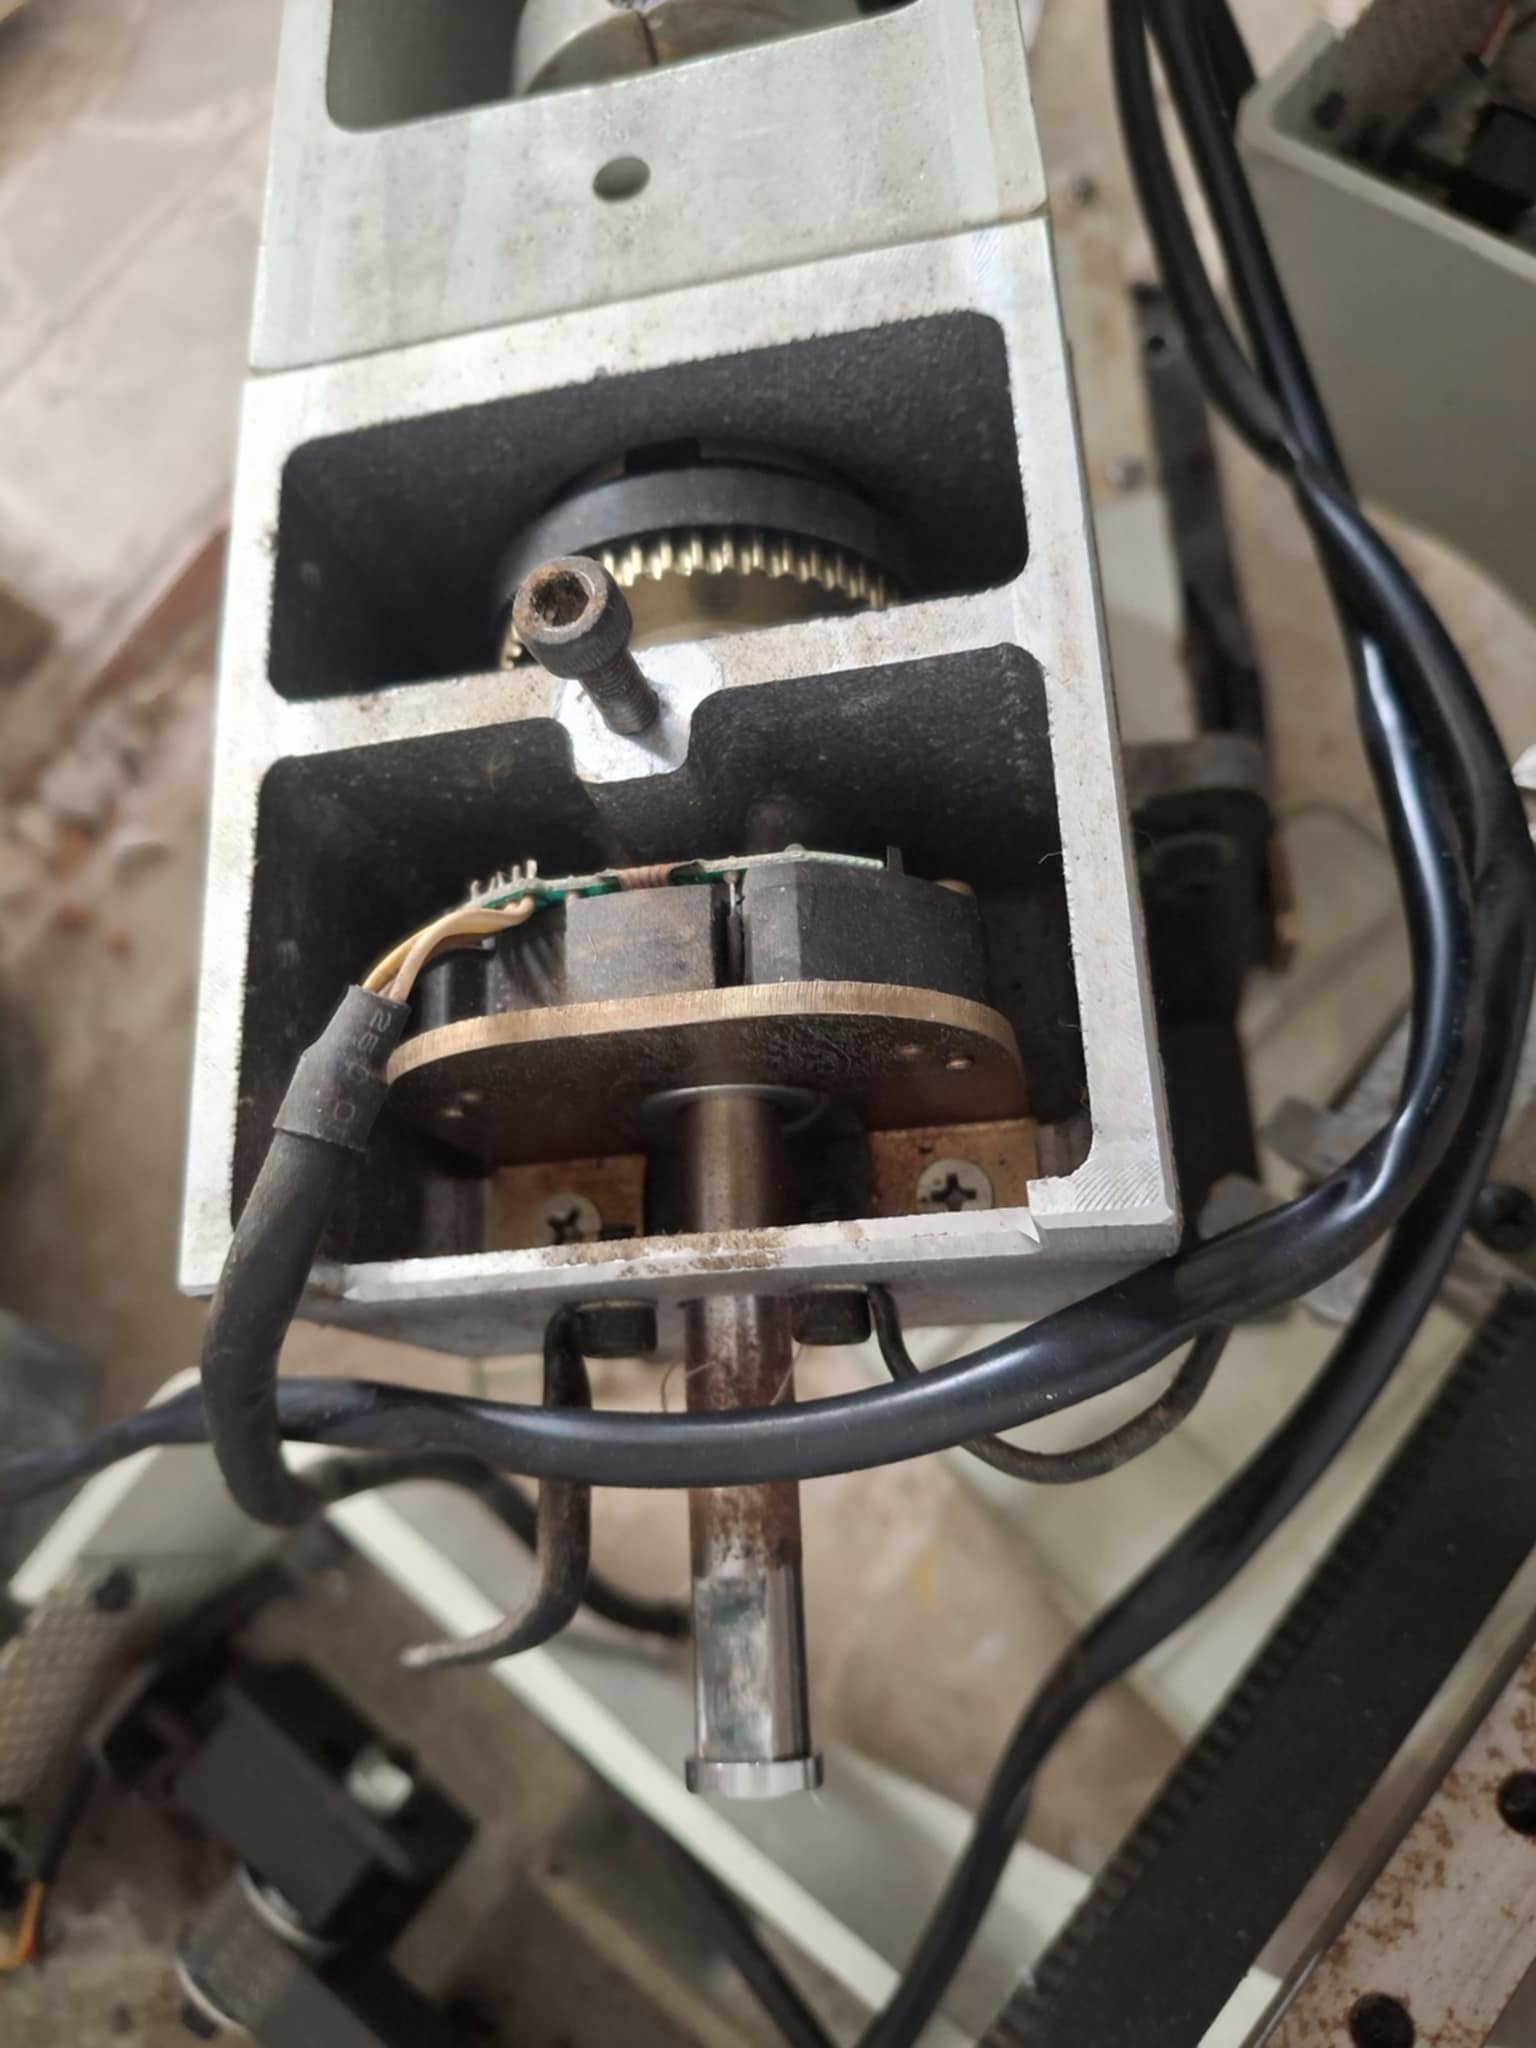
Is there another motion axis?


There is and it seems so be using the same potentiometer setup:


Please Log in or Create an account to join the conversation.

More
1 year 4 months ago #329679 by andypugh
I think that if you scale the potentiometer voltage to position, and latch it in HAL (you can do this with a mux component, with the output wired to the input, and triggered by machine-is-on) and add that to the scaled encoder position from the motor encoder, then you would have a "good enough" absolute encoder emulator.
Then configure HOME_ABSOLUTE_ENCODER in the INI

Please Log in or Create an account to join the conversation.

More
1 year 4 months ago #329680 by andypugh
You might want to set feed-hold when the needle is down, and release it when the needle is up...

Please Log in or Create an account to join the conversation.

More
1 year 4 months ago - 1 year 4 months ago #329705 by greg23_78
thank you for your feedback.

indeed,

- it's a 0-5K ohm single turn potentiometer.
- on the 2 X and Y axes there are
- there is no limit switch.
-Since it's a single turn, I assume (not tried) that 1 turn = the distance the axis moves.

Thanks for the procedure, I was going to ask if it was possible to homing with a potentiometer.

Which reasoning do you think is best?

     - when homing, the motor runs until the potentionemetre is read at 1 ohm, then it looks for the incremental encoder index?

     - No homing, the encoder reads the potentiometer value directly?


I have a question about the needle motor control.

I have this electronic component, I suppose it's an encoder because of the markings next to the wires. A (Phase A) Z(Pulse) G(Ground) V(VCC) B ( Phase B )
Can you confirm this?


If yes, I suppose that I control the speed of the motor for embroidery and the position for changing the head (I have 5 heads).

However, I don't have a reference for this one. What test would allow me to know the number of pulses for this encoder?
Last edit: 1 year 4 months ago by greg23_78.

Please Log in or Create an account to join the conversation.

More
1 year 4 months ago #329723 by juliankoenig87
For homing I would meassure how much the resistor value changes for one motor revolution. After that one can think of solutions. That said. It would be a good step to identify the ratios of the axis.

For the needle encoder. Plug it to a mesa card (first test with bench power supply and oscilloscope) and turn 10 revolutions....

Please Log in or Create an account to join the conversation.

Time to create page: 0.062 seconds
Powered by Kunena Forum