hi everyone
during project im struck with some problems.
I tell what i done ,write my experience. im new to linux cnc.
I'm retrofit cnc milling maching with linux cnc it has analog servo drive module with Z 18 NM , X 5.6 NM ,Y 5.6 NM servo motors (teco feed back get in to drive and motor has incrimantal encoder connect to controller)
i using 5i25+7i77 mesa cards.
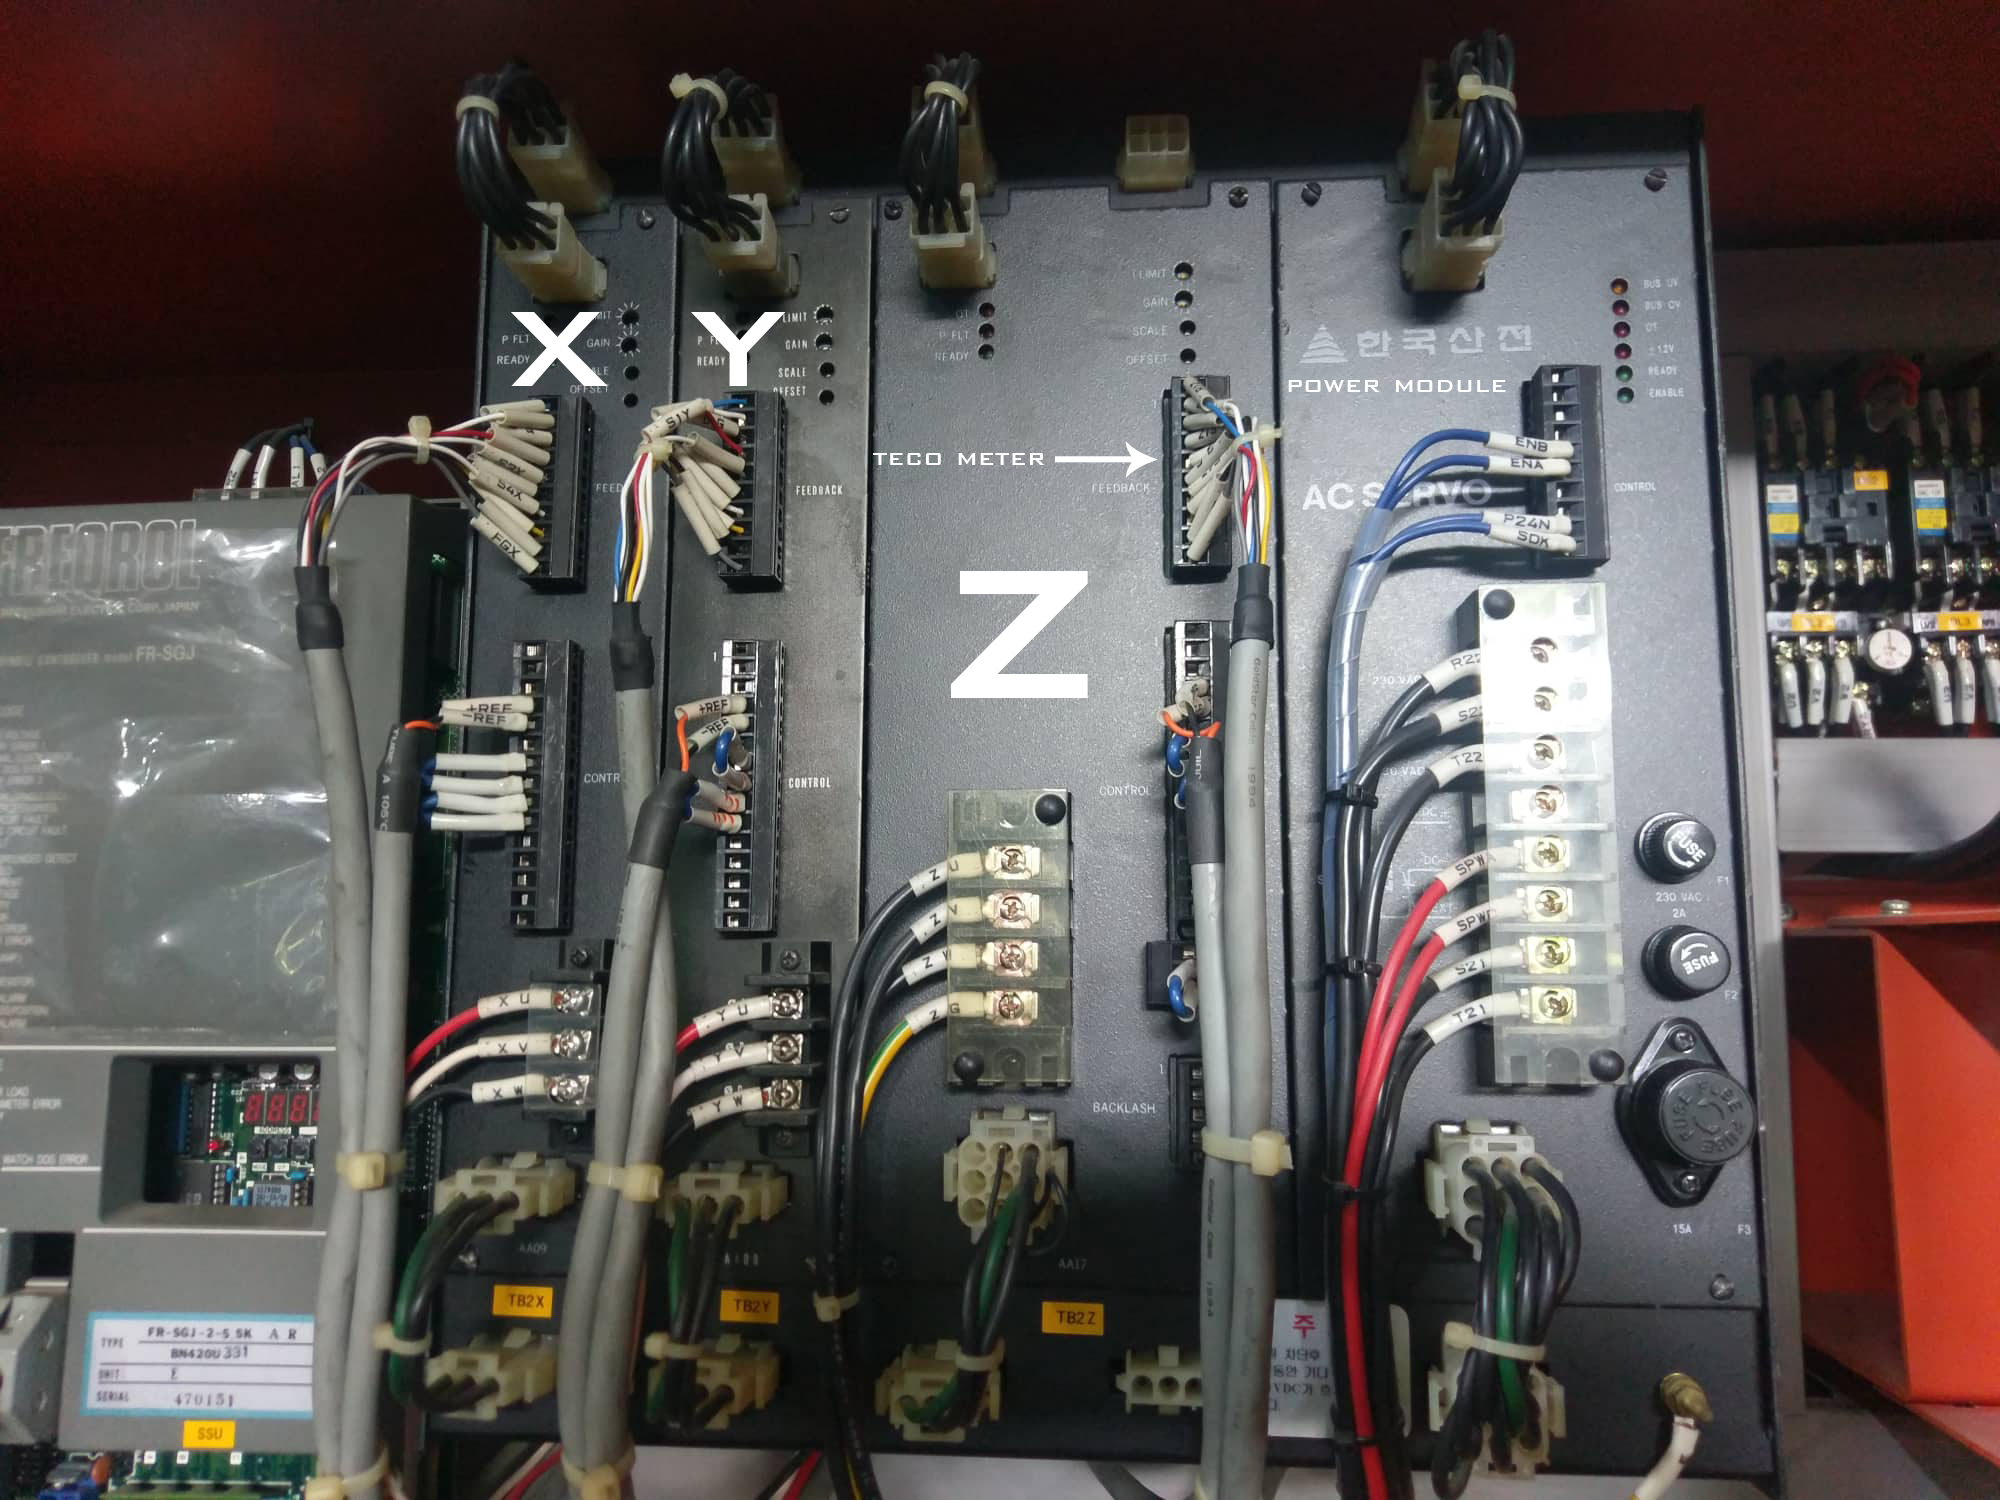
this is drive module
in this module x drive card dead and we repair it replase igbt and some control circuit components
I Earth the machine properly with separate Earth rod wit 7 ft.
I wire drive module power cut off by series limit switch and emergency.
and remove motor from load.
wire the encoder, and make encoder calibrate with linux cnc system(encoder ppr 2500 / ball screw pitch 10 mm and direct couple to motor
first i tune motors from drive side remove the analog out and ground connector from drive and enable drive module with linux cnc
motor are rotate slowly.
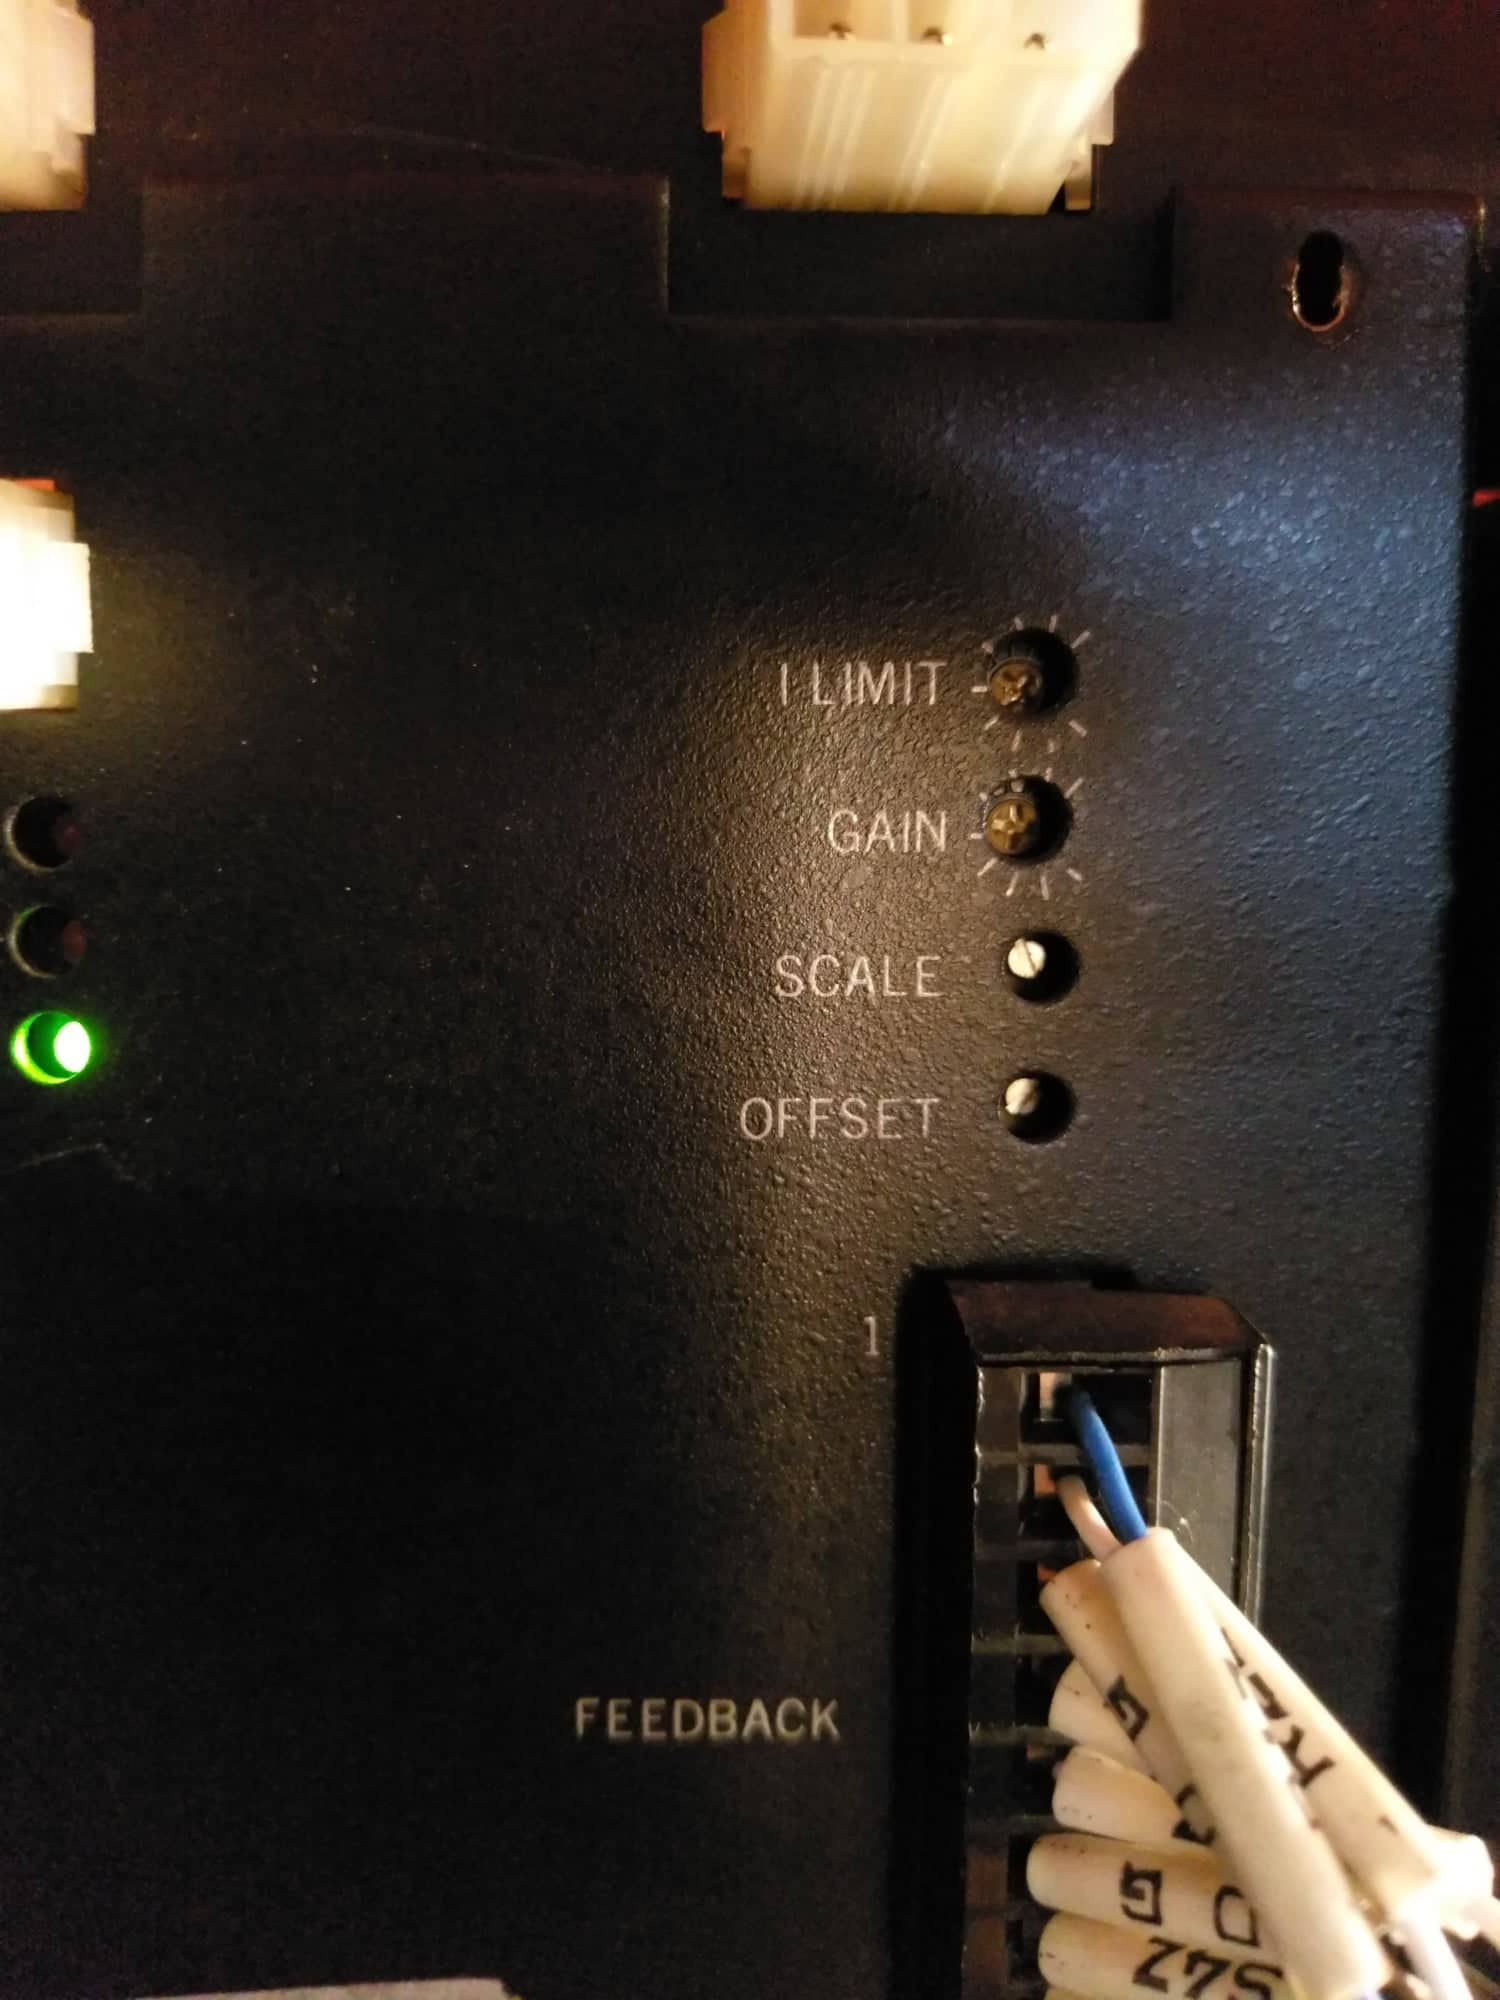
drive has scale and offset (variable resistors) rotate them and make motor to stop.stable
I put pid Value P=0 / I=0 / D=0 /FF1 = 0.01 / ff2 = 0 in all axis
connect analog out and ground connector to drive, and power up and enable drive module with linux cnc
but motor are running again I try to again rotate scale and offset (variable resistors) to stop rotate the motors Y is stop and other motor are not stop I rotate to max position to scale and offset (variable resistors) they are rotate very slow.
I remove analog out and ground connector to drive again make motor to stop at drive enable.
connect analog out and ground connector to drive, and power up and enable drive module with linux cnc motors rotate again I put PID value in P=1 ta all axis. then motor stop rotate and hold but motors are oscillating . I decrease P value but nothing happen
I put Pgain to X P=5 / Y P=7 / Z P=1.1 this are ok. higher than these value motor are highly vibrate and trying to jump not stable
I disable drive and enable drive it motors move little bit and hold and oscillating (it like steady state error)
I zero the machine (home limit are not wire to system) it not come to 0.000 position X in 0.012 Y in 0.008 Z 0.058
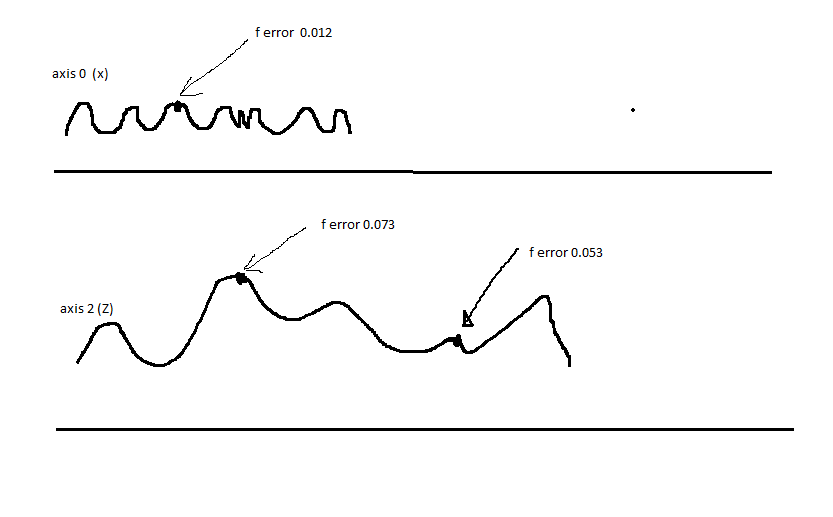
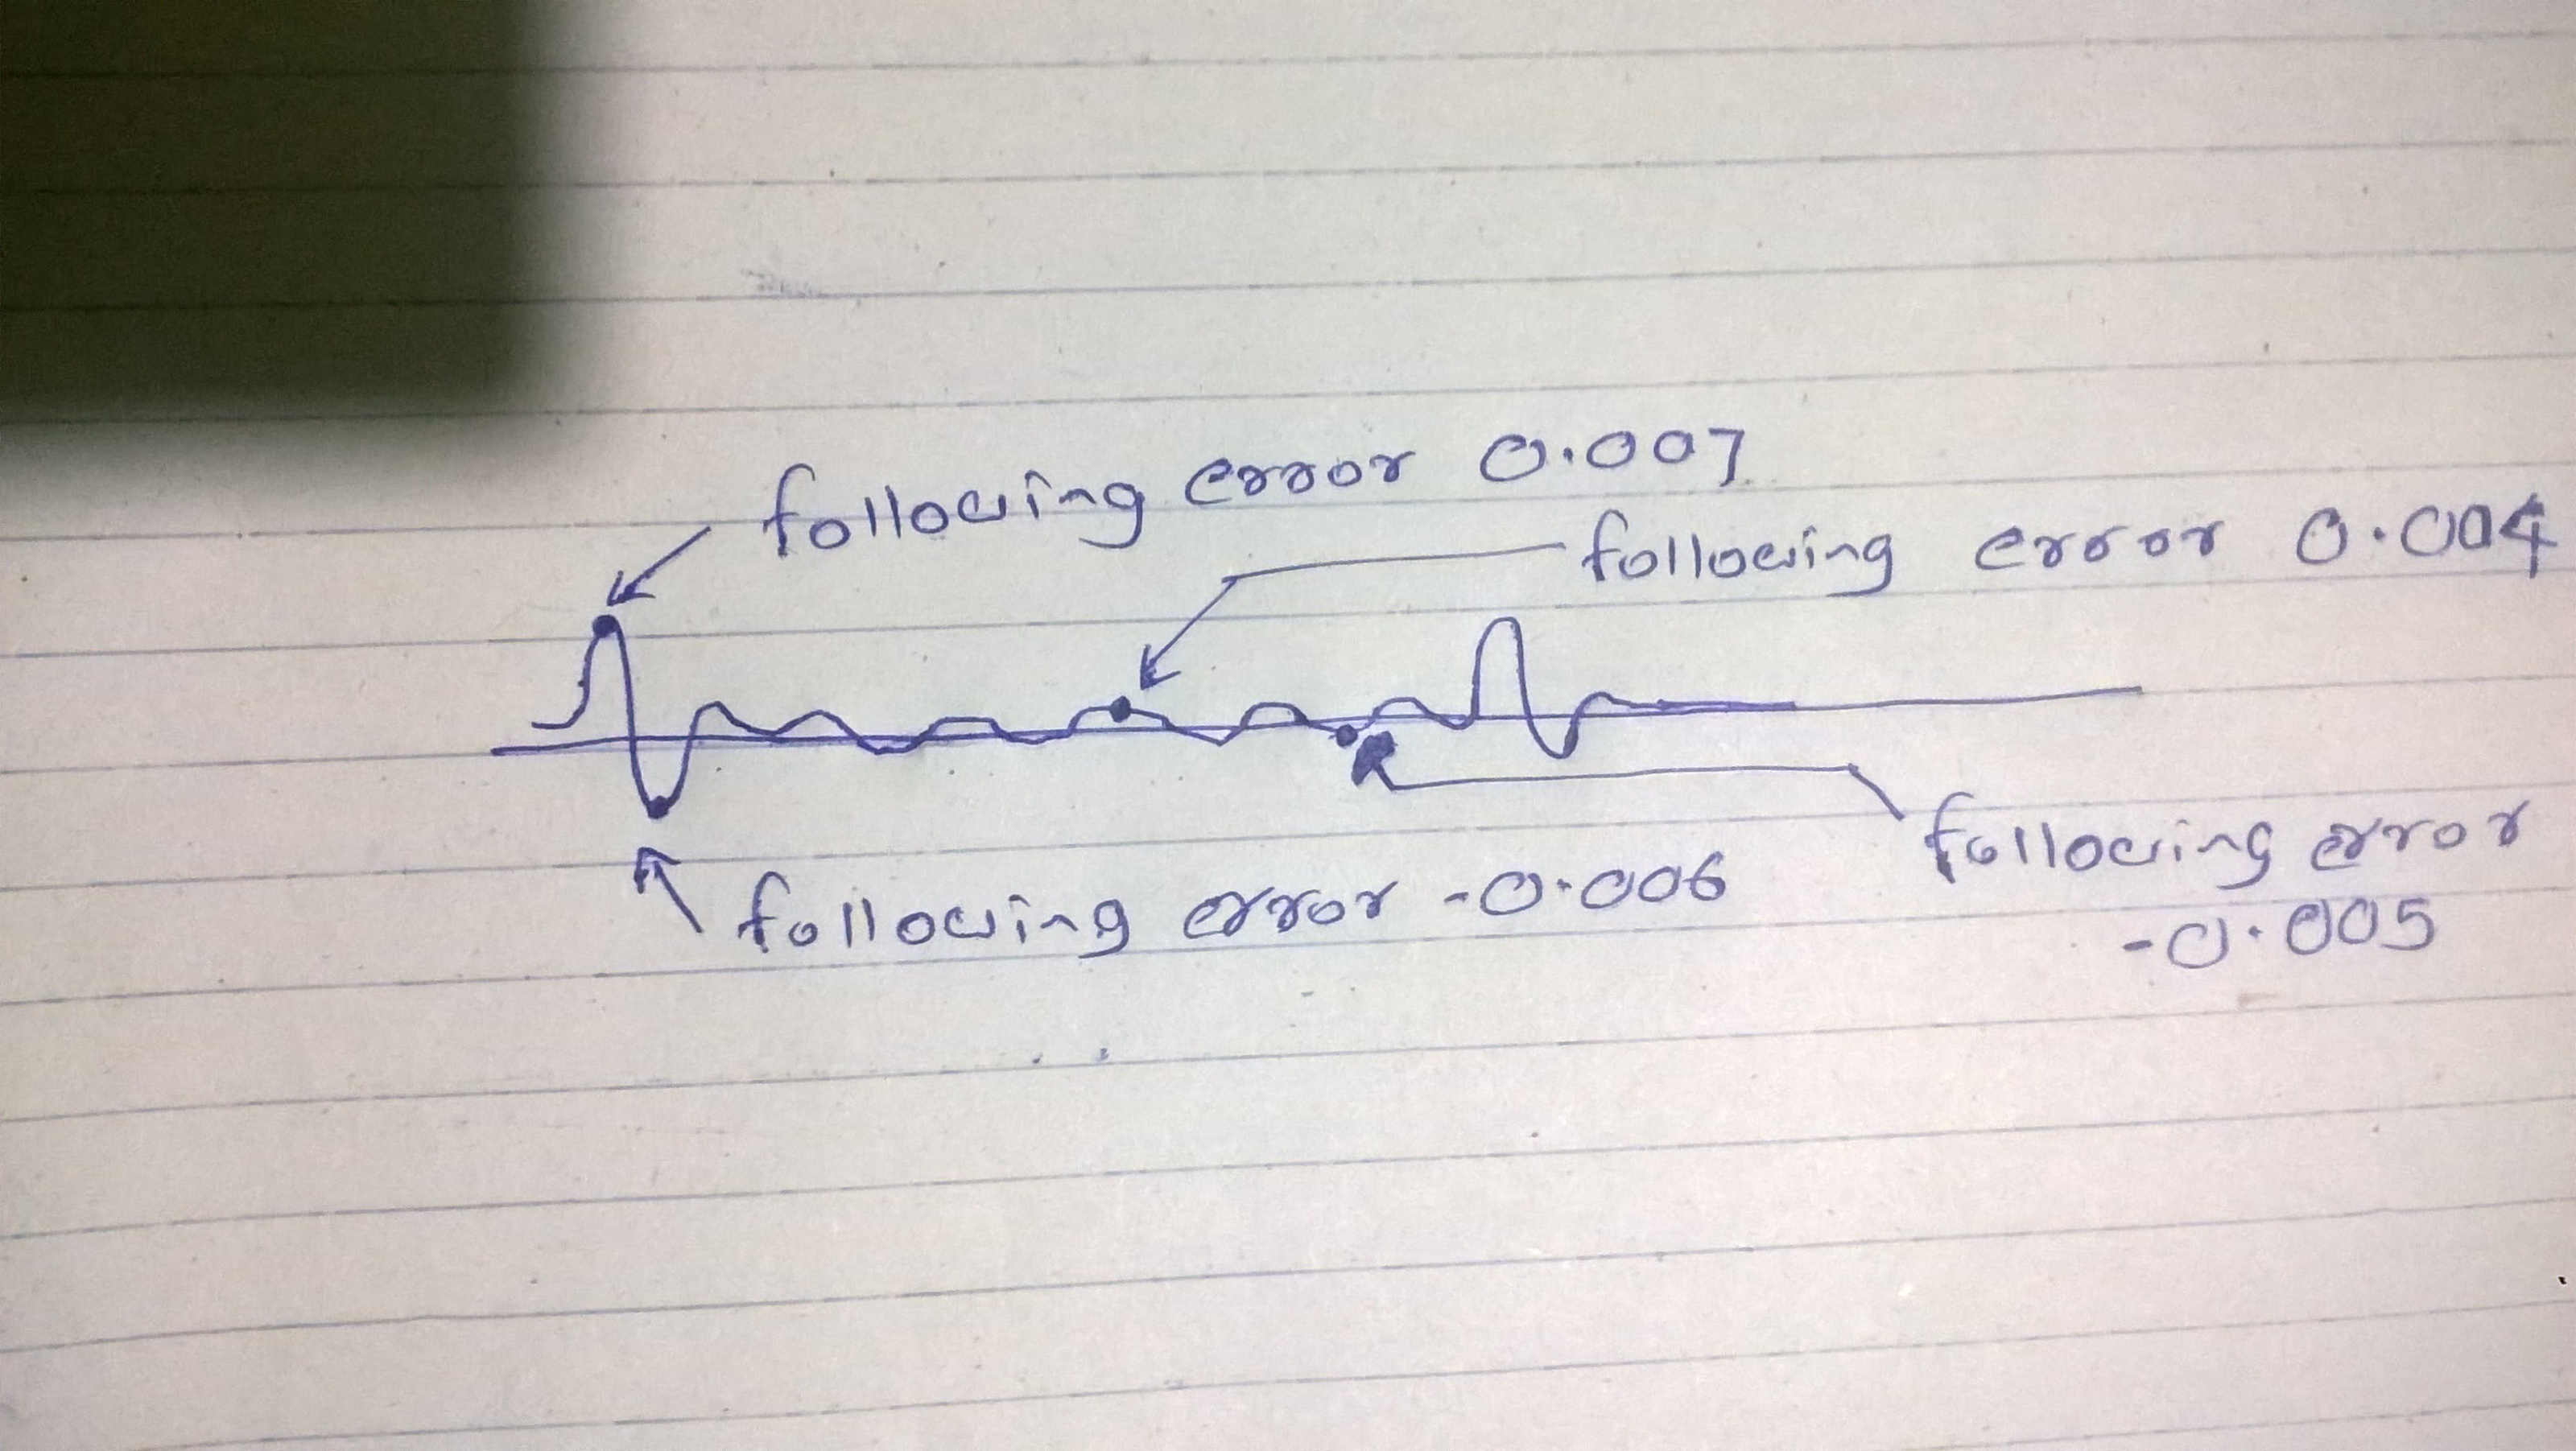
in hall scope show that like that
I move the X motor he not goes right position
EG ; i give comand in MDI X 20.000 motor goes to 20.015 and oscillating i give comand in MDI X 0.000 motor goes to 0.014
and oscillating
Tuning with I value put I=1 I zero the machine it with 0.014 and after few seond it came near to 0.000 but not in to 0.000 oscillating between -0.007 to 0.006
I move to motor to 20.000 it goes to 20.012 and try to come to 20.000 position. but oscillating between 19.993 to 20.006
Y is same like this Z error greater than X and Y
i try make this position from D but it is not work.
AND I TRY another way Put I=0 and D=0 P is same value. I tell motor to move 0.000 , it goes 0.013 I zero machine it value in 0.013
rotate offset (variable resistor) in each driver zero position came near 0.000 but oscillating is same .now it oscillate between -0.003 t0 0.004
we move motor to 20.000 it goes 20 .000 but oscillate between 19.993 to 20.004
hall scope chart show
Z is oscillating largely it position error cant get in near 0.000 by drive
I try lot but oscillating in same
3)And i try another way
remove X drive card and Z drive card from drive module and drive Module on with Y drive enable the drive Y Motor hold without
oscillation I ZERO the machine motor come 0.000 and move without position error
I connect the Z drive card on Drive module with Y and Z then problem came again Z and Y oscillating again
Z torque is very low
I power up drive module X drive card X little bit oscillate 0.001 to 0.000 some time goes -0.001
I on drive module with X and Z ,, Z and X oscillating again
Z torque is very low
I CANT THINK WHY THIS HAPPEN (in old system Y and Z work ok )
***I remove x and y drive card from drive module and power up with Z drive card then Z motor is stop oscillating and motor stable
Z torque is good now,
In MDI mode i run Z (g1 f 400 z-100) position is ok ,, motor moving with following error ( 0.018) use FF1 and FF2 low the followin
to 0..004
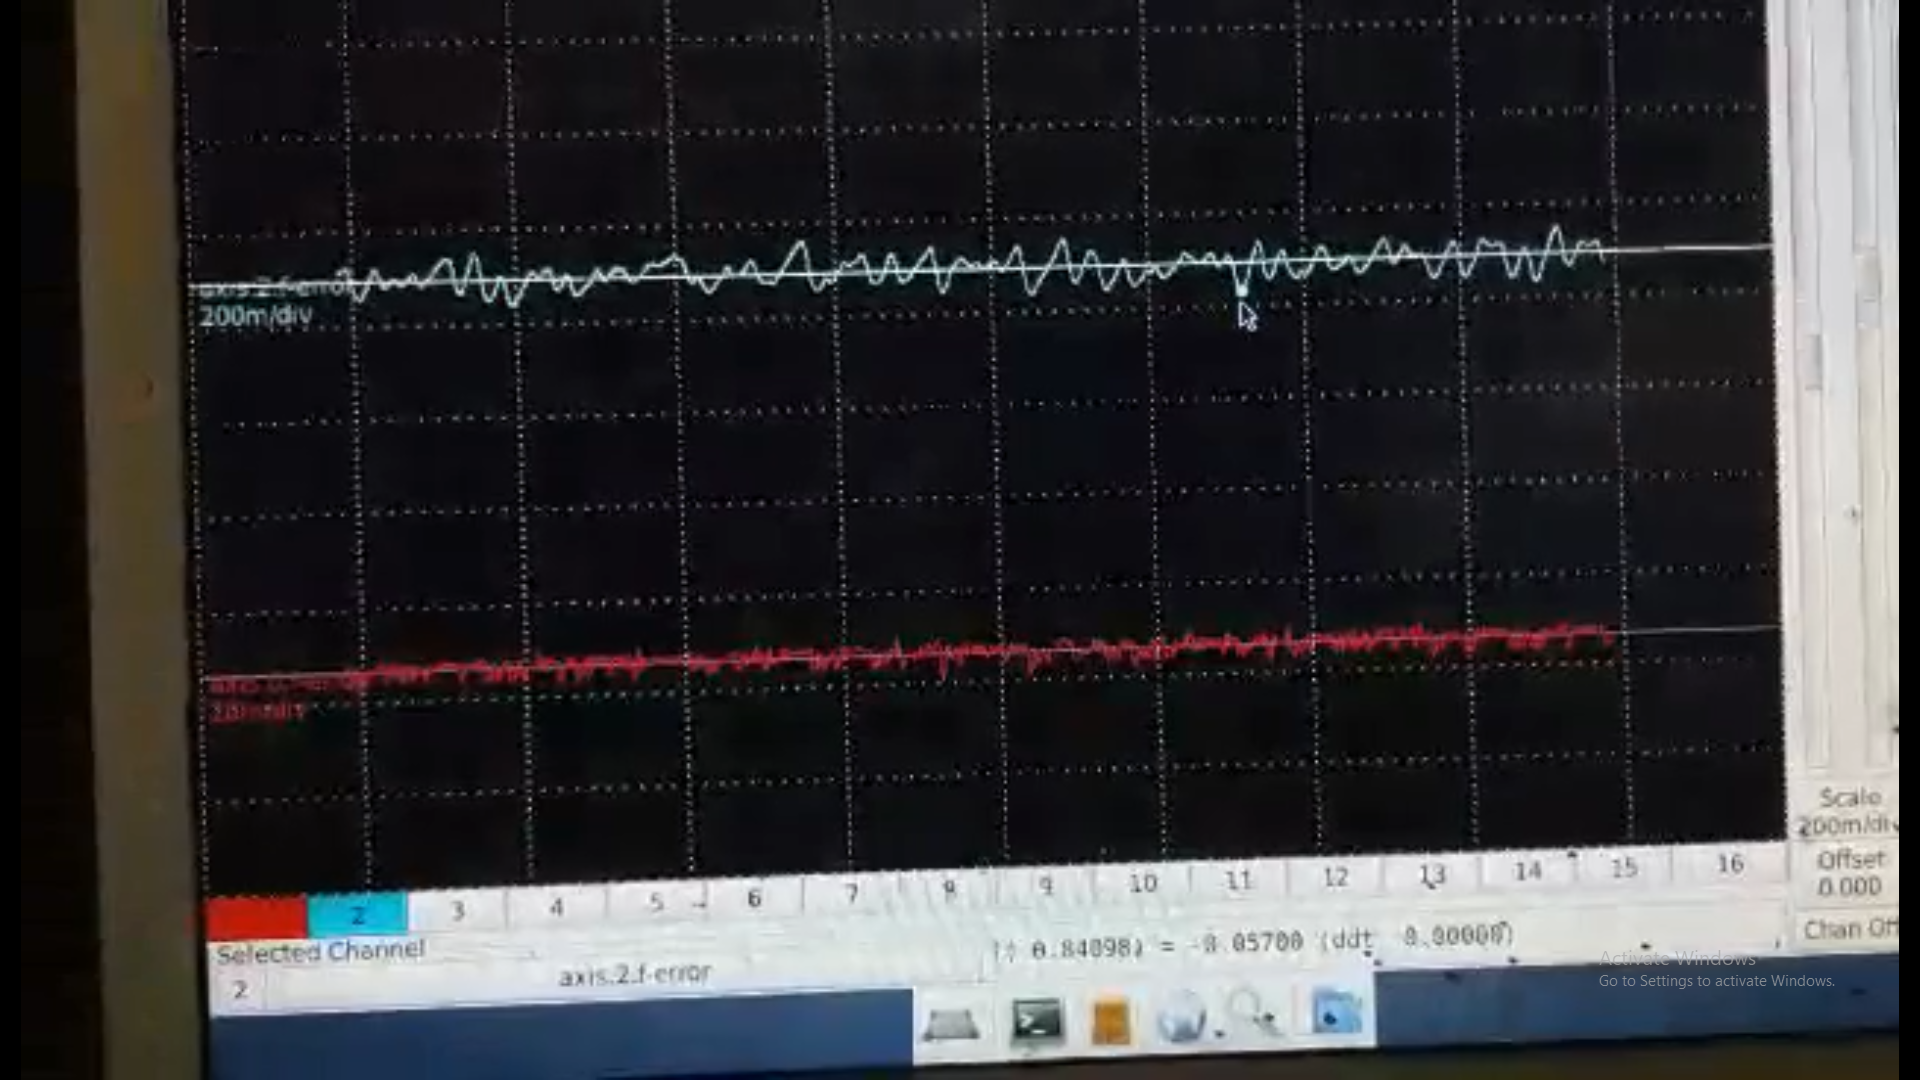
hall scope show like that
I connect motor to load power up and enable drive it hold Z axis without oscillate move very smooth position is ok I ZERO the machine axis in 0.000 position I move axis to 100.000 axis move to 100.000 I check movement in using dial gauge it ok with position
I again connect Y drive card enable drive Z fall -0.078 position error is also come and oscillating again 0.000 to 0.002 value
I remove Y motor power cables and enable drive module , then Z is working with out position error
I cant think what happen
@@ I have new 2 servo drive with motors im planing to run them in puls and direction
i have another 5i25 mesa card and write (5i25_prob_rfx2.bit) firmware to that card
and i connect 2 mesa card to pc mesa 0 with 5i25+7i77
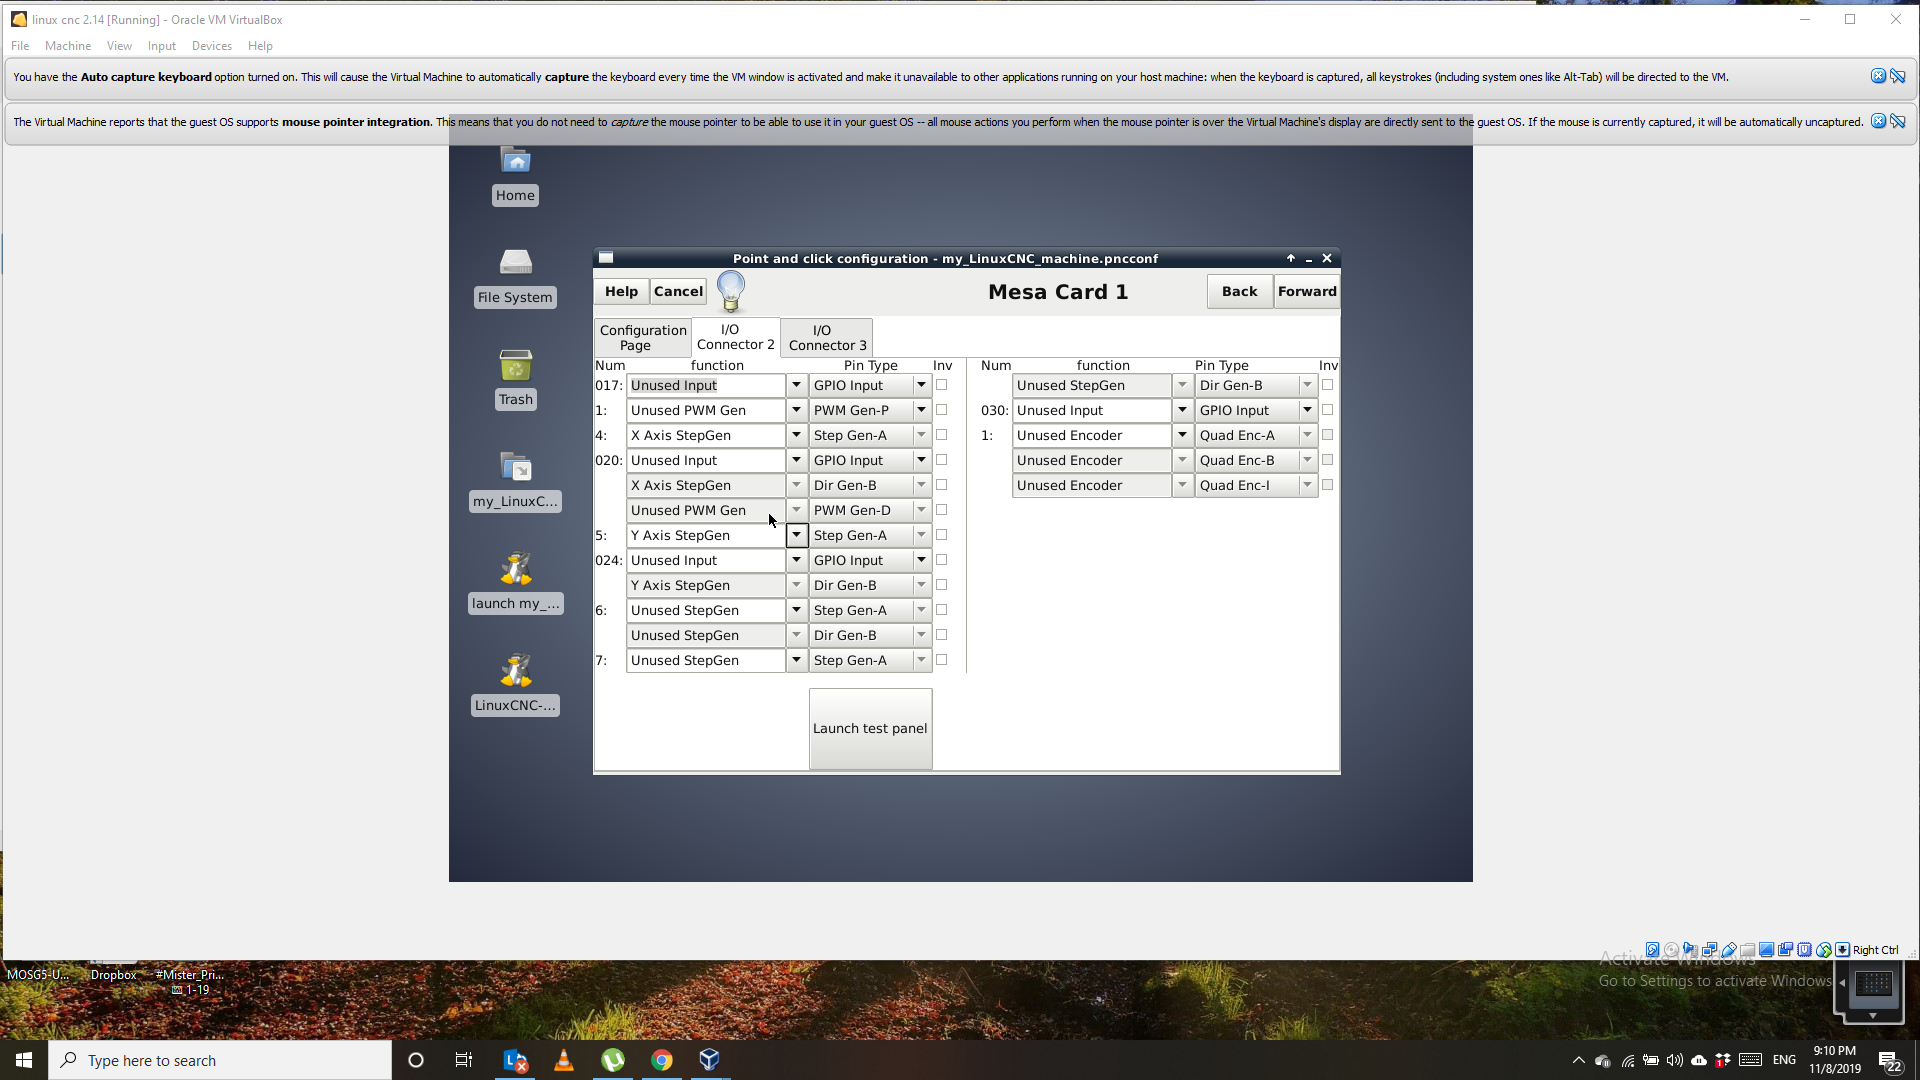
mesa 1 step direction
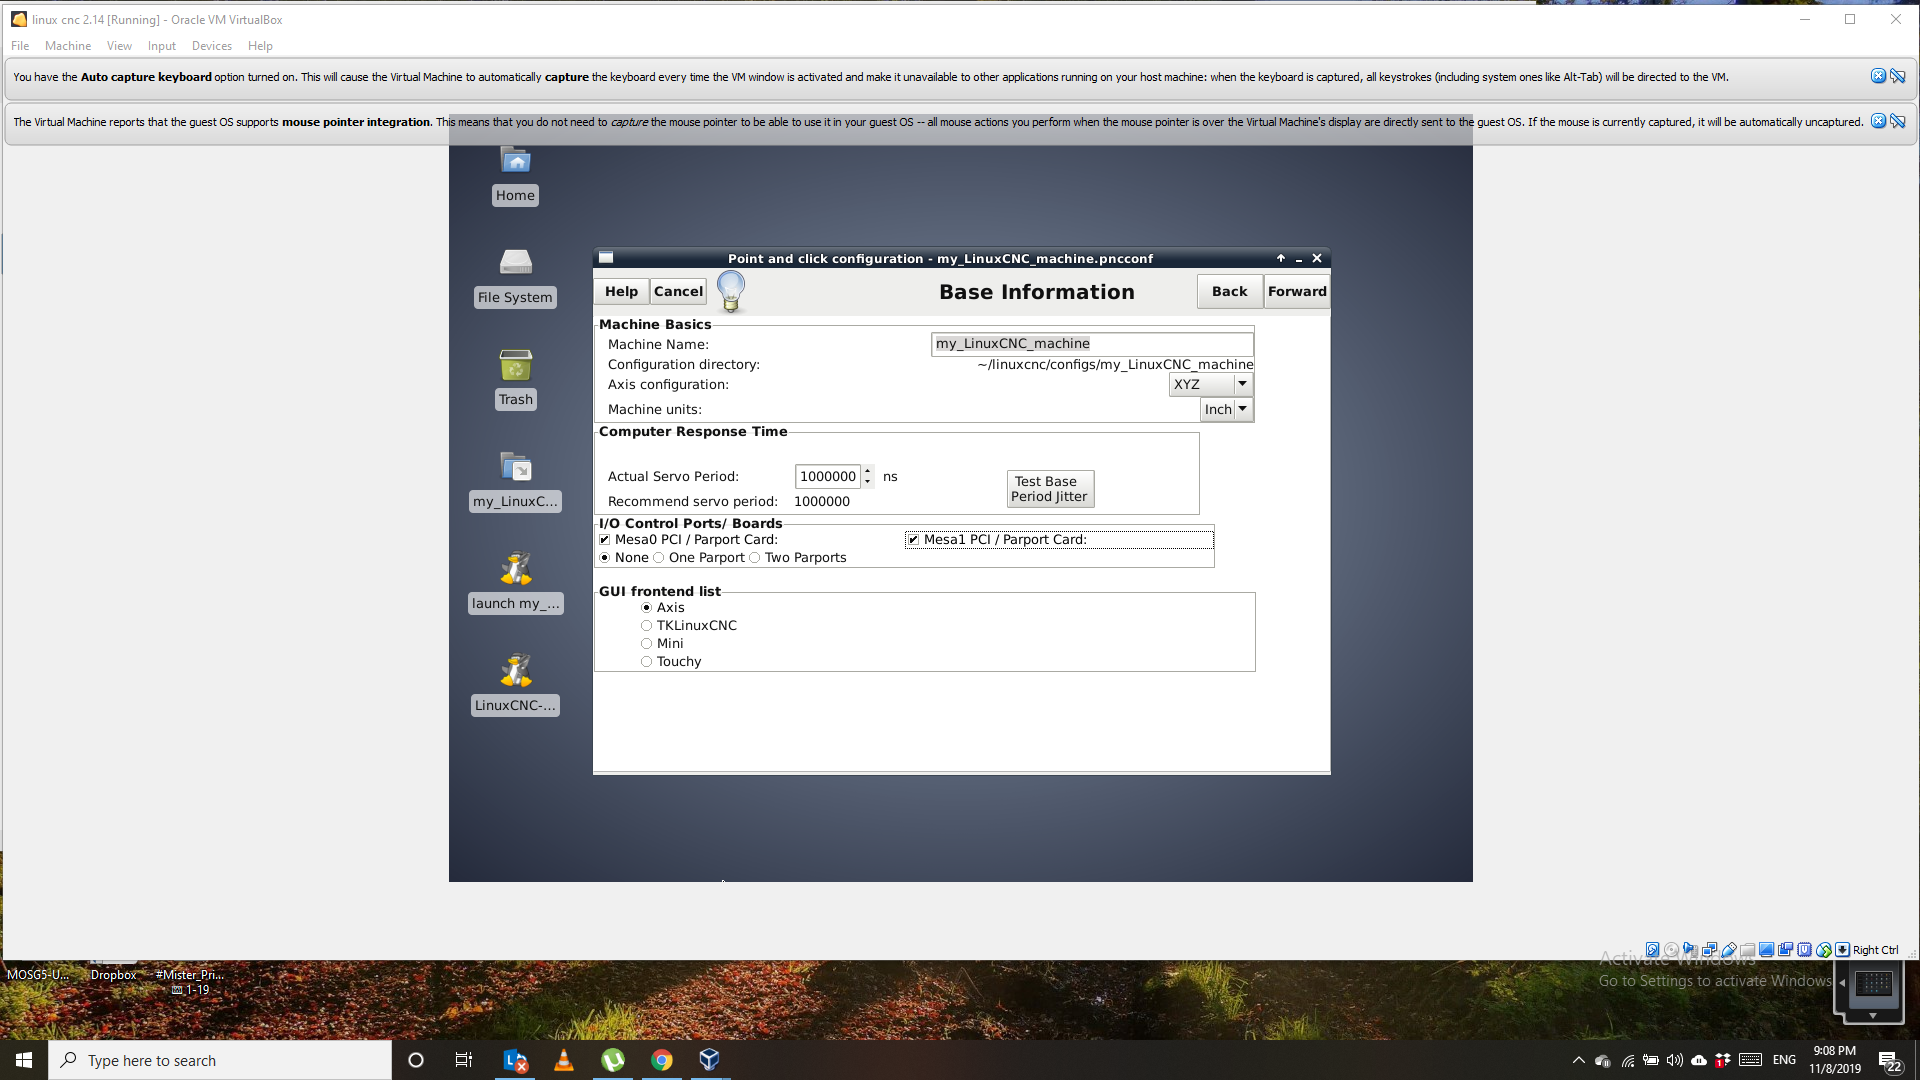
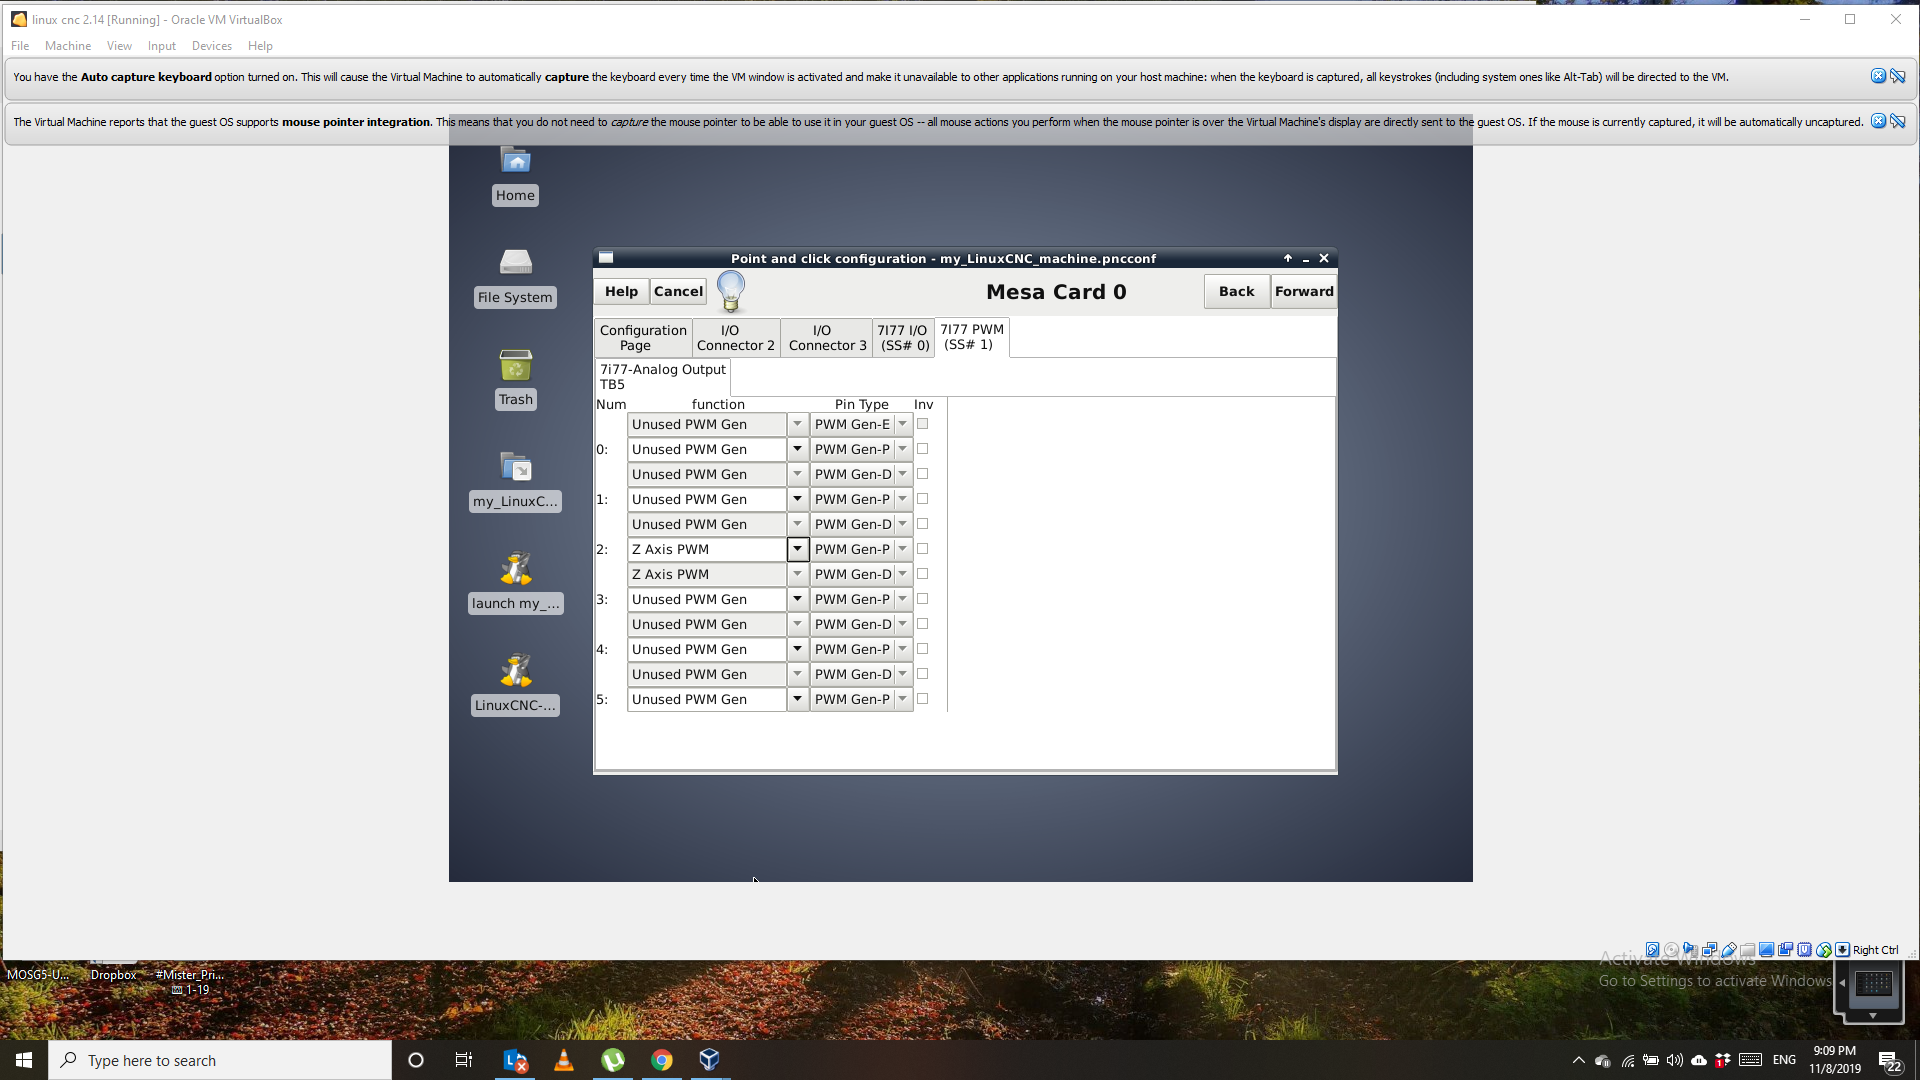
i configure pncconf wizard with like that
open this cnc file, i enable the machine with linux cnc my Z analog servo motor moving slowly.
i make another configure pncconf wizard for 1 mesa card (5i25=7i77) and enable machine from linux cnc Z analog servo is ok
motor is not moving.
then i open 2 mesa card cnc file and enable machine z moving slowly I Change P value of Z ,, put P=2 / P=10 / P=20
P=50 P=100 for p gain and nothing change.
are we cant use 2 mesa card to 1 pc
or power issue of pc
or other reason
i cant think what to do im struck in hear