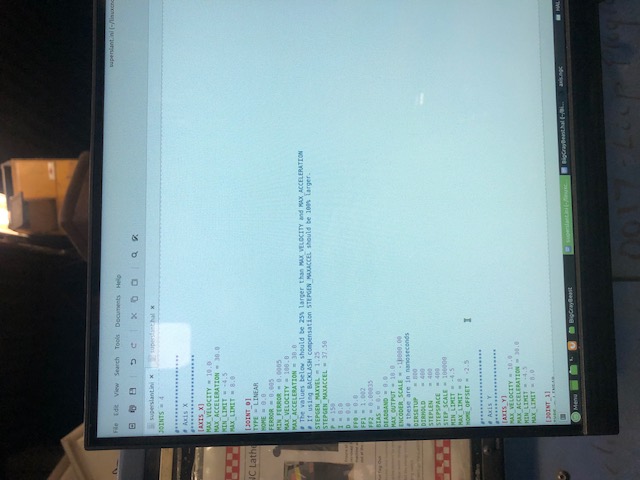
Hi Guys.
I'm trying to figure out my motor tuning for steps per inch. I'm guessing I need to use electronic gear ratio in my servo drive to be able to handle the amount of pulses per inch. Right now if I set an encoder count of (and i'm just playing right now to speed it up) 2500, and a step count of 500000 and I tell it to move .100 it only moves approx. .002 with different variations I can only get approx .011 per .100 request.
So what would be the best electronic ratio
As near as I can figure at this time my ball screws are 5 turns per inch or .200 per rev. (Hardenge SuperSlant, Maybe someone knows for sure the pitch)
it is belt driven from the survo 2 turns of the motor to one turn of the ball screw
The information I find for the motor and encoder says it has 2500 lines per rev.
So I'm thinking 2500x 5(ballscrew)= 12,500 x 2(gearing)= 25000 and this is nothing for a computer to handle but if i work on this figure the axis doesn't move enough to read on a dial indicator.
I am obviously missing something big because of the amount of pulses I actualy have to put out to get any readable movement per .1 request.
In case you might think it helps. My survo's and drives are chinese the drives are lichuan A6 drives Below copied from manual. I only wanted one line but it would only let me copy from top of page to that line.
A6 Servo Drive User Manual
2
Chapter 2 Electrical Specifications
2.1 Specification
Input power
CONTROL
POWER Single phase 220 VAC
MAIN POWER
SUPPLY Single Phase/Three Phase 220VAC
Working
environment
Temperature 0~45℃
Humidity No condensation ≤90% RH or less
Elevation Altitude ≤1000M
Installation
environment Non-corrosive gases, flammable gases, oil mist or dust, etc.
Installation
method VERTICAL INSTALLATION
Encoder feedback 2500 p/r (resolution: 10000), incremental encode