Hi,
I have a 4-axis MPCNC with a rotary B axis mounted at the far end of the Y travel (machine Y=700mm). The rotary axis is fixed — it does not move along Y.
G-code is generated by CAM with program zero at the chuck face, all moves go in Y-.
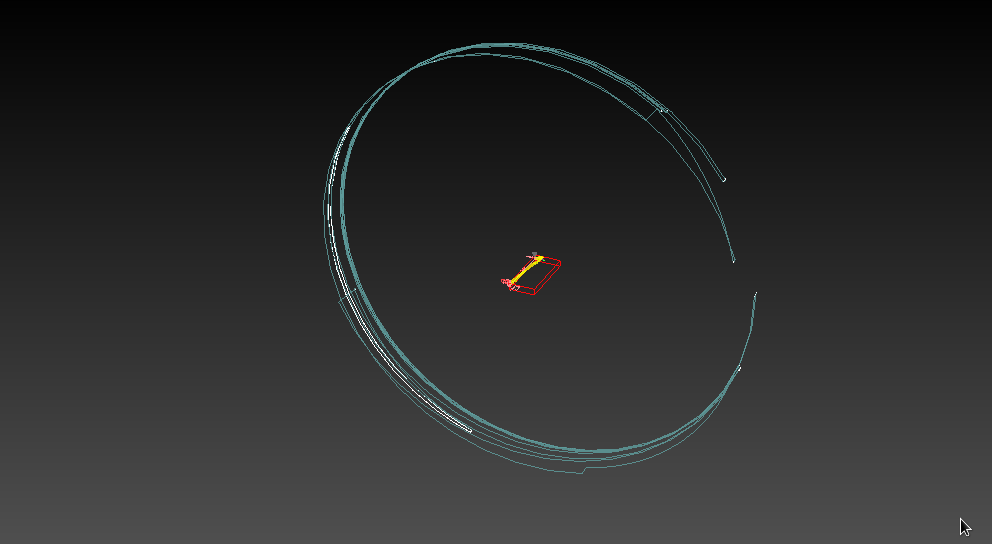
The problem: the backplotter does not display the toolpath correctly. Instead of showing the wrapped toolpath around the tube near the chuck, it draws a large circle. I believe this happens because the backplotter uses machine zero as the centre of rotation rather than the actual chuck position.
Setup:
- LinuxCNC 2.9.8 stable
- trivkins coordinates=XXYYZB, 6 joints
- qtdragon_hd interface
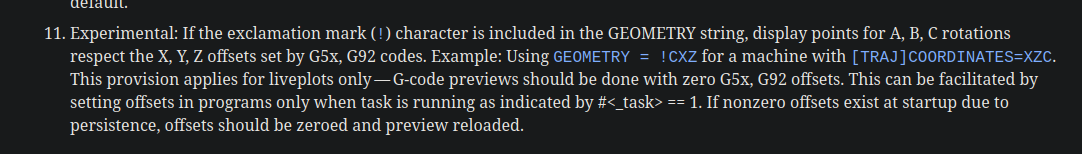
- GEOMETRY = !-BXYZ
Is there any way to tell the backplotter where the centre of rotation is?
Code:
[DISPLAY]
DISPLAY = qtvcp qtdragon_hd
# qtdragon saves most preference to this file
PREFERENCE_FILE_PATH = WORKINGFOLDER/qtdragon.pref
POSITION_OFFSET = RELATIVE
POSITION_FEEDBACK = ACTUAL
MAX_FEED_OVERRIDE = 2.000000
MAX_SPINDLE_0_OVERRIDE = 1.5
MIN_SPINDLE_0_OVERRIDE = .5
DEFAULT_SPINDLE_0_SPEED = 12000
# spindle up/down increment in RPM
SPINDLE_INCREMENT = 200
# min max apindle speed manually allowed
MIN_SPINDLE_0_SPEED = 1000
MAX_SPINDLE_0_SPEED = 20000
# max spindle power in Watts
MAX_SPINDLE_POWER = 2000
#MAX_SPINDLE_OVERRIDE = 1.000000
#MIN_SPINDLE_OVERRIDE = 0.500000
INTRO_GRAPHIC = linuxcnc.gif
INTRO_TIME = 5
#PROGRAM_PREFIX = /home/user/linuxcnc/nc_files
PROGRAM_PREFIX = /home/user/cnc-programs
INCREMENTS = 5mm 1mm .5mm .1mm .01mm
ANGULAR_INCREMENTS = 1, 5, 10, 30, 45, 90, 180, 360
POSITION_FEEDBACK = ACTUAL
DEFAULT_LINEAR_VELOCITY = 40.000000
MAX_LINEAR_VELOCITY = 100.000000
MIN_LINEAR_VELOCITY = 0.500000
DEFAULT_ANGULAR_VELOCITY = 12.000000
MAX_ANGULAR_VELOCITY = 180.000000
MIN_ANGULAR_VELOCITY = 1.666667
EDITOR = gedit
GEOMETRY = !-BXYZ
CYCLE_TIME = 100