What Mesa card for that?

More
9 years 2 months ago #97912 by bkt
Replied by bkt on topic What Mesa card for that?
@Tood

(What in the world do you need 18 servos for? Sounds like a fun project. Remember Linuxcnc only supports up to 9 axis of motion. (Not sure what the real joint limit is in Master but the user interfaces stop at 9 there as well.)


just ask to mail list ... with some modification code is possible ... without not possible ... fortunately is for 16/18 axis robot so there are 2 option: rtethernet with exchange of data for cordinate 2 different kinematics on two different Lcnc Pc ... or increase Lcnc code with XX, YY, ZZ, aa, BB, CC etc etc ... I think I test solution 1 and 2 too.

If someone have some other ideas ... welcome.

regards
Giorgio

Please Log in or Create an account to join the conversation.

More
9 years 2 months ago - 9 years 2 months ago #98168 by andypugh
Replied by andypugh on topic What Mesa card for that?
I don't think you need extra G-code coordinates to drive more joints. And no matter how many joints there are the tool tip position and orientation is completely described by XYZABC.

So, I think that all is needed, in theory, is to increase EMCMOT_MAX_JOINTS
github.com/LinuxCNC/linuxcnc/blob/master...tion/emcmotcfg.h#L23

A bit of work is needed to make Axis display a radio button for all the axes, and currently the number of PIDs in HAL is limited to 16 (easy fix).

But other than that, things seem to work.
Code:
halcmd: show pin *motor-pos-cmd Component Pins: Owner Type Dir Value Name 19 float OUT 0.1009 joint.0.motor-pos-cmd ==> J0:pos-cmd 19 float OUT 0.1009 joint.1.motor-pos-cmd ==> J1:pos-cmd 19 float OUT 0 joint.10.motor-pos-cmd ==> J10:pos-cmd 19 float OUT 0 joint.11.motor-pos-cmd ==> J11:pos-cmd 19 float OUT 0.1009 joint.12.motor-pos-cmd ==> J12:pos-cmd 19 float OUT 0.1009 joint.13.motor-pos-cmd ==> J13:pos-cmd 19 float OUT 0.1009 joint.14.motor-pos-cmd ==> J14:pos-cmd 19 float OUT 0.1009 joint.15.motor-pos-cmd ==> J15:pos-cmd 19 float OUT 0.1009 joint.16.motor-pos-cmd ==> J16:pos-cmd 19 float OUT 0.1009 joint.17.motor-pos-cmd ==> J17:pos-cmd 19 float OUT 0.1009 joint.2.motor-pos-cmd ==> J2:pos-cmd 19 float OUT 0.1009 joint.3.motor-pos-cmd ==> J3:pos-cmd 19 float OUT 0.1009 joint.4.motor-pos-cmd ==> J4:pos-cmd 19 float OUT 0.1009 joint.5.motor-pos-cmd ==> J5:pos-cmd 19 float OUT 0 joint.6.motor-pos-cmd ==> J6:pos-cmd 19 float OUT 0 joint.7.motor-pos-cmd ==> J7:pos-cmd 19 float OUT 0 joint.8.motor-pos-cmd ==> J8:pos-cmd 19 float OUT 0 joint.9.motor-pos-cmd ==> J9:pos-cmd
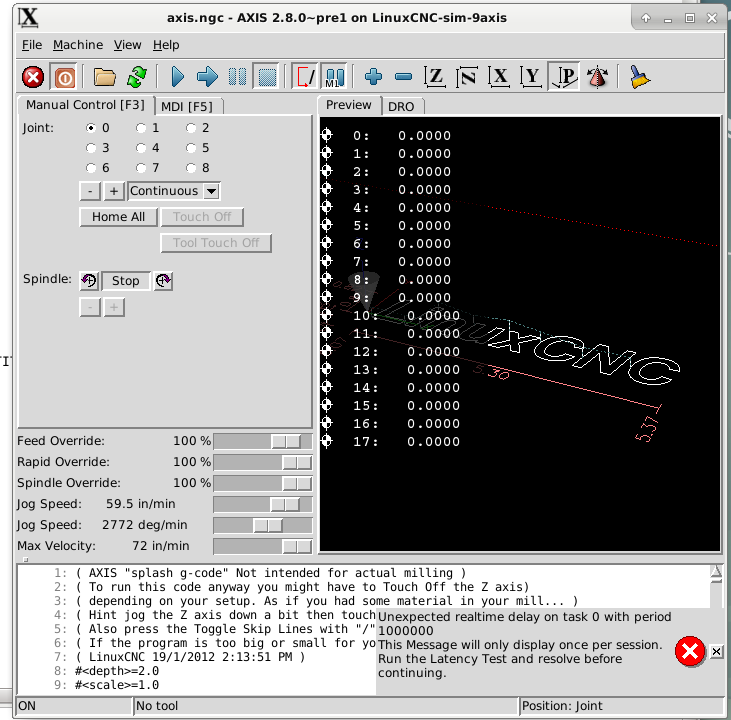
Last edit: 9 years 2 months ago by andypugh.
The following user(s) said Thank You: bkt

Please Log in or Create an account to join the conversation.

More
9 years 2 months ago - 9 years 2 months ago #98184 by bkt
Replied by bkt on topic What Mesa card for that?
thanks for indicate my the right file.

I not thinks was so big problem modify axis gui. A 19" screen resolution 1280*xxx is big enough for containing all checkbox needed.
Monday I try to improve these modification. If work I will share the result on my github.

regards
giorgio
Last edit: 9 years 2 months ago by bkt.

Please Log in or Create an account to join the conversation.

More
9 years 2 months ago #98199 by Todd Zuercher
You may also find it helpful to know that it is possible to connect, disconnect, slave and unslave different joints to different axis letters using some custom M-codes and some clever hal programming. I've done it on a servo machine.
If you would find it helpful I could share the config files with you for it. That example is only has 4 axis router with 2 Z axis. Normally the 2nd Z is defined as W, but to take advantage of the new trajectory planner only XYZ can be used, so I created this config to temporarily slave the W to the Z so that code using only XYZ can be used to run it. I did this all in hal, and it is very sensitive to thread ordering. It would probably work better and be more robust, if it was done with a custom kinematics file, but I don't have the C programming skills to pull that off (at least not yet).

Please Log in or Create an account to join the conversation.

Moderators: cmorley
Time to create page: 0.056 seconds
Powered by Kunena Forum
