
- Posts: 41
- Thank you received: 0
Motor encoder scaling
- PMCD
- Offline
- Senior Member
-

Less
More
6 years 3 days ago #187631
by PMCD
Replied by PMCD on topic Motor encoder scaling
Everything is correct as you have explained.
I have the analogue enables for x and y pulled from the 7I77 board.
Using only the z motor which is uncoupled from the axis, I enabled the servos and the motor drifts at about 2rpm then toggled F2. There is a quick jerk of the motor then a 'joint following error" on the screen.
should I play with PID tuning now?
Peter
Please Log in or Create an account to join the conversation.
- PCW
- Offline
- Moderator
-

Less
More
- Posts: 18115
- Thank you received: 5334
6 years 3 days ago #187637
by PCW
Replied by PCW on topic Motor encoder scaling
If you get a quick move and a following error when enabled,
its likely you have the feedback reversed.
Here is a basic tuning sequence for velocity mode drives:
gnipsel.com/linuxcnc/tuning/servo.html
its likely you have the feedback reversed.
Here is a basic tuning sequence for velocity mode drives:
gnipsel.com/linuxcnc/tuning/servo.html
Please Log in or Create an account to join the conversation.
- PMCD
- Offline
- Senior Member
-
Less
More
- Posts: 41
- Thank you received: 0
6 years 3 days ago - 6 years 3 days ago #187642
by PMCD
Replied by PMCD on topic Motor encoder scaling
This is how I have the encoders wired.
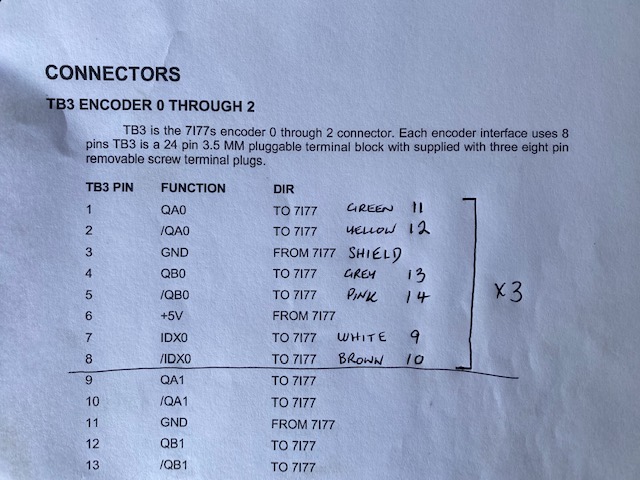
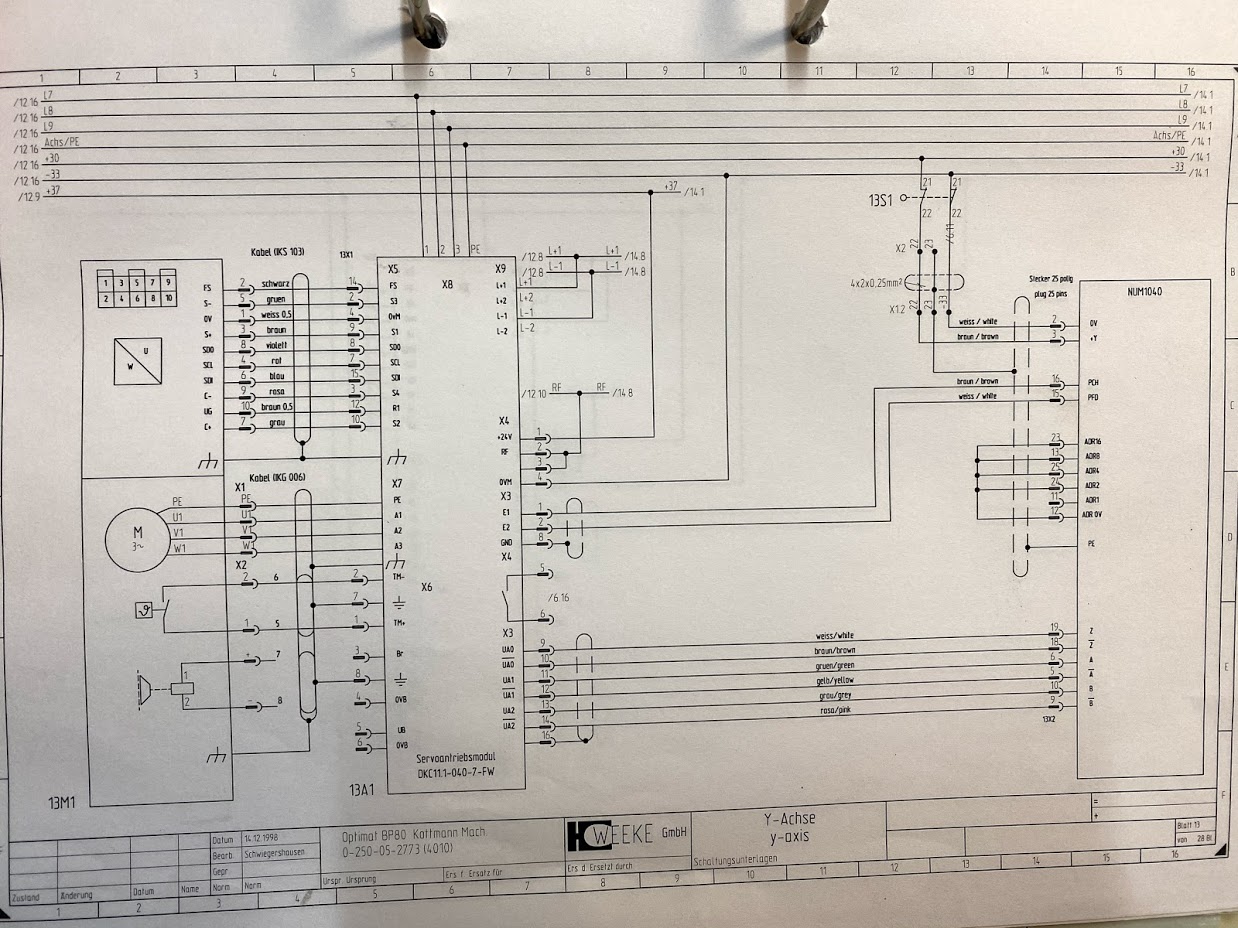
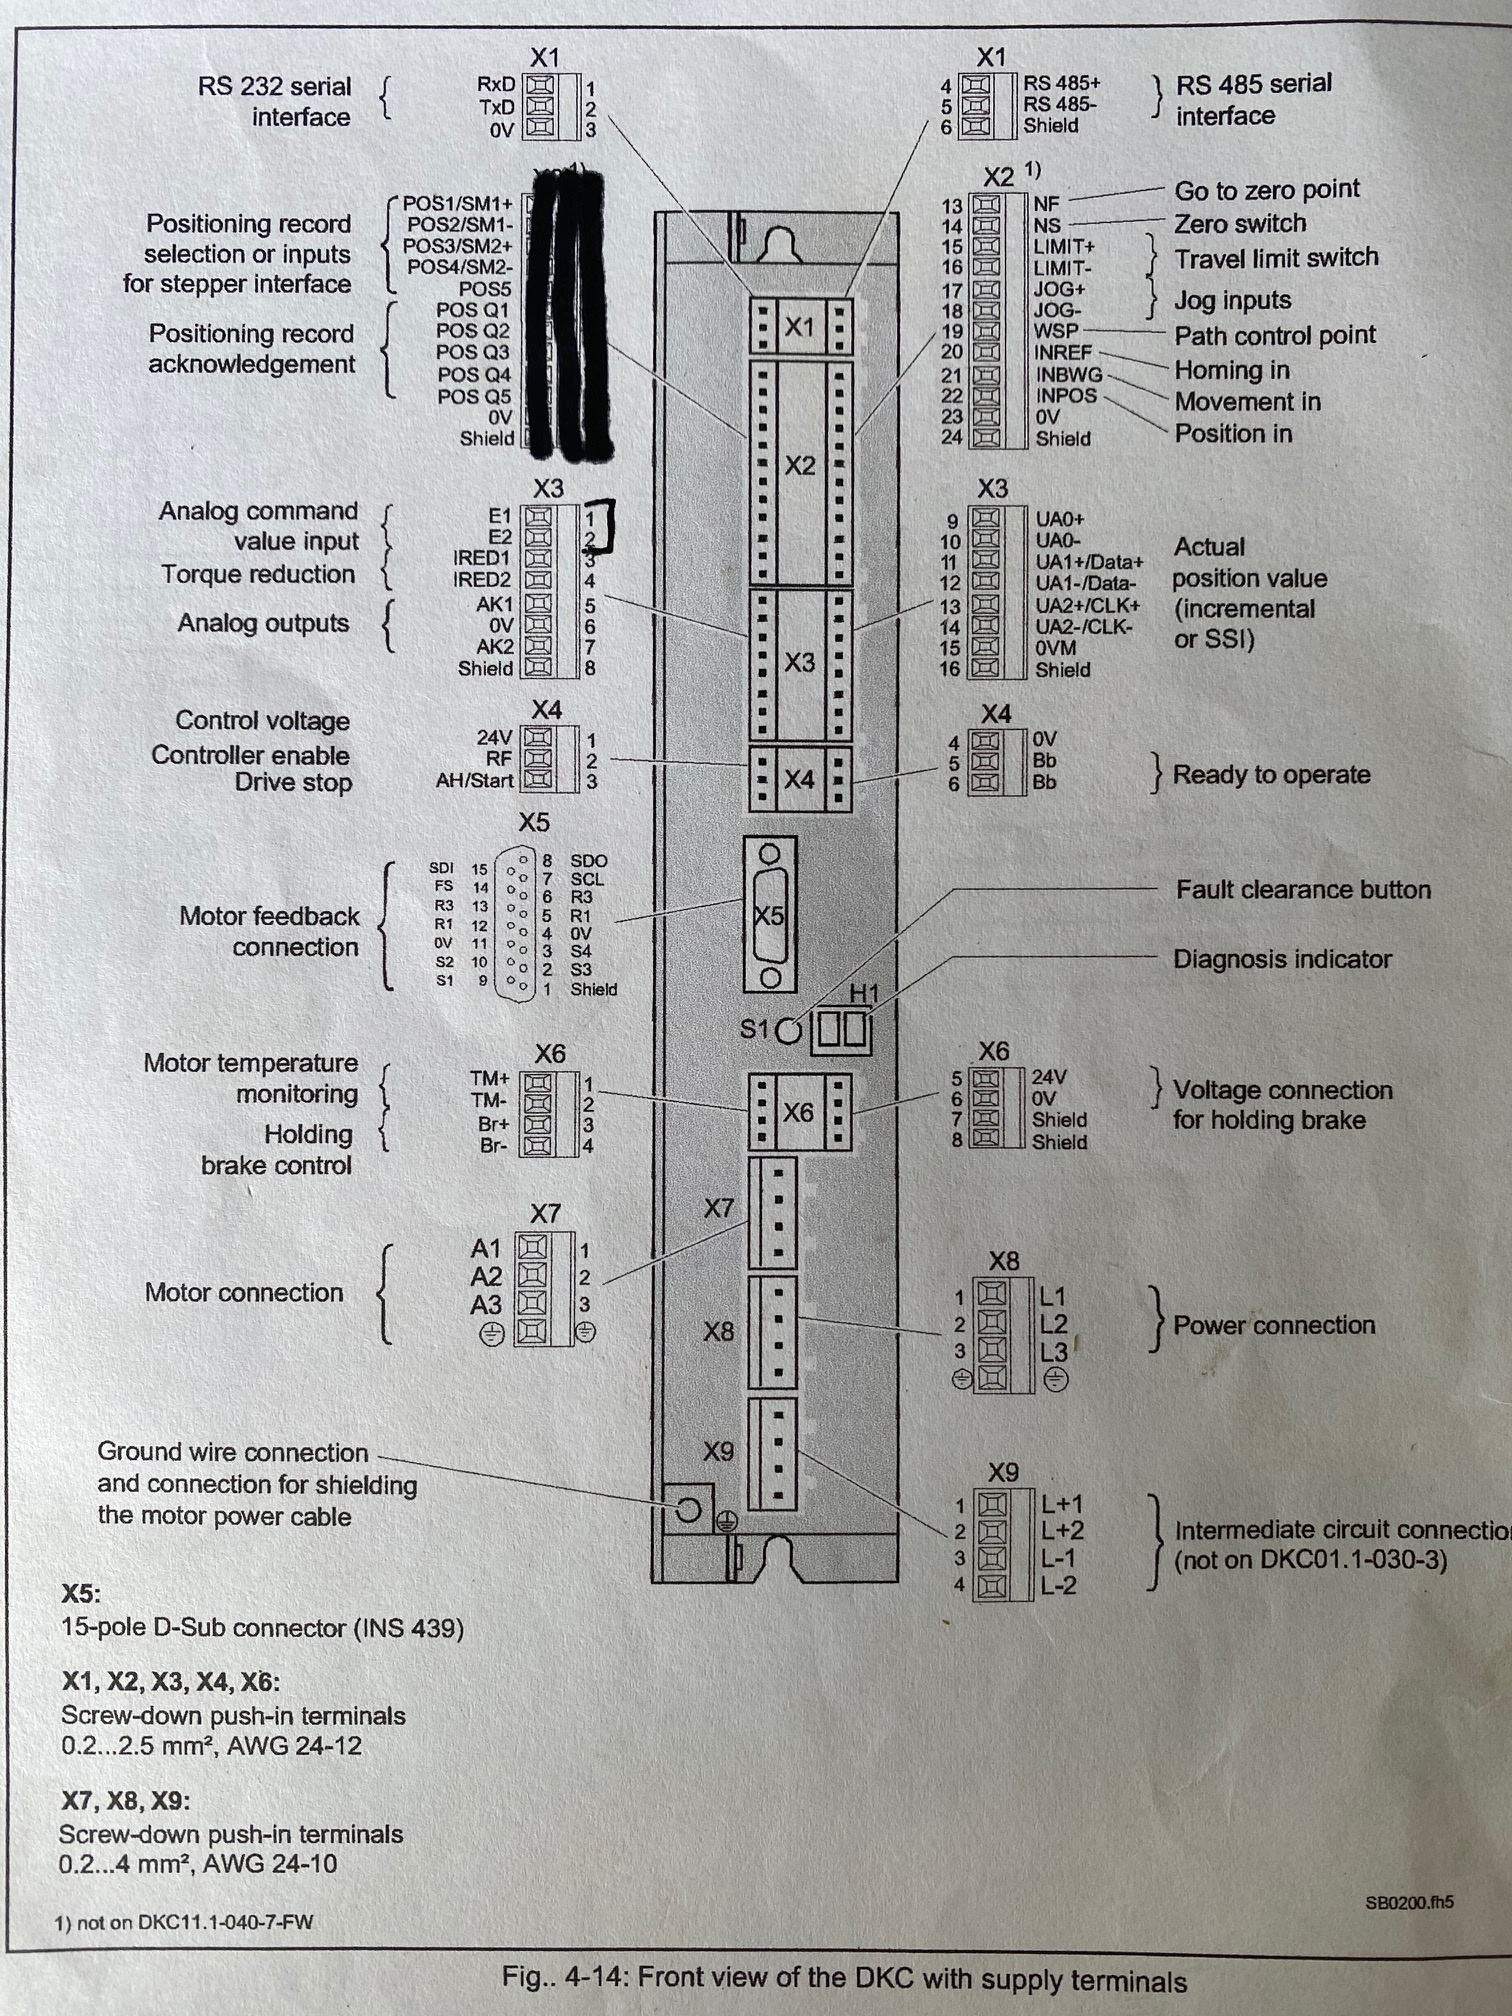
Peter
Peter
Last edit: 6 years 3 days ago by PMCD.
Please Log in or Create an account to join the conversation.
- PMCD
- Offline
- Senior Member
-
Less
More
- Posts: 41
- Thank you received: 0
6 years 2 days ago #187719
by PMCD
Replied by PMCD on topic Motor encoder scaling
So I've been playing around with encoder scale in the INI file for the 'Z' axis and am get some better result The motor is still drifting (slower) and now there is a delay (3s) before I get the following error when I start Linuxcnc,
From the attached document in my original post is there a correct figure I should be using in the encoder scale.
The last number I tried was 24576 for MKD041 motor
Peter
From the attached document in my original post is there a correct figure I should be using in the encoder scale.
The last number I tried was 24576 for MKD041 motor
Peter
Please Log in or Create an account to join the conversation.
- tommylight
- Offline
- Moderator
-
Less
More
- Posts: 22011
- Thank you received: 7491
6 years 2 days ago #187731
by tommylight
Replied by tommylight on topic Motor encoder scaling
If the motor is drifting while enabled, there is something wrong with the wiring or configuration, so:
Check if the drive is set to output INCREMENTAL values,
open halshow and check the number of raw encoder counts while the drive is disabled by moving the motor exactly one turn by hand,
And since it seems to me there might be more than one issue there, have a read through this, especially the wiring and checking parts:
forum.linuxcnc.org/10-advanced-configura...ning-detailed-how-to
Please Log in or Create an account to join the conversation.
- PMCD
- Offline
- Senior Member
-
Less
More
- Posts: 41
- Thank you received: 0
6 years 2 days ago - 6 years 2 days ago #187738
by PMCD
Replied by PMCD on topic Motor encoder scaling
H Tommy,
I think the wiring is ok.
I have had some success this morning since my last post.
Here is what I did
I changed these figures in the ini file.
Z MKD041 encoder scale 21000 (PncConf had these at 600 800 and 1600)
Y MKD041 encoder scale 21000
X MKD071 encoder scale 32000
Now when I enable the servos I get a small amount of drift until I toggle F2 then they stop and I am able to jog each axis around. The direction is correct but the DRO does not match the machine movement now (which I expected)
I have done what you said and rotated the y axis one turn, 8000 was the count.
Last edit: 6 years 2 days ago by PMCD.
Please Log in or Create an account to join the conversation.
Moderators: cmorley
Time to create page: 3.885 seconds