I did observer the behavior with different velocities and are testing without the gantry to simulate non squareness of the gantry. And the behavior I see is what you would expect from the documentation and will work in most cases.
I made some pictures in a try to better explain why I would like to change the behavior. I left out some of the details of the movements with the home_search_velocity and home_latch_velocity as it is irrelevant for the point I'm trying to make.
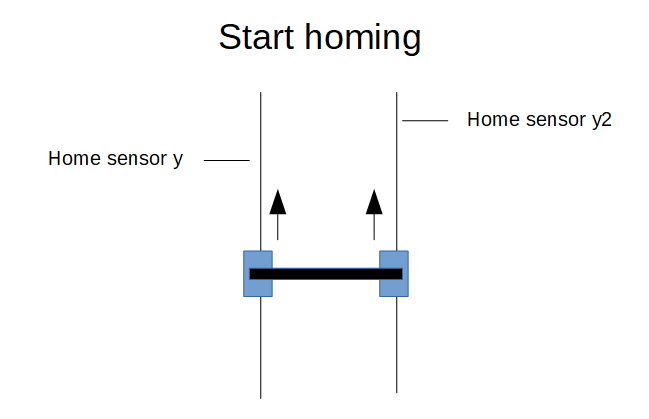
Assume that the home sensor are at different positions as shown in the picture. Then when starting the homing both carriages start moving towards the home sensors as shown in the picture below.
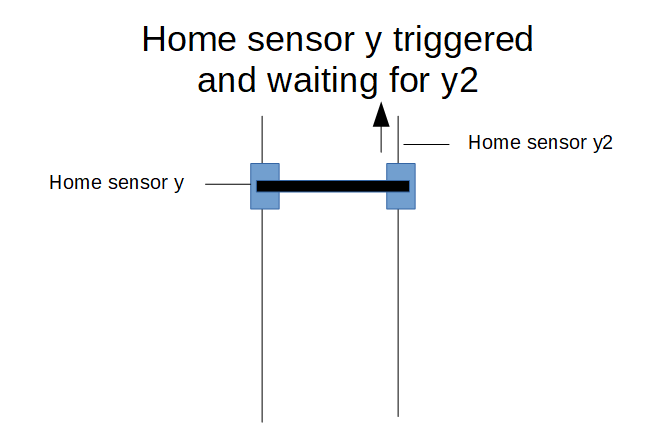
When the left carriage (y) sees the home sensor (and yes, it will back off and go forward again) it will stop there. However, the right side (y2) didn't see the sensor yet (as the sensor is further away) and keeps on moving.
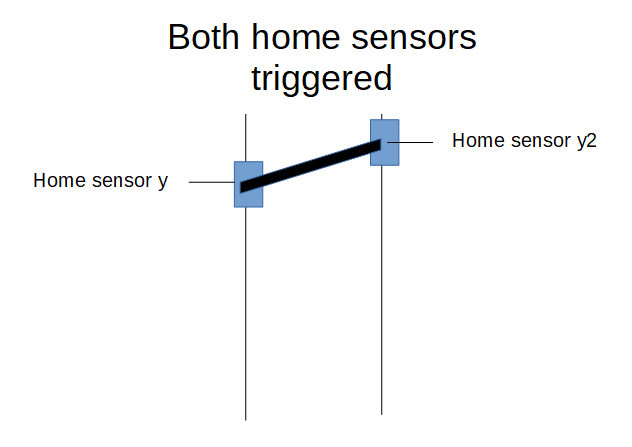
Now the right carriage (y2) sees the home sensor (and yes, will also back off and go forward again to latch) and will stop there. Not the gantry is skewed (is this the right word?). When the gantry is rather rigidly connected you can get quite high forces to deform the gantry/carriages.This is the situation I want to try to avoid.
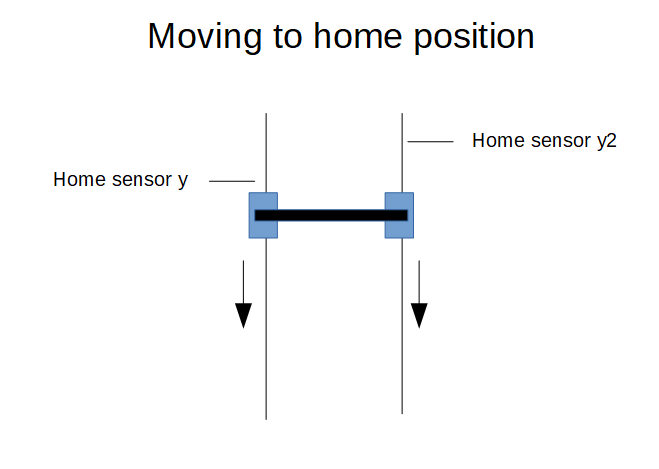
Now both sides have seen (and latched) their home sensors and start moving simultaneous towards the home position.
Rewriting/recompiling doesn't sound attractive

But maybe there's another way. Like using one home sensor to home both sides. And then probe the other home sensor or so. I don't know but was hoping somebody already thought about this.