
- Posts: 28
- Thank you received: 1


Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
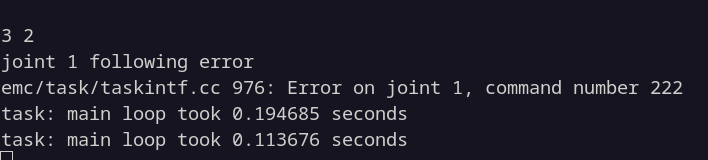
FERROR and MIN_FERROR entries need to be in the [JOINT_n] section not in the [AXIS_l] section:After I added both of above setting, the issue still happens.
I would suggest something like (100,100). I presume you are running your drives in position mode and the loop is closed in the drive, if so LinuxCNC really has no part in monitoring following errors at all and setting the values very high will effectively eliminate following error checking in LinuxCNC.I tried (FERROR; MIN_FERROR) options: (1;0.1) ; (0.1; 0.01) ; (0.01; 0.001)
If you get drive faults because of following error then you likely need to lower acceleration/velocity values. Also note that if your SCARA pose is close to a singular point the kinematic model will likely fail and cause large or even infinite angular velocities which will then cause the drives to fault.Yes, I think EtherCAT drives handle joint error, but it makes motor shocking so strong & stop suddenly without finishing targeted position.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.

Please Log in or Create an account to join the conversation.

