MVO to RO

More
10 months 2 weeks ago #340267 by gravedigger
Replied by gravedigger on topic MVO to RO
To connect encoders, the following pins are exported:

gmoccapy.jog.jog-velocity.counts (s32 IN) - Jog velocity

gmoccapy.jog.jog-velocity.count-enable (bit IN) - Must be True, to enable counts

gmoccapy.feed.feed-override.counts (s32 IN) - feed override

gmoccapy.feed.feed-override.count-enable (bit IN) - Must be True, to enable counts

gmoccapy.feed.reset-feed-override (bit IN) - reset the feed override to *0%

gmoccapy.spindle.spindle-override.counts (s32 IN) - spindle override

gmoccapy.spindle.spindle-override.count-enable (bit IN) - Must be True, to enable counts

gmoccapy.spindle.reset-spindle-override (bit IN) - reset the spindle override to *0%

gmoccapy.rapid.rapid-override.counts (s32 IN) - Maximal Velocity of the *chine

gmoccapy.rapid.rapid-override.count-enable (bit IN) - Must be True, to enable counts

Please Log in or Create an account to join the conversation.
More
10 months 2 weeks ago - 10 months 2 weeks ago #340272 by Aciera
Replied by Aciera on topic MVO to RO
Seems you are looking at 'gmoccapy' documentation for using 'halui' pins.

Halui documentation is here:
linuxcnc.org/docs/html/man/man1/halui.1.html#Rapid%20Override

However you should really be using the pins provided by gmoccapy for this purpose.
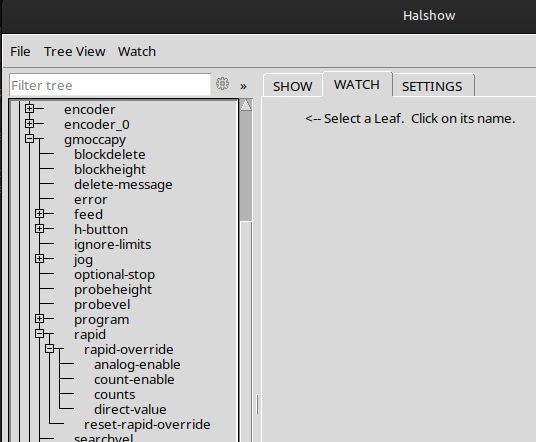
If unsure comment all lines in your hal files that give errors and use the 'Halshow' tool on the Settings page of Gmoccpy.
Using 2.9.7 I get this (which seems to agree with the documentation for Gmoccapy):
 
Last edit: 10 months 2 weeks ago by Aciera.
The following user(s) said Thank You: PCW

Please Log in or Create an account to join the conversation.

More
10 months 2 weeks ago #340273 by rodw

Please Log in or Create an account to join the conversation.

Moderators: newbynobi, HansU
Time to create page: 0.225 seconds
Powered by Kunena Forum
