PID tuning for LS Mecapion setup with MESA 7i77

More
6 years 7 months ago #161436 by alex.statie
Thank you!!

Added the config in the hal file and rerun the test.


By the way, also triggered a servo auto gain tuning in the meantime - nothing has changed.

Please Log in or Create an account to join the conversation.

More
6 years 7 months ago #161439 by PCW
Can you lower the P term to say 0.5 to see if the noise is feedback related?
also including the complete halscope screen would help (so the time/div is visible)

Please Log in or Create an account to join the conversation.

More
6 years 7 months ago - 6 years 7 months ago #161443 by alex.statie
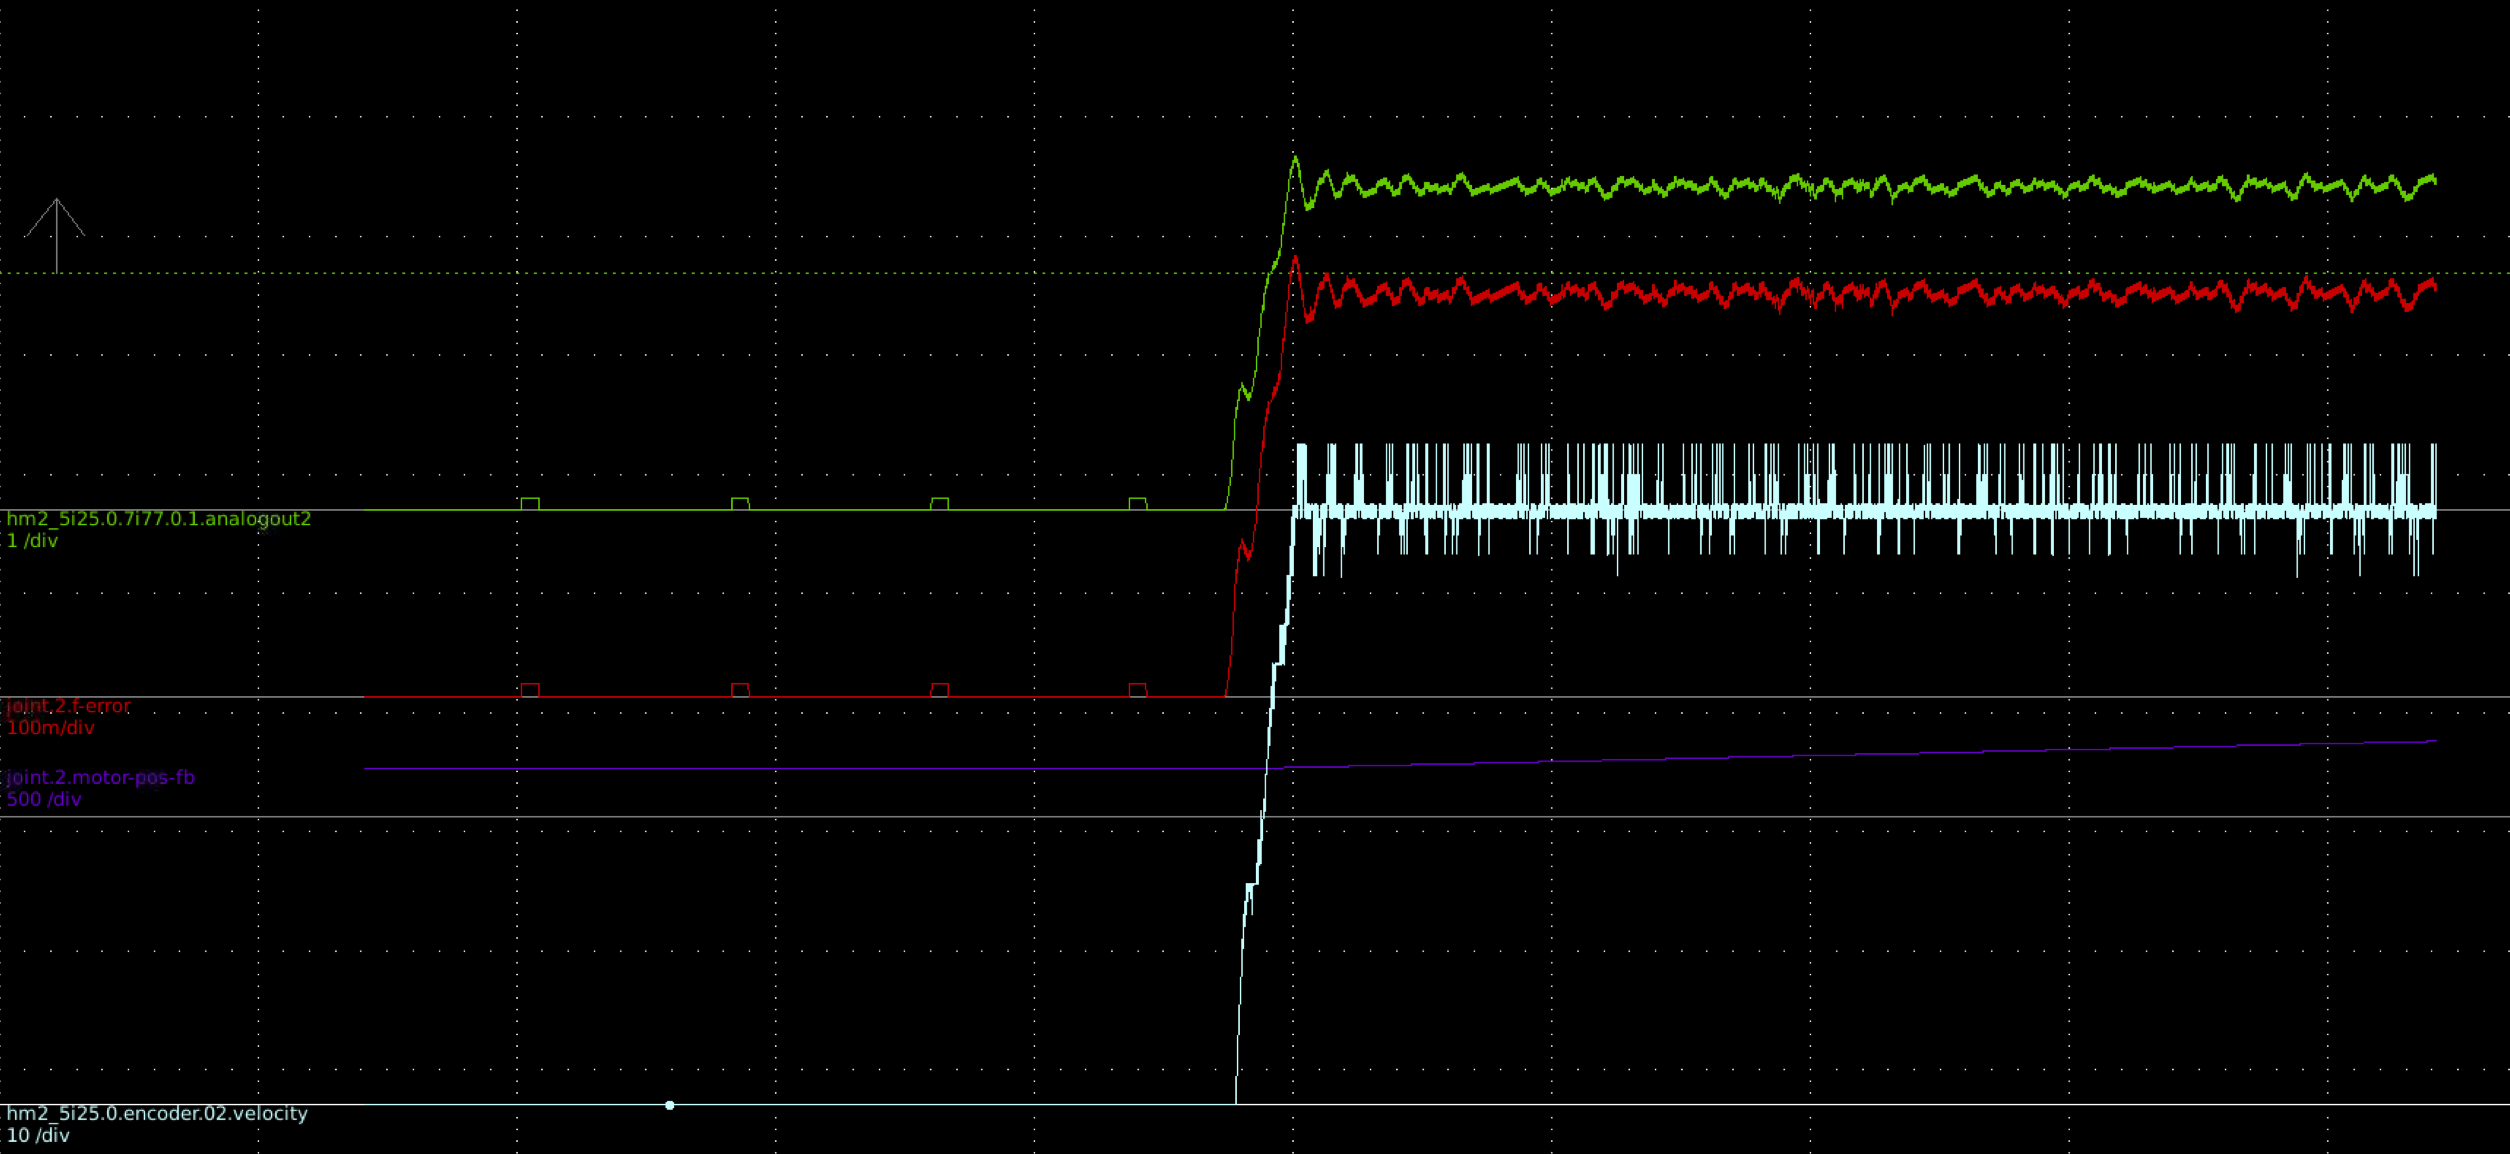
Lowered P to 0.5

Had to run at a much lower speed - from F3000 to F300 - otherwise i would trigger following error with this P value.

Here is the result:
Last edit: 6 years 7 months ago by alex.statie.

Please Log in or Create an account to join the conversation.

More
6 years 7 months ago #161447 by PCW
Note: you need to tune FF1 to lower the following error, this should be done at
a low P value

Use the calibrate menu and adjust FF1 so the following error is minimized
If error is in the same direction as the velocity (like the plot above) you have
too little FF1, If the error is in the opposite direction of the velocity, you have too
much FF1

This should allow you to get to the previous speed

Please Log in or Create an account to join the conversation.

More
6 years 7 months ago - 6 years 7 months ago #161471 by alex.statie
Did the changes.

First screenshot F700
Second one F7000


Thank you so much, big improvement!

Anything else that can be further tuned?

LE. should i also revert the encoder read freq or can i leave it to 1mhz?

Thanks,
Alex
Last edit: 6 years 7 months ago by alex.statie.

Please Log in or Create an account to join the conversation.

More
6 years 7 months ago - 6 years 7 months ago #161477 by PCW
OK one thing that needs improvement is the drives response to the velocity command.
If there are any filters in the velocity command path they should be set to their minimum time constants.

The encoder feedback indicates that the drive is not very good at generating the simulated encoder
signal (you can see obvious frequency quantization in the encoder velocity feedback) This will limit
your maximum P term but might be improved at a higher resolution simulated encoder output.

Note that you should be able to do very well with a low P term if the drive is tuned
well and there are no large delays or filters in the velocity command path, that is the
velocity command should get you 99% of the way there
Last edit: 6 years 7 months ago by PCW.

Please Log in or Create an account to join the conversation.

Moderators: snowgoer540
Time to create page: 0.276 seconds
Powered by Kunena Forum