16 Pocket tool changer with PB and carousel.comp (Working config for reference)

More
3 years 1 month ago #279850 by Marcodi
Thanks Spumco!!

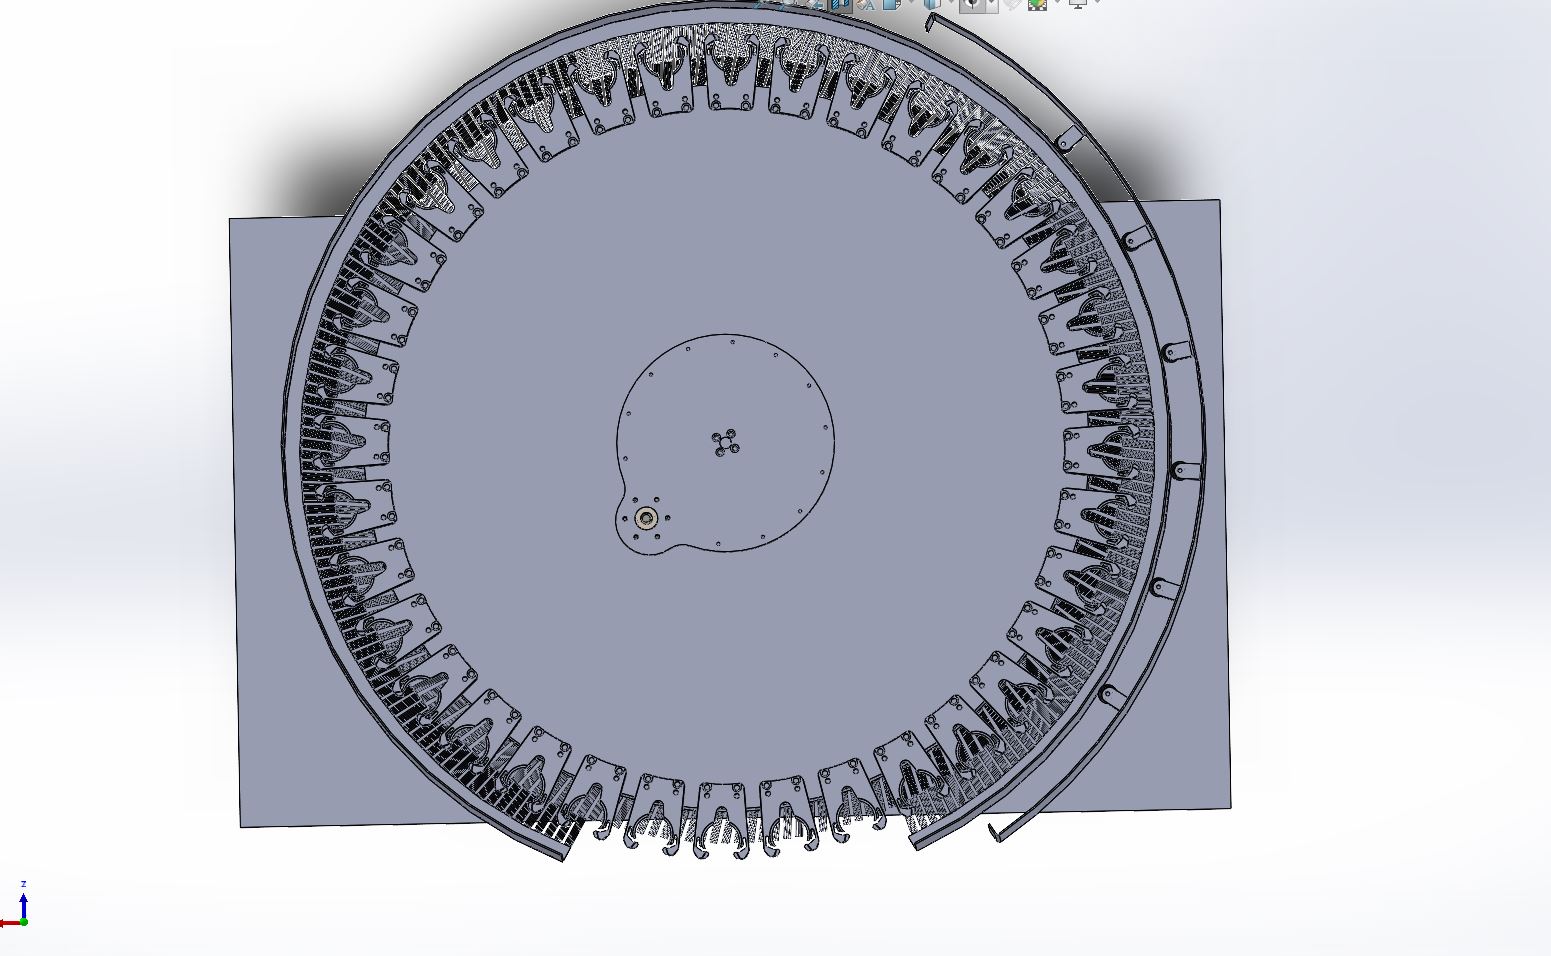
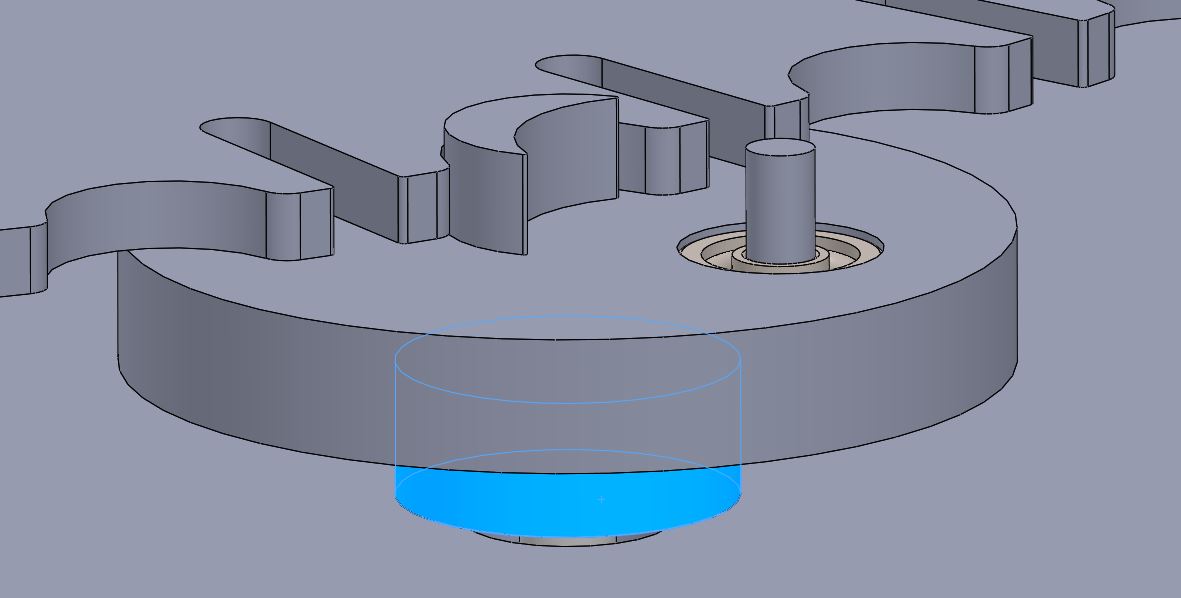
So as i am working with a geneva drive, so if we focus on that.

I will install one homing sensor ( inductive Proximity Sensor )
Secondly , i will install one inductive proximity sensor that will be triggered each time a pocket passes by. So the sensor will be on a fixed location and a screw will be used at the position of each sensor to trigger this sensor. Will this be enough for probe basic to count the pockets and know where is which pocket?

Thirdly i will install the laser sensor to check if a pocket is empty

Fourth i would install an inductive proximity sensor to sense if the lid of the toolchanger is opened and another sensor to confirm if the lid is closed to avoid crash of the spindle and the dustcover of the toolchanger.

Could you please have a look at my thread where i am describing everything, if i am on the right track? ( forum.linuxcnc.org/qtpyvcp/49649-creatin...nted-with-cad-models )

Here are 2 pictures from there to show my setup.


Please Log in or Create an account to join the conversation.

More
3 years 1 month ago #280163 by spumco

Thanks Spumco!!

So as i am working with a geneva drive, so if we focus on that.

I will install one homing sensor ( inductive Proximity Sensor )
Secondly , i will install one inductive proximity sensor that will be triggered each time a pocket passes by. So the sensor will be on a fixed location and a screw will be used at the position of each sensor to trigger this sensor. Will this be enough for probe basic to count the pockets and know where is which pocket?

Thirdly i will install the laser sensor to check if a pocket is empty

Fourth i would install an inductive proximity sensor to sense if the lid of the toolchanger is opened and another sensor to confirm if the lid is closed to avoid crash of the spindle and the dustcover of the toolchanger.


You are on the right track.  Sensor config looks good.

The Probe Basic 'standard' ATC subroutines do not include tool checks with a laser or your dustcover sensor - you will have to figure those out on your own, or at least copy & modify GuiHue's configuration & subroutines to use those features.

The PB subroutines also include logic for sensors to detect if the ATC platter is in extended or retracted position.  If you have (or will have) such sensors, those will need to be connected.  If your mechanism is different you'll have to manage something else, of course.

I don't know what's driving the geneva rotation - what motor - but PB expects to output a forward and reverse signal.  One signal/pin each, and there's no speed control.  Whatever is driving your motor will need to be capable of using two digital outputs from LCNC.

Please Log in or Create an account to join the conversation.

Moderators: KCJ, Lcvette
Time to create page: 0.220 seconds
Powered by Kunena Forum