Search Results (Searched for: )

  • unknown
21 Nov 2025 12:19
Replied by unknown on topic How do you vote in the hardware survey?
I get it the rest of us are on double secret probation. ;)
  • Aciera
21 Nov 2025 12:17
'matrixkins.comp' would need to be modified to map your tandem joints to the approriate axes.

Please attach your current ini file so I can have a look.
  • TimP
21 Nov 2025 12:12
Replied by TimP on topic Need your opinion on Axes placement.
i guess in my case what i have drown that it will be mix of twos, since x axis(table) will move with + to the left (as usual cnc does) and others two as you said. Wondering can it cause any problems with configuration or smt else
  • Mr. Mass
21 Nov 2025 12:09
Replied by Mr. Mass on topic qtdragon mod
I came back to this topic again, and I had a new idea. I want to make a semaphore thingy using RGB LEDs. I used 3 OUT FLOAT, which I connected to PWM LEDs. The hardware works fine, the colors change, but I'm stuck on how to write the function correctly. Here's what I came up with:
Code:
def init_pins(self):# status LED pins pin = QHAL.newpin("led-red", QHAL.HAL_FLOAT, QHAL.HAL_OUT) pin.value_changed.connect(lambda: self.status_led_changed()) pin = QHAL.newpin("led-green", QHAL.HAL_FLOAT, QHAL.HAL_OUT) pin.value_changed.connect(lambda: self.status_led_changed()) pin = QHAL.newpin("led-blue", QHAL.HAL_FLOAT, QHAL.HAL_OUT) pin.value_changed.connect(lambda: self.status_led_changed()) def status_led_changed(self): if STATUS.is_man_mode(): print("status is manual mode", STATUS.is_man_mode()) self.h["led-red"] = 255 self.h["led-green"] = 0 self.h["led-blue"] = 0 elif STATUS.is_auto_mode(): print("status is auto mode", STATUS.is_auto_mode()) self.h["led-red"] = 0 self.h["led-green"] = 255 self.h["led-blue"] = 0

It seems to work, but only once at startup. How can I make this function run continuously?
  • snowgoer540
21 Nov 2025 12:06
Replied by snowgoer540 on topic How do you vote in the hardware survey?
The third was me, so seems like only mods?
  • abs32
21 Nov 2025 11:43 - 23 Nov 2025 16:16
We figured out the setting of the parameters, thank you. The program starts normally. Home search is normal.
But running any g-code program fails. Moreover, an attempt to move manually (with arrows on the keyboard) leads to the fact that only each motor moves separately - i.e. not two X X motors, but one X motor, which immediately leads to an accident.

#2025-11-20 для 2.9.4
#KINEMATICS = trivkins coordinates=XXYYZ
KINEMATICS=matrixkins

Where exactly and how exactly can we now indicate that we have 5 engines and an XXYYZ circuit?

ini-file:
[KINS]
    JOINTS = 5
   
    #2025-11-20 для 2.9.4
    #KINEMATICS = trivkins coordinates=XXYYZ
    KINEMATICS=matrixkins


[HAL]
    HALFILE = 4.hal
    HALCMD = setp matrixkinx.C_xy 0 # Skew Y axis towards X axis
    POSTGUI_HALFILE = postgui_call_list.hal
    
[TRAJ]
    COORDINATES =  XXYYZ
    LINEAR_UNITS = mm
    ANGULAR_UNITS = degree
    DEFAULT_LINEAR_VELOCITY = 25.00
    MAX_LINEAR_VELOCITY = 250.00


  • Aciera
21 Nov 2025 10:28
setting maxkins paramter values certainly works for me.
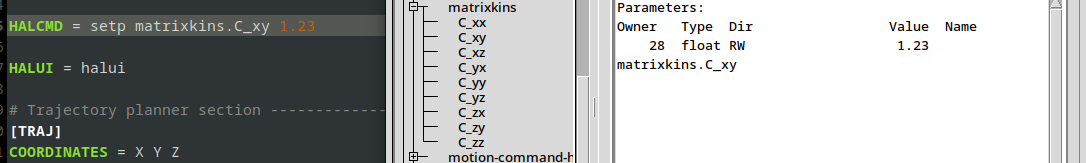
Example using 'HALCMD' entry in the [HAL] section of the inifile:
 

parameter values can also be changed during run time using an executable Mcode that calls 'halcmd' tool but doing so on a kinematics parameter may lead to joint following errors.
  • abs32
21 Nov 2025 10:20 - 21 Nov 2025 10:21
But another problem immediately appeared!

when you try to run a regular program, errors will appear
about the release of a program for A and B positive limits!
I don’t have A and B axles, but for 0-4 engines all the limits are set correctly
XXYYZ!
  • abs32
21 Nov 2025 10:13 - 21 Nov 2025 10:16
But how to correctly write the value of one of the parameters in the settings? If earlier I could provide in a hal file
setp relkins.adjX.Y0 0

now it's an attempt to indicate

setp matrixkinx.C_xy 0

leads to abortion program launch

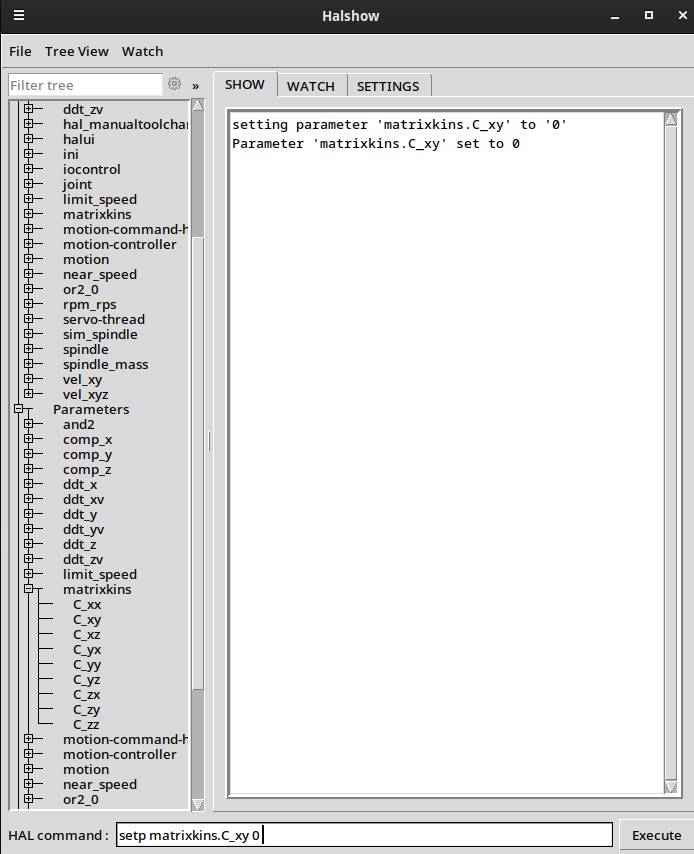
Through HalShow, the command setp matrixkinx.C_xy 0 is executed normally.
  • abs32
21 Nov 2025 10:09
Bravo, thank you!
The interface immediately changed - before home, a choice of individual motors is now available!
There was an error in the perception of the hal file configuration when I tried to write down the parameters
setp matrixkins.C_xy 0
  • Aciera
21 Nov 2025 09:52
Comment out or remove all lines with 'matrixkins' and try to start the config, if it starts open the 'show hal configuration' tool and check if 'matrixkins' has been loaded and the parameters have been created:
 
  • abs32
21 Nov 2025 09:42 - 21 Nov 2025 09:43
Thank you, of course, I'm a hat and stupidly downloaded the html page. We have advanced

halcompile --install matrixkins.comp
Compiling realtime matrixkins.c
Linking matrixkins.so
cp matrixkins.so /usr/lib/linuxcnc/modules/

start abort -
4.hal:22: parameter or pin 'matrixkins.C_xy' not found

4.hal file -
setp matrixkins.C_xy 0  # Skew Y axis towards X axis
setp matrixkins.C_xx 1  # X axis scale
setp matrixkins.C_xz 0  # Skew Z axis towards X axis
setp matrixkins.C_yx 0  # Skew X axis towards Y axis
setp matrixkins.C_yy 1  # Y axis scale
setp matrixkins.C_yz 0  # Skew Z axis towards Y axis
setp matrixkins.C_zx 0  # Skew X axis towards Z axis
setp matrixkins.C_zy 0  # Skew Y axis towards Z axis
setp matrixkins.C_zz 1  # Z axis scale
  • Aciera
21 Nov 2025 09:25
Try copy/pasting the contents of the file:
raw.githubusercontent.com/LinuxCNC/linux...ents/matrixkins.comp
  • abs32
21 Nov 2025 09:21 - 21 Nov 2025 09:21
pardone, -
wget github.com/LinuxCNC/linuxcnc/blob/master...ents/matrixkins.comp
--2025-11-21 12:20:08-- github.com/LinuxCNC/linuxcnc/blob/master...ents/matrixkins.comp
Распознаётся github.com (github.com)… 140.82.121.3
Подключение к github.com (github.com)|140.82.121.3|:443... соединение установлено.
HTTP-запрос отправлен. Ожидание ответа… 200 OK

halcompile --install matrixkins.comp
Traceback (most recent call last):
File "/usr/bin/halcompile", line 1553, in <module>
main()
File "/usr/bin/halcompile", line 1523, in main
process(f, mode, outfile)
File "/usr/bin/halcompile", line 1363, in process
a, b = parse(filename)
^^^^^^^^^^^^^^^
File "/usr/bin/halcompile", line 441, in parse
a, b = f.split("\n;;\n", 1)
^^^^
ValueError: not enough values to unpack (expected 2, got 1)
  • dgdodo
21 Nov 2025 09:19
Replied by dgdodo on topic [SOLVED] Backlash issues on Y-AXIS
unknown,

Do you have a Debian Trixie version with RT-PREEMPT kernel for a RaspberryPi 3B+?
It is everywhere written that Trixie already is ' real-time', but I faced a lot of issues when trying to run LinuxCNC on Trixie. Especially on a RaspberryPi 3B+.

Regards, DGdodo
Displaying 10906 - 10920 out of 11917 results.
Time to create page: 0.689 seconds
Powered by Kunena Forum