Search Results (Searched for: )

  • micklethenickel
29 Jan 2026 01:24
Replied by micklethenickel on topic Using Mesa 7i95T for laser + galvo (xy2-100) control
Thank you so much!
  • PCW
29 Jan 2026 01:19
7I95T configuration with last two stepgens replaced with XY2-100 galvanometer outputs
and serial 0 RX replaced with XY2-100 Status


File Attachment:

File Name: 7i95t_xymodd.zip
File Size:281.46 KB

 
  • grandixximo
29 Jan 2026 01:19 - 29 Jan 2026 01:20
Replied by grandixximo on topic LinuxCNC S-Curve Accelerations

A word of caution to anyone testing the new planner on real hardware:

I would strongly recommend to NOT activate the new planner in the ini file.
I dropped my homing velocities to 20% and my real hardware setup still runs into the hard stops on homing.

Users should leave ini.planner_type = 0, home the machine and use halshow to set ini.planner_type = 1.

Try with max_jerk and default_jerk to 10000 or more, 1000 was more for showcasing the curves, not to run on actual hardware, already planning to change the showcase ini to 10000 
  • grandixximo
29 Jan 2026 01:17
Replied by grandixximo on topic LinuxCNC S-Curve Accelerations

I've been trying to test this on real hardware using Mesa but I cannot seem to get the new planner to work at all.

- [TRAJ] section has 'MAX_LINEAR_JERK = 1000.0'
- both [JOINT_0] and [JOINT_1] have 'MAX_JERK = 1000.0'
- ini.planner_type = 1


Yet running this code in G61.1 mode
Code:
G21 F5000 G0 x0 y0 g1 x20 y20 x0 y0 m2 I get this:  [attachment=74126]Screenshot from 2026-01-27 10-31-48.png[/attachment] here is my ini file: [spoiler] # This file was updated with the Mesa Configuration Tool on Nov 25 2025 13:43:50 # Changes to most things are ok and will be read by the Configuration Tool [MESA] VERSION = 2.1.8 BOARD = 7i95 BOARD_NAME = 7i95t [EMC] VERSION = 1.1 MACHINE = test_setup DEBUG = 0x00000000 [HM2] DRIVER = hm2_eth ADDRESS = 192.168.1.121 [DISPLAY] DISPLAY = axis PROGRAM_PREFIX = ./nc_files POSITION_OFFSET = RELATIVE POSITION_FEEDBACK = ACTUAL MAX_FEED_OVERRIDE = 1.2 MIN_LINEAR_VELOCITY = 0.0 DEFAULT_LINEAR_VELOCITY = 150.0 MAX_LINEAR_VELOCITY = 300.0 CYCLE_TIME = 0.1 INTRO_GRAPHIC = emc2.gif INTRO_TIME = 0 OPEN_FILE = ./square.ngc EDITOR = gedit DEFAULT_ANGULAR_VELOCITY = 18000 MAX_ANGULAR_VELOCITY = 36000 MIN_ANGULAR_VELOCITY = 1 [KINS] KINEMATICS = trivkins JOINTS = 2 [EMCIO] CYCLE_TIME = 0.100 TOOL_TABLE = tool.tbl [RS274NGC] PARAMETER_FILE = parameters.var [EMCMOT] EMCMOT = motmod COMM_TIMEOUT = 1.0 SERVO_PERIOD = 1000000 [TASK] TASK = milltask CYCLE_TIME = 0.010 [TRAJ] COORDINATES = XY LINEAR_UNITS = mm ANGULAR_UNITS = degree MAX_LINEAR_VELOCITY = 200.0 PLANNER_TYPE = 1 MAX_LINEAR_JERK = 1000.0 DEFAULT_LINEAR_JERK = 500.0 [HAL] HALFILE = main.hal [AXIS_X] MIN_LIMIT = 0 MAX_LIMIT = 300 MAX_VELOCITY = 300 MAX_ACCELERATION = 800 [JOINT_0] CARD = 0 MIN_LIMIT = 0 MAX_LIMIT = 300 MAX_VELOCITY = 300 MAX_ACCELERATION = 800 MAX_JERK = 1000.0 TYPE = LINEAR SCALE = 252.65 STEPGEN_MAX_VEL = 360.00 STEPGEN_MAX_ACC = 960.00 DIRSETUP = 10000 DIRHOLD = 10000 STEPLEN = 4000 STEPSPACE = 4000 ENCODER_SCALE = 200 FERROR = 1.5 MIN_FERROR = 0.25 DEADBAND = 0.01 P = 1000 I = 0 D = 0 FF0 = 0 FF1 = 1 FF2 = 0 BIAS = 0 MAX_OUTPUT = 0 MAX_ERROR = 0.0127 HOME_OFFSET = -0.75 HOME = 0 HOME_SEARCH_VEL = -5 HOME_LATCH_VEL = -5 HOME_FINAL_VEL = 2.5 HOME_IGNORE_LIMITS = YES HOME_SEQUENCE = 0 [AXIS_Y] MIN_LIMIT = 0 MAX_LIMIT = 300 MAX_VELOCITY = 300 MAX_ACCELERATION = 800 [JOINT_1] CARD = 0 MIN_LIMIT = 0 MAX_LIMIT = 300 MAX_VELOCITY = 300 MAX_ACCELERATION = 800 MAX_JERK = 1000.0 TYPE = LINEAR SCALE = 252.65 STEPGEN_MAX_VEL = 360.00 STEPGEN_MAX_ACC = 960.00 DIRSETUP = 10000 DIRHOLD = 10000 STEPLEN = 4000 STEPSPACE = 4000 ENCODER_SCALE = 200 FERROR = 1.5 MIN_FERROR = 0.25 DEADBAND = 0.01 P = 1000 I = 0 D = 0 FF0 = 0 FF1 = 1 FF2 = 0 BIAS = 0 MAX_OUTPUT = 0 MAX_ERROR = 0.0127 HOME_OFFSET = 0.25 HOME = 0 HOME_SEARCH_VEL = -5 HOME_LATCH_VEL = -5 HOME_FINAL_VEL = 2.5 HOME_IGNORE_LIMITS = YES HOME_SEQUENCE = 0 [/spoiler] What am I missing?
 
Axis Max Jerk ?
  • unknown
29 Jan 2026 01:13 - 29 Jan 2026 01:15
So.....you are wanting testers for a closed source hardware project ;)
What's in it for the testers ? :)

USB Stability & Real-Time Thread I’m well aware that USB isn't for the Servo Thread. 

What thread will it run in ? And you suggesting another thread to add to a config ? What period would this be run at ?
How would that affect a config that has a base thread (for software step gen) and a servo thread for other functions ?
  • grandixximo
29 Jan 2026 01:13 - 29 Jan 2026 01:37
Replied by grandixximo on topic LinuxCNC S-Curve Accelerations

A word of caution to anyone testing the new planner on real hardware:

I would strongly recommend to NOT activate the new planner in the ini file.
I dropped my homing velocities to 20% and my real hardware setup still runs into the hard stops on homing.

Users should leave ini.planner_type = 0, home the machine and use halshow to set ini.planner_type = 1.
 

I would echo this warning for the latest master changes

1. Jerk does not seem to be limited nor acceleration:


2. Commanded position may take off on random tangents"


Do you think this is related to the 0000% feed override? how many multipliers of feed override have you set?

I tested with my configuration can complete torus no problem but I only did 200%

can you zip your config folder? I also don't use inches, that could be a factor.
  • unknown
29 Jan 2026 01:08
Replied by unknown on topic Debian Trixie upgrade/install to 2.9.4
Google "linux clone hdd"

And choose your poison, the subject is a bit expansive, and it's not something I'd like to describe to a newbie. There are many many ways to do this.

You can also use debian's preseed config to install extra apps.

Once again google "debian preseed" and you will have a clean install without any fluff.
  • grandixximo
29 Jan 2026 01:07
Replied by grandixximo on topic LinuxCNC S-Curve Accelerations
Please share a zip of entire configuration, so I can reproduce what you are seeing on my end, thank you
  • phino
29 Jan 2026 01:05

Do you need the galvo status?
Would be great to have firmware for both option. Thanks for making the firmware!

Are there instructions somewhere for building the firmware for oneself?
  • unknown
29 Jan 2026 01:01
  • COFHAL
29 Jan 2026 00:56
How do I create an image of the contents of one hard drive to install it on another? This is to avoid having to reinstall the additional applications I use with LCN.
  • COFHAL
29 Jan 2026 00:50
Replied by COFHAL on topic Debian Trixie upgrade/install to 2.9.4
Excuse my ignorance, but how do I create an image of the contents of one hard drive to install it on another? This is to avoid having to reinstall the additional applications I use with LCN.
  • COFHAL
29 Jan 2026 00:38 - 29 Jan 2026 00:40
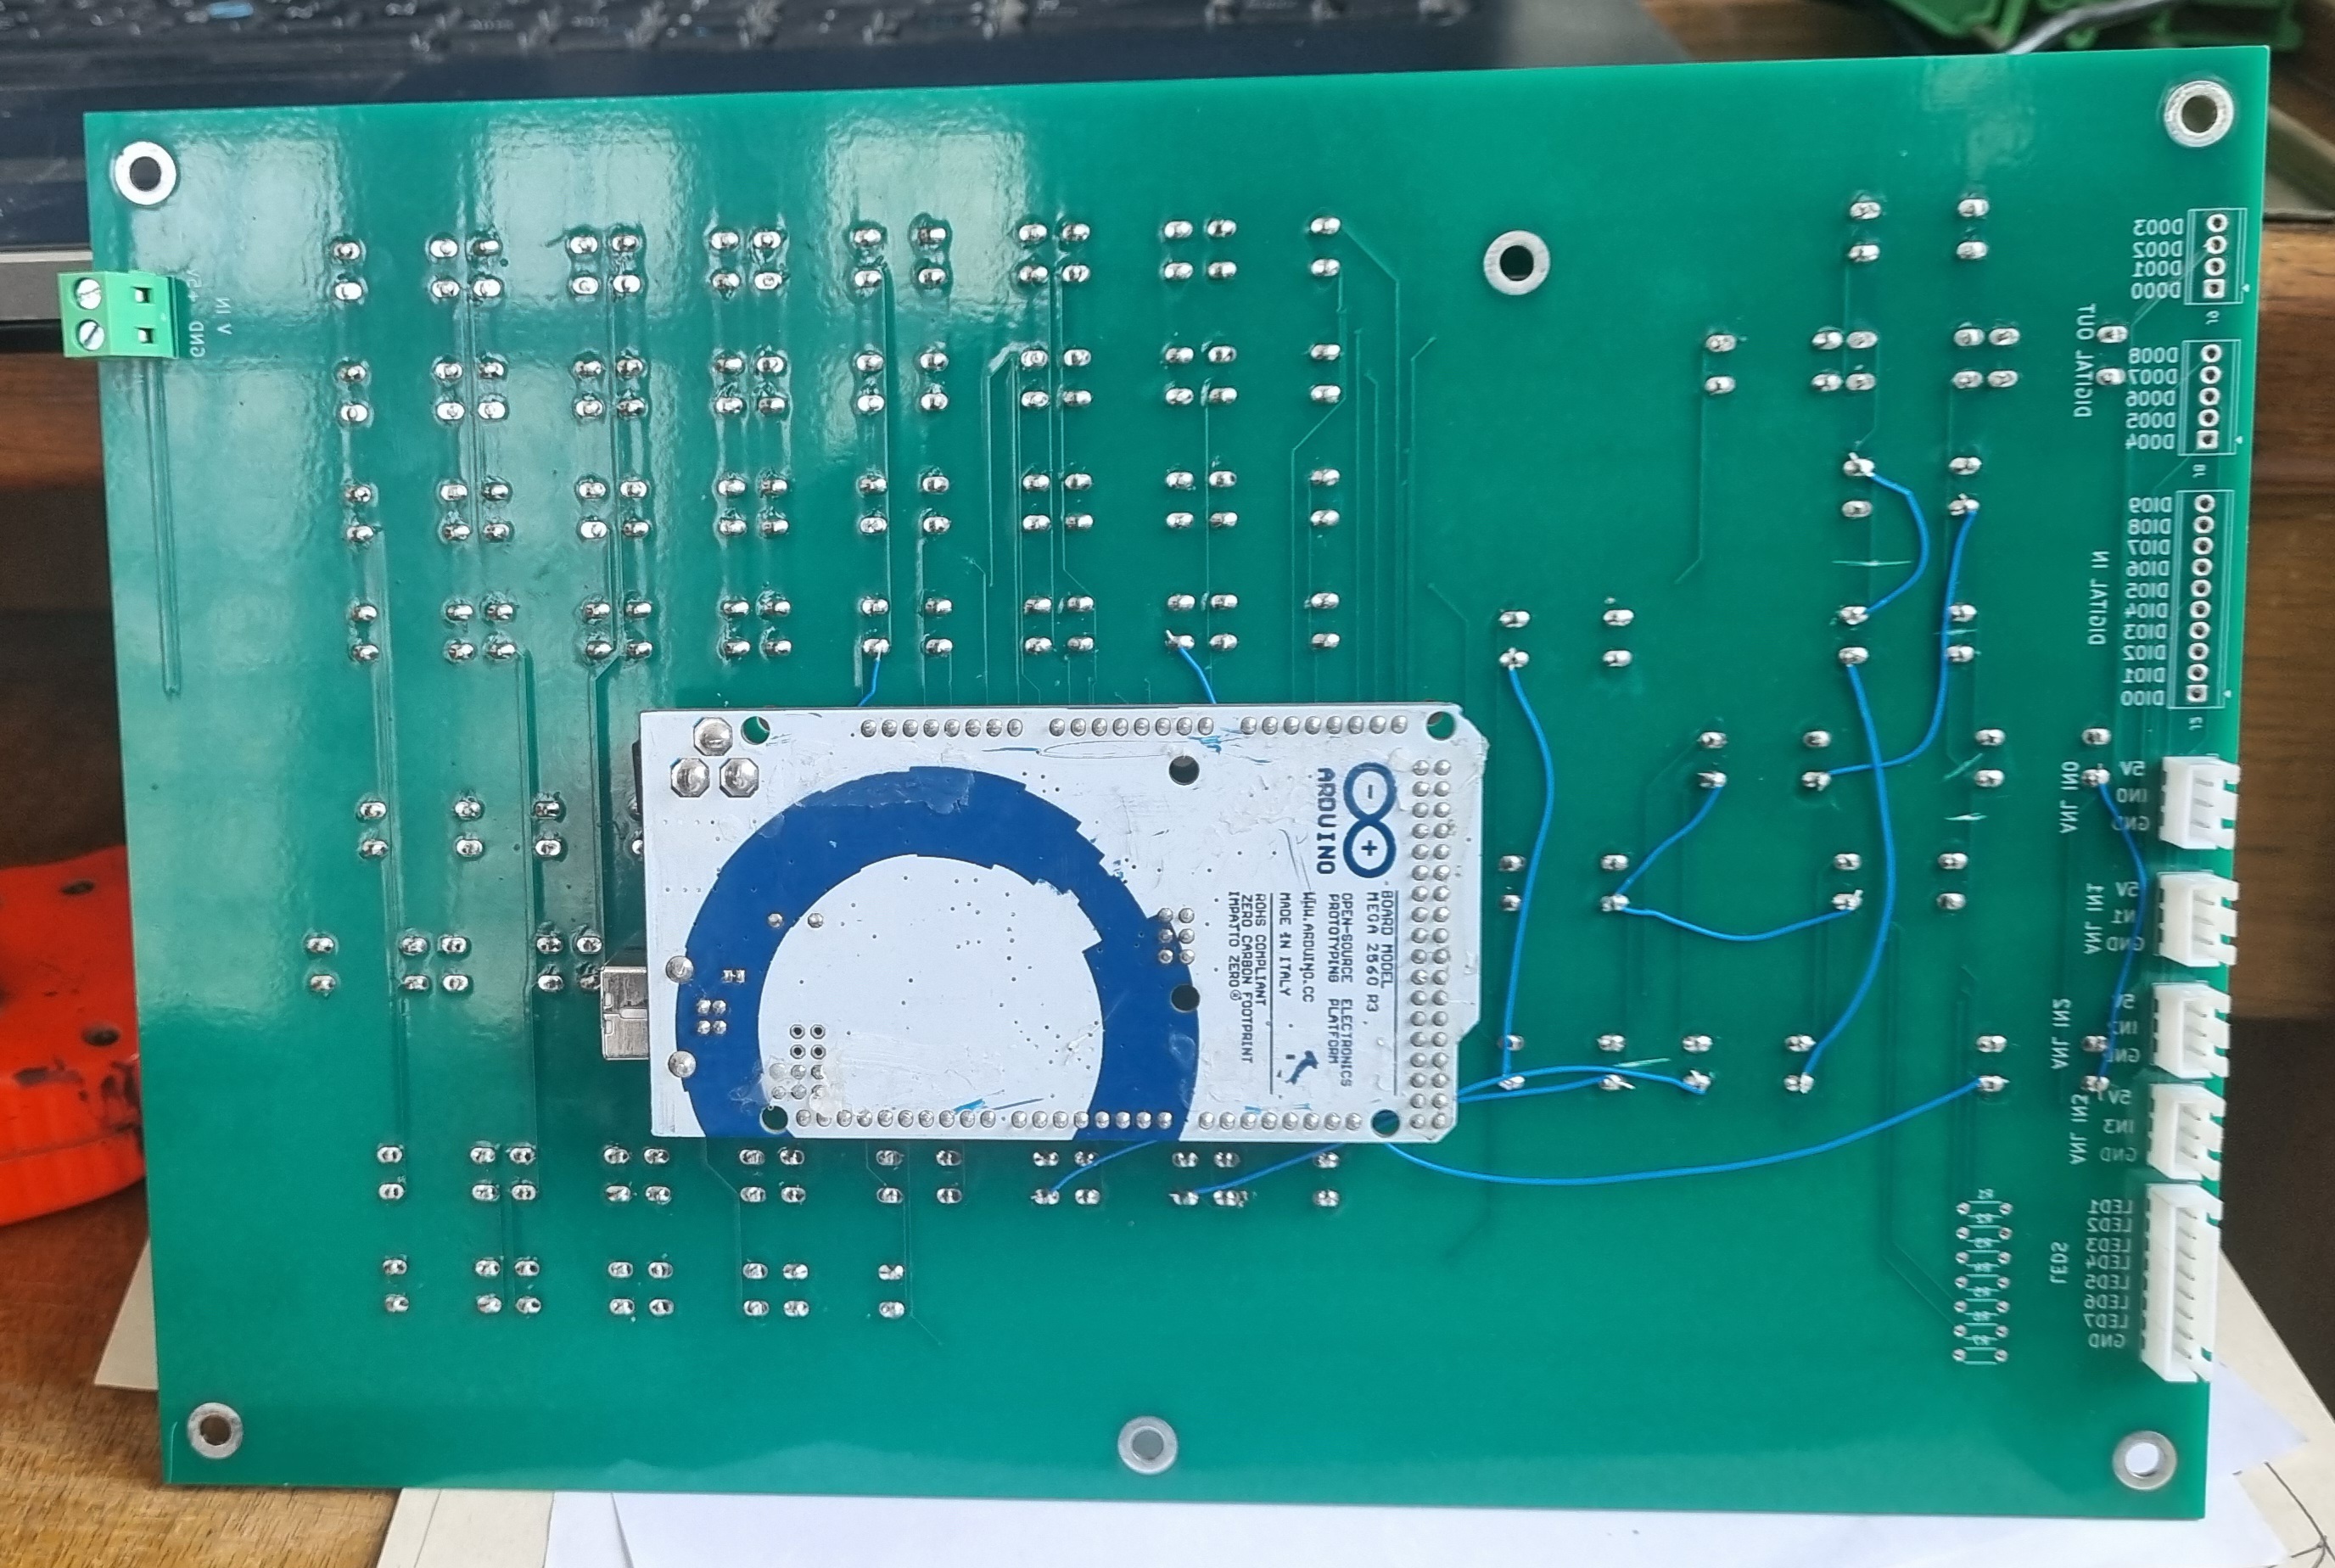
I use Arduino Connector, I really like your project, it's very professional. I don't know if you plan to create matrix-type keyboards to simulate keys or to be used as HAL pins like in Arduino Connector, which gives great flexibility.
  • COFHAL
29 Jan 2026 00:32
Thanks, I had an error in the rules file, that's why that error appeared.
  • micklethenickel
29 Jan 2026 00:28
Replied by micklethenickel on topic Using Mesa 7i95T for laser + galvo (xy2-100) control
Yes
Displaying 7966 - 7980 out of 11814 results.
Time to create page: 0.259 seconds
Powered by Kunena Forum