
Search Results (Searched for: )

  • tommylight
16 Nov 2025 16:37
Replied by tommylight on topic Why is there no BSDCNC?
DOS is also not mentioned in that document.
  • PCW
16 Nov 2025 16:30
Replied by PCW on topic Problema de altura en el eje Z
Possibly  like an issue with:

1. Z home switch

2. home switch debouncing

3. home latch velocity too high
  • miro199315
16 Nov 2025 15:51
Replied by miro199315 on topic Configuration Schnider electric ILA2 Servo
Thanks for the hint. I recompiled and installed the EtherCAT master with
Code:
--disable-eoe
, and now EoE is fully disabled.Also, my network card is Intel, not Realtek, so the Realtek DKMS driver wasn’t needed.After reinstalling the master without EoE, the bus comes up normally and the slaves are detected correctly.

However, I still have one remaining issue after boot. Here is the relevant kernel log excerpt:
Code:
[    5.626873] EtherCAT: Master driver 1.6.8 1.6.8 [    5.626989] EtherCAT: 1 master waiting for devices. [    5.639150] ec_generic: EtherCAT master generic Ethernet device module 1.6.8 1.6.8 [    5.639161] EtherCAT: Accepting 00:0B:AB:B6:75:75 as main device for master 0. [    5.639168] ec_generic: Binding socket to interface 2 (enp2s0). [    5.656187] EtherCAT 0: Starting EtherCAT-IDLE thread. [    7.256801] igb 0000:02:00.0 enp2s0: igb: enp2s0 NIC Link is Up 100 Mbps Full Duplex, Flow Control: RX [    7.256910] IPv6: ADDRCONF(NETDEV_CHANGE): enp2s0: link becomes ready [    7.260394] EtherCAT 0: Link state of ecm0 changed to UP. [    7.268195] EtherCAT 0: 2 slave(s) responding on main device. Re-scanning on next possibility. [    7.268197] EtherCAT 0: Slave states on main device: PREOP. [    7.268198] EtherCAT 0: Re-scanning now. [    7.268519] EtherCAT 0: Scanning bus. [    7.513259] EtherCAT 0: Bus scanning completed in 244 ms. [    7.513262] EtherCAT 0: Using slave 0 as DC reference clock. [    8.700315] logitech-hidpp-device 0003:046D:1020.0005: HID++ 1.0 device connected. [    9.018640] e1000e 0000:00:19.0 eno1: NIC Link is Up 1000 Mbps Full Duplex, Flow Control: None [    9.018673] IPv6: ADDRCONF(NETDEV_CHANGE): eno1: link becomes ready [  185.482430] EtherCAT: Requesting master 0... [  185.482433] EtherCAT: Successfully requested master 0. [  185.482540] EtherCAT 0: Domain0: Logical address 0x00000000, 46 byte, expected working counter 3. [  185.482542] EtherCAT 0:   Datagram domain0-0-main: Logical offset 0x00000000, 46 byte, type LRW. [  185.482553] EtherCAT 0: Master thread exited. [  185.482554] EtherCAT 0: Starting EtherCAT-OP thread. [  190.204353] EtherCAT ERROR 0-1: Failed to set SAFEOP state, slave refused state change (PREOP + ERROR). [  190.205350] EtherCAT ERROR 0-1: AL status message 0x001D: "Invalid output configuration". [  190.207352] EtherCAT 0-1: Acknowledged state PREOP. [  190.215070] EtherCAT 0: Slave states on main device: PREOP, OP. linuxcnc@linuxcnc:~$ 
EK1100 goes into OP, but the servo stays in PREOP + ERROR with "Invalid output configuration" when LinuxCNC (via lcec) tries to move the system into OP. 

File Attachment:

File Name: ethercat-conf.xml
File Size:1.77 KB
  • tommylight
16 Nov 2025 15:37
Replied by tommylight on topic Sinker EDM machine based on diy pulse generator
I do not think monitoring voltage is of any use, monitoring current should be used.
The voltage will vary a lot during active time as it is current limited.
  • Aciera
16 Nov 2025 15:37
That 'relkins.c' is a bit more effort than I'm willing to put into it.

Maybe have a look at the rather extensive comments in the source code for matrixkins, there are examples no how to set the parameters:
github.com/LinuxCNC/linuxcnc/blob/master...ents/matrixkins.comp
  • tommylight
16 Nov 2025 15:33
Replied by tommylight on topic Why is there no BSDCNC?

That is the first ever GNOME GUI on some GNU Linux version on that document.
Also searching that document for windows or NT shows nothing.
  • mooser
16 Nov 2025 15:26
Strange
Checking the halui.mode inputs and the settings from the custom_postgui.HAL are showing up but the output states are not matching
Even when setting the halui inputs manually (using the halcmd) to "re-trip" them, the output states (is-teleop and is-joint) don't change looking either at the command line or in the HALshow within the program.
Setting those input values doesn't actually trigger the output change, something else must be happening when an MDI command happens that doesn't happen when I set the mode values.

More digging
  • andypugh
16 Nov 2025 15:14
Replied by andypugh on topic Why is there no BSDCNC?
I don't know where I heard about Windows NT, there isn't any mention of it here:
tsapps.nist.gov/publication/get_pdf.cfm?pub_id=821651
However the very first implementation described there seems to have run the GUI on a Windows PC.
  • EdWorks
16 Nov 2025 14:47
Parallel ports share much in common with GPIO pins so I wasn't sure. Thanks for the response and particularly the references.
  • PCW
16 Nov 2025 14:33
Replied by PCW on topic 7i96 with analog Spindle Servo
I think that should work with a couple conditions:

1. You must have a digital spindle enable signal because the spindle output will default to -5V
when LinuxCNC is not running or after a watchdog fault

2. You need to set the PWMgens offset mode "true" so that a 0 PWM value results in
a 50% duty cycle and therefore a 0V output
 
  • mooser
16 Nov 2025 14:30 - 16 Nov 2025 14:36
That's what I figured but I can't seem to get it to work.
I've tried
setp halui.mode.in-teleop 1 but that's an output so it errors as not writable
setp halui.mode.is-manual 1 but that's also an output so it errors as not writable

Tried
setp halui.mode.manual 1 doesn't seem to do anything
setp halui.mode.teleop 1 doesn't seem to do anything
setp halui.mode.enabled 1 No such pin error

Looking at the states when the program loads and I can't use the MPG
10  bit   IN          FALSE  halui.mode.auto
    10  bit   OUT         FALSE  halui.mode.is-auto
    10  bit   OUT          TRUE  halui.mode.is-joint
    10  bit   OUT          TRUE  halui.mode.is-manual
    10  bit   OUT         FALSE  halui.mode.is-mdi ==> MDI-mode
    10  bit   OUT         FALSE  halui.mode.is-teleop
    10  bit   IN          FALSE  halui.mode.joint
    10  bit   IN          FALSE  halui.mode.manual
    10  bit   IN          FALSE  halui.mode.mdi
    10  bit   IN           TRUE  halui.mode.teleop
 
and after I make some kind of MDI move

10  bit   IN          FALSE  halui.mode.auto
    10  bit   OUT         FALSE  halui.mode.is-auto
    10  bit   OUT         FALSE  halui.mode.is-joint
    10  bit   OUT          TRUE  halui.mode.is-manual
    10  bit   OUT         FALSE  halui.mode.is-mdi ==> MDI-mode
    10  bit   OUT          TRUE  halui.mode.is-teleop
    10  bit   IN          FALSE  halui.mode.joint
    10  bit   IN           TRUE  halui.mode.manual
    10  bit   IN          FALSE  halui.mode.mdi
    10  bit   IN           TRUE  halui.mode.teleop


I see that the halui.mode.is-joint went from true to false. And probable a coincidence but the last thing I did was to get the MPG to work AFTER a MDI move I also changed the references for the MPG from joints(from a previous setup I did years ago)  to axis references.
Guess I'll try setting that to false as well and see what happens

Thanks for the help.
M
 
  • abs32
16 Nov 2025 14:22 - 16 Nov 2025 14:26
Thank you, however, this is not necessary. If you already have a Matrixkins component built into the LinuxCNC kernel, then you need to use it. According to the description, it is quite suitable. The main thing is to understand the configuration synatxis for hal.
According to the description, the component built into the kernel solves issues of three axes at once. Simple (linear), but closes.

I don’t have the realkins component itself. The forum where this component was published has already died. The module is here. That's exactly what's holding me up on version 2.8.4
  • Aciera
16 Nov 2025 13:42
If you attach the code of your current 'relkins' component I can have a look at updating it to be used in version 2.9
  • juergen-home
16 Nov 2025 13:20
TWOPASS was already on.
  • abs32
16 Nov 2025 13:11 - 16 Nov 2025 13:15
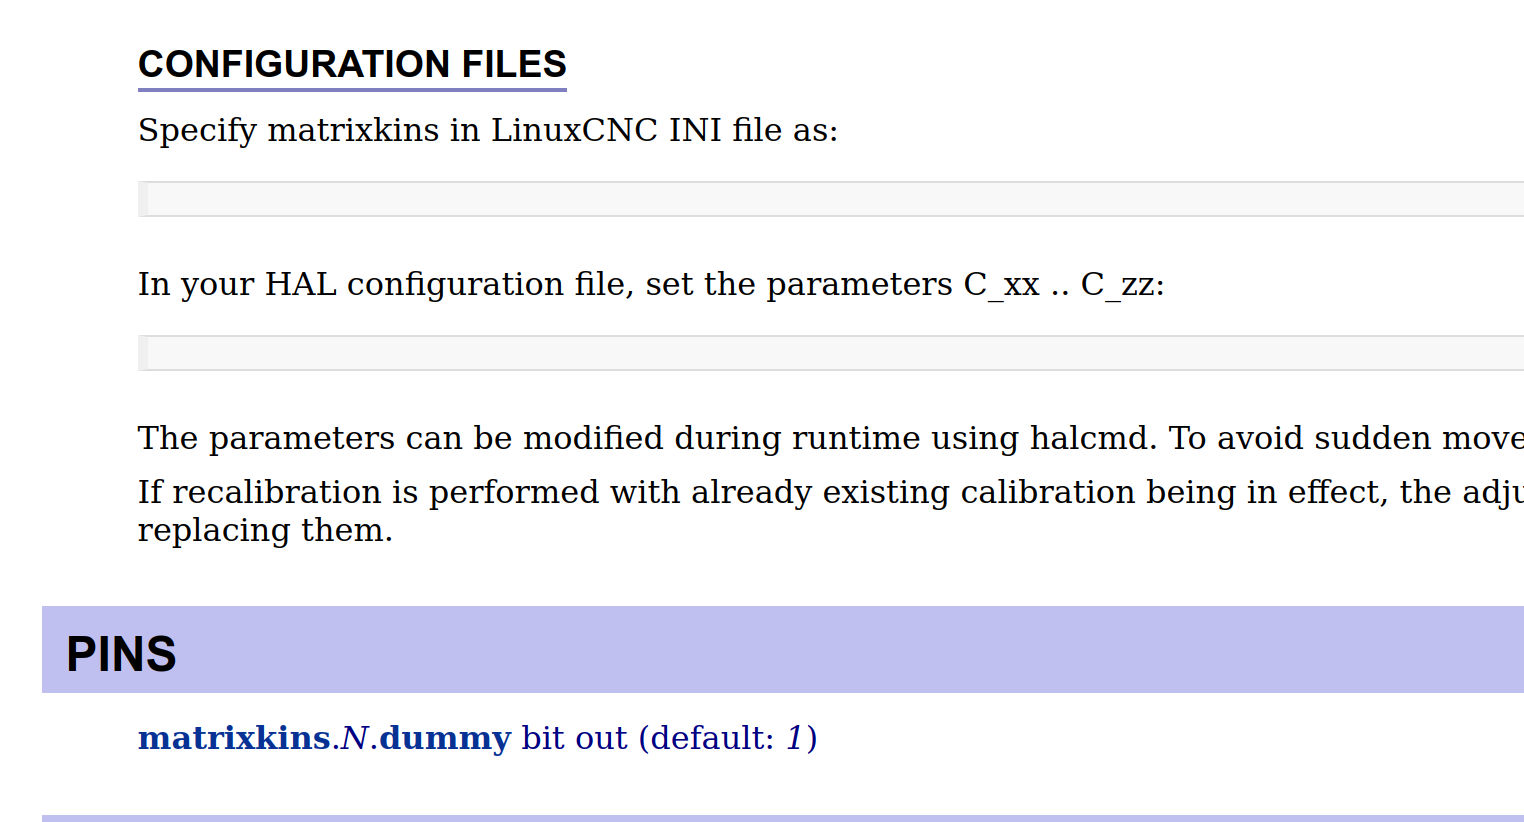
From the description at the link I see the following alorhythm -

1. I know the amount of deviation
2. in the case of XU, I need to explicitly specify the parameter for the formula -
X_joint = C_xx * X_axis + C_xy * Y_axis + C_xz * Z_axis

Those. I know the coefficient from clause 1
C_xx = 1
C_xy = (deviation X divided by width Y)

But what are the rules of use, syntax, examples?

loadrt matrixkins count=0
C_xx = 1
C_xy = 0.03
or
C_xy = [3/100]

or otherwise?
how to change the C_xy parameter on the fly without rebooting the program?
if loading a component requires specifying the contact number count=N, then N is what, what are the options? And where should this count be specified in the C_xy job?

In general, we need examples of syntax and application
In man, the example section of the configuration file shines with emptiness
Displaying 11236 - 11250 out of 11917 results.
Time to create page: 0.446 seconds
Powered by Kunena Forum
