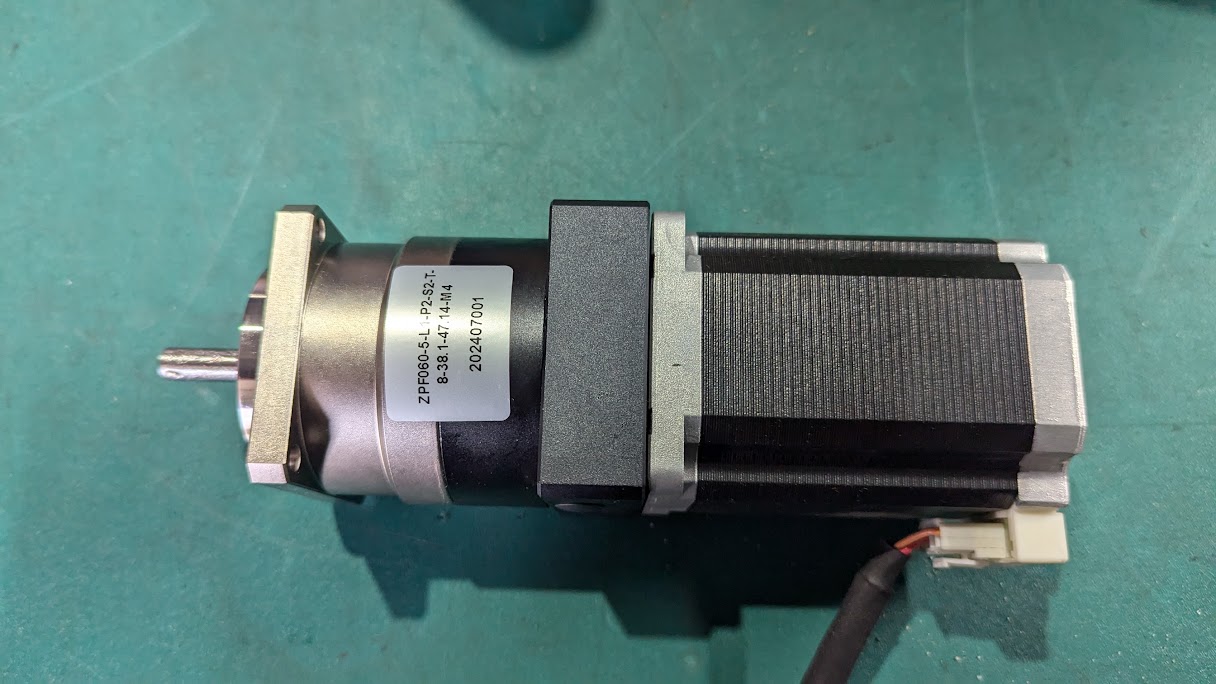
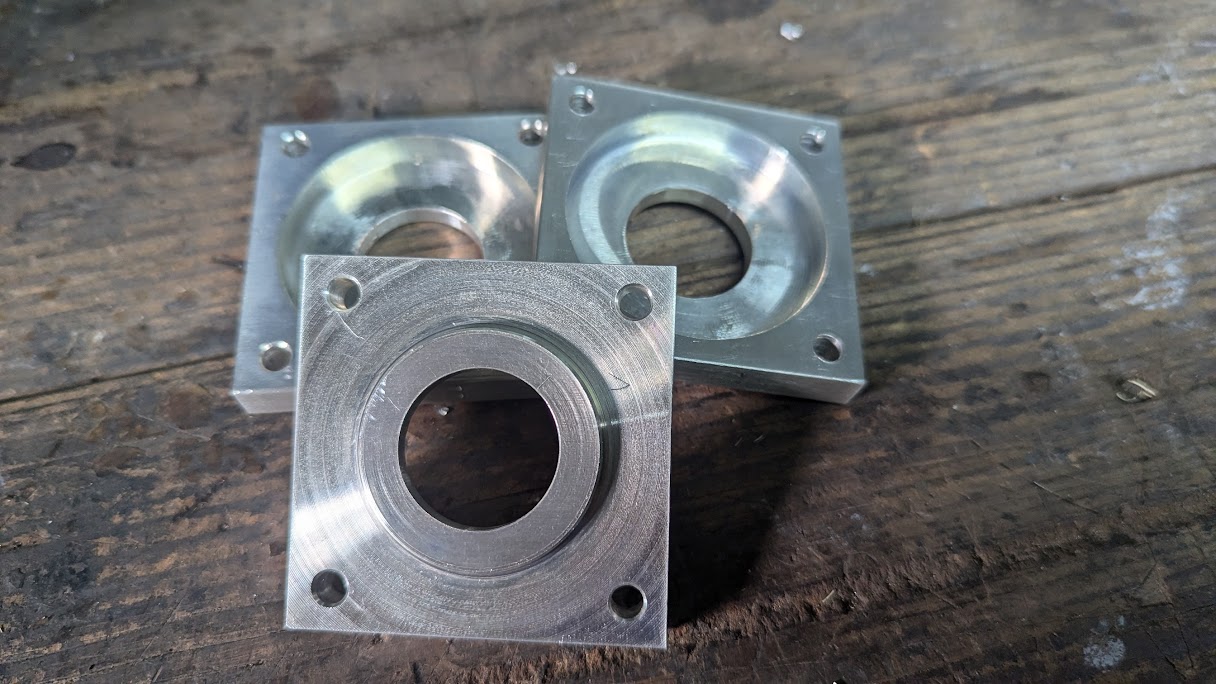
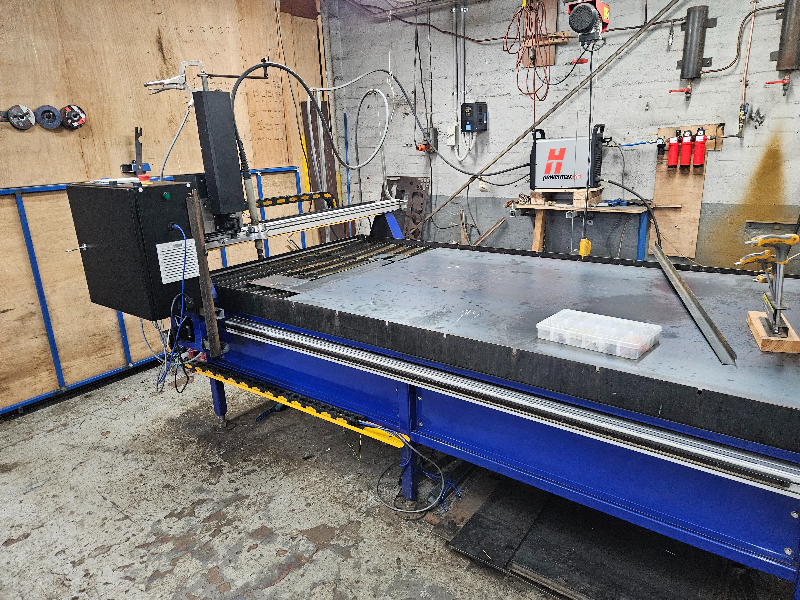
To get the gearboxes to mount up, we had to machine up some adapter plates because the gearbox 7mm long flange would not fit.
So the compination of near quadrupling the voltage and a significant gear reduction really gave the machine a lift in performance.
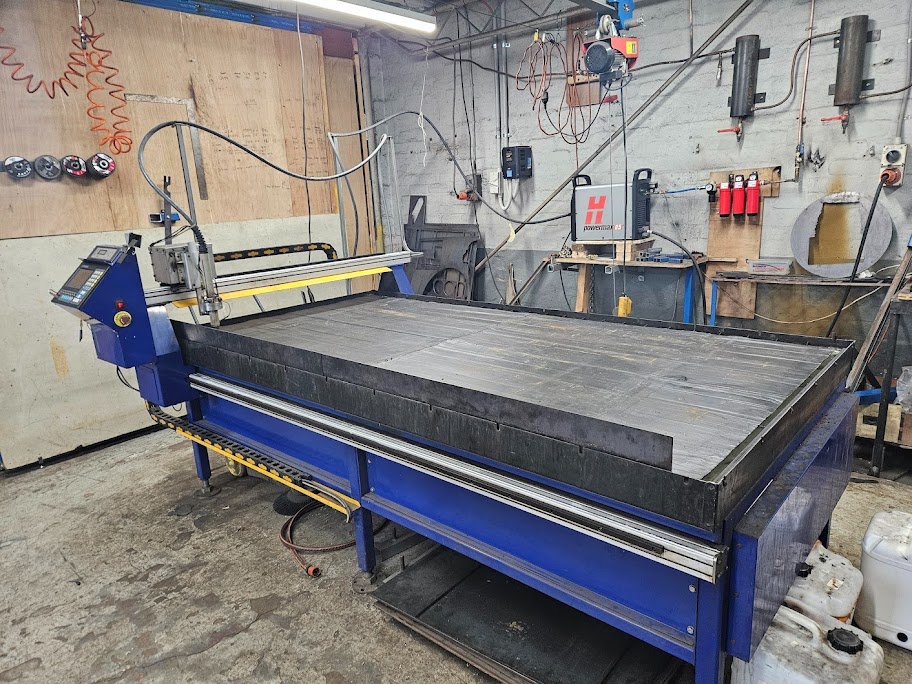
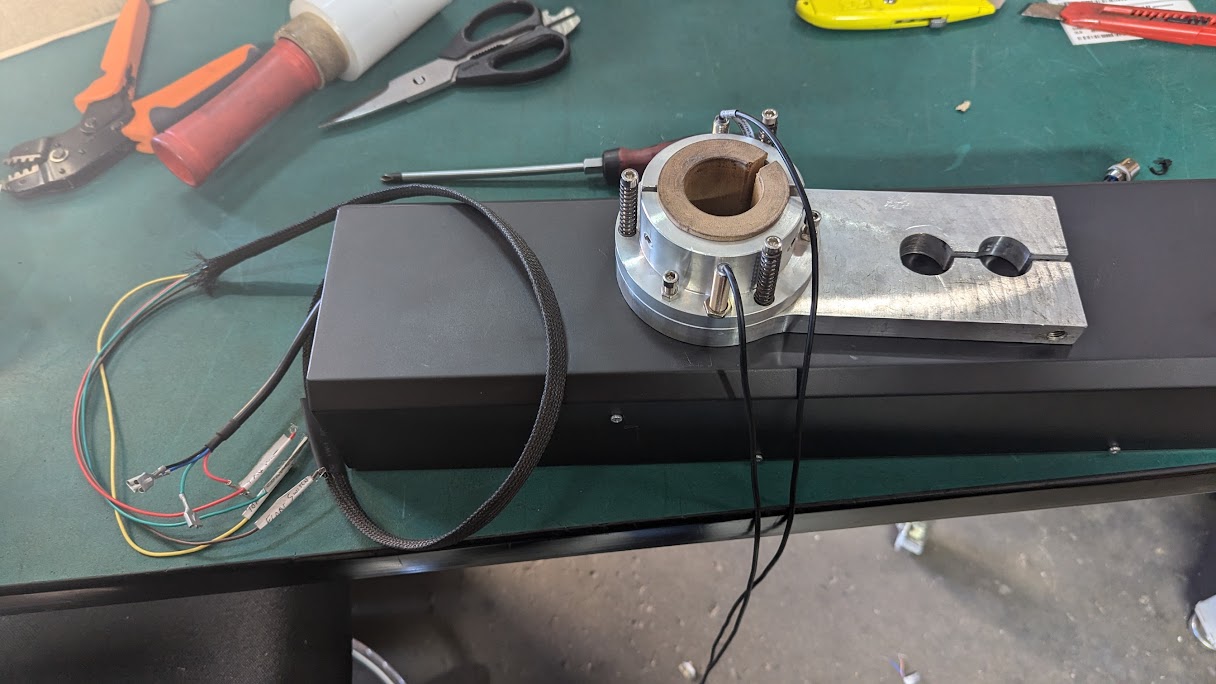
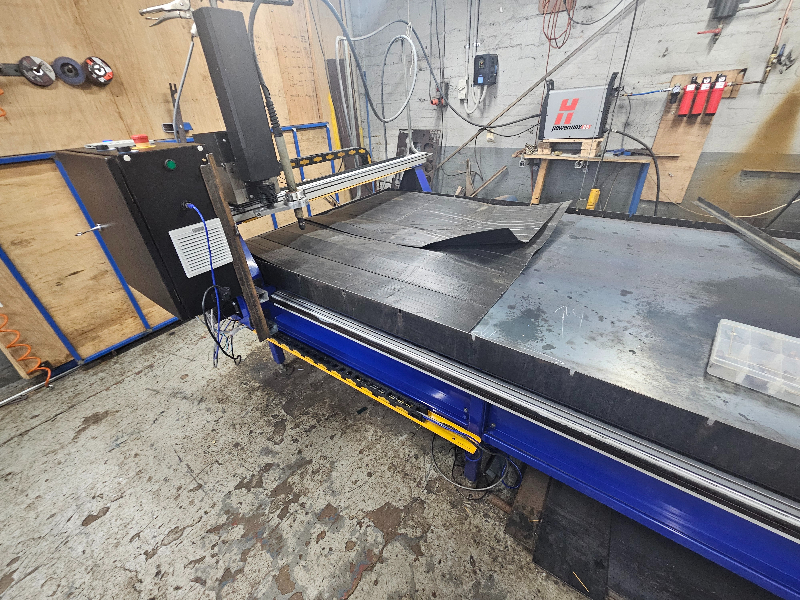
The plasma had a 24 volt motor driving the z axis lifter so we replaced that with a stepper driven torch lifter with 200 mm of travel
I was annoyed originally about this because despite being assured it would be stepper driven, it had a geared motor. All was not lost as they had spot drilled the mounting plate to take a NEMA23 motor. This has a break away mount and a float switch built in and a bit of tewiring was tequired.
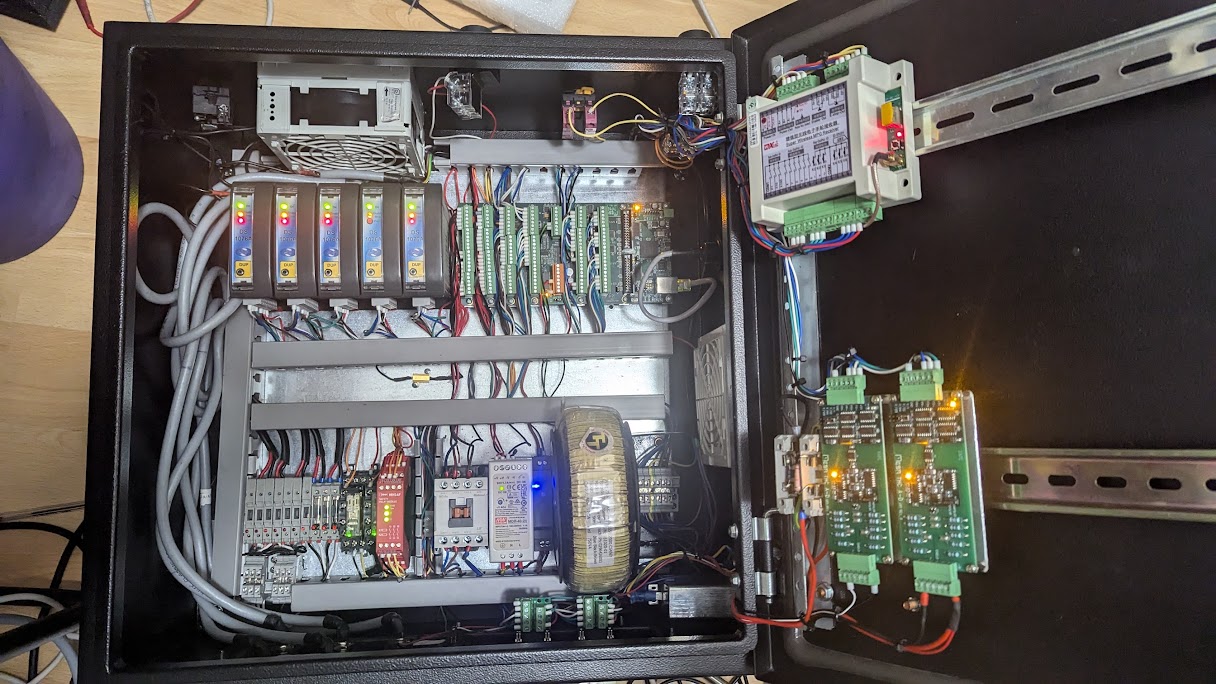
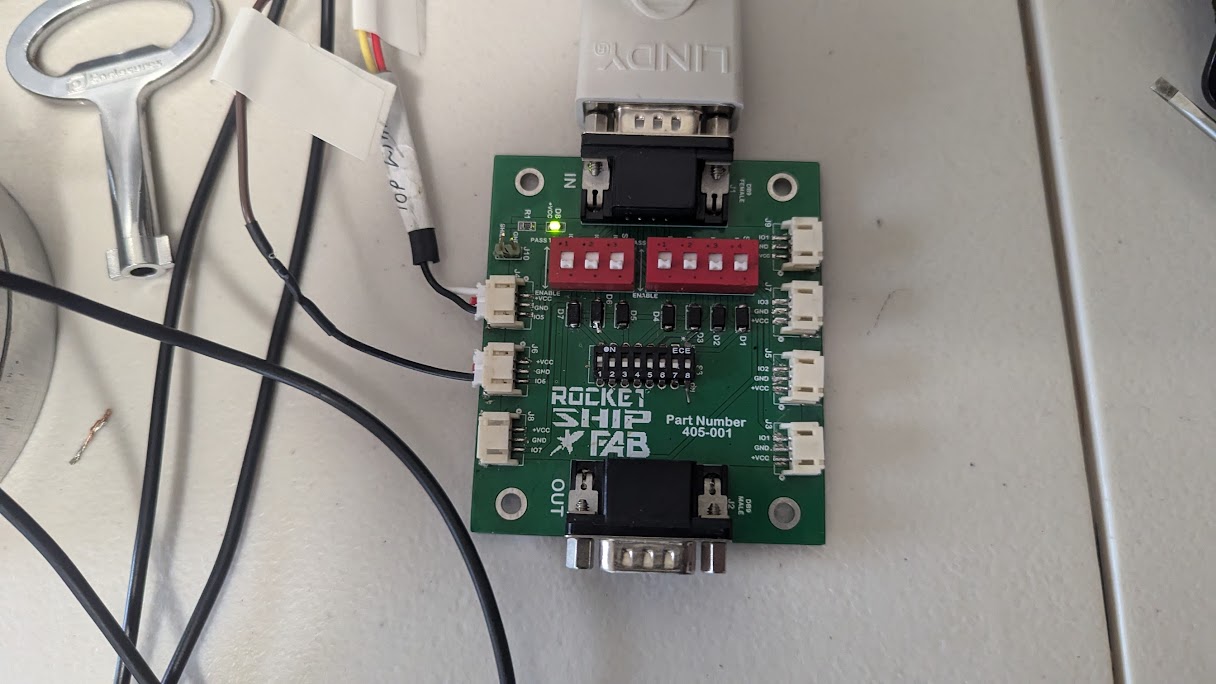
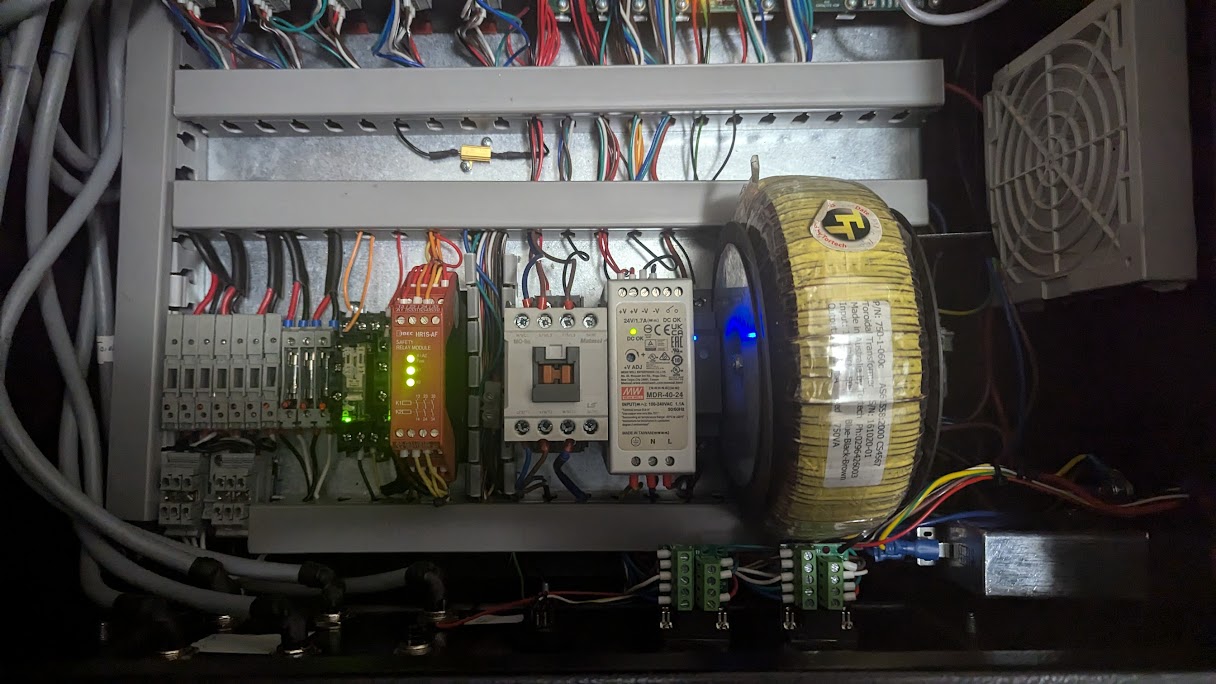
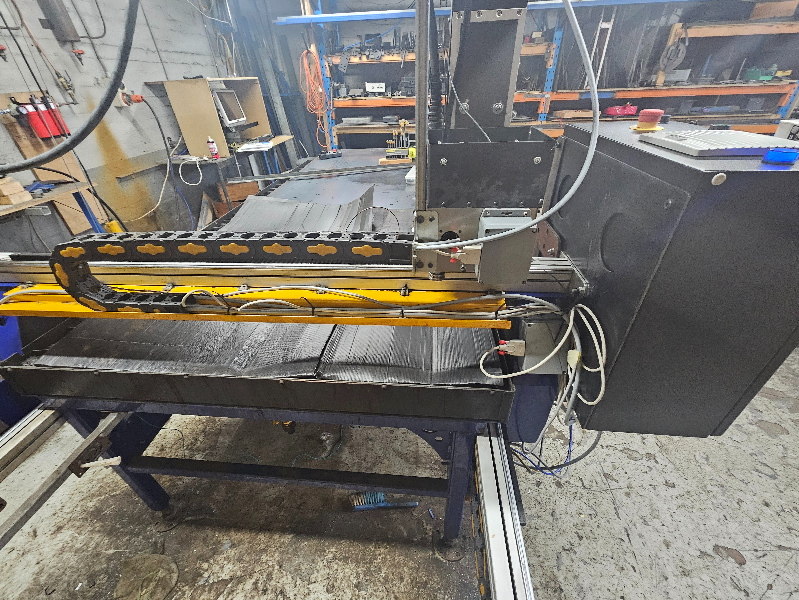
To wire everything up, we used two little breakout boards I made a long time ago so we could use a couple of DB9 cables to wire it up.
Thes can be daisy chained together and support proximity sensors, switched inputs and ooutputs (with flyback diodes built in)
If anybody is interested in these, please let me know, I was thinking of getting a batch made.
The only problem is the connectors are very hard to crimp on (for me) so I sourced some tails that I could join onto the prox sensors.