PID Setting for drifting axis

More
9 years 11 months ago #82369 by Chre9
Hey guys,
a colleague and I are currently repairing a milling machine ("Heller CNC PFH 10-1000"). We are using LinuxCNC 2.7.7 and the engines are controled by MESA Cards (5i20, 7i37 TA, 7i48) with a svst6_6_7i48 firmware.
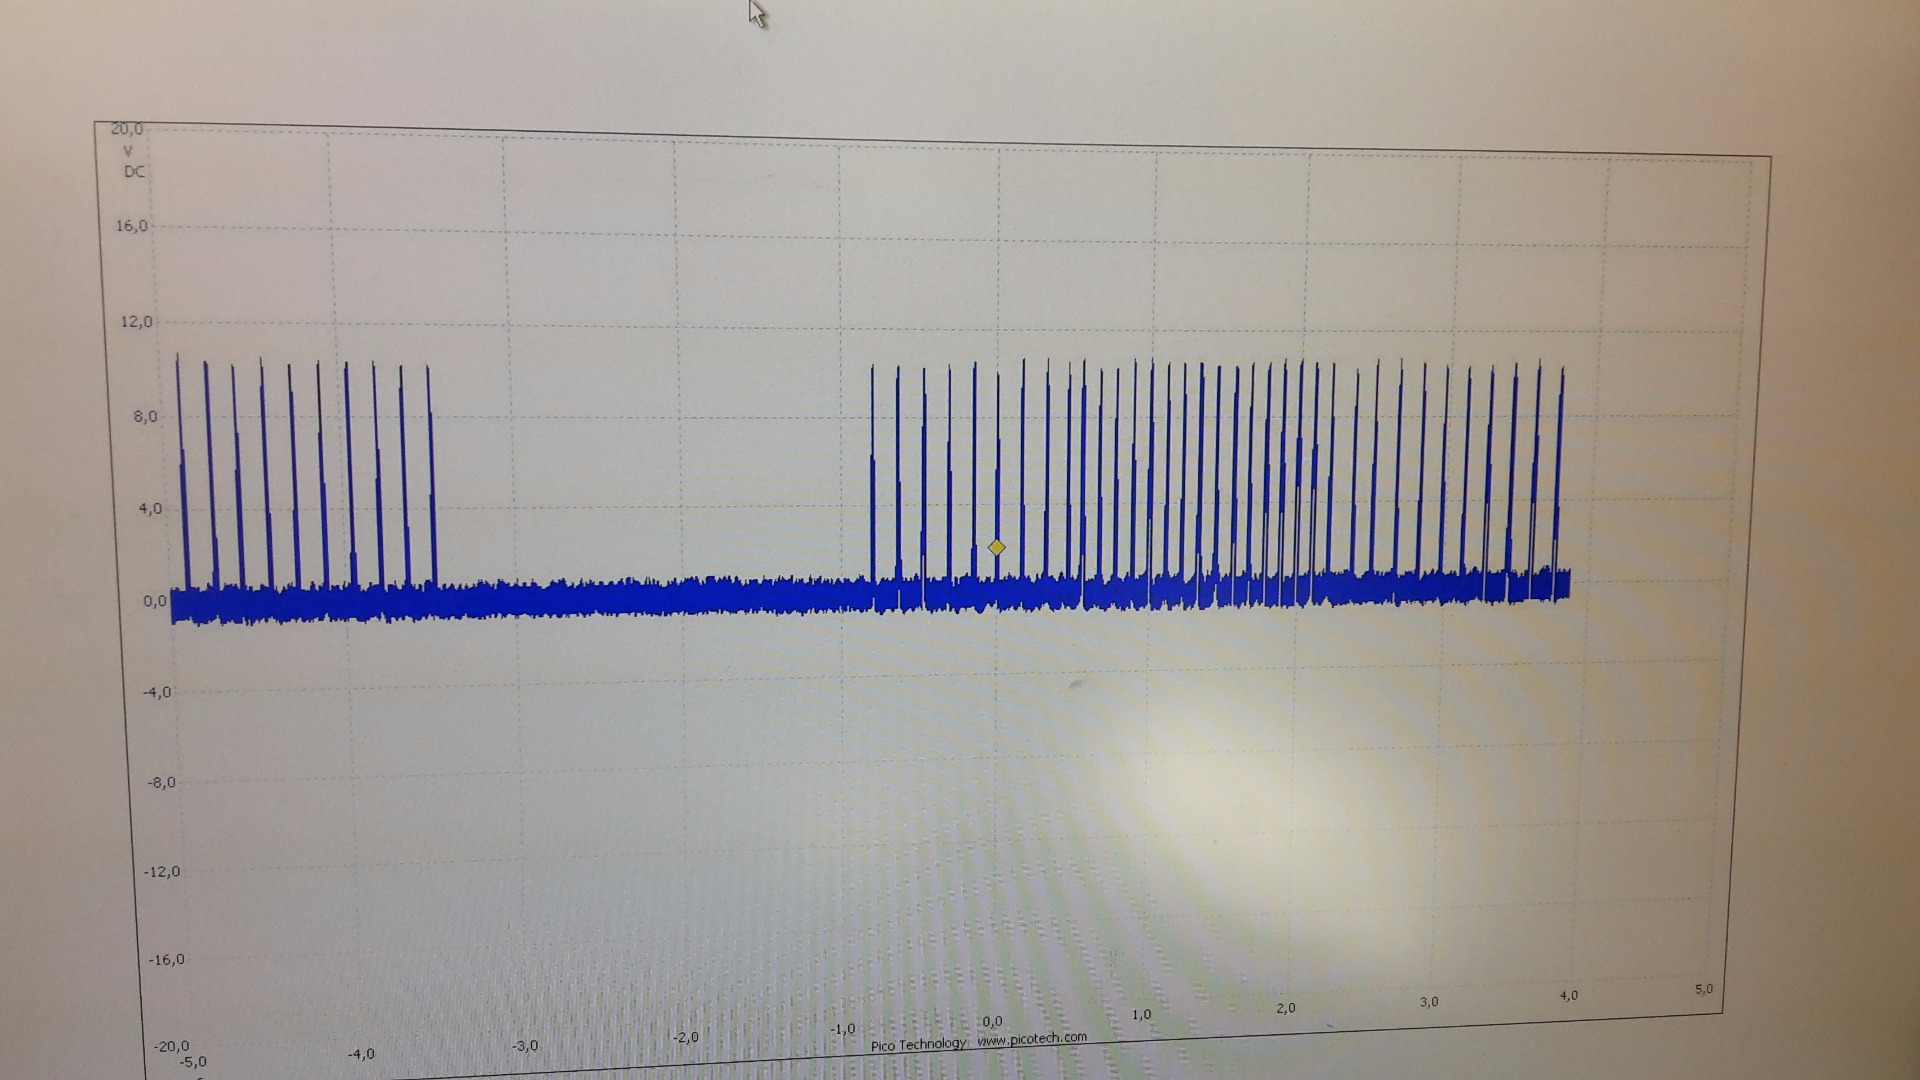
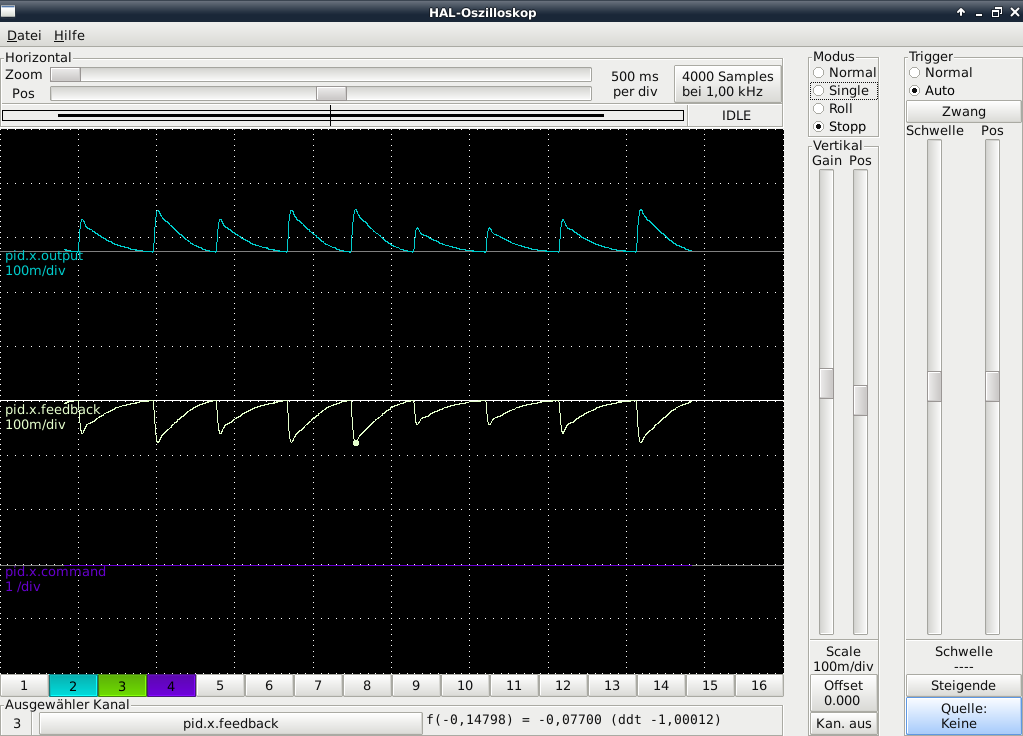
The problem we are facing is, that LinuxCNC tries to compensate the drifting of the x- and y-axis with lots of short peaks of voltage in the output, so the machine starts to cog while holding its position or moving against the drifting direction. Moving the axis in drifting direction in not a problem. You can see the voltage output signal in the attached picture.


We have been trying to figure out the correct PID values to fix this, but couldn't really. So we would appreciate your help. If you have problems understanding or need further information, please ask.

Thanks in advance!

Please Log in or Create an account to join the conversation.
More
9 years 11 months ago #82372 by andypugh
How much I-Gain do you have relative to P-Gain?

Please Log in or Create an account to join the conversation.
More
9 years 11 months ago #82375 by PCW
Replied by PCW on topic PID Setting for drifting axis
Also do you have the PWM gens output mode set to 2?

( This is required by the 7I48 and you will have bizarre behaviour if they are not set to mode 2 )

Please Log in or Create an account to join the conversation.
More
9 years 11 months ago #82531 by Chre9
Replied by Chre9 on topic PID Setting for drifting axis
Hey guys, thanks for your reply!

Yes, we are already using output mode 2. Before that it was a huge mess.
The best results we could get were including P=1,5 and I=0,75.
This way the cogging is not so hard, but it still doesn't prevent it.

Please Log in or Create an account to join the conversation.
More
9 years 11 months ago #82545 by PCW
Replied by PCW on topic PID Setting for drifting axis
Do the axis move smoothly both ways open loop? say with 100 mV/-100 mV of analog signal
(that is, is this possibly a drive issue?)

Can you send any output voltage open loop (via setp) (try +5 and -5)
(that is is this a hardware interface problem)

Does the encoder read accurately?

A 10V output with a P gain of 1.5 means an error of 6.66 mm (assuming mm)
is this much error really present?
(In addition I should almost always be 0 when doing initial tuning )

Halscope plots of the PID output value, commanded and feedback position would be helpful

Also posting the HAL and INI files may help

Please Log in or Create an account to join the conversation.
More
9 years 11 months ago - 9 years 11 months ago #82587 by Chre9
Replied by Chre9 on topic PID Setting for drifting axis
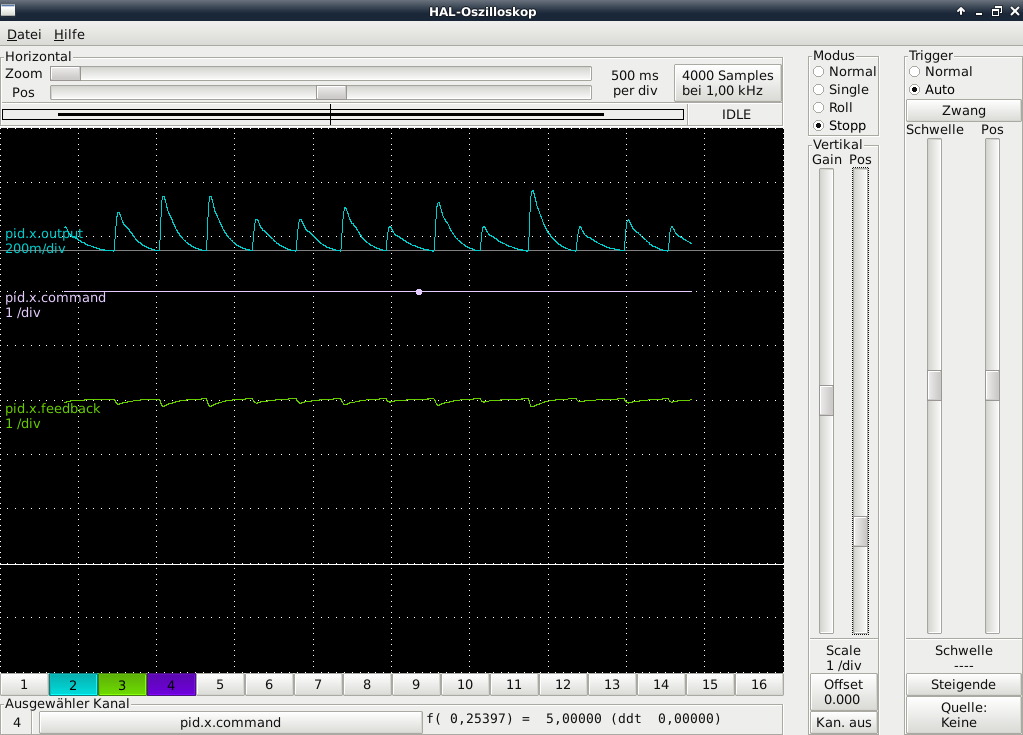
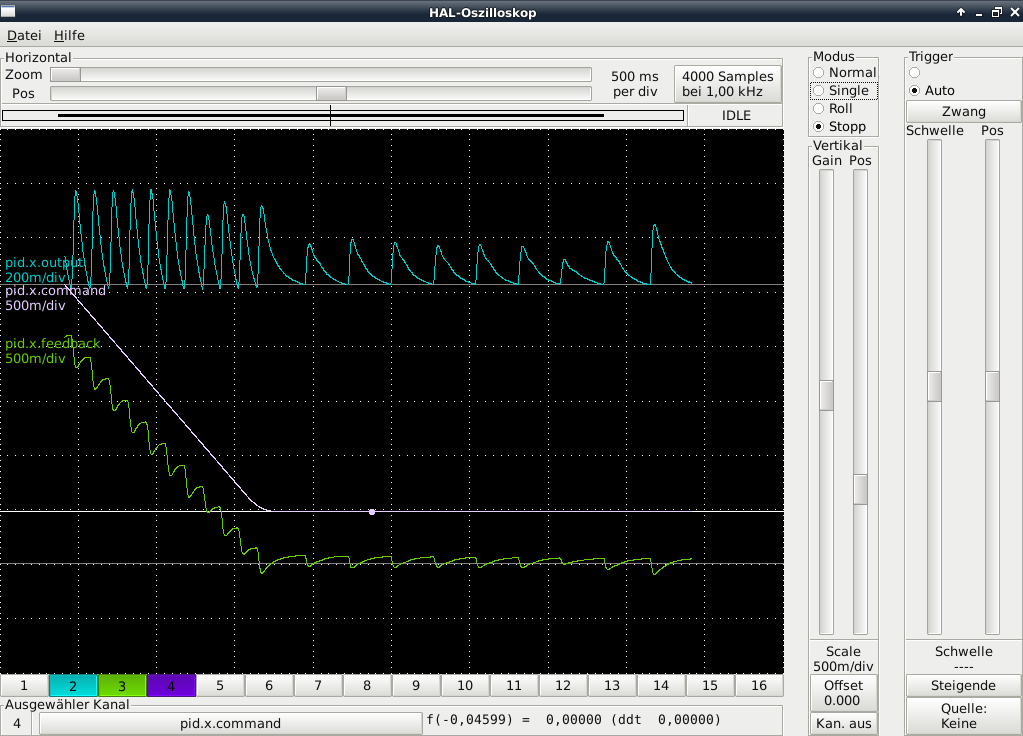
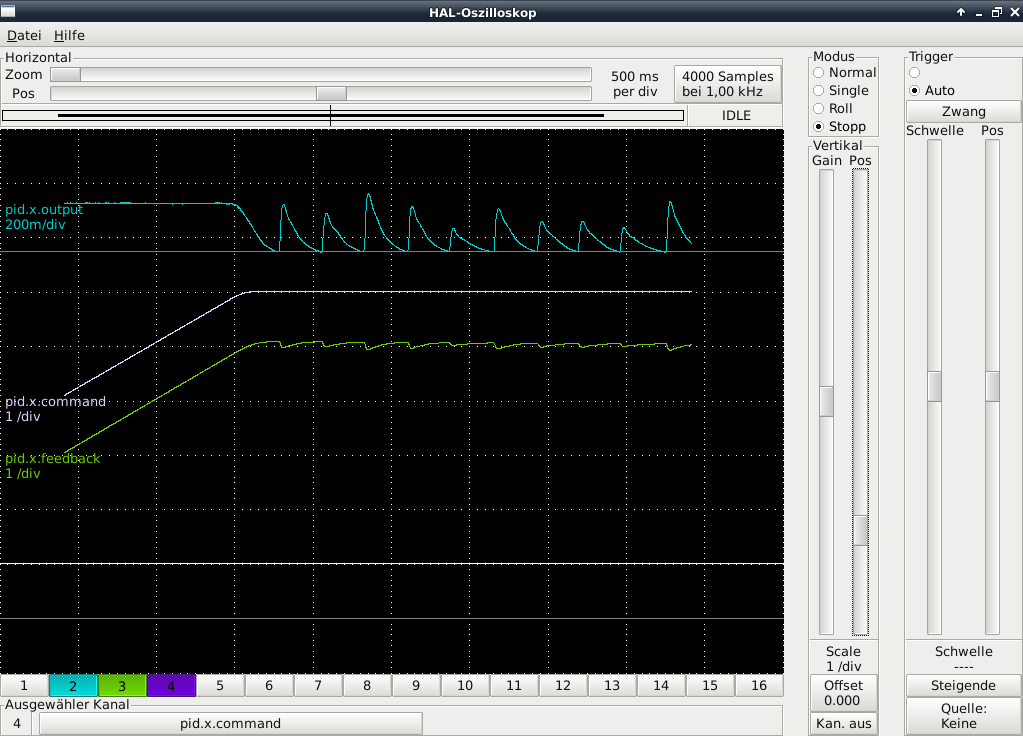
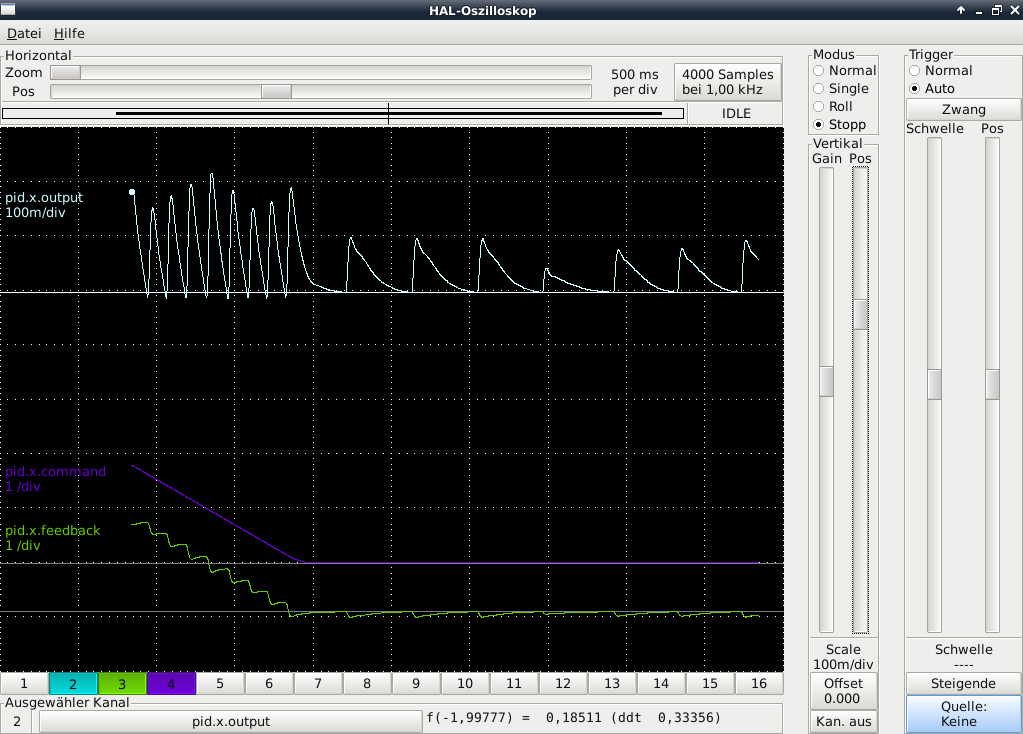
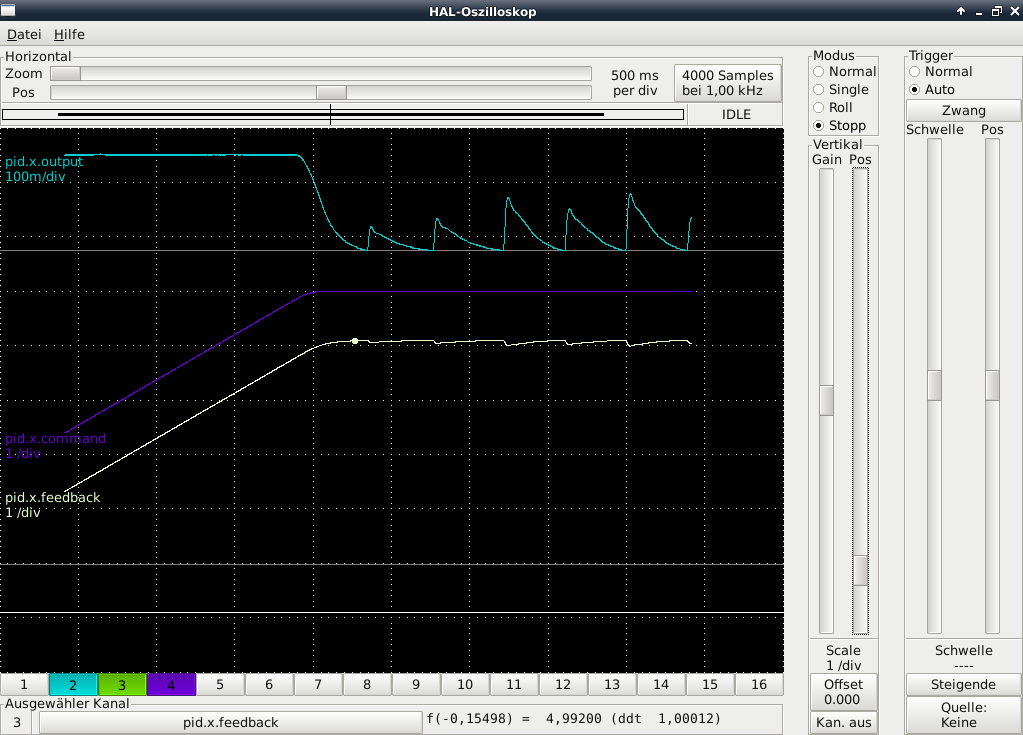
We just recorded the PID output value, commanded and feedback position of the x-axis with halscope while moving in each direction and staying in the same position. First with P=1,5 and I=0,75:


And with P=1 and I=0:


The y and z axes show the same behaviour.
Last edit: 9 years 11 months ago by Chre9.

Please Log in or Create an account to join the conversation.
Time to create page: 0.470 seconds
Powered by Kunena Forum