- Posts: 14
- Thank you received: 5


Please Log in or Create an account to join the conversation.
correctNever the less - I believe I have correctly ascertained the math necessary to compute the left and right drum rotation (from home position of 0,0) to achieve a desired X,Y location for the truncation of the two cables. I believe these are inverse kinematics, correct?
hal pins are used to connect signals in the hal layer. If your kinematic does do not need real time information from hal (eg tool length) then you do not need to add any pins.I honestly don't really understand what a hal pin is and whether these are required. I'm running my code on a Raspberry pi if it matters.
I believe in your case the forward kinematic is only used until the machine is homed. (ie to calculate the initial XY position) But I might be wrong about that.I don't have any feedback in my device so what does LinuxCNC do with the Forward kinematics?
That is correct, for HOME = (0,0) and provided you have not built any offsets into your model (eg a tool-offset)My inverse kinematics routine computes the drum rotations FROM HOME to a desired X,Y. Is this correct?
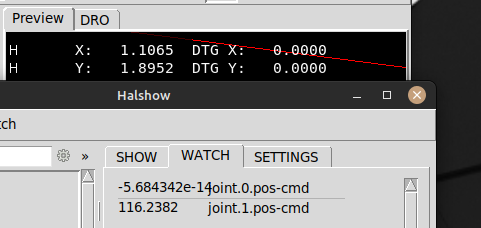
So what is the error you are getting?My CableKins.comp file is attached. I'm basically breaking out of the forward kinematics since that was erroring out but I'm not getting expected results. If you see any glaring issues I'd appreciate any guidance.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
That is what I _think_ is happening but I'm not positive. If you home your machine manually I wonder if you could simply set the cartesian position to zero in your forward kinematics:Is it a correct assumption that the forward transformation is only called when homing the machine - and beyond that is not referenced?
Please Log in or Create an account to join the conversation.


