- Posts: 200
- Thank you received: 10


Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
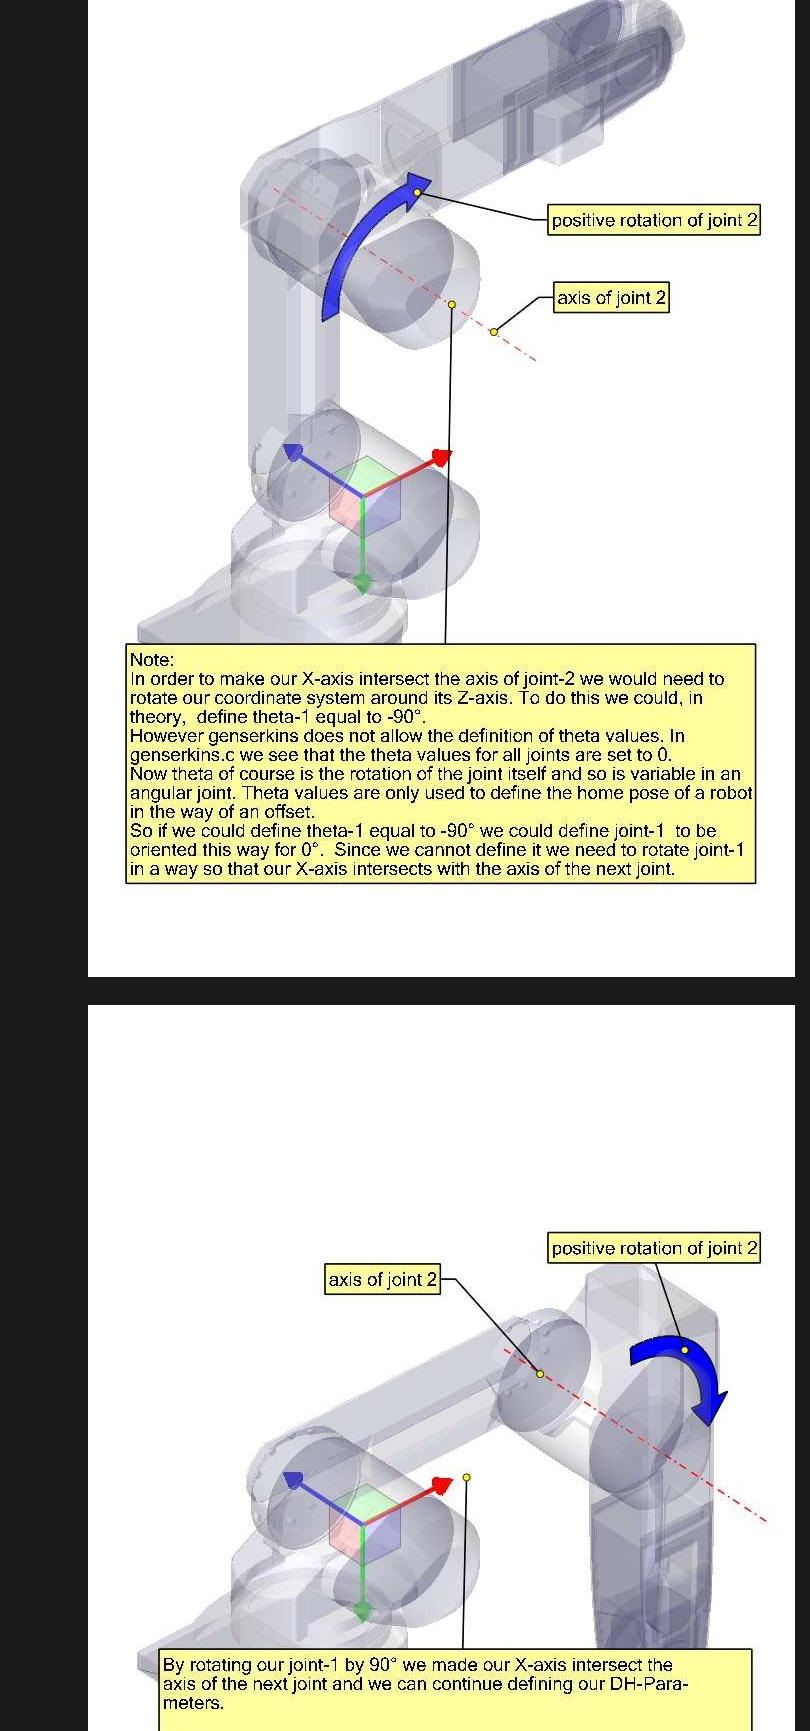
So the joint axis limits in this case are relative the arm posture defined by the modified DH parameters?Aciera post=312133 userid=25994You don't _need_ it, those are simply used to define the pose for (x,y,z,a,b,c)=(0,0,0,0,0,0).
[edit]
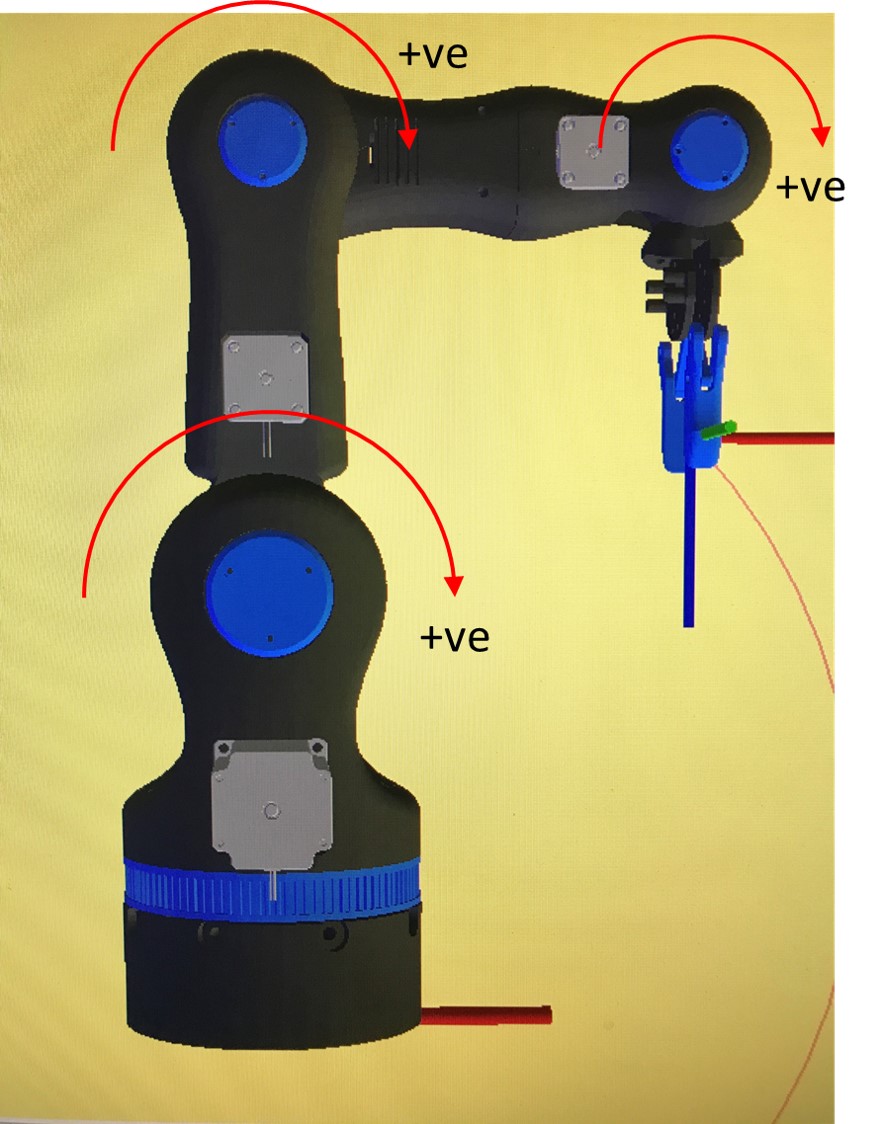
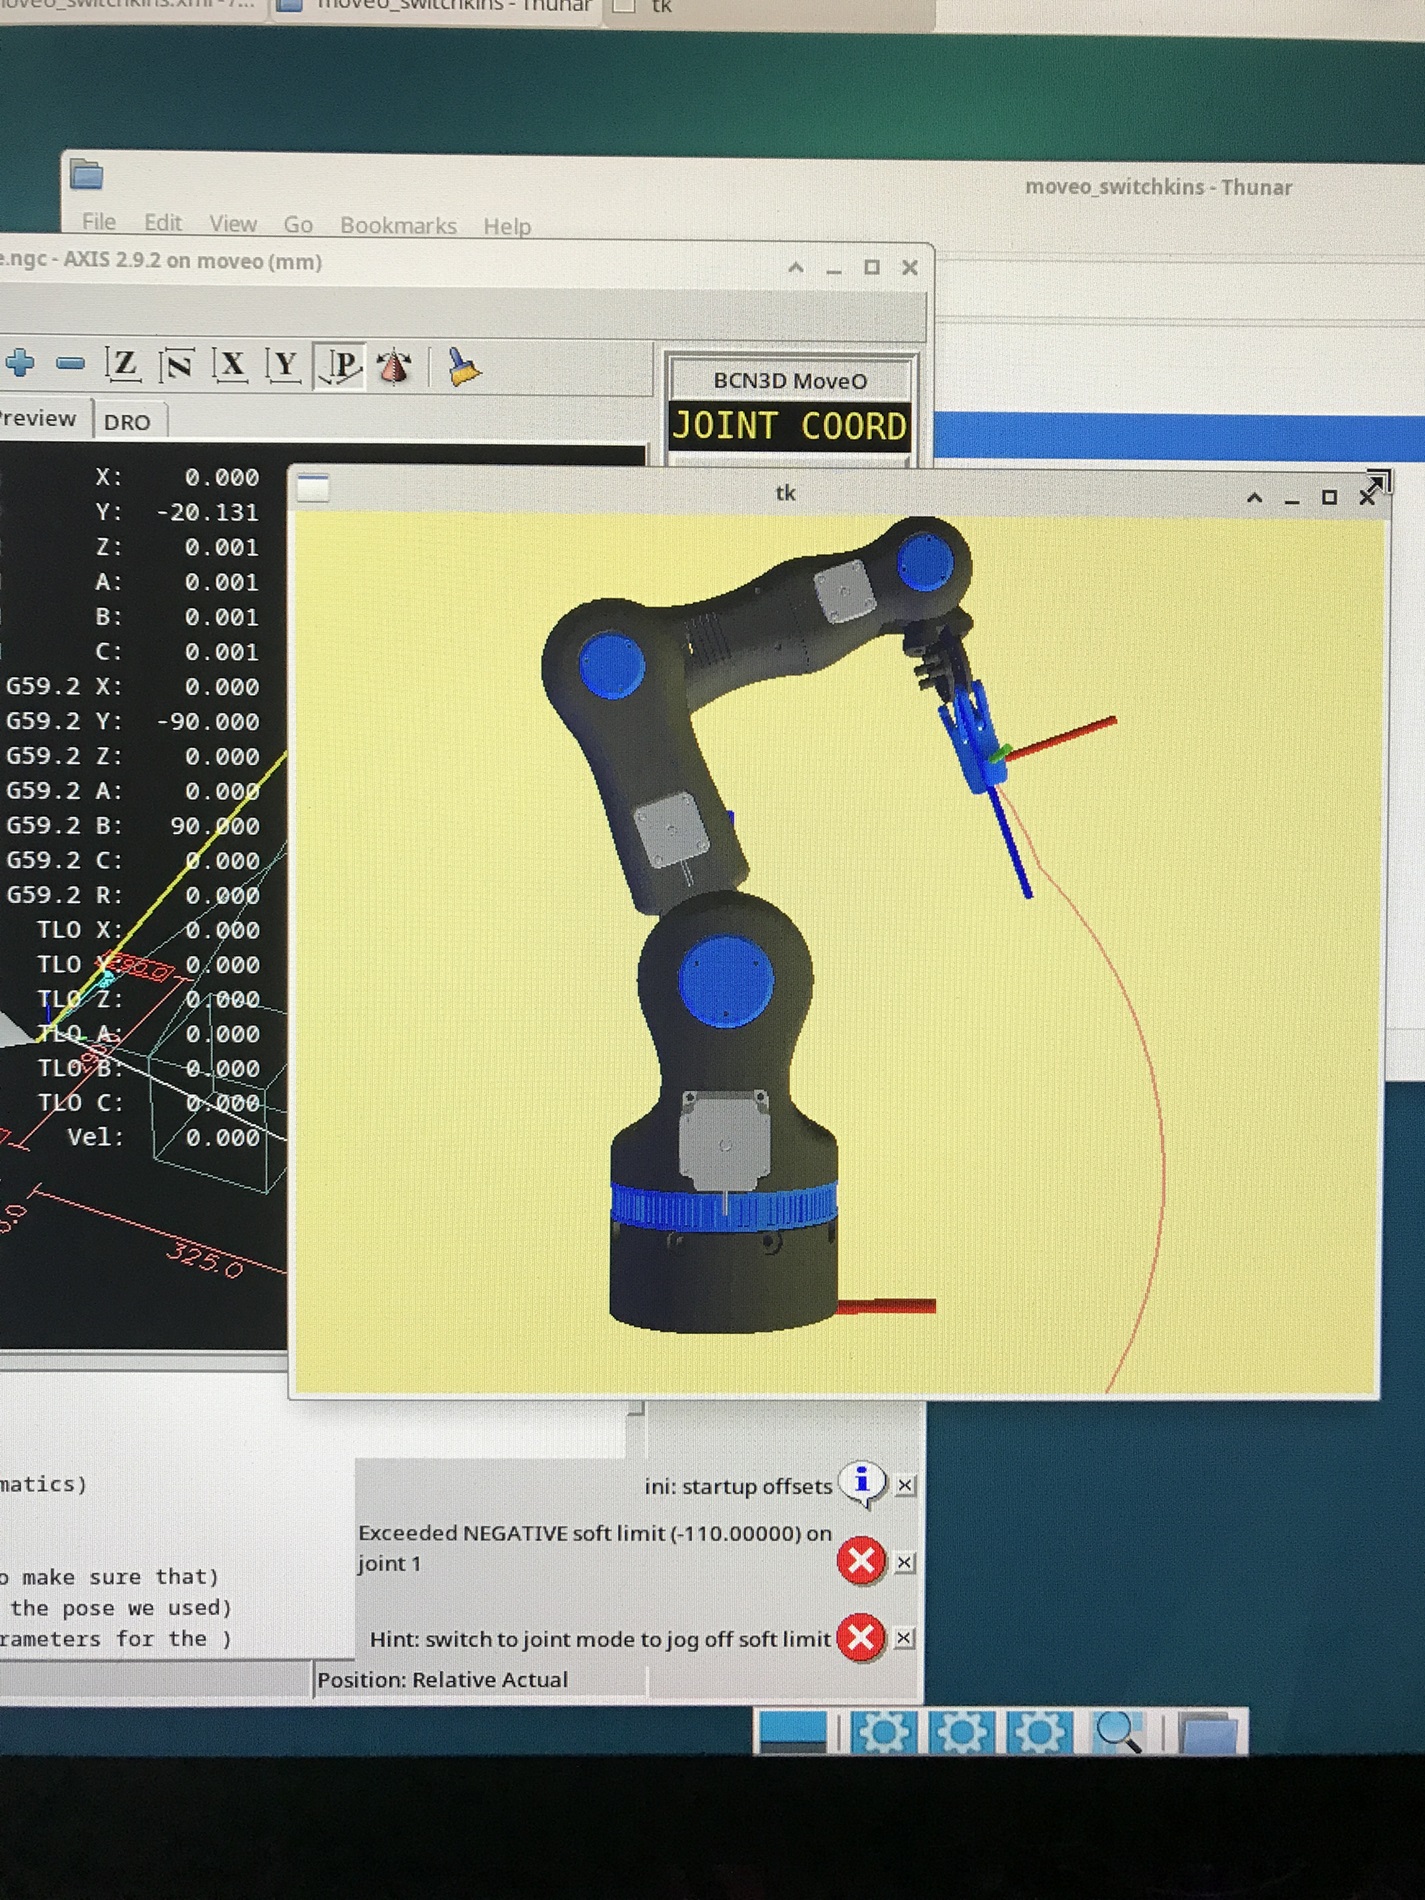
Actually I just noticed that you are not getting an 'axis' limit error but a 'joint' limit error. So the issue is that you have to adjust your 'MIN_LIMIT' , 'MAX_LIMIT' values in the [JOINT_1] section of your ini file. Note that joint1=0 has the upper arm in the horizontal forward pose as that is what is used in the genserkins model so you may need to adjust the limit values accordingly.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
