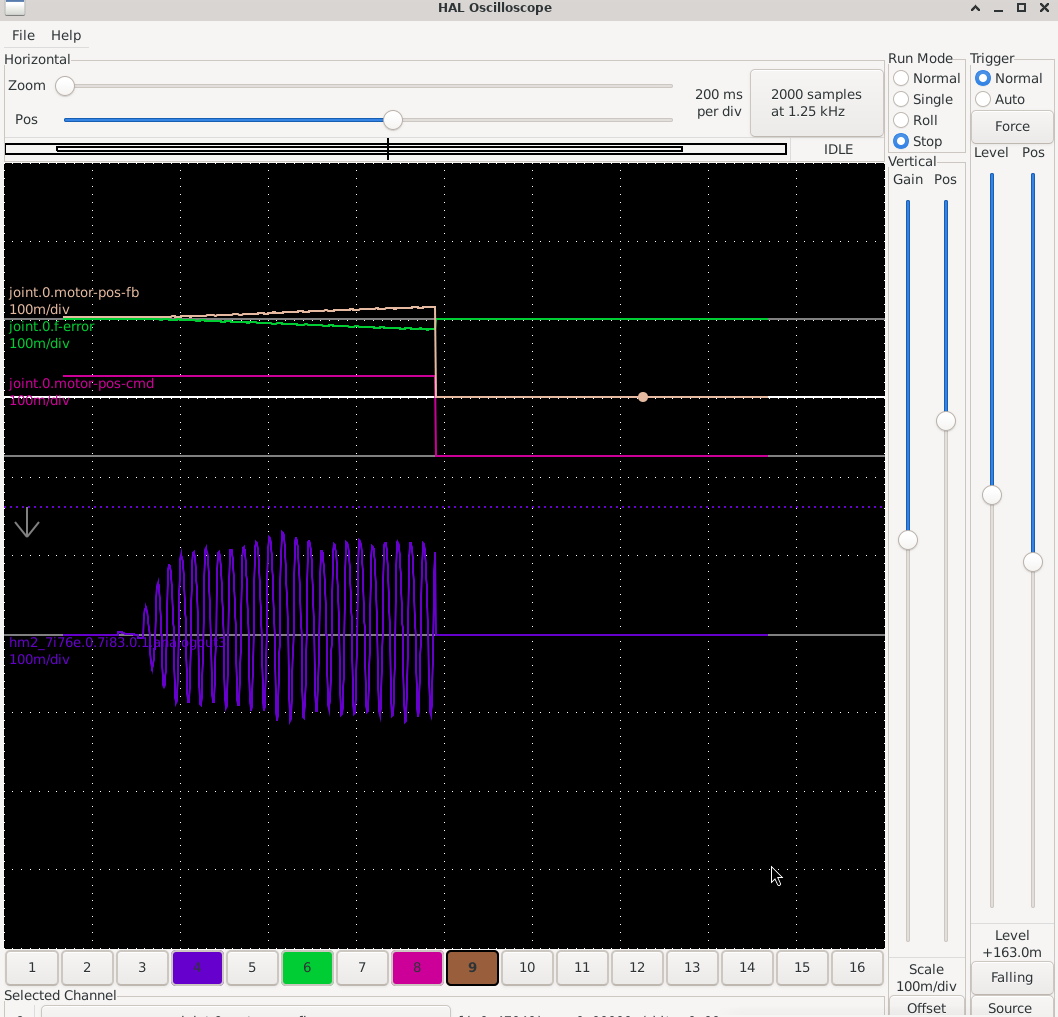
I’m working on a retrofit and I’m having trouble with oscillation on an analog velocity-controlled axis using existing Fanuc DC motors and drives.I have a Mesa 7i77EU for the FPGA, 7i85 for the encoders, and 7i83 for the analog outputs. I am using two outputs for each drive. one for a velocity command and one for a virtual tachometer. This is similar to how the original Fanuc controller was doing it.Current status:
- I have the analog outputs scaled correctly as far as I can tell. I measured the voltages going to the drive and they match the drive specs. 7V/2000RPM for velocity and 3V/1000RPM for the tachometer signal.
- With the velocity command wires disconnected from the drive, the system appears stable. The motor holds position well and resists manual twisting of the shaft.
- As soon as I connect the analog command wires to the drive, the axis begins oscillating even when all PID values are set to 0.(I was expecting this to act the same as when the wires were disconnected. The motor oscillates and drifts until i get a following error.
- Increasing the PID P gain to about 0.5 prevents the following error, but the oscillation is still present.
Does anyone have any suggestions on why the drive would be stable without the velocity command wires hooked up but unstable with them connected even with no movements?Any suggestions on where to start troubleshooting would be appreciated.