
- Posts: 51
- Thank you received: 10
Anilam Crusader linear scales
- spangledboy
- Offline
- Senior Member
-

Less
More
10 years 10 months ago #66863
by spangledboy
Yes, I concur - I was surprised at how sensitive the tachometers were to movement - putting a volt meter on them showed that they output at very slow rotational velocity. Connecting them to the replacement AMC drives made sense.
I just improved my machines accuracy significantly by examining the ball screw thrust bearings - there was a lot of play which played havoc when cutting forces increased (working in steel rather than aluminium).
Replied by spangledboy on topic Anilam Crusader linear scales
Todd Zuercher wrote: The secret is the tackos. Their analog velocity feed back is actually better than you can get with with a digital encoder. And since the drives and tachometers handle the velocity loop, the low count of the scales is less of an issue, but please remember that you will still need to temper your expectations. Accuracy will likely not be better than 2 or 3 encoder counts with at least some dither.
Yes, I concur - I was surprised at how sensitive the tachometers were to movement - putting a volt meter on them showed that they output at very slow rotational velocity. Connecting them to the replacement AMC drives made sense.
I just improved my machines accuracy significantly by examining the ball screw thrust bearings - there was a lot of play which played havoc when cutting forces increased (working in steel rather than aluminium).
Please Log in or Create an account to join the conversation.
- 5axisormore
- Offline
- New Member
-

Less
More
- Posts: 17
- Thank you received: 2
10 years 10 months ago #66945
by 5axisormore
Replied by 5axisormore on topic Anilam Crusader linear scales
Which AMC drives did you use. I have the Glentek drives on mine and was thinking about switching to something later as well. I have AR5 scales from the look of things on a Crusader II, Pre RS232 control.
Fred
Fred
Please Log in or Create an account to join the conversation.
- joekline9
- Offline
- Senior Member
-
Less
More
- Posts: 59
- Thank you received: 9
10 years 10 months ago #67164
by joekline9
Replied by joekline9 on topic Anilam Crusader linear scales
I ditched the Glenteks and use AMC 20a14. I kept the tack feedback and used the original Anilam glass scales (.01mm res. Approx .004 inch)
I could not get the servos to completely stop. They had a very slow drift do to no dead zone in the amps. It was very usable but I wanted it better.
I have recently added U.S. Digital rotary encoders to get higher res. I made adapters for the SEM servo motors so I could keep the tacks.
I bored a relief in the back of the encoder base to clear the tack armature. My SEM motors have a 5mm shaft extending past the tack.
Encoders: U.S. Digital E5-500-197-D-D-G-B
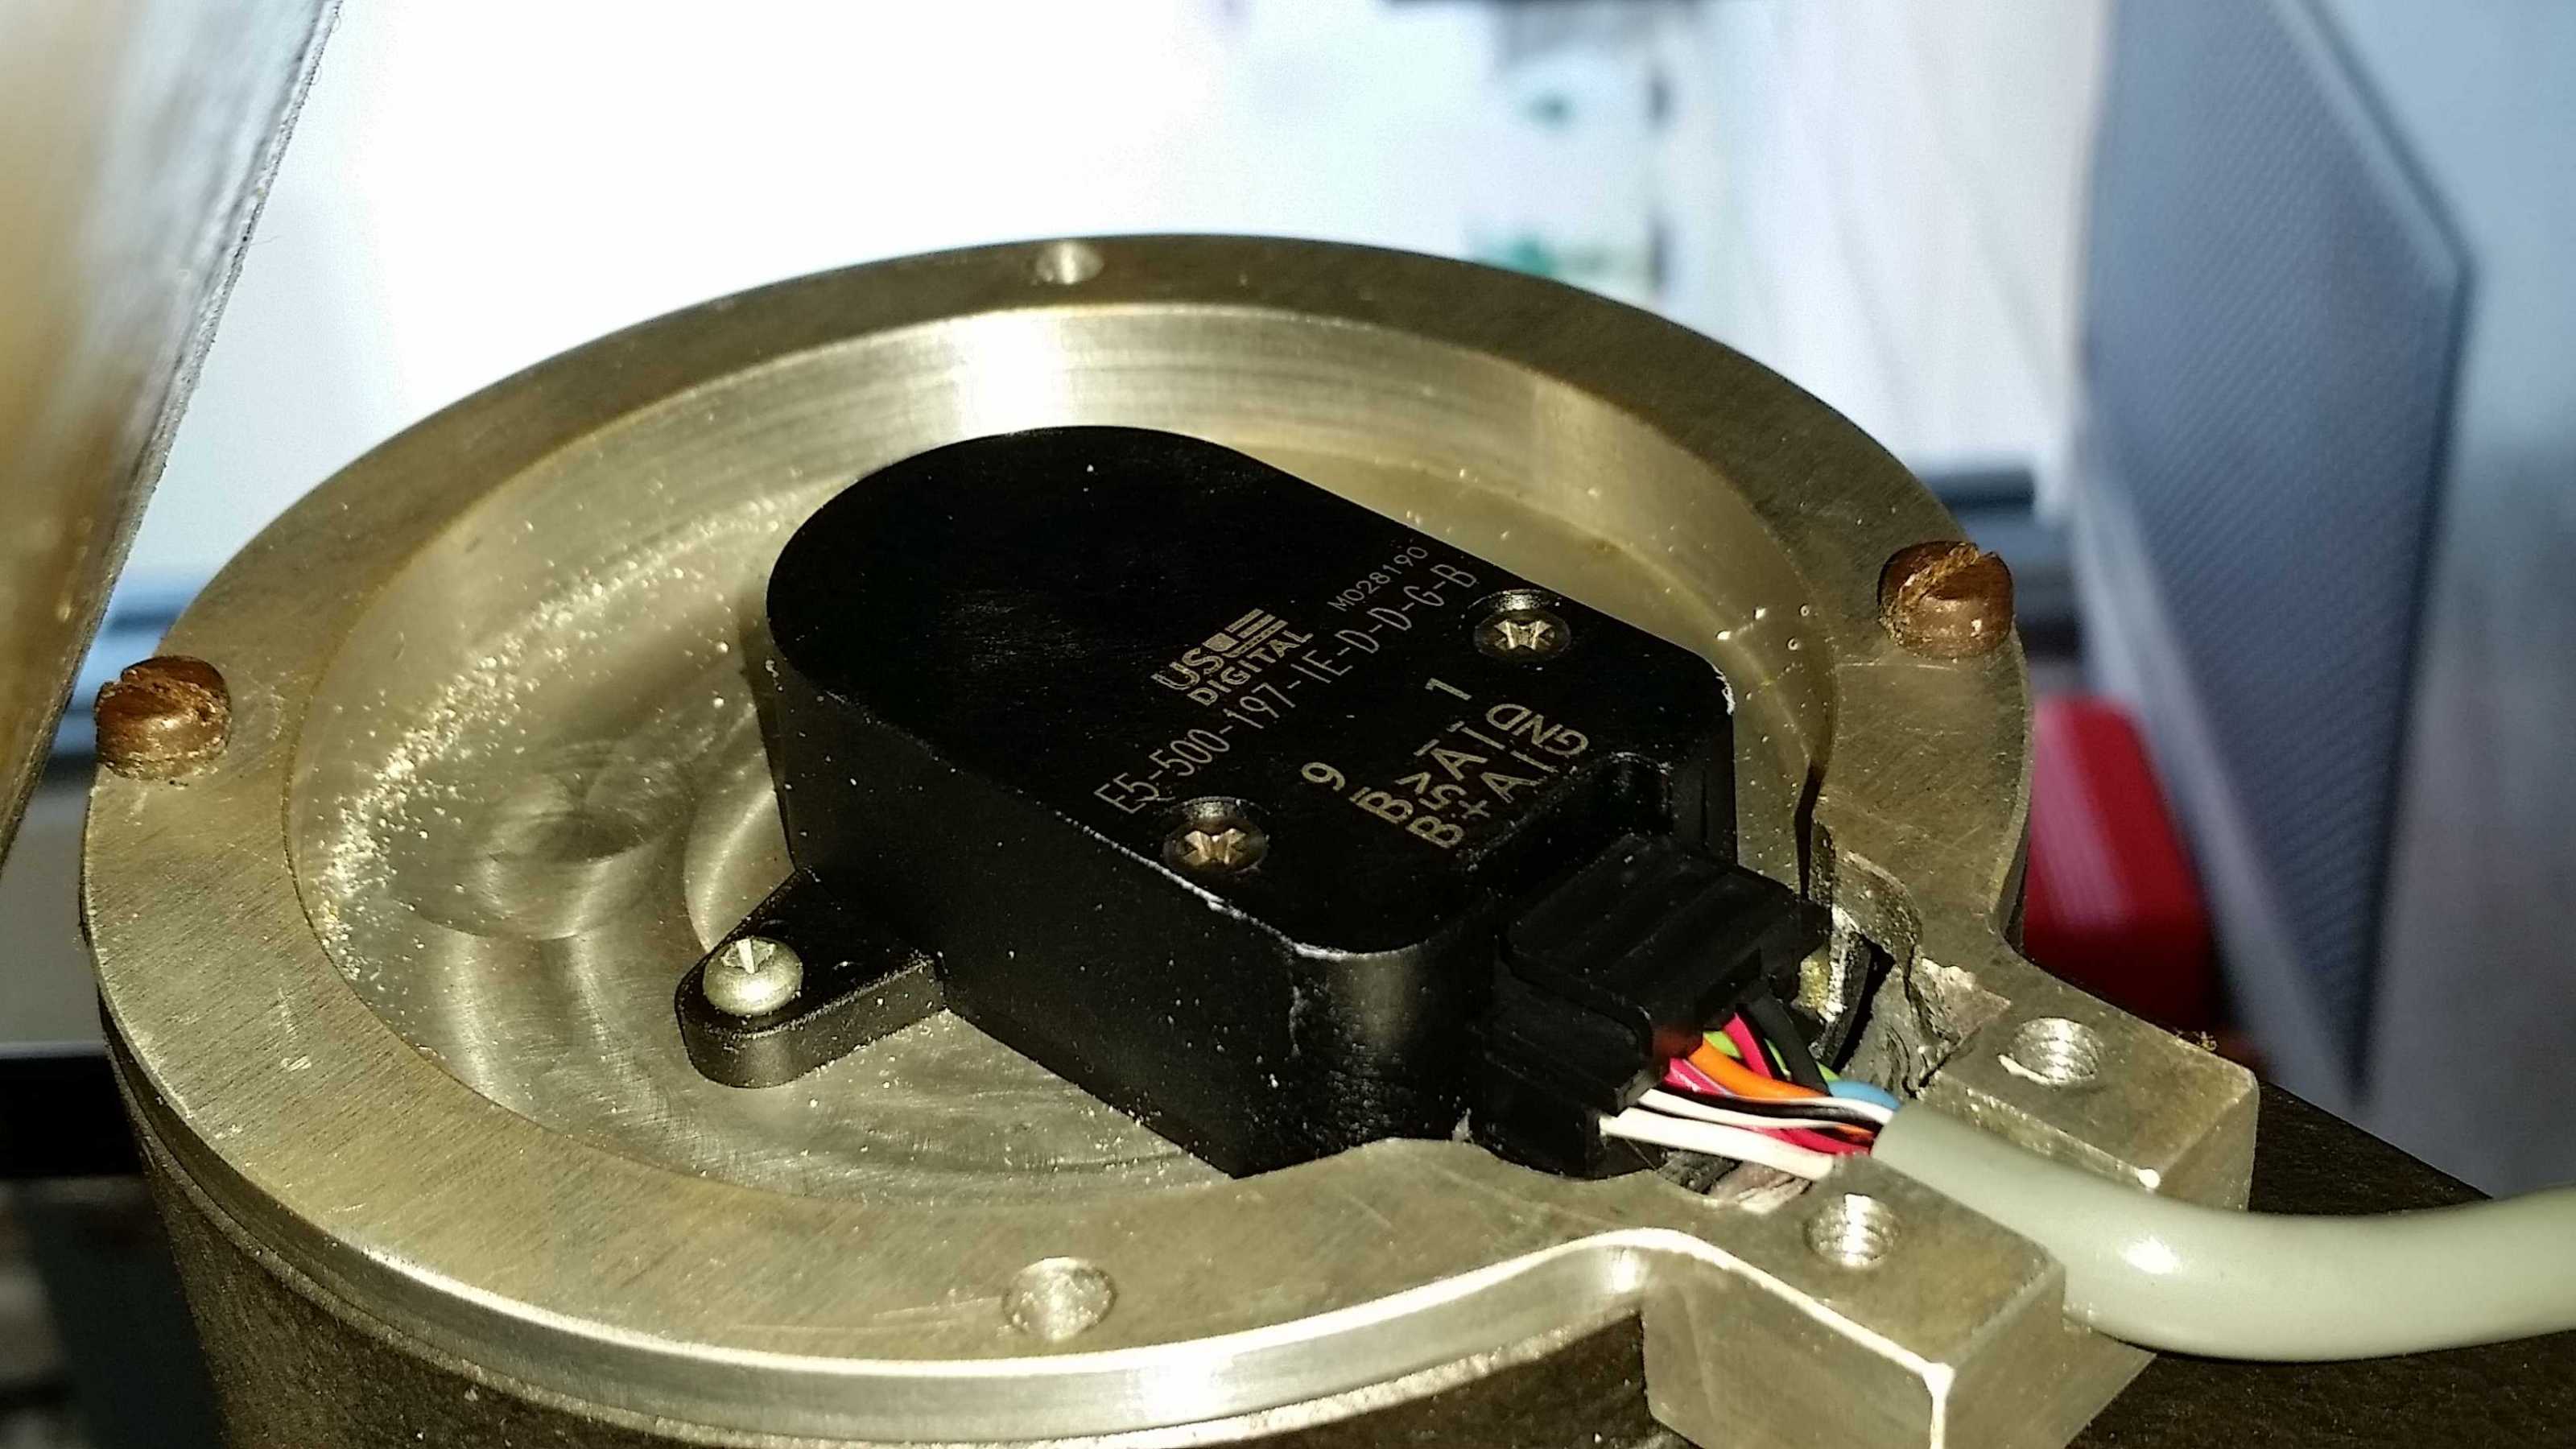
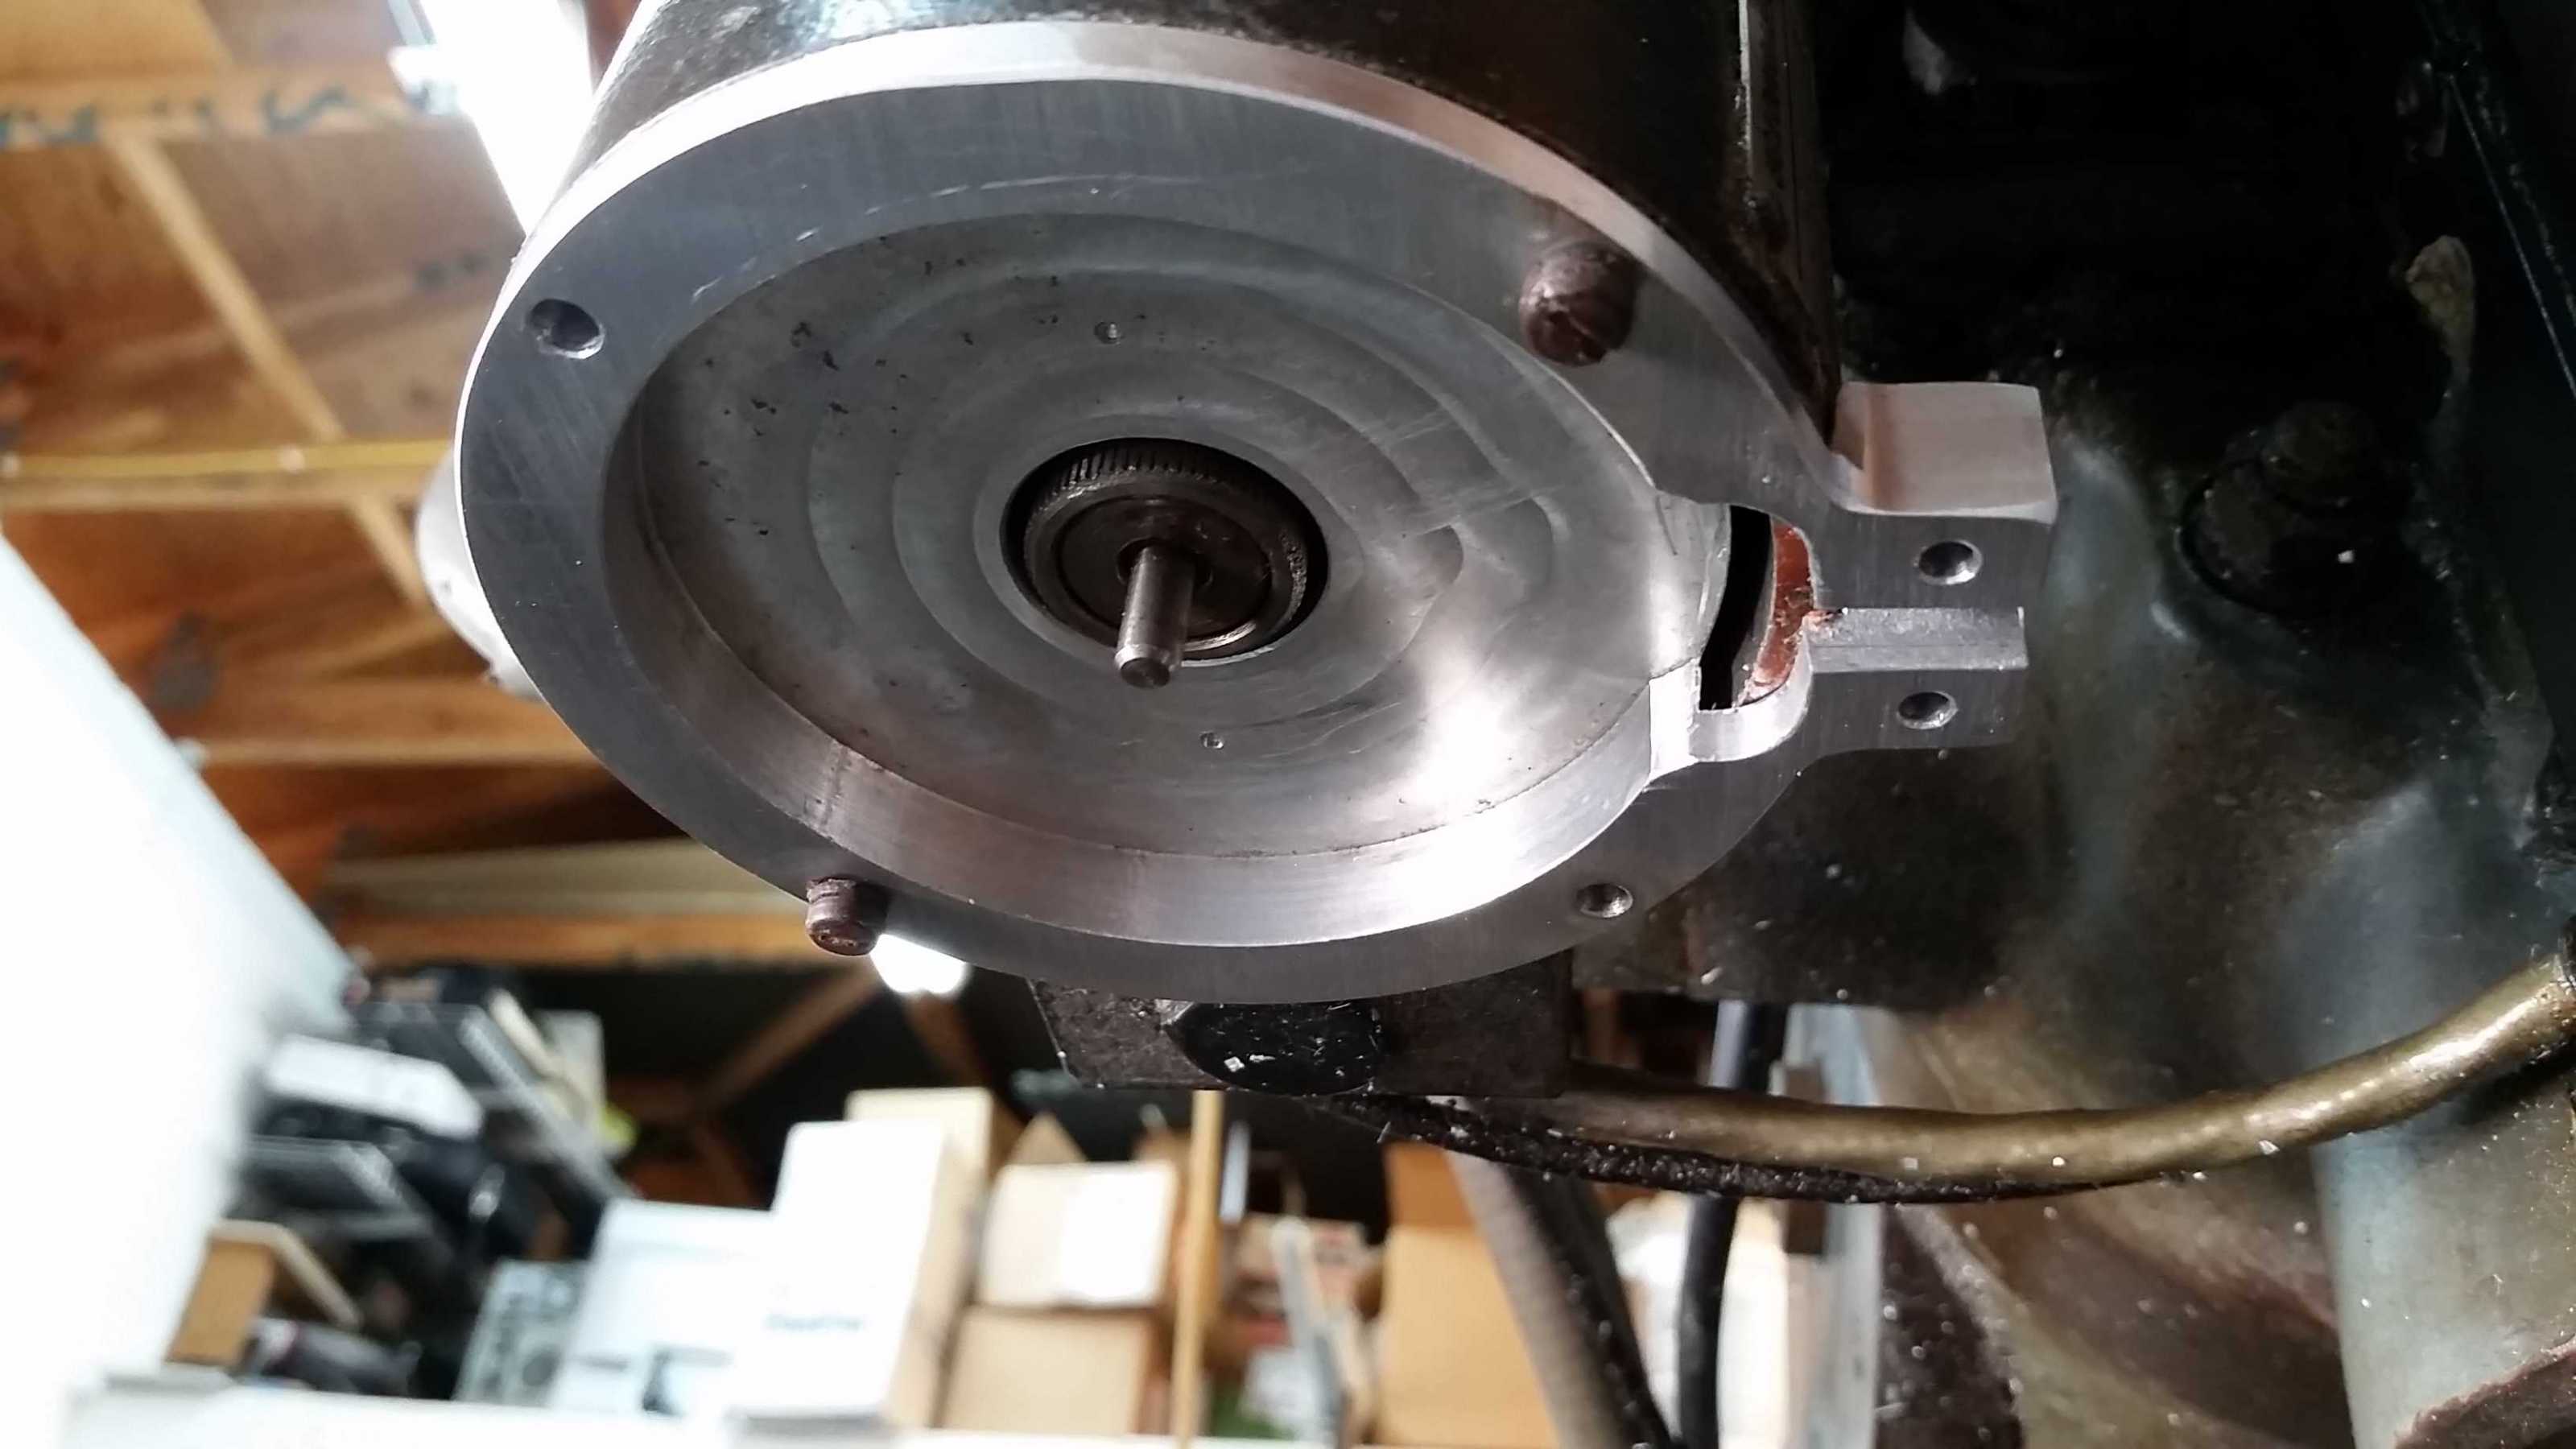
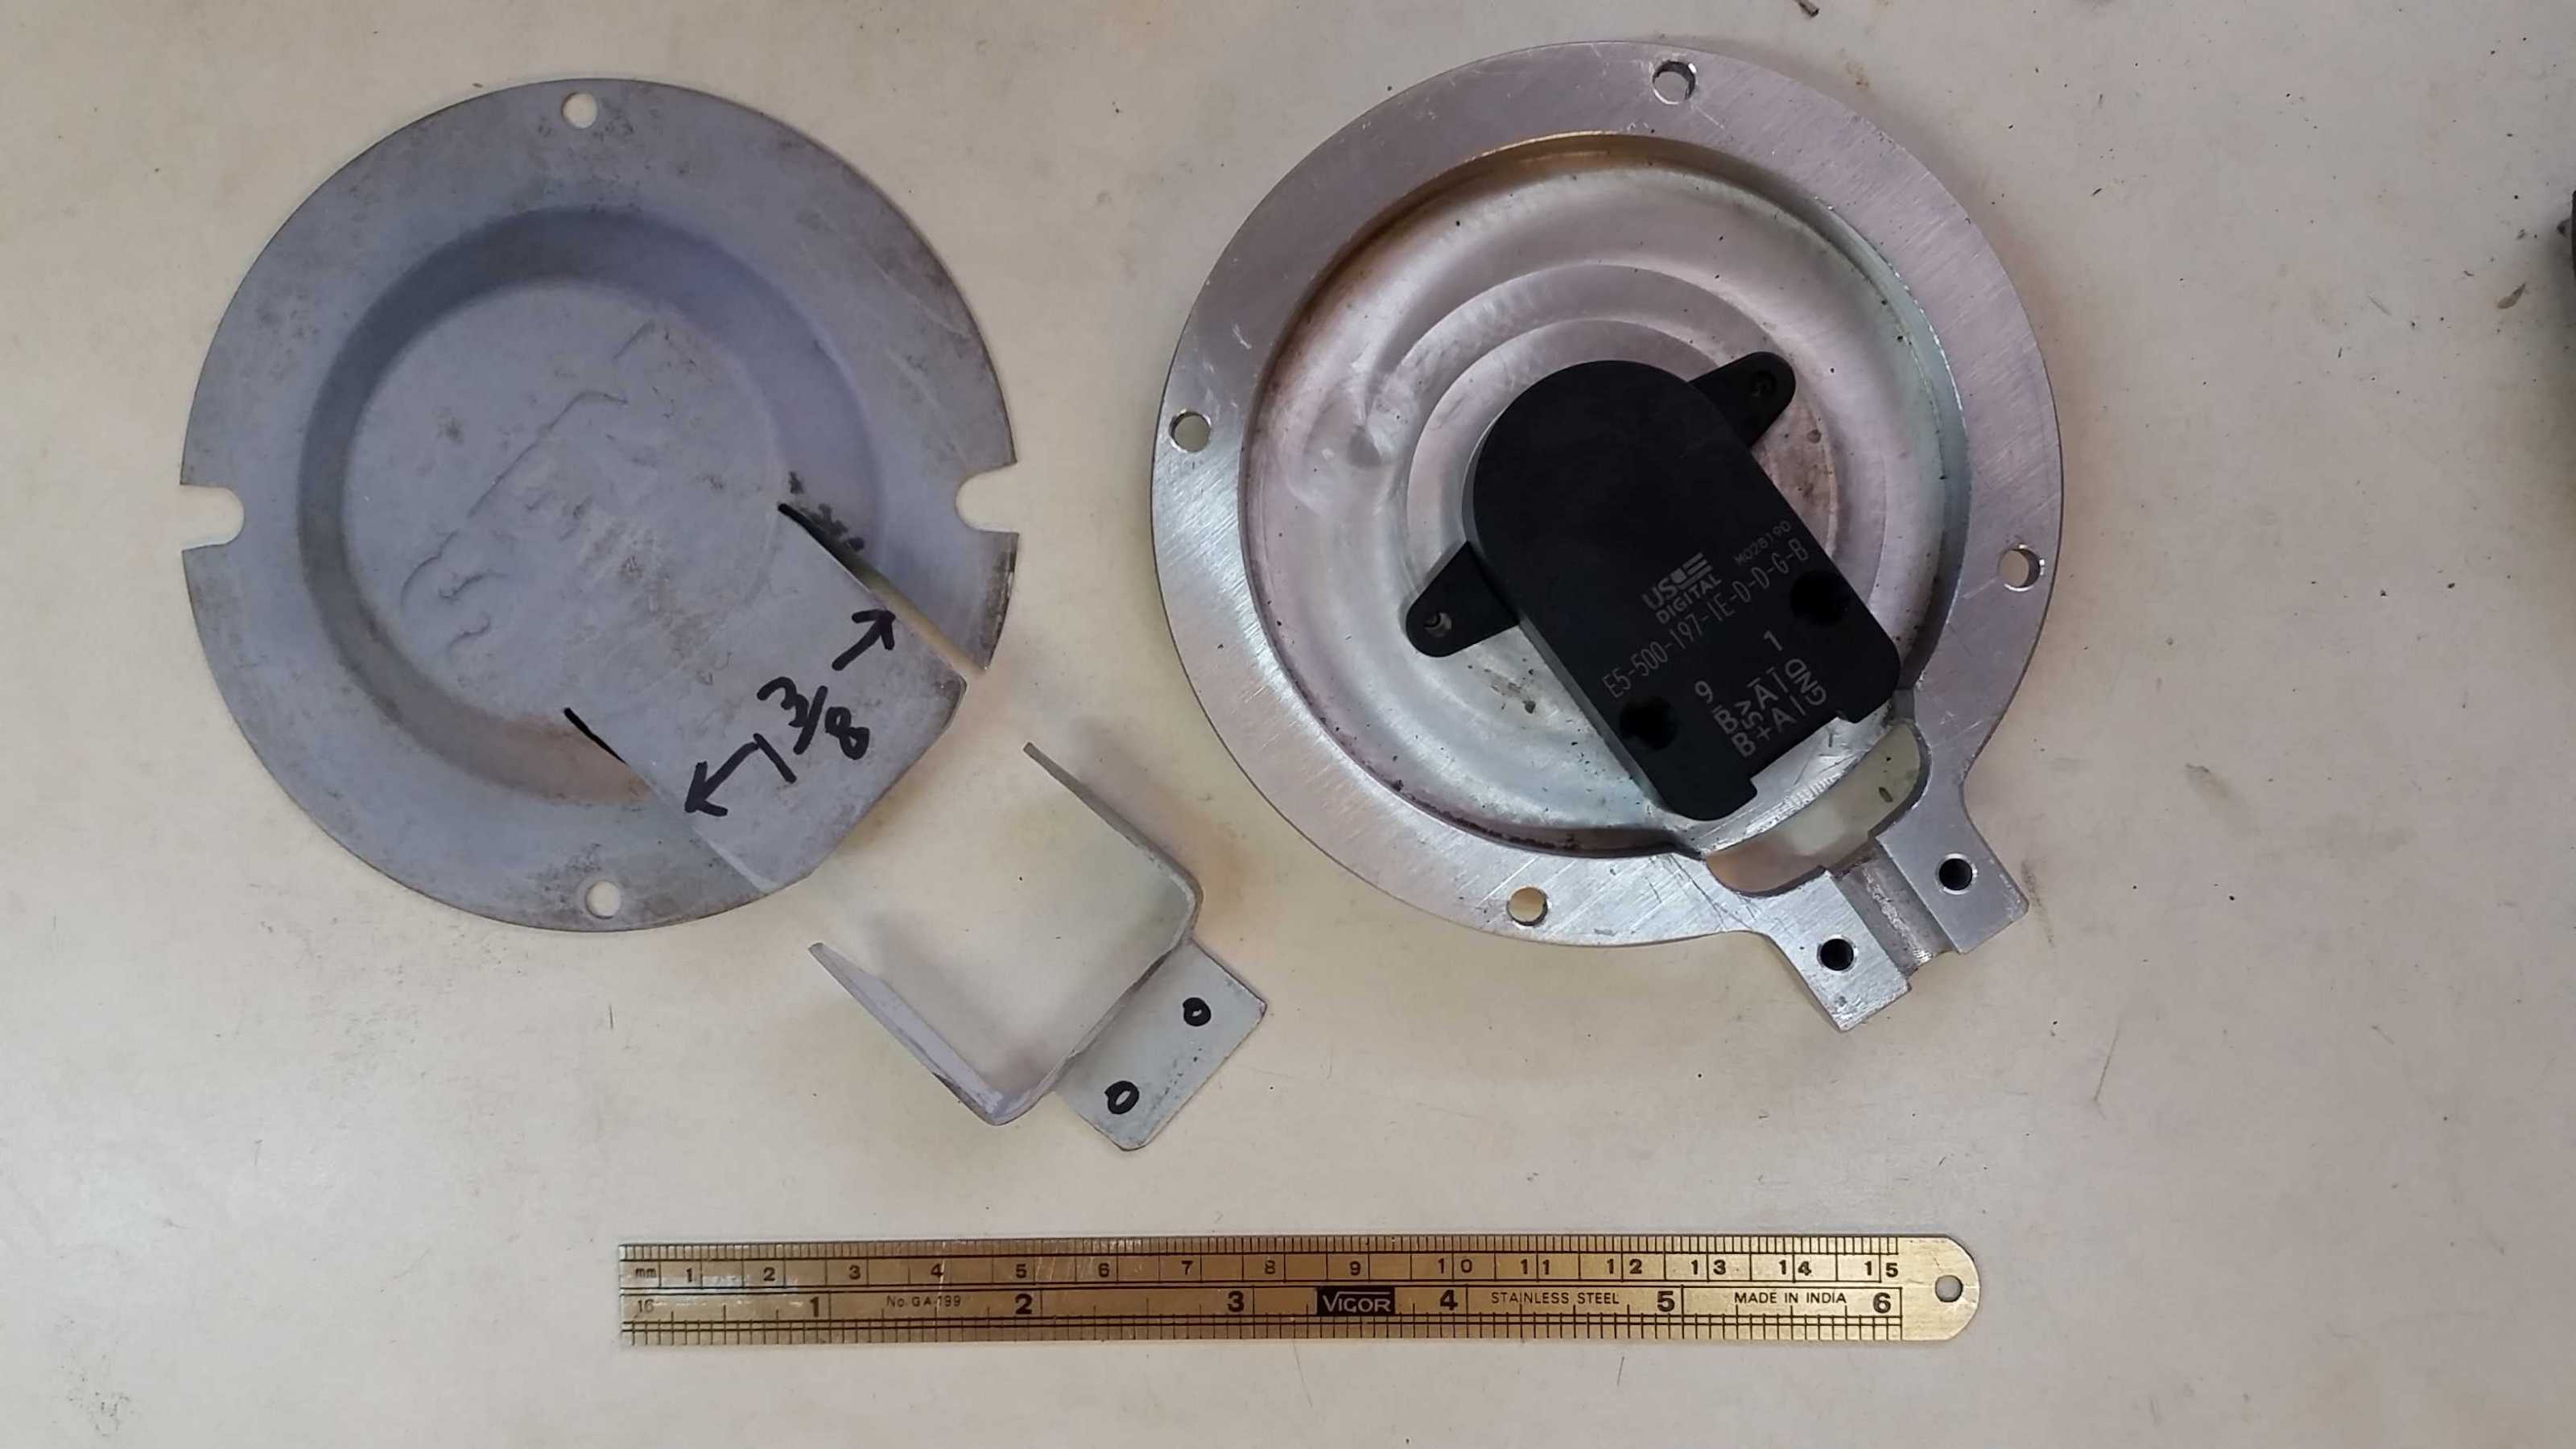
I could not get the servos to completely stop. They had a very slow drift do to no dead zone in the amps. It was very usable but I wanted it better.
I have recently added U.S. Digital rotary encoders to get higher res. I made adapters for the SEM servo motors so I could keep the tacks.
I bored a relief in the back of the encoder base to clear the tack armature. My SEM motors have a 5mm shaft extending past the tack.
Encoders: U.S. Digital E5-500-197-D-D-G-B
Please Log in or Create an account to join the conversation.
- andypugh
- Offline
- Moderator
-

Less
More
- Posts: 19899
- Thank you received: 4655
10 years 10 months ago #67199
by andypugh
Replied by andypugh on topic Anilam Crusader linear scales
[quote="joekline9" post=67164
I could not get the servos to completely stop. They had a very slow drift[/quote]
That sounds like you were not using the glass scales for absolute position control?
I could not get the servos to completely stop. They had a very slow drift[/quote]
That sounds like you were not using the glass scales for absolute position control?
Please Log in or Create an account to join the conversation.
- joekline9
- Offline
- Senior Member
-
Less
More
- Posts: 59
- Thank you received: 9
10 years 10 months ago - 10 years 10 months ago #67206
by joekline9
Replied by joekline9 on topic Anilam Crusader linear scales
Yes I was using the glass scales for abs position.
When I say the servos would not 'stop' I mean they drift 1 encoder count the Linuxcnc would have to correct.
So it was just 1 count drift back and forth. I could zero the offset on the amps and it was OK for a while.
Seems that temperature of something would cause it to change ever so slightly.
I thought about maybe putting back to back diodes in the +-10 volt signal line to create a dead zone but never tried it.
Using Mesa 5i20 and 4 axis servo card.
I just wanted to share the way I added encoders to the SEM motors while keeping the tachometers.
Last edit: 10 years 10 months ago by joekline9.
Please Log in or Create an account to join the conversation.
- andypugh
- Offline
- Moderator
-
Less
More
- Posts: 19899
- Thank you received: 4655
10 years 10 months ago #67207
by andypugh
That should have been something that the PID component deadband could tune out.
Replied by andypugh on topic Anilam Crusader linear scales
joekline9 wrote: So it was just 1 count drift back and forth. I could zero the offset on the amps and it was OK for a while..
That should have been something that the PID component deadband could tune out.
Please Log in or Create an account to join the conversation.
Time to create page: 3.713 seconds