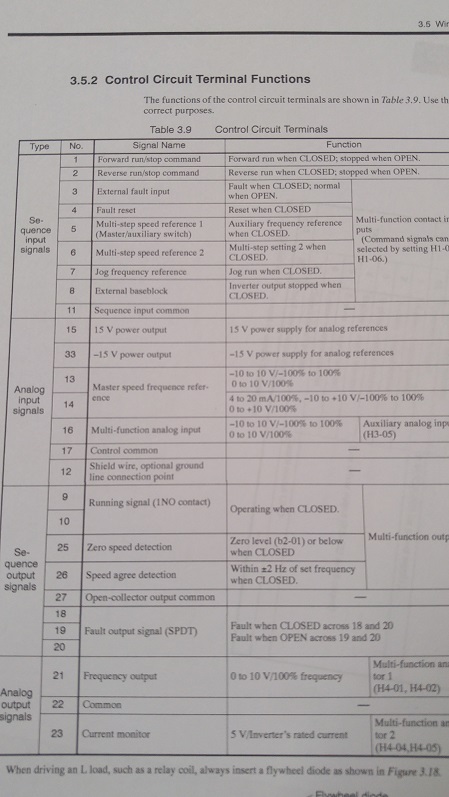
Your manual seems to be different to the two I linked to. However, I'm guessing you should set it up for standard "2-wire" or "3-wire" operation. You either have one input for run/stop forward and another for run/stop reverse - or one for forward, a second for reverse and a third for run/stop. Depends on how you want to connect it to the 7i77.
If you look at the manual in my first link, you can see section 5.23 (page 5.44) shows how to reset to factory defaults for common modes such as 2-wire and 3-wire. The connection diagram for 2-wire is shown on page 1-15 and for 3-wire on page 1-17.
The "base block" input either inhibits the output or latches it off, depending on how other parameters are set up (see page 5-29). Not sure why this has been set up on yours but presumably you have a used drive from an unknown system. It looks as if you can remove this feature by disconnecting terminal S6, as base blocking is enabled by connecting S6 to SC (signal ground). I think you should stick to the conventional 2-wire or 3-wire schemes. Current drives have a "Safe Disable" feature but that completely kills the outputs and isn't recommended for normal on-off control.
A resolver reports the angular position of the motor, usually with high resolution. An encoder like yours only reports the speed of rotation - and the direction if you have both an A and B signal. You only need speed feedback (ie an encoder, not a resolver) for closed loop speed control of an induction motor. However, you could operate it without closed loop control if it gives you problems, although the speed regulation will be better if you can use the encoder.