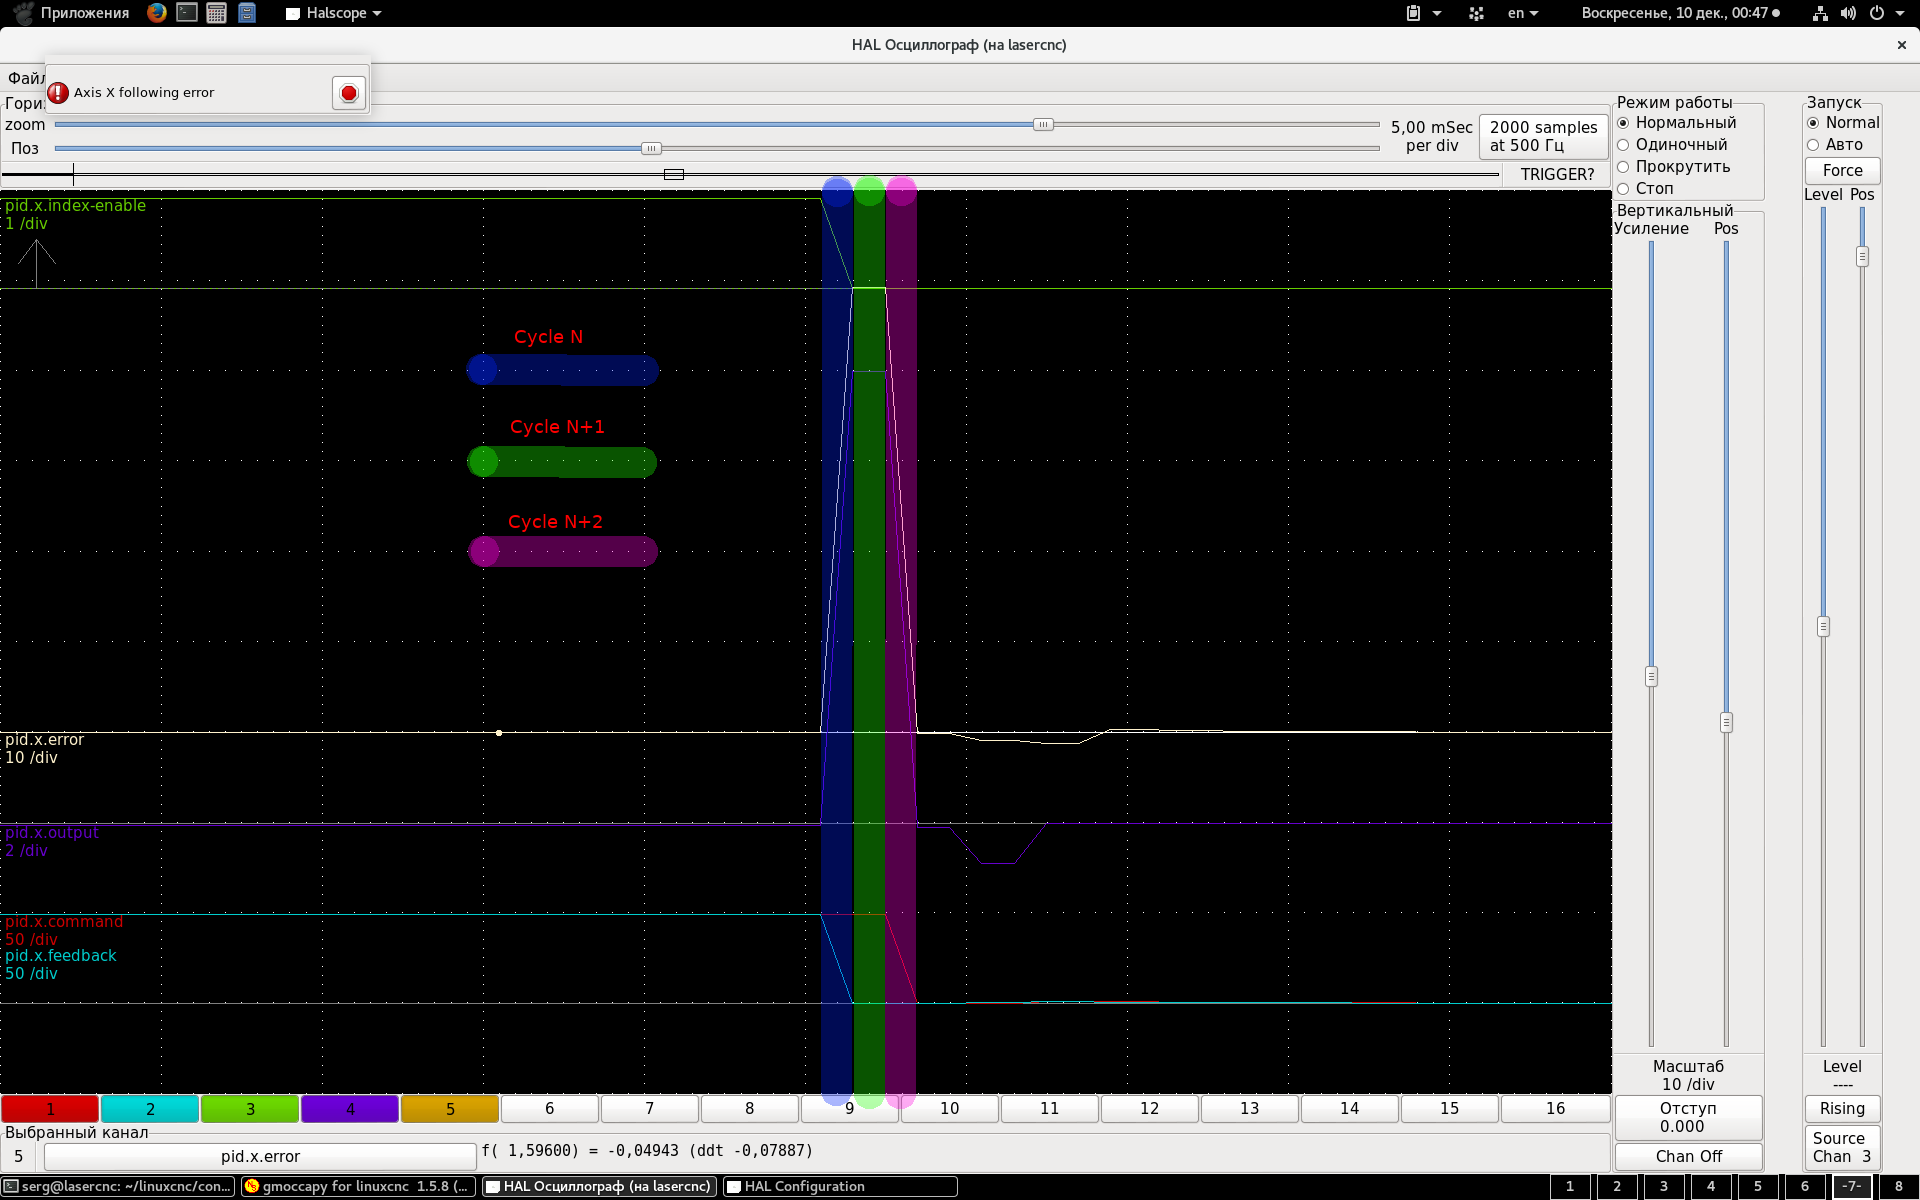
So?
Code:
loadrt hostmot2
loadrt [HOSTMOT2]DRIVER0 board_ip=[HOSTMOT2]BOARD0IP config=" num_encoders=6 num_pwmgens=0 num_stepgens=0 sserial_port_0=000xxx"
addf hm2_7i92.0.read servo-thread
loadrt trivkins
loadrt [EMCMOT]EMCMOT servo_period_nsec=[EMCMOT]SERVO_PERIOD num_joints=[TRAJ]AXES
addf motion-command-handler servo-thread
addf motion-controller servo-thread
loadrt pid names=pid.x,pid.z,pid.s
addf pid.x.do-pid-calcs servo-thread
addf pid.z.do-pid-calcs servo-thread
addf pid.s.do-pid-calcs servo-thread
....
addf hm2_7i92.0.write servo-thread
I tried it. As expected, the problem remained.
I noticed that on the given oscillograms I was mistaken in the designation of cycles: The inscription "Cycle N + 1" should be read as "Cycle N + 2". Below is the correct picture. Sorry.
My patch causes the PID to skip the cycle N+1