motion channels for robotic atc library

More
8 months 1 day ago #343681 by ihavenofish
mmm. interesting

I may wind up making it self contained, as not all my customers will use linuxcnc.

it could run linuxcnc self contained. or we could make it much more simplistic on an arduino.

The way the system is now its down to 2 coordinated linear axes, one fixes linear axis (most likely to be an air cylinder) and one for rotating, which might be best served with a servo axis. not sure yet.

thanks

Please Log in or Create an account to join the conversation.

More
8 months 14 hours ago #343692 by hmnijp

A “HAL-only second planner” is technically possible, but then you own all the safety, limits, interlocks and coordination logic yourself — and it tends to become fragile fast.
 

If the toolchanger robot only requires point-to-point motion and doesn't require circular or linear interpolation, then extrajoints can be used. Basic safety chains, homing, and limits will work as for other regular joints. However, for motion planning, you need to connect the simple_tp or limit3 components. Their motion calls should be implemented in custom M-code (e.g., M100 P1.2 Q23 ...).

Please Log in or Create an account to join the conversation.
More
8 months 11 hours ago #343696 by ihavenofish

A “HAL-only second planner” is technically possible, but then you own all the safety, limits, interlocks and coordination logic yourself — and it tends to become fragile fast.
 

If the toolchanger robot only requires point-to-point motion and doesn't require circular or linear interpolation, then extrajoints can be used. Basic safety chains, homing, and limits will work as for other regular joints. However, for motion planning, you need to connect the simple_tp or limit3 components. Their motion calls should be implemented in custom M-code (e.g., M100 P1.2 Q23 ...).

oooh. yeah we can 100% just have single axis at a time motion for this.
thanks, ill look into this.

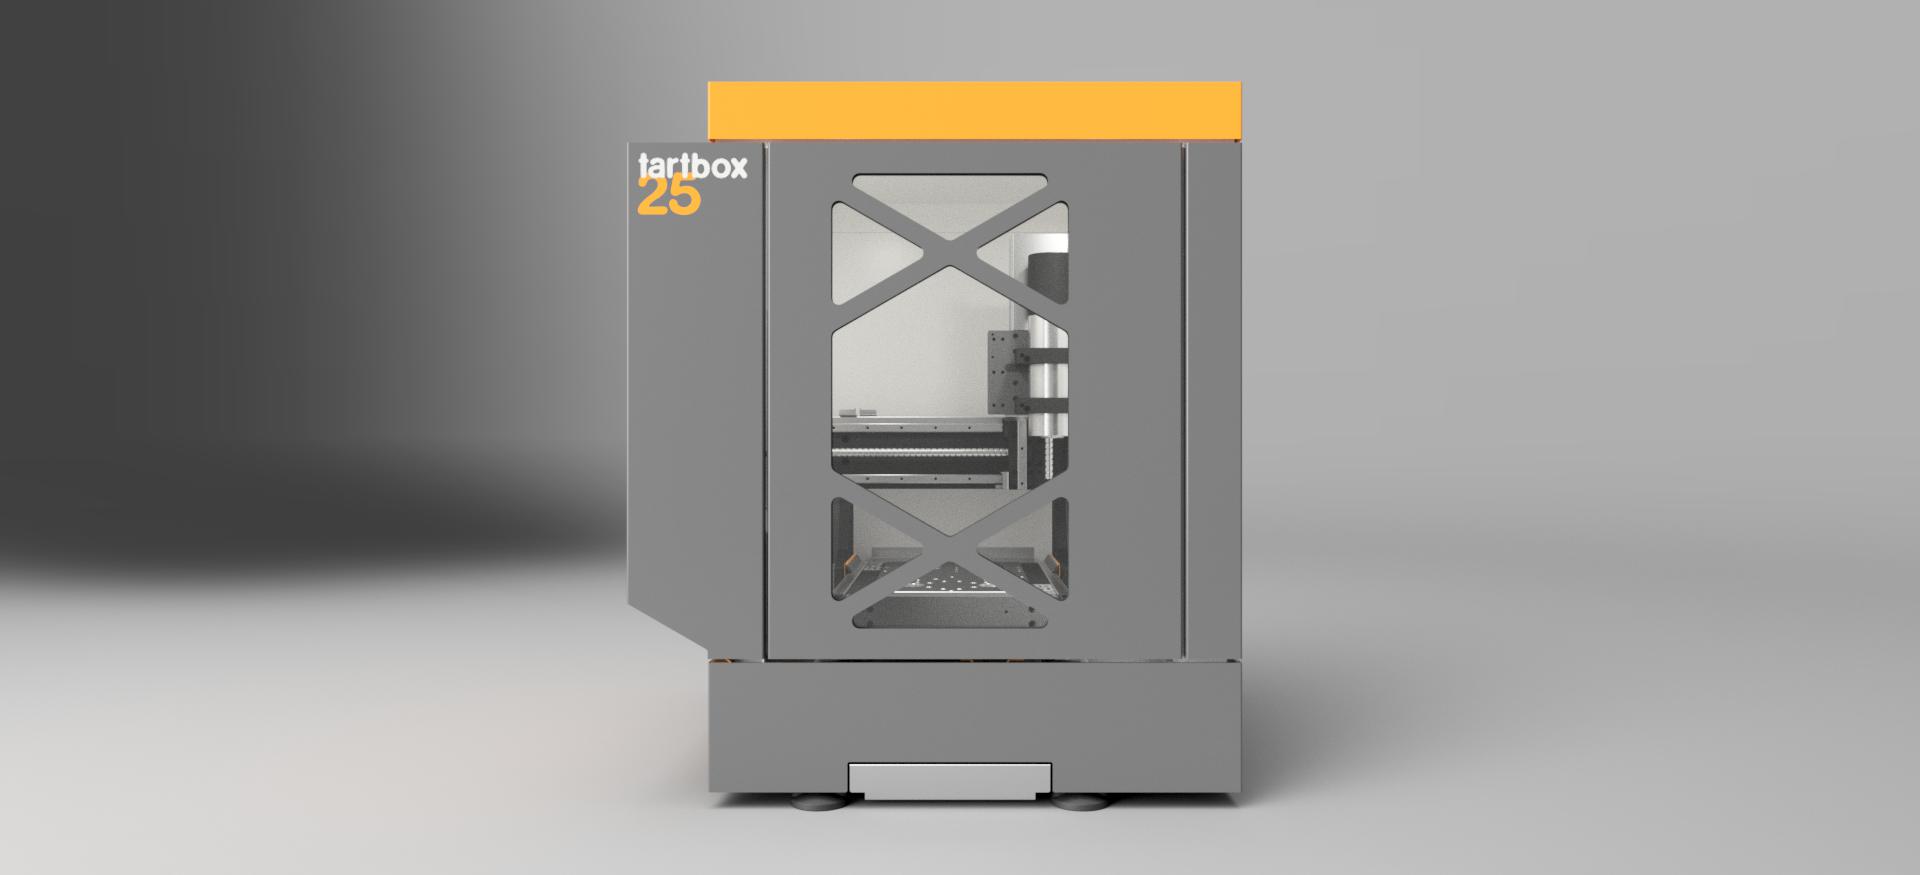
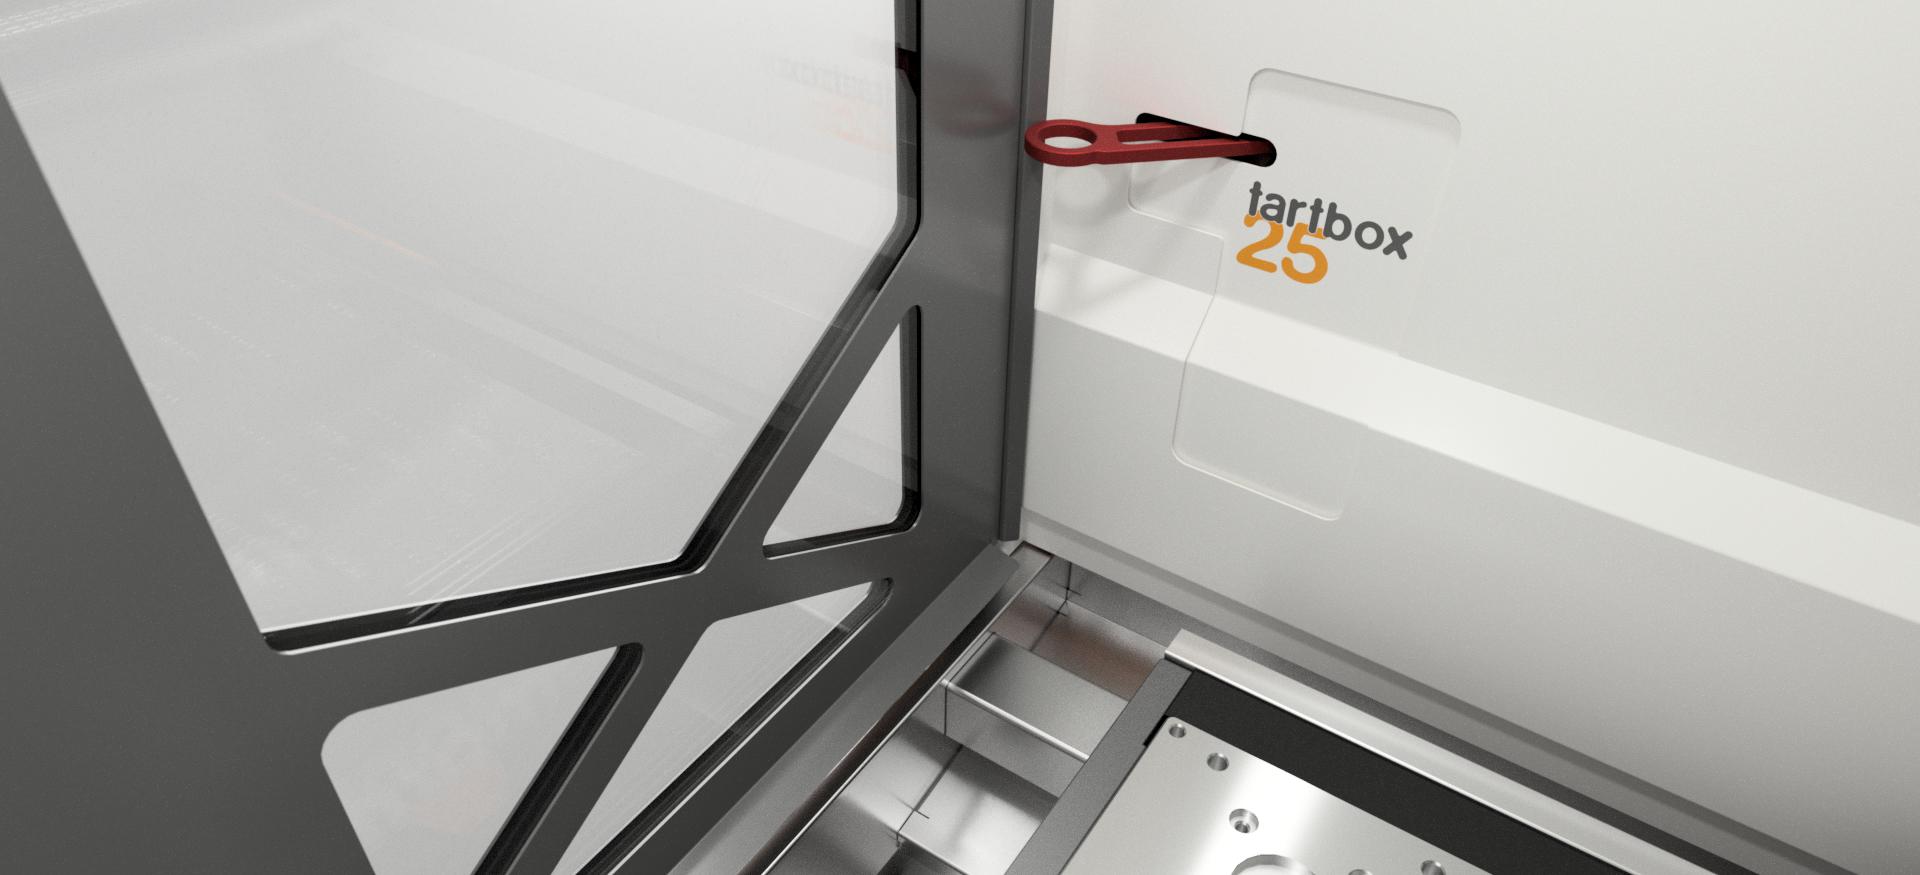
The devices is starting to take shape here


The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.
More
7 months 4 weeks ago #343819 by ihavenofish
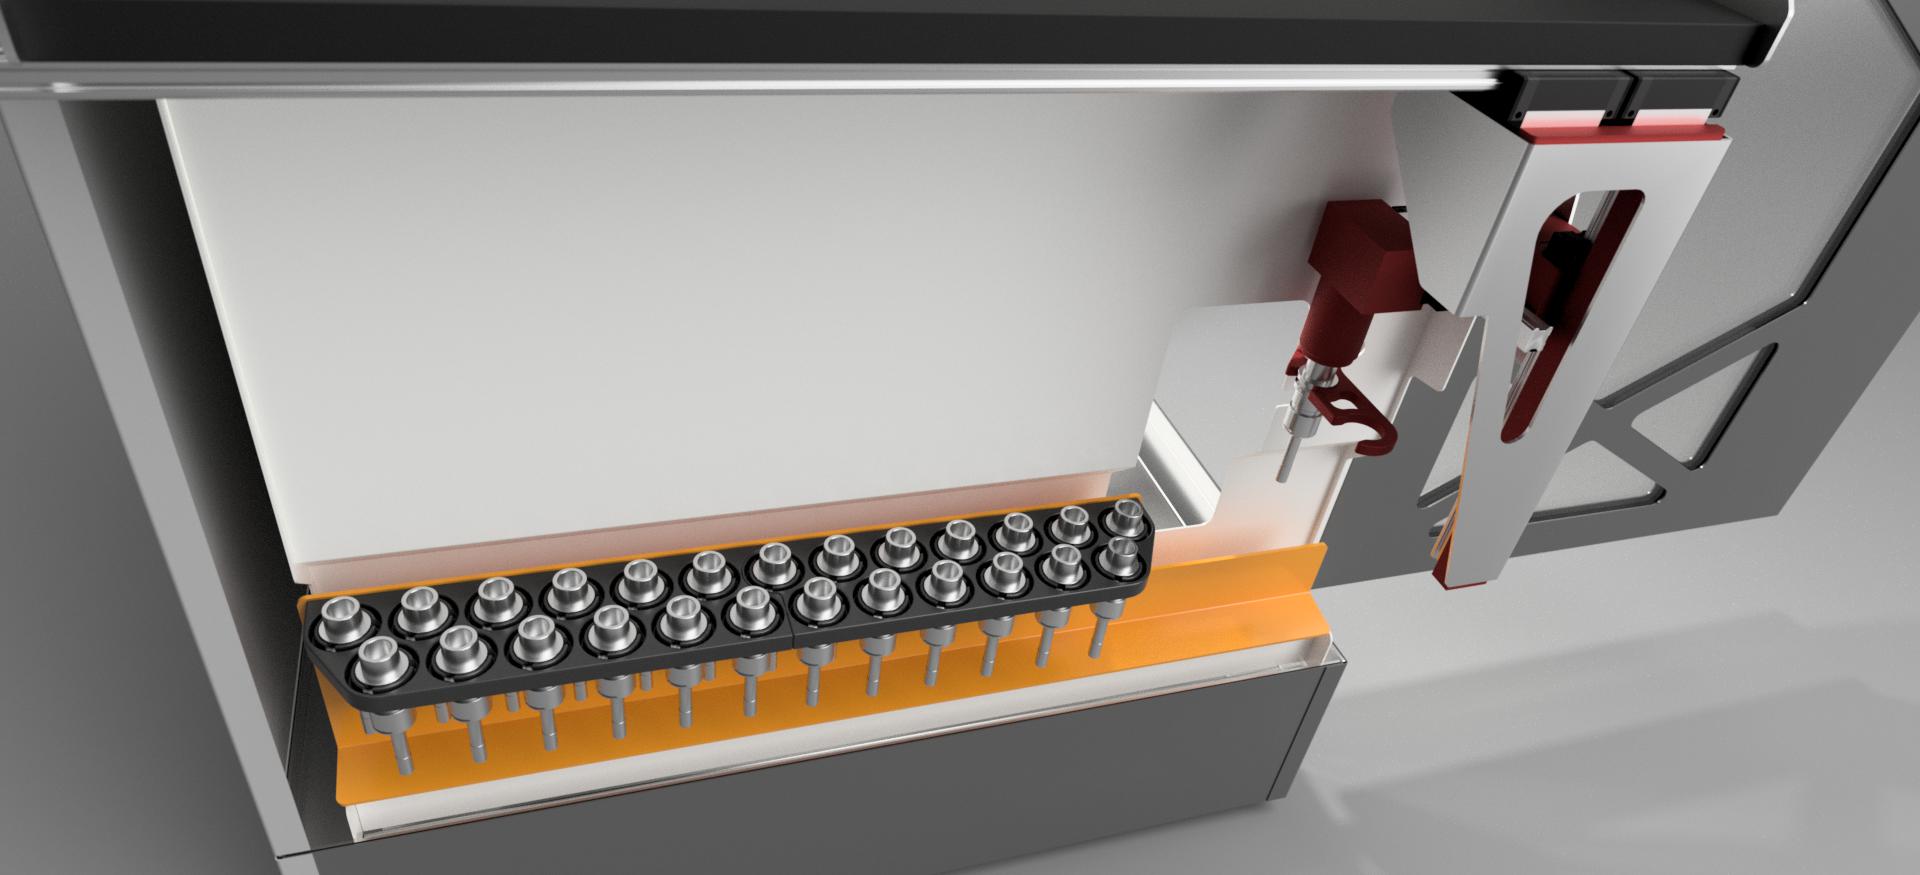
So we have wound up with a simple little 3 axis cartesian robot. Robot basically has a spindle taper and air powered gripper, and then hands off to a switcher arm that will be moved by the little robot with a roller cam. 


I will probably build this in april, then we can see if it can live inside the master linuxcnc or needs a separate controller.

So the run down:

- X, Y, Z linear motion.
- gripper air cylinder.

1: Robot on its own goes to grab the next tool needed by the machine, and places it in the arm SLOT A
2: M6 Tx called
3: Robot uses cam to move arm out into position. Door opens on the same linkage (we could also do this with air)
4: Machine moves to tool change arm and places the tool in SLOT B
5: Then it grabs the tool in SLOT A and moves away from the arm

Basically the main control sees the atc as a stationary rack type with only 2 tools

6: The arm retracts in and door closes
7: Machine resumes cutting
8: The robot takes the tool from SLOT B and puts it back in the right pocket
9: Robot grabs the next tool in the program and we repeat everything again

Make sense?

Please Log in or Create an account to join the conversation.
More
7 months 4 weeks ago #343842 by NWE
I'm convinced extrajoints handles such a case. It can even move multiple joints at the same time, they're just not synced with each other in any way unless extra hal logic is used to interpolate moves, which you don't need here.

Please Log in or Create an account to join the conversation.

More
7 months 4 weeks ago - 7 months 4 weeks ago #343847 by hmnijp
It would be nice to have a simple_xyz_tp.comp component to support linear interpolation and be independent of the main TP.

I think this is a simple task for extending the simple_tp component, where smoothing and arcs are not required.
Last edit: 7 months 4 weeks ago by hmnijp.

Please Log in or Create an account to join the conversation.

Time to create page: 0.112 seconds
Powered by Kunena Forum
