
EtherCAT Master Beckhoff slave not found
- andrax
-
- Offline
- Platinum Member
-

Less
More
- Posts: 321
- Thank you received: 84
11 Sep 2026 19:45 #349585
by andrax
Replied by andrax on topic EtherCAT Master Beckhoff slave not found
Vertraue keiner KI bevor du nicht das Handbuch gelesen hast.
Please Log in or Create an account to join the conversation.
- rodw
-
- Offline
- Platinum Member
-
Less
More
- Posts: 12161
- Thank you received: 4151
12 Sep 2026 12:35 #349596
by rodw
Replied by rodw on topic EtherCAT Master Beckhoff slave not found
I would try typing: lcec-configgen
and see how much of your configuration is done for you
and see how much of your configuration is done for you
Please Log in or Create an account to join the conversation.
- Schaublin12
- Away
- New Member
-

Less
More
- Posts: 9
- Thank you received: 0
14 Sep 2026 16:05 - 14 Sep 2026 16:11 #349634
by Schaublin12
Replied by Schaublin12 on topic EtherCAT Master Beckhoff slave not found
I have tried lcec configgen xml
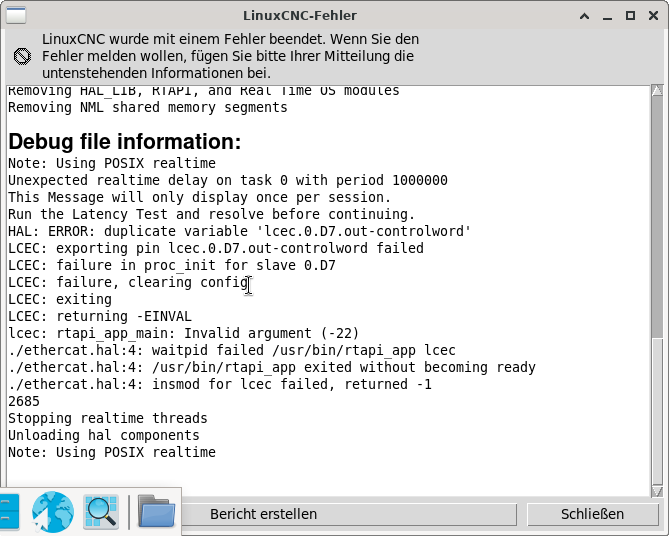
Now I have got a new xml file as attached, but LinuxCNC doesn't start.
Now I have got a new xml file as attached, but LinuxCNC doesn't start.
Last edit: 14 Sep 2026 16:11 by Schaublin12.
Please Log in or Create an account to join the conversation.
- rodw
-
- Offline
- Platinum Member
-
Less
More
- Posts: 12161
- Thank you received: 4151
15 Sep 2026 11:26 #349649
by rodw
Replied by rodw on topic EtherCAT Master Beckhoff slave not found
I did say try! You have duplicated a pin name in the xml file. It tells you that.
Please Log in or Create an account to join the conversation.
- Schaublin12
- Away
- New Member
-
Less
More
- Posts: 9
- Thank you received: 0
15 Sep 2026 13:02 #349653
by Schaublin12
Replied by Schaublin12 on topic EtherCAT Master Beckhoff slave not found
Thanks, Rod, for your help. I'm still pretty overwhelmed by this right now. But I've figured out that the automatically generated XML file lists all the operating modes, and I have to choose one. I hadn't realized that, which is why I ended up with duplicate variable names. I've now decided on operating mode CSP and deleted the rest. I'll give it a try when I get home.
Please Log in or Create an account to join the conversation.
- andrax
-
- Offline
- Platinum Member
-
Less
More
- Posts: 321
- Thank you received: 84
16 Sep 2026 07:30 #349674
by andrax
Replied by andrax on topic EtherCAT Master Beckhoff slave not found
Alle Hall Pins müssen einen eineindeutigen Namen haben.
Am besten benennst du die Pins nach der jeweiligen Achse, das macht die die spätere Zuordnung einfacher.
halPin="out-controlword" >>> halPin="X-out-controlword"
halPin="out-controlword" >>> halPin="Y-out-controlword"
halPin="out-controlword" >>> halPin="Z-out-controlword"
Am besten benennst du die Pins nach der jeweiligen Achse, das macht die die spätere Zuordnung einfacher.
halPin="out-controlword" >>> halPin="X-out-controlword"
halPin="out-controlword" >>> halPin="Y-out-controlword"
halPin="out-controlword" >>> halPin="Z-out-controlword"
Please Log in or Create an account to join the conversation.
- Schaublin12
- Away
- New Member
-
Less
More
- Posts: 9
- Thank you received: 0
23 Sep 2026 22:08 #349827
by Schaublin12
Replied by Schaublin12 on topic EtherCAT Master Beckhoff slave not found
ich habe jetzt ein bisschen mit KI rumprobiert. Im PP Modus hatte sich der Motor mal gedreht im CSP Modus nicht mehr. Scheinbar hatte irgendwie die DC Synchronisation gefehlt. Hier mein aktueller Stand:Wir haben bereits bewiesen:
- EtherCAT OP ✅
- DC-Synchronisation 1 ms ✅
- CSP PDO-Mapping ✅
- über PDO erreichbar ✅
0x607A
- Motor reagiert auf kleine CSP-Positionsänderungen ✅
- aktueller Fehler✅
0x603F = 0
Please Log in or Create an account to join the conversation.
- rodw
-
- Offline
- Platinum Member
-
Less
More
- Posts: 12161
- Thank you received: 4151
24 Sep 2026 04:17 #349833
by rodw
Replied by rodw on topic EtherCAT Master Beckhoff slave not found
For now I would set your machine up for immediate homing. Its described here but also read the whole thing (about 8 times as its important) 
linuxcnc.org/docs/stable/html/config/ini-homing.html
If you want to use internal homing by the drive, I would leave that for now and set up homing by LinuxCNC until you have a better understanding.
linuxcnc.org/docs/stable/html/config/ini-homing.html
If you want to use internal homing by the drive, I would leave that for now and set up homing by LinuxCNC until you have a better understanding.
Please Log in or Create an account to join the conversation.
- Schaublin12
- Away
- New Member
-
Less
More
- Posts: 9
- Thank you received: 0
27 Oct 2026 06:51 #350475
by Schaublin12
Replied by Schaublin12 on topic EtherCAT Master Beckhoff slave not found
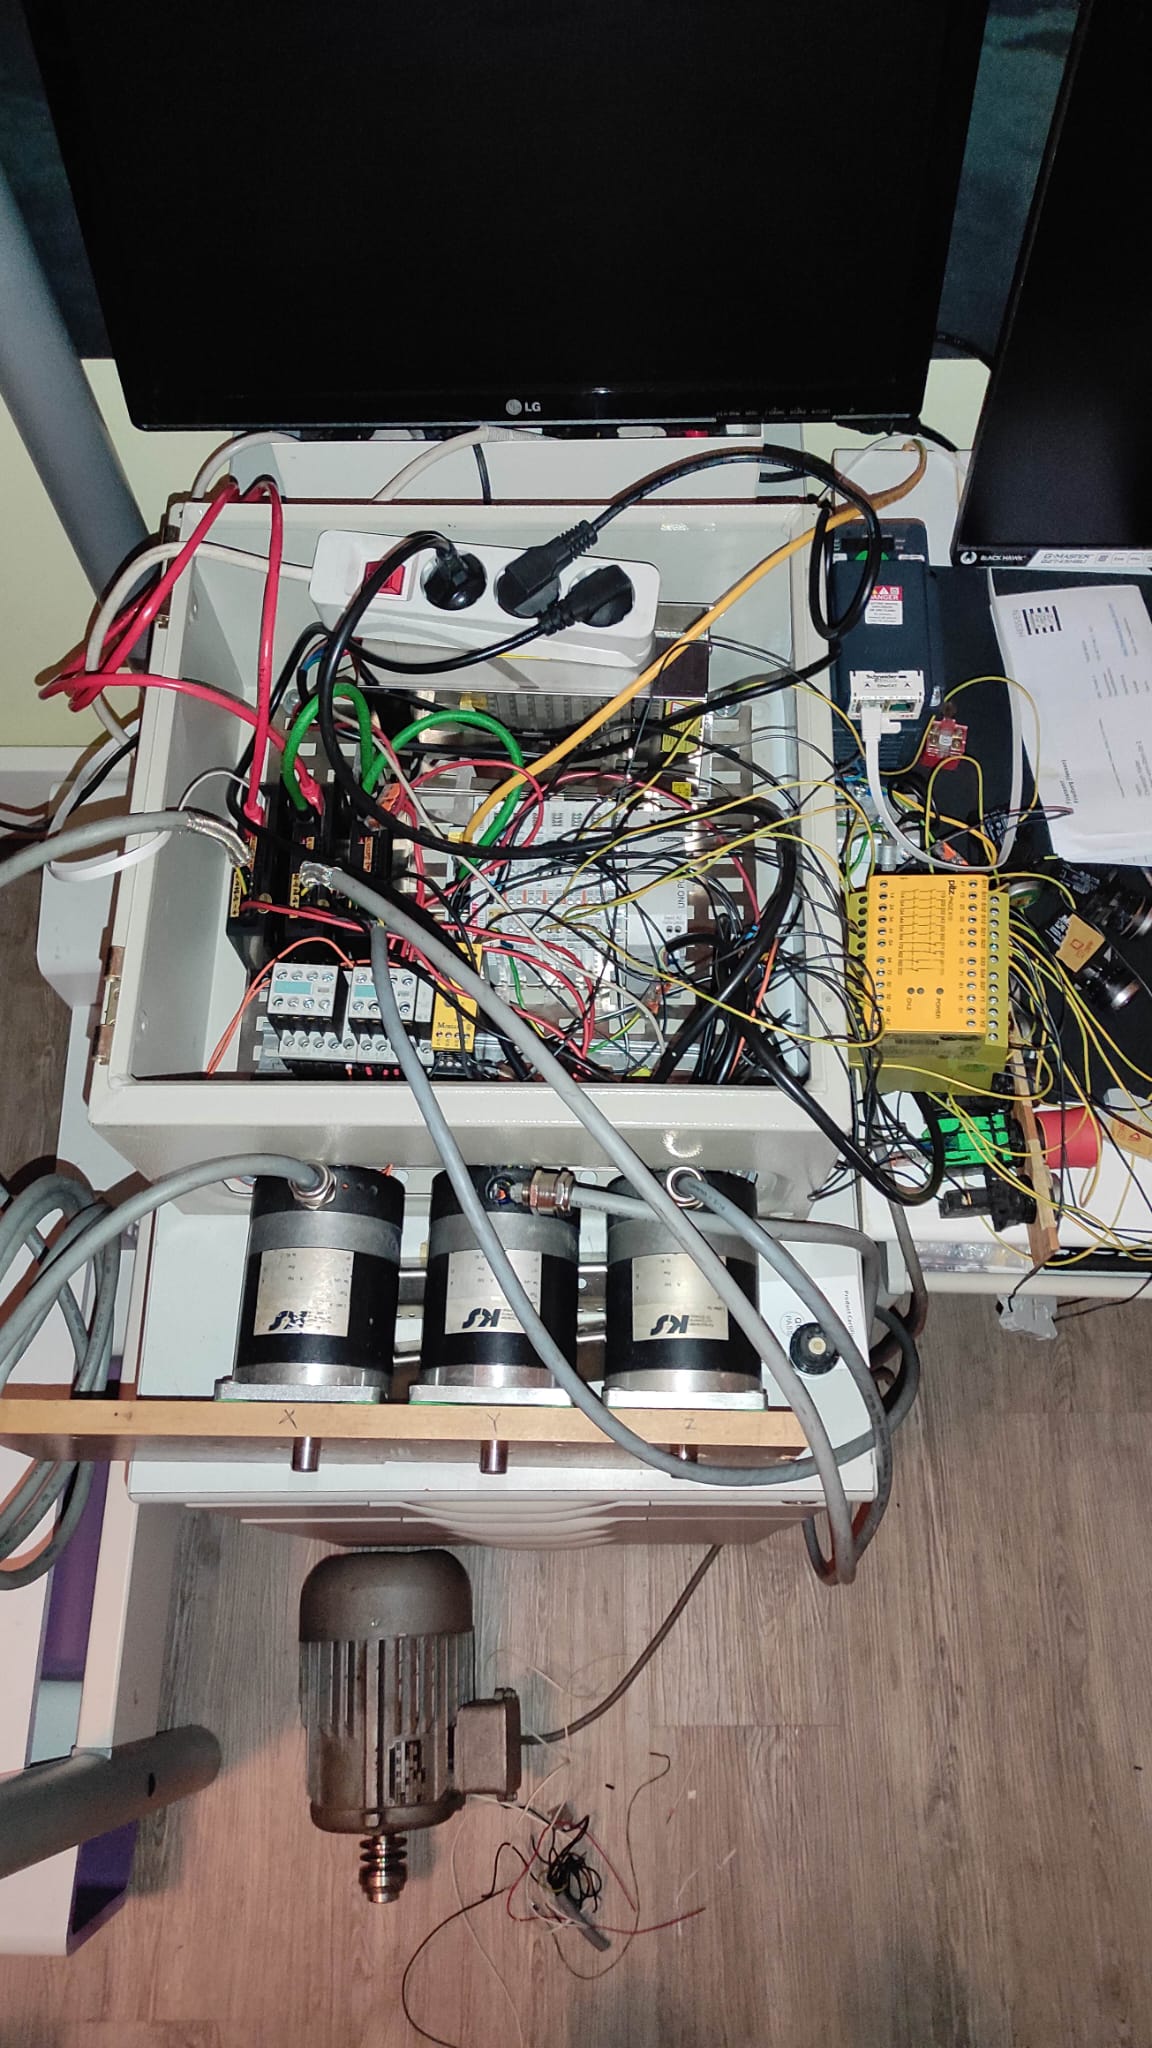
Ich dachte ich gebe euch mal wieder ein kleines Update zum aktuellen Stand: In der Zwischenzeit habe ich einen Nuc MiniPC gekauft und habe diesen PC statt der virtuellen Umgebung eingerichtet. Mein Servothread brauchte anfangs knapp über 1ms und ich musste die Aufgaben auf die Kerne verteilen. Jetzt bin ich unter 1mS. Ich habe einen Notaus mit manuellem Reset, ich kann „Maschine ein/aus“ über Taster steuern. Dann habe ich daran gearbeitet den Schneider ATV320 über das EtherCAT Modul in die Steuerung einzubinden. Das hat gut geklappt. Die Taster für M3,M4 und M5 haben allerdings gefühlt eine Ewigkeit gedauert. Aber auch dieses Problem ist gelöst und die Taster funktionieren nach meiner Vorstellung. Dann kam noch Cycle start und Cycle stop dazu. Für feed hold sind mir die Taster ausgegangen. Aktuell warte ich noch auf eine Beckhoffklemme für meinen Joystick für x und y. Was wären noch wichtige Funktionen, die man als physikalischen Taster braucht? Was wäre ein praktisches Layout für das Bedienpanel?
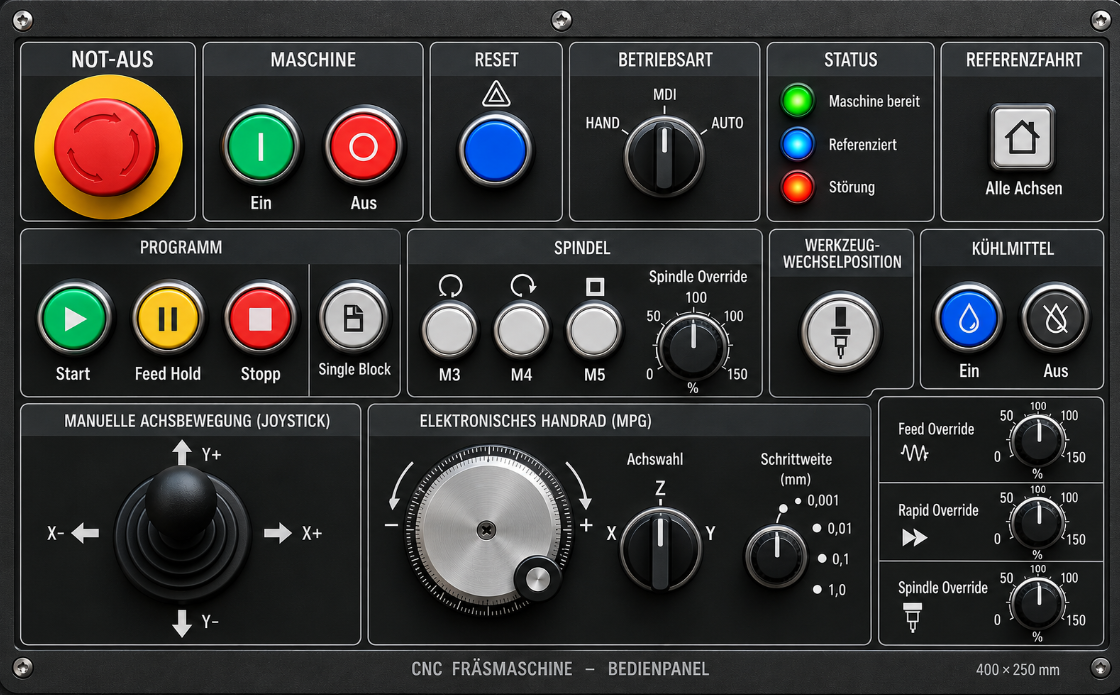
Attachments:
Please Log in or Create an account to join the conversation.
Time to create page: 0.299 seconds