How to proper compile, built, and install linuxCNC

  • ALittleOffTheRails
  • New Member
  • New Member
More
4 years 9 months ago - 4 years 9 months ago #231975 by ALittleOffTheRails
Replied by ALittleOffTheRails on topic How to proper compile, built, and install linuxCNC
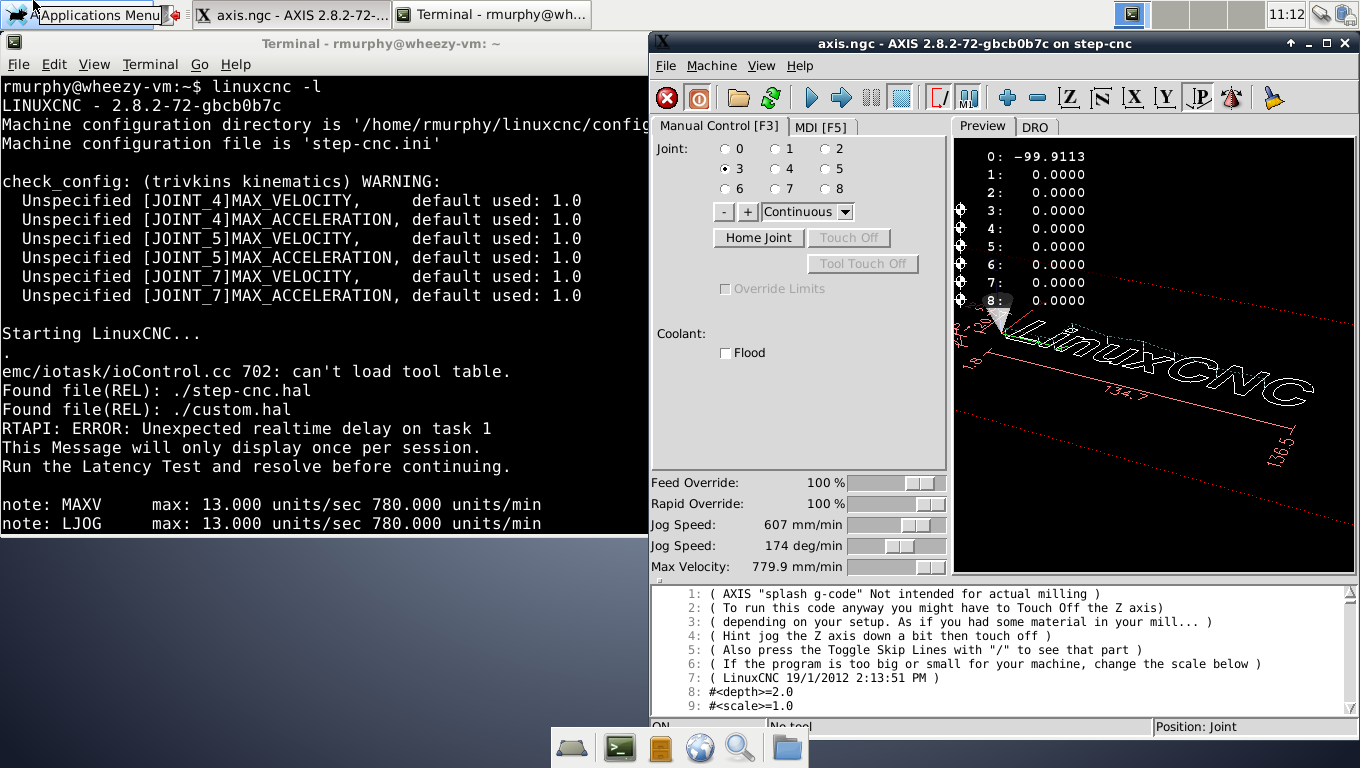
Ok I installed a Wheezy from the ISO to a virtual machine.

Updated Linuxcnc to 2.8.2

Compiled and installed the comp.

Fiddled with the ini & hal files from the wiki to get them to work with 2.8.2

Ran the config and it loaded fine with no issues.

So I'm guessing it has to be something at your end. As far as I can tell the config will load to the axis gui.

 
Last edit: 4 years 9 months ago by ALittleOffTheRails.

Please Log in or Create an account to join the conversation.

More
4 years 9 months ago - 4 years 9 months ago #231995 by Matt Hat
Thank you, such efforts too support is very much appreciated!!
Your right, it is - as in other cases - the config file format that makes the issue.
1) Fresh install of lncnc 2.9 from buildbot.linuxcnc,org
2) sudo halcompile --install rot4thaxiskin.c
3) Open a running config file and let it convert automatically to new format
4) Add the modification from the wiki manually
- First Only add the
Code:
loadrt rot4thaxiskins setp rot4thaxiskins.H1 41
--> no error. kinematics is loading.
5) adapt the .ini: Most evidently, format changes of
Code:
[TRAJ] should be empty [KINS] JOINTS = 9 XZY+ABC+UVW
Attention: the wiki defines 8x [AXIS] but now we need 9x [JOINTS]
6) connect
Code:
net upos-fb joint.6.motor-pos-cmd => joint.6.motor-pos-fb net vpos-fb joint.7.motor-pos-cmd => joint.7.motor-pos-fb net wpos-fb joint.8.motor-pos-cmd => joint.8.motor-pos-fb

This configs are still quite outside of my circle of competence.
- 9 joints enough for 4 axes with travel limits
- What do we need for the tool offsets UVW, only [JOINTS] it seems?

Last edit: 4 years 9 months ago by Matt Hat.

Please Log in or Create an account to join the conversation.

More
4 years 9 months ago #232002 by Matt Hat
Hurray, it is running. Final thing to do is to implement the correct kinematics, recompile rot4thaxiskin.c, and run the machine.
Weird is the code in rot4thaxiskin.c:
Code:
m_z = 1. / sin_a * (joint[1] - cos_a * m_y) + H1;
I am working to fix it, something like
Code:
m_z = sin_a * joint[1] + cos_a * (joint[2] - H1)+H1;
makes more sense to me.
Code:
[J1;J2]=[cos.a sin.a; -sin.a cos.a].*[my;mx] [my;mz]=[cos.a -sin.a; sin.a cos.a].*[J1;J2] then substitute mz->mz-H1 and substitute J2->J2-H1

Please Log in or Create an account to join the conversation.

Time to create page: 0.089 seconds
Powered by Kunena Forum