How to monitor OP mode in Panasonic A6B Ethercat

More
2 years 3 months ago #304866 by onceloved
You can run it multiple times to find the servo drive that can OP every time. Use ethercat sii_read to read the sii data in it and compare it with the sii data in the drive that cannot OP to find the difference. The easiest way is to use ethercat sii_write to write the good sii data. It has been several months since I solved this problem and this problem has never appeared again.
The following user(s) said Thank You: marq_torque

Please Log in or Create an account to join the conversation.

More
2 years 3 months ago #304867 by onceloved
I translated the post from Chinese into English using Google Translate. It may not be clear, feel free to ask questions if you don't understand.
The following user(s) said Thank You: marq_torque

Please Log in or Create an account to join the conversation.

More
2 years 3 months ago #304878 by marq_torque
Sorry for my illiteracy but This is beyond my understanding... Can you give me detailed steps to start from.?

Thanks in advance.

Please Log in or Create an account to join the conversation.

More
2 years 3 months ago - 2 years 3 months ago #304880 by marq_torque

Now, do I need to invert "lcec.0.0.drivestatus-0" ? How it can be done?
Maybe try the 'NOT' component:
linuxcnc.org/docs/devel/html/man/man9/not.9.html


I think I already tried using "not" component, can you confirm this is right format?
" 
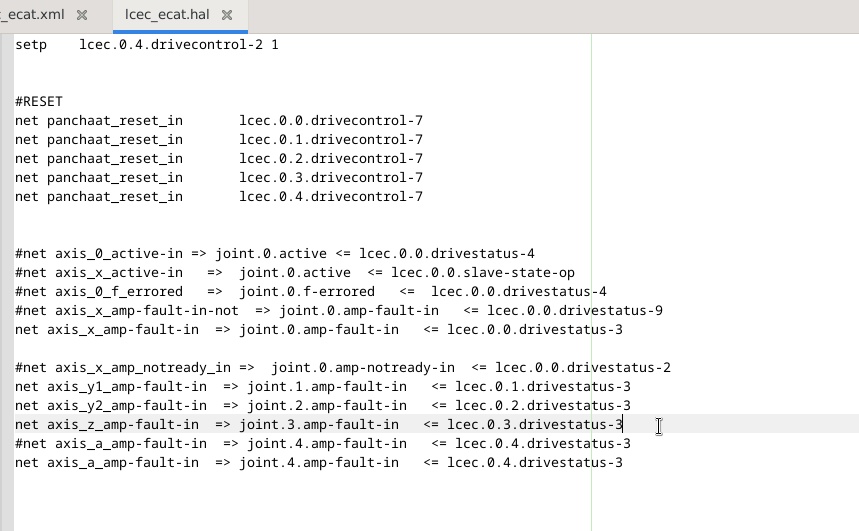
Last edit: 2 years 3 months ago by marq_torque.

Please Log in or Create an account to join the conversation.

More
2 years 3 months ago #304883 by endian

try running this in terminal:
Code:
watch -n 0.1 ethercat slaves however drives not getting to OP mode must have a reason. What hardware are you on? I have similar issue with RPI5 and generic driver. I tried faster servo threads, but developers told me, that generic driver is only good for 1 000 000 ns servo thread.

 
Hello zmrdko,

have you ever reinstalling drivers from default generic to other as e1000e or rtl8190too ? I did some questions about this problematic during early days of lcec at one of the first threads and guys told me that there is no much big difference between them...

but I should have calmer sleeping if there is right driver with the right hardware..

regards

Please Log in or Create an account to join the conversation.

More
2 years 3 months ago #304884 by Aciera

I think I already tried using "not" component, can you confirm this is right format?

I know nothing about EtherCAT, so I have no idea if you can get an inverted value back from the drive. What I suggested was using the built in HAL component called 'NOT'. For which you would need to use 'loadrt' and 'addf' commands and connect the input and output pins in hal.
The following user(s) said Thank You: marq_torque

Please Log in or Create an account to join the conversation.

Time to create page: 0.099 seconds
Powered by Kunena Forum
