- Posts: 12169
- Thank you received: 4153

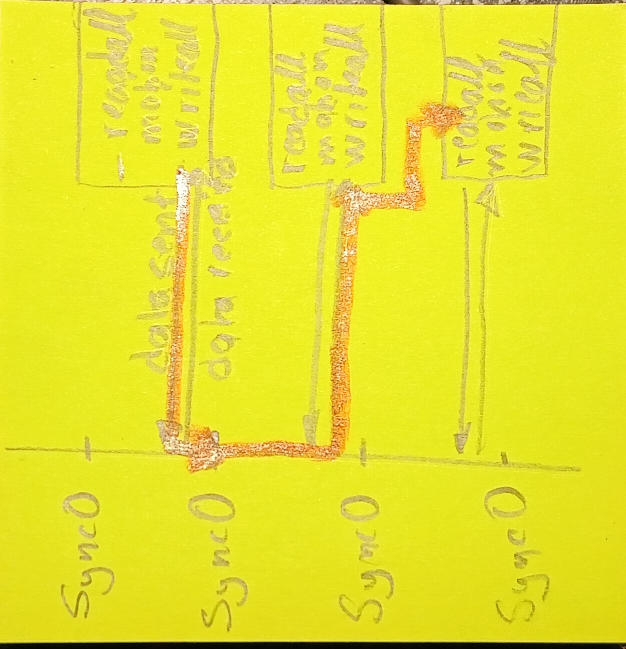
Not sure how this can be. The servo thread fires every 1 Ms (1000 usec), If you do a trace, It might take 200 usec to execute, then it sleeps for the remaining 800 usec) until it fires gain. The Ethercat thread and the Linuxcnc servo thread are synchronized. We read from lcec at the beginning of the servo thread execution, do our stuff, pids and position adustments etc then write write the result back to lcec then sleep as normal for the remaining 800 usec. How does it lag 2000 usec behind?You hit the weak point in linuxcnc Ethercat.
Position feedback from a drive is always two servo cycles behind.
Following error due to this is at least axis speed x 2 x servo cycle time.
You can easily verify this.
Please Log in or Create an account to join the conversation.

You hit the weak point in linuxcnc Ethercat.
Position feedback from a drive is always two servo cycles behind.
Following error due to this is at least axis speed x 2 x servo cycle time.
You can easily verify this.
Not sure how this can be. The servo thread fires every 1 Ms (1000 usec), If you do a trace, It might take 200 usec to execute, then it sleeps for the remaining 800 usec) until it fires gain. The Ethercat thread and the Linuxcnc servo thread are synchronized. We read from lcec at the beginning of the servo thread execution, do our stuff, pids and position adustments etc then write write the result back to lcec then sleep as normal for the remaining 800 usec. How does it lag 2000 usec behind?

Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.


That, i believe!And my brain hurts.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
