Retrofitting an old industrial CNC mill with EtherCAT components - MAHO MH400E

More
5 months 1 week ago #346570 by PedPEx
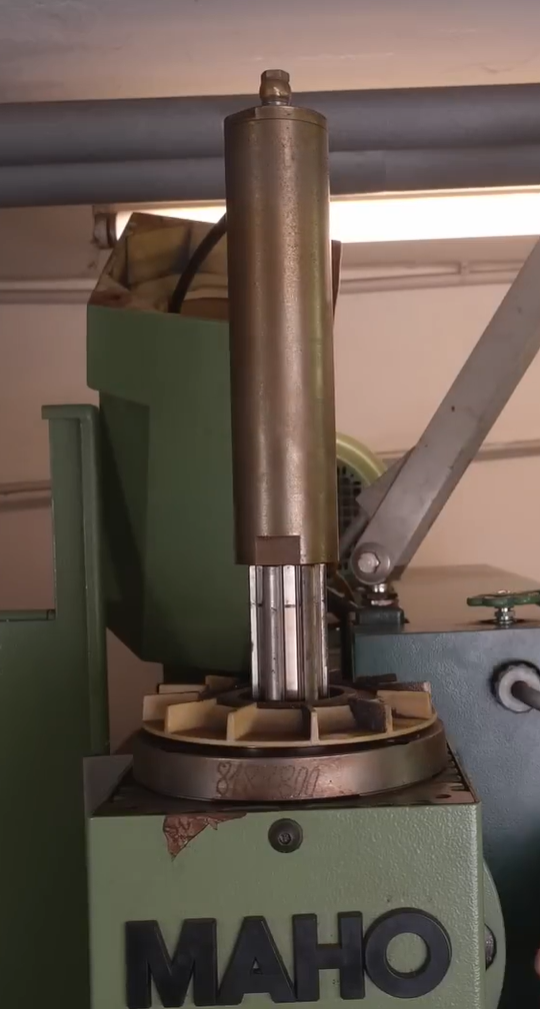
Since we operate in vertical milling mode 99.9% of the time, we need to read the spindle position somewhere on the vertical milling head. Our current plan is to design and manufacture a resin (or similar) replacement part to substitute the white fan/impeller (or whatever the exact term is). By carefully cutting slots on the back, we should be able to mount an SSI encoder behind the hydraulic drawbar and drive it with a belt. If you have a better idea, let us know :)
We do actually have a second unused channel on the SSI encoder input terminal, eventually we will integrate the horizontal spindle too, but i don't think so.

Picture Source: Your Video "Why does my MAHO CNC spindle rattle? || RotarySMP" @ 1:57 (
)

Please Log in or Create an account to join the conversation.

More
5 months 1 week ago #346571 by Surmetall
Cool project! I like your PDF!

To the spindleencoder a hollow shaft encoder by calt on AliExpress is really low priced and should perfect fit the spindle.

To be honest i never understood why people mount an encoder to the head that is flipped away in horizontal mode. Even if you use it not that often - 50% of cool Features can not use rigid tapping. so you even less will use the cool horizontal mode. not a good place in my opinion. just mount the encoder to the motor and scale with the gearbox and you are happy for the z signal you only need an inductive sensor or similar on the horizontal spindle for reference.


greetings
Tom
The following user(s) said Thank You: PedPEx

Please Log in or Create an account to join the conversation.

More
5 months 1 week ago #346572 by PedPEx
Thank you Tom :)

The current plan is to mount an inductive sensor on the motor shaft and let the VFD count the pulses. That way no additional EtherCAT hardware is required and the VFD (or LinuxCNC) is able to read the motor velocity for a future PID controller or similar. An encoder is not well placed at that spot, because the vertical milling head has quite a bit of dead-zone/backlash. To keep it as simple as possible while being accurate, we decided to mount the encoder on the milling head

Please Log in or Create an account to join the conversation.

More
5 months 1 week ago #346573 by Surmetall
i am aware of the backlash but in this case it doesn't matter.

Please Log in or Create an account to join the conversation.

More
5 months 3 days ago #346741 by PedPEx
Hello guys,

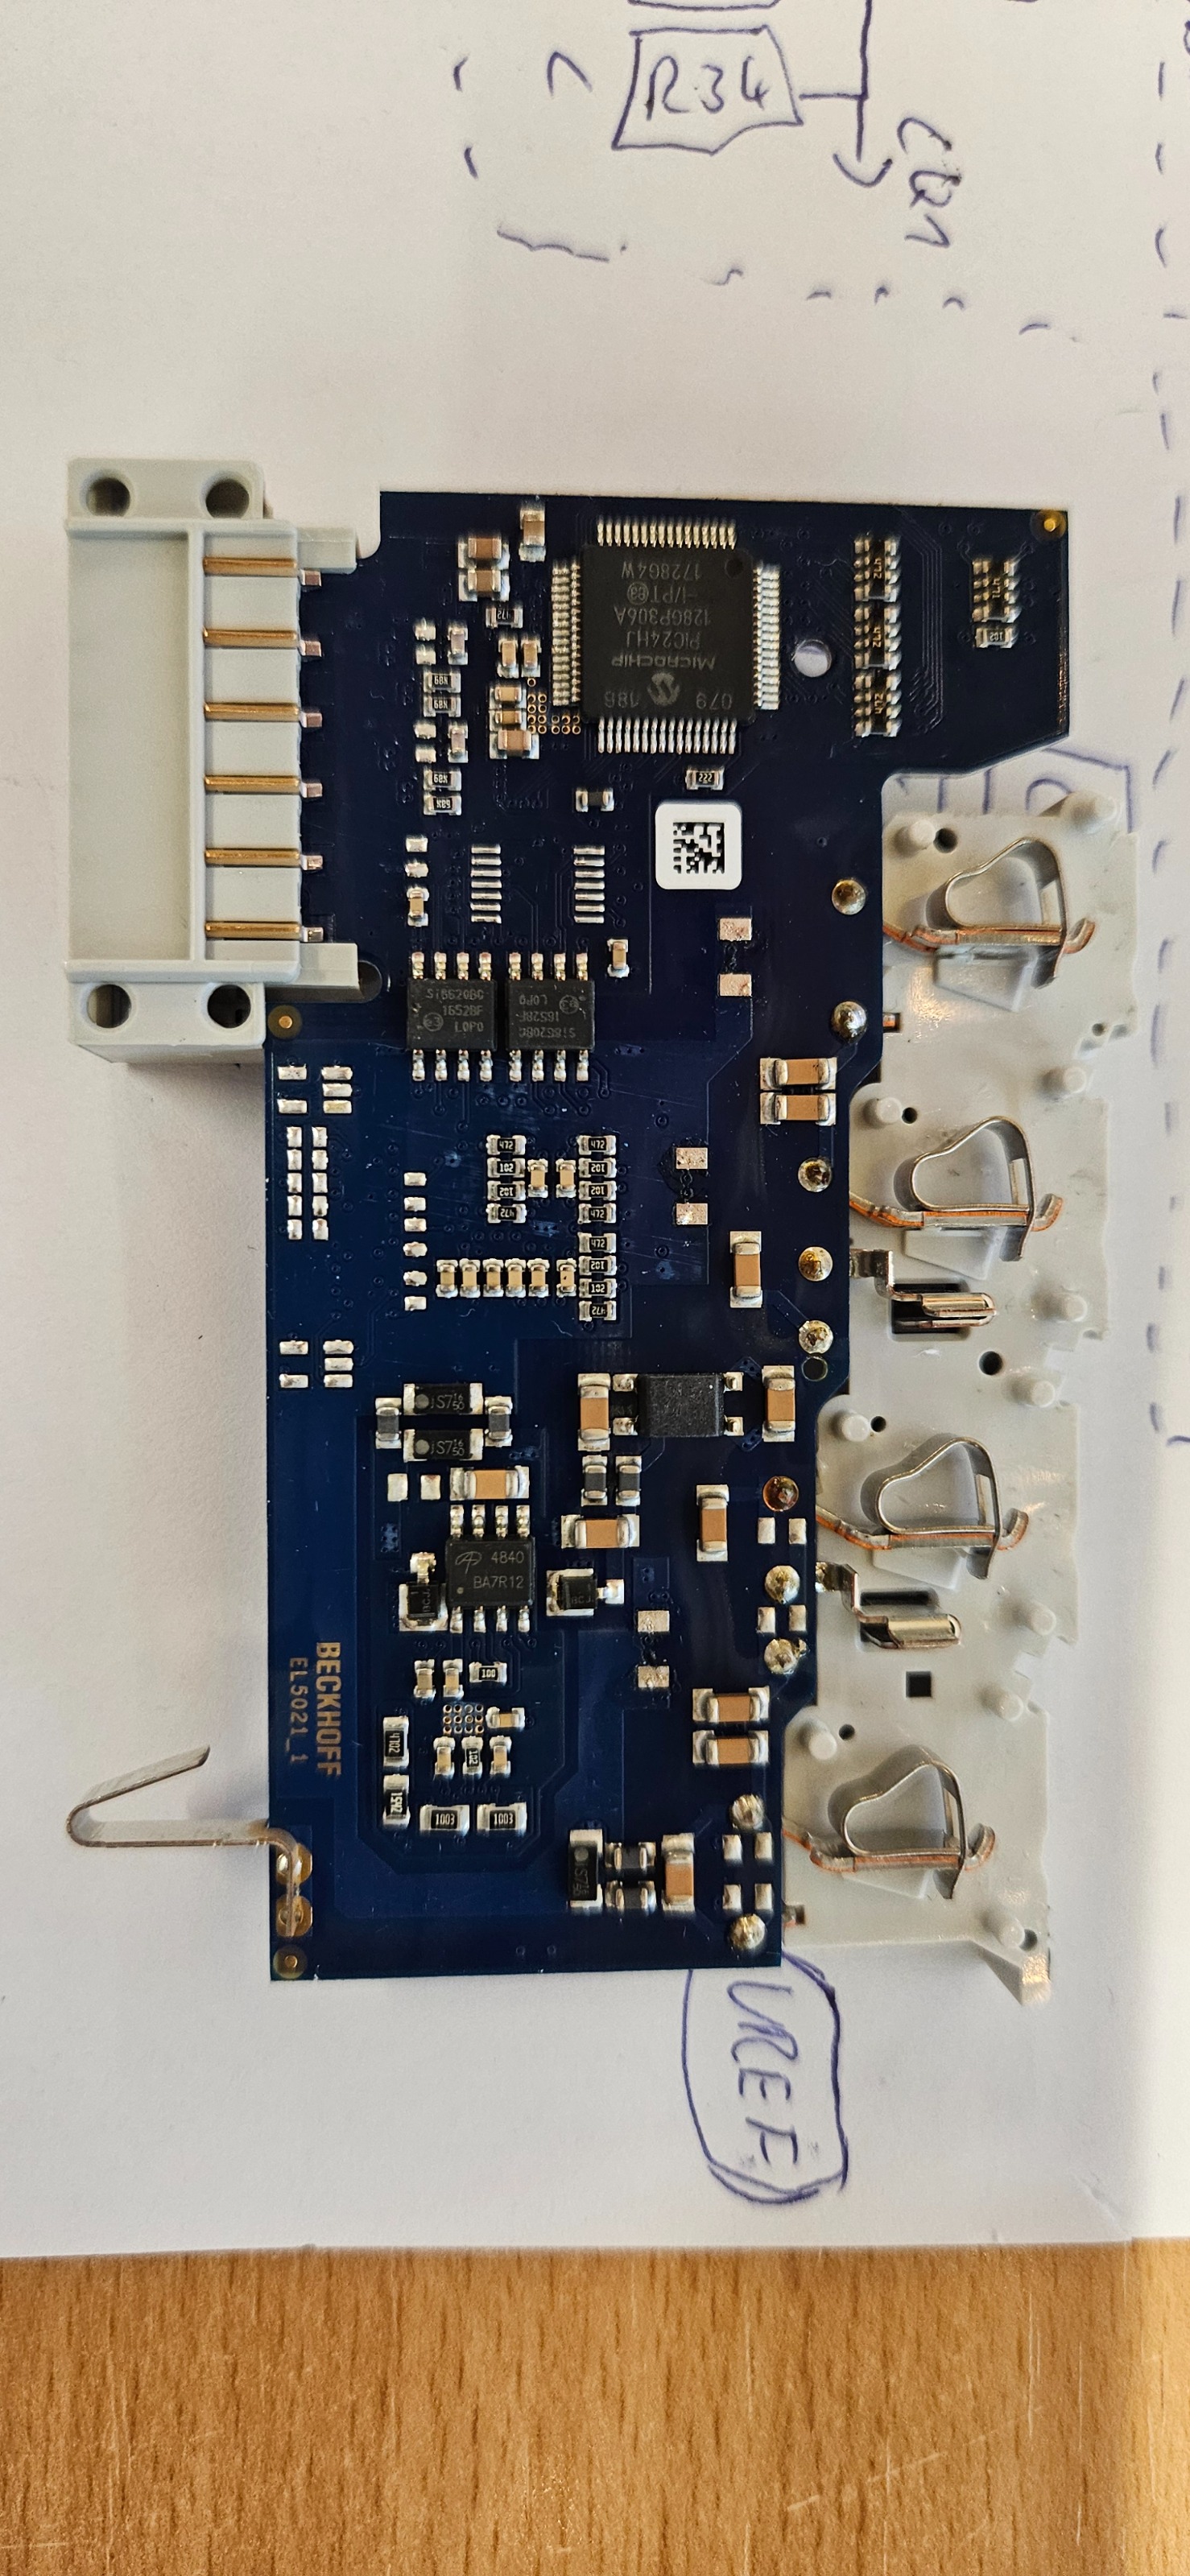
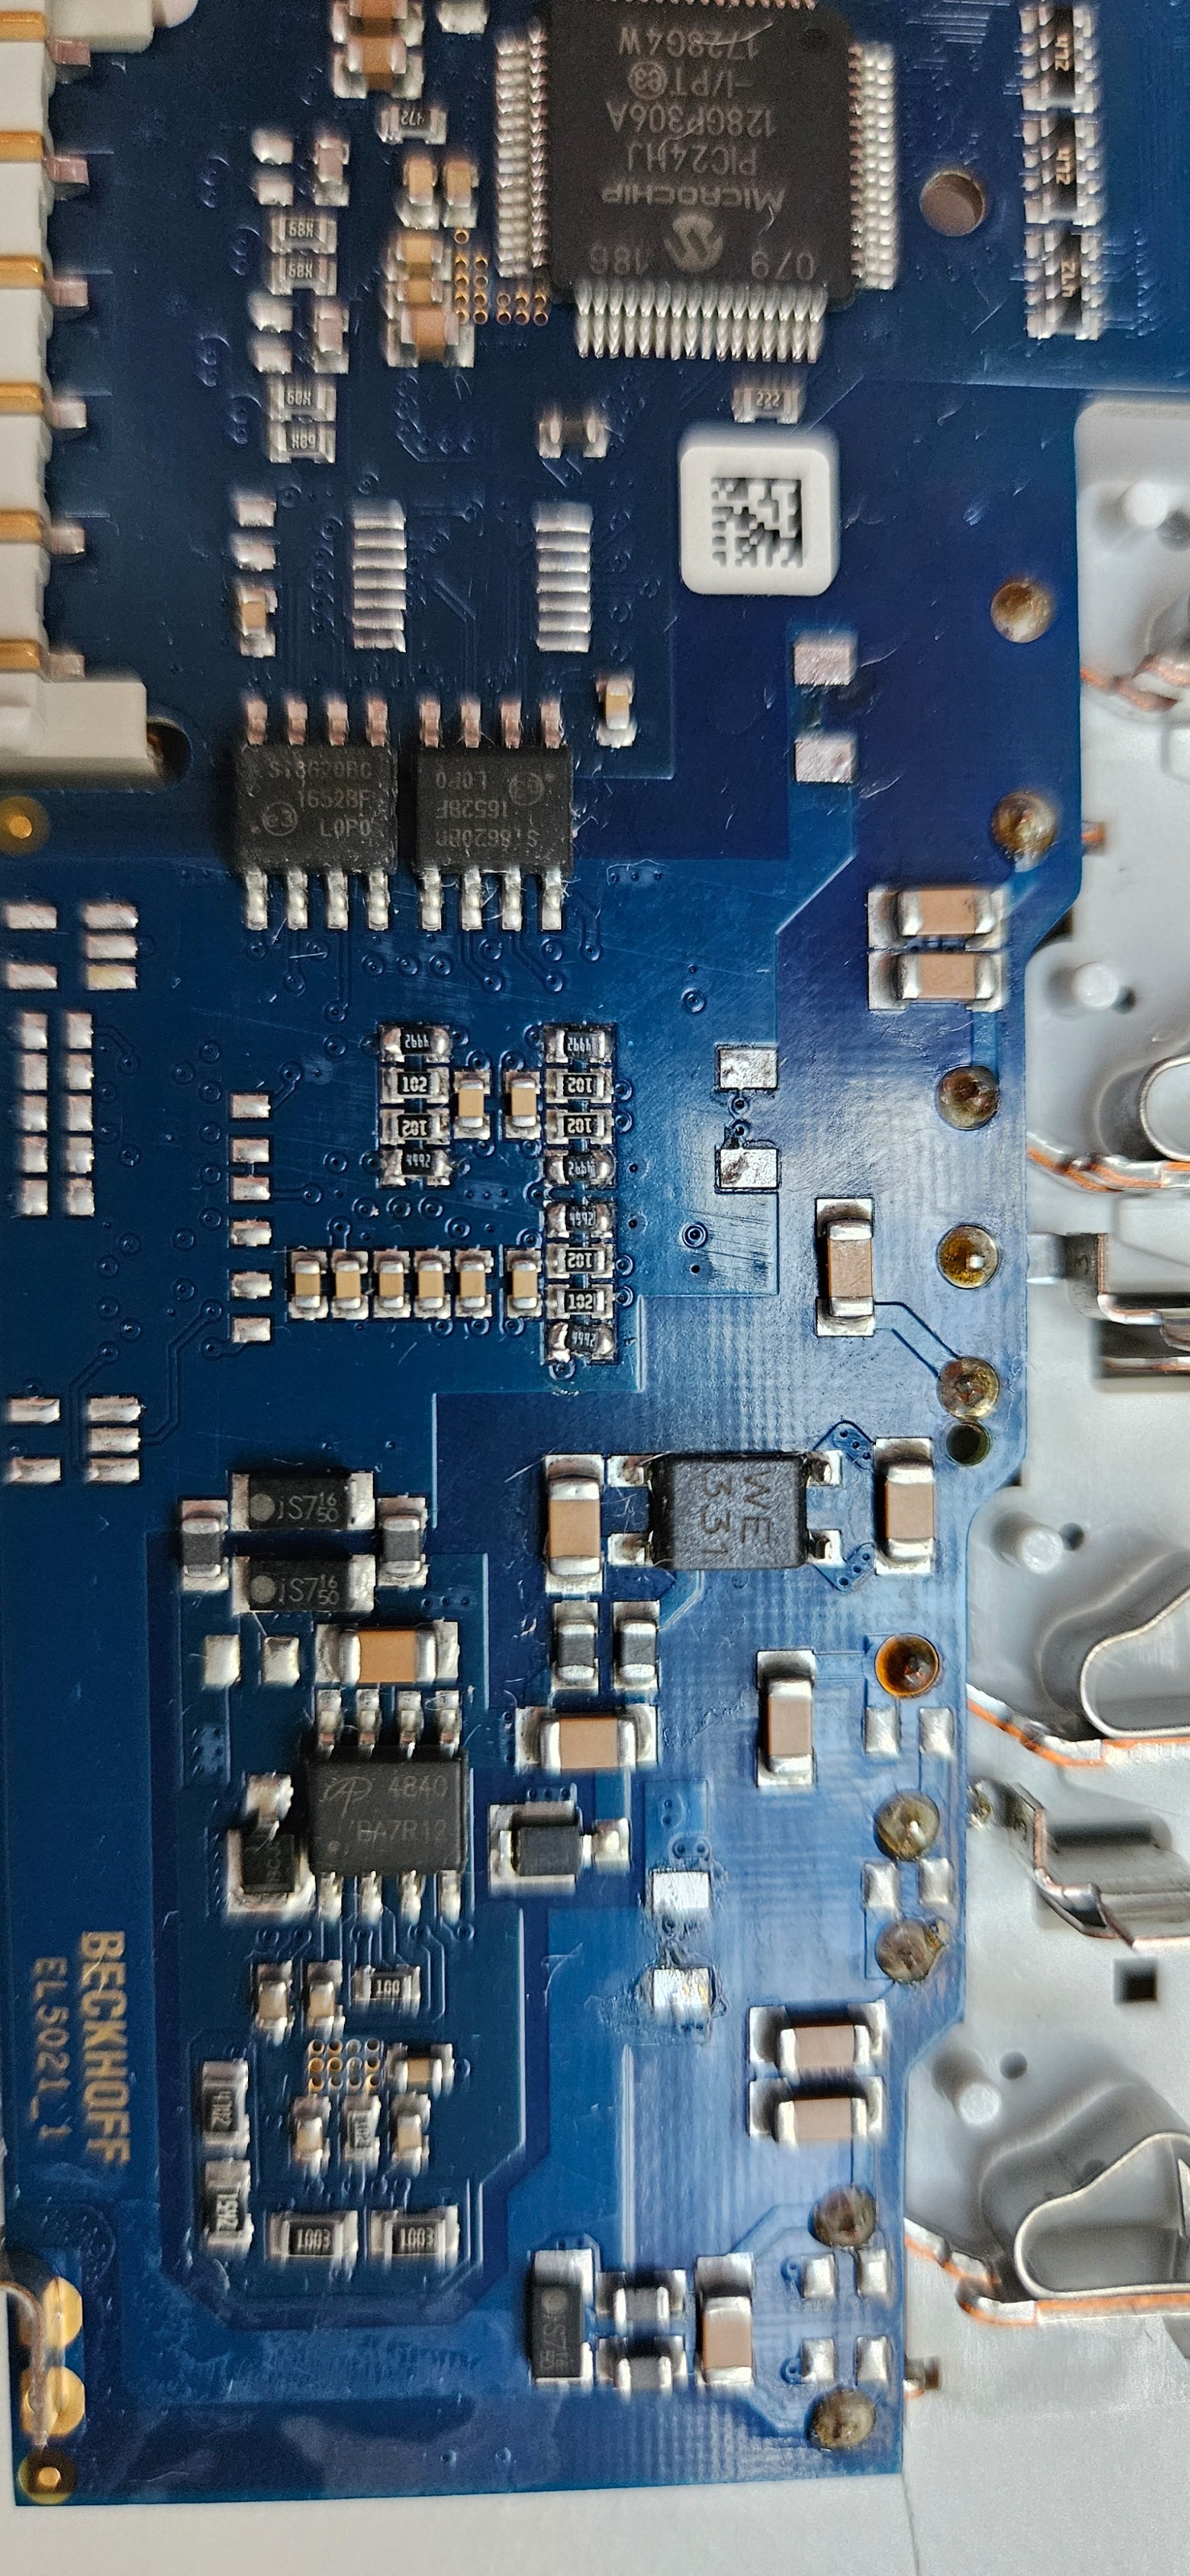
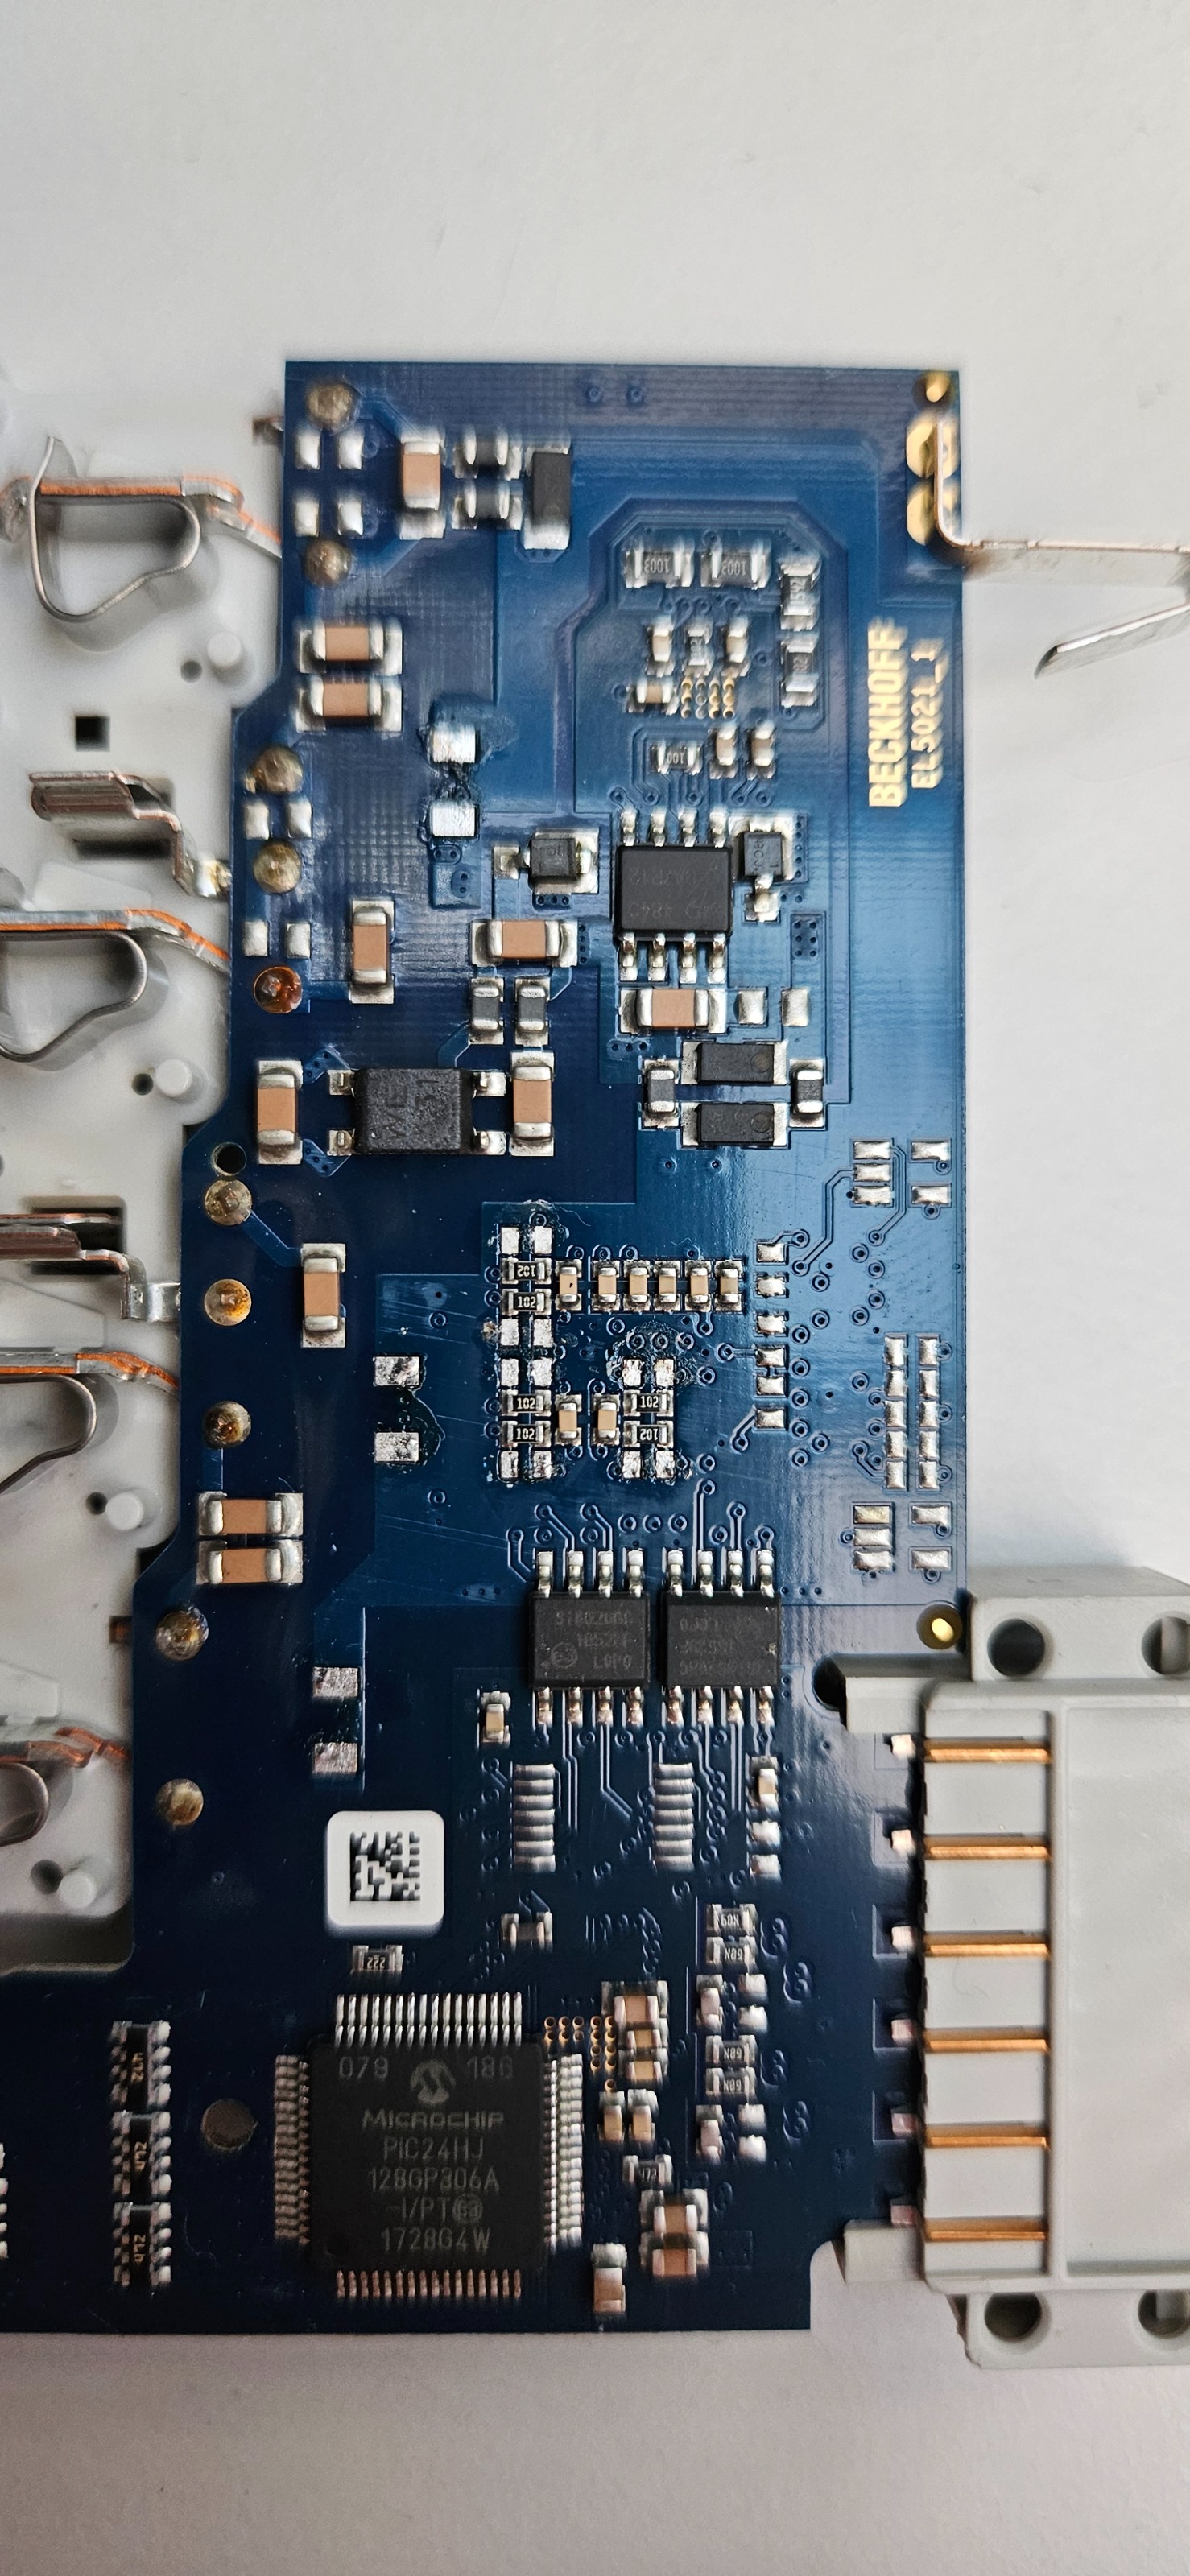
Here is a little update. Since my last post, I had a detailed look at my picture gallery, specifically at the pictures of an EL5021 terminal I bought and disassembled back in early 2025. The original plan back then was to add an axial resistor in order to get it to read 11µA encoder signals. I quickly realized that wouldn't work, took some pictures, reassembled it, and returned it to the seller.

Last weekend, I took another detailed look at the PCB of the EL5021 and recognized the interpolator IC Beckhoff is using: an iC-Haus iC-NQI. For my own interpolator solution, I had actually copied the typical application circuit straight from that datasheet. That's why I immediately reordered an EL5021 terminal off eBay, opened it up, and properly reverse-engineered it today.
Beckhoff is actually following this required application circuit almost exactly ( Datasheet iC-NQI, Page 24, Figure 30 ). They are also using 4.7k Ohm resistors for RS1 and RS2. Those have to be swapped for 50k Ohm ones (I will test if these are too big; possibly 43k or 47k are better suited), and lastly the 120 Ohm resistors need to be removed. This way, the EL5021 terminal should be able to read 11µA sensors. By adding a 120 Ohm axial resistor across each input channel (A & /A, B & /B, and C & /C), the EL5021 can again be used for 1V signals. In theory, it would also support TTL signals, but that is outside the scope of this test.

Other than that, I vibe-coded a CiA402 dashboard tab for LinuxCNC to be able to see any problems with the Danfoss VFD directly in one place, without needing to decode the status word or the command word. The Danfoss VFD is now also able to read the frequency of an inductive sensor, internally calculates the motor speed, and reports that speed back via a PDO as feedback speed.

Additionally, the decision was made not to keep the original relay-based DC gearmotor solution, but to switch to two Beckhoff EL7332 terminals. Details about that coming soon™.

I'll test the functionality of the modified EL5021 terminal and keep you posted :) Wishing you all a great weekend!
The following user(s) said Thank You: rodw, Surmetall

Please Log in or Create an account to join the conversation.

More
5 months 2 days ago #346769 by vibram
Awesome work Patrick!
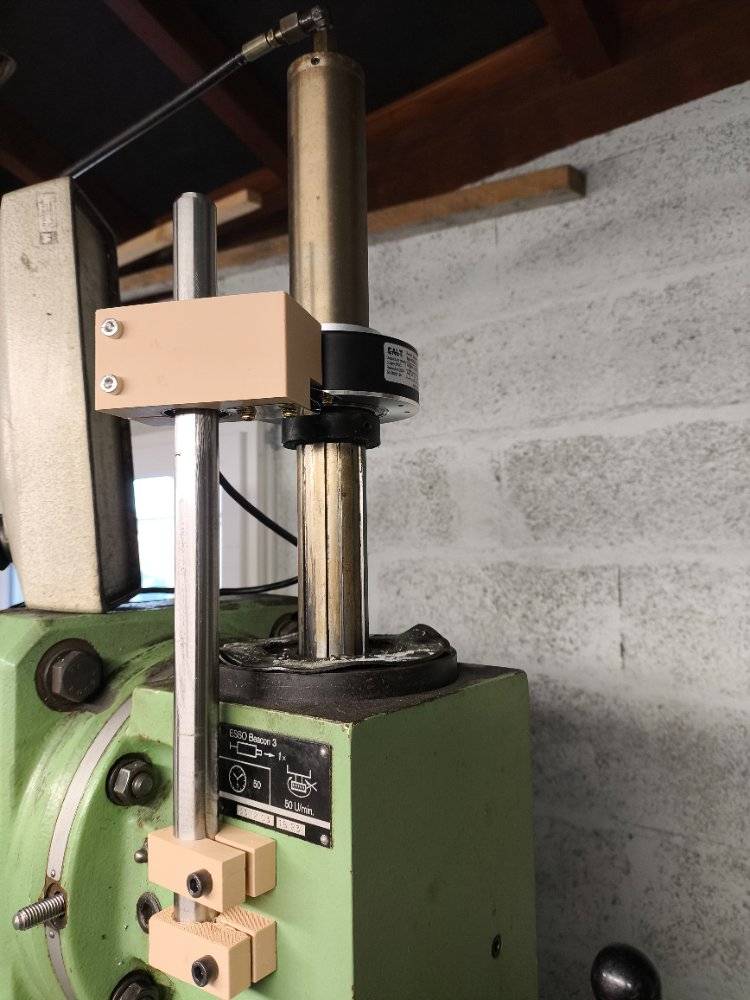
Regarding the spindle, here is my solution for a similar setup, the idea was to be able to keep the drilling operation possible. It works well 
 
The following user(s) said Thank You: PedPEx

Please Log in or Create an account to join the conversation.

Time to create page: 0.113 seconds
Powered by Kunena Forum