Stepperonline A6 Ethercat - Digital IO [SOLVED]

More
5 months 6 days ago #346656 by rodw
PRogress!
The vendor supplied XML can go in the bin with the rest of your windows stuff. its for twincat. So explained. I have never used this stuff.

Quickest way to test outputs is to hook up an output to coolant or mist so you can trigger with GUI or MDI command

Please Log in or Create an account to join the conversation.

More
5 months 6 days ago #346664 by spumco

PRogress!
The vendor supplied XML can go in the bin with the rest of your windows stuff. its for twincat. So explained. I have never used this stuff.

Quickest way to test outputs is to hook up an output to coolant or mist so you can trigger with GUI or MDI command
Rod - I appreciate your suggestions, but we seem to be talking past each other.

I know - have known since I started - the vendor xml file is useless for LCNC.  I was hoping someone more experienced could interpret the vendor xml file to see if the output bit(s) required were buried or presented inside the file.

The quickest way to test outputs is to simply trigger them in halshow; no need to net them to coolant or mist or anything.  This is what I've been doing the whole time I've been fiddling with the outputs.

The drive has been communicating with LCNC since the 1st post in this thread.  As long as I don't flub the xml file edits I've had no problems with the connection & communication between LCNC and the drive.

I just received a reply from Stepperonline regarding the outputs.  I'll test later tonight, but it appears the original OEM (JSS Motors) failed to document anything about the outputs.  Stepperonline was kind enough to supply information about some required parameters (again, undocumented) and the Ethercat addresses/bits needed to trigger the outputs.

I'll post the information later for future reference once I've confirmed it works.
The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.

More
5 months 5 days ago #346684 by spumco
Success.

My suspicions were correct - there are undocumented parameters to set in the drive before the digital outputs can be activated.

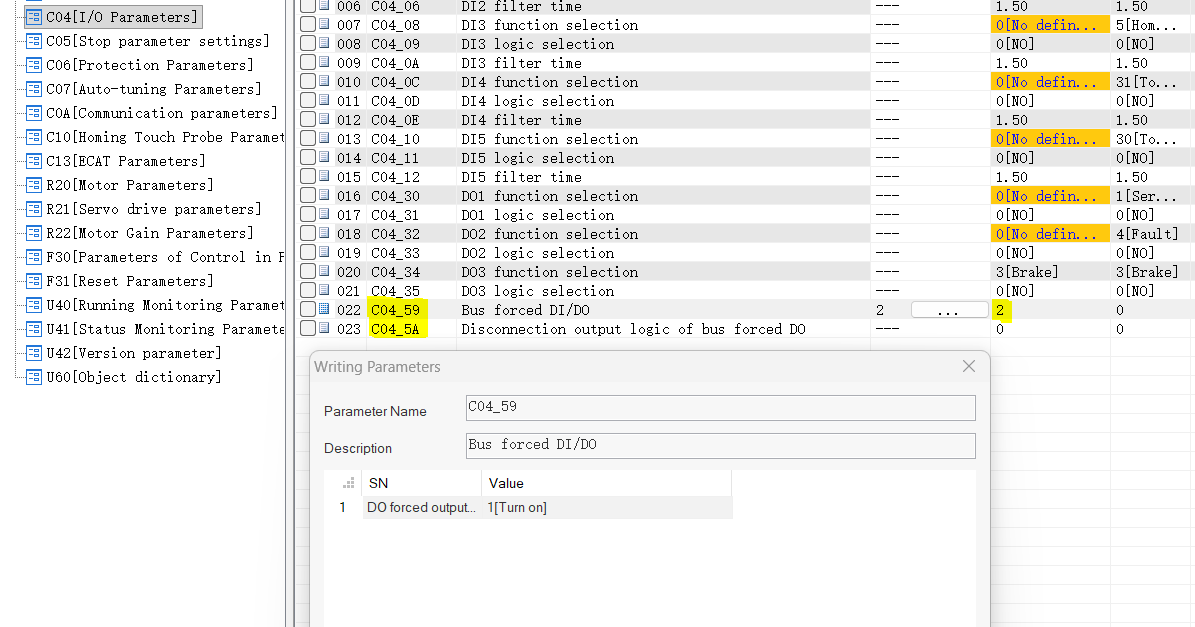
Stepperonline advised the following:
Warning: Spoiler!


Parameters C04.59 and C04.5A are not in the manual.  They are, however, visible in the tuning software (see attached screenshot).

I've attached a bare-bones xml file which will create HAL pins for all five digital inputs, and two of the three digital outputs.  The last output - DO3 - is reserved for the motor brake and commented out.

As usual, thanks to everyone for helping out.  

MODERATORS - please change title to:  Stepperonline A6 Ethercat - Digital IO [SOLVED]
The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.

More
5 months 5 days ago #346685 by tommylight

MODERATORS - please change title to:  Stepperonline A6 Ethercat - Digital IO [SOLVED]
Done, thank you.

ASUS ROG Crosshair VIII Impact - AMD X570
The following user(s) said Thank You: rodw, spumco

Please Log in or Create an account to join the conversation.

More
5 months 3 days ago #346717 by rodw
Great you worked it out. But normally, there will also be settings to tell the type of input. eg, GPIO, Max Limit, Min Limit, Estop (disable drive),
Did you work that out too? eg If you want to use as GPIO, you need to set the type to be GPIO for a specific pin for internnalhoming, you need to set homing.

Please Log in or Create an account to join the conversation.
More
5 months 3 days ago #346730 by spumco

Great you worked it out. But normally, there will also be settings to tell the type of input. eg, GPIO, Max Limit, Min Limit, Estop (disable drive),
Did you work that out too? eg If you want to use as GPIO, you need to set the type to be GPIO for a specific pin for internnalhoming, you need to set homing.

Yes, I worked that out, too.  I'd already set the DIO appropriately before starting this thread.

Unlike the missing output information, the manual is explicit on DIO function configuration:
  • Via parameters:
    • DI - C04.00-C04.12
    • DO - C04.30-C04.35
  • Via Ethercat:
    • 2004, sub-index 01 through 36
As I stated in my first post, this was a only basic bench test to explore the drive's IO with some buttons and LED's.
The following user(s) said Thank You: rodw

Please Log in or Create an account to join the conversation.

Time to create page: 0.492 seconds
Powered by Kunena Forum
