lcec_conf exited without becoming ready

More
1 month 1 week ago #349791 by rodw
Nobody knows  you VFD so you need to work it out yourself, it seems there is a syntax error in your xml and it reports the line number.
Sharing your xml file now you have  made some progress would be helpful. as we are flying blind
I suspect you will need to command it more like it was a servo except use a mode that commands RPM (velocity) not position 

Please Log in or Create an account to join the conversation.

More
1 month 1 week ago - 1 month 1 week ago #349796 by viesturs.lacis
I found this document:
library.e.abb.com/public/52b4831c464449e..._CiA402_Rev_A_EN.pdf

that is where I found which parameters to set to enable the ethercat module. at the moment I have:
1) set 50.01 parameter to 1 (enable the module)
2) 51.01 to 135 (set to EtherCAT)
3) 50.04 to 4 (reference is speed)
4) 51.02 to 0 (CiA402 drive profile)
and attached is the XML file. I would appreciate any hints on how to get it move the motor (I am looking for basic functions - start/stop and set the rotation speed). any extras, like spindle-at-speed signal, what is motor load etc is optional
I am looking at that manual and it is very confusing for me about the bits of command word and status word. I believe it is handled by cia402 component and I just need to connect proper HAL pins. is that correct?
Last edit: 1 month 1 week ago by viesturs.lacis.

Please Log in or Create an account to join the conversation.
More
1 month 1 week ago #349797 by rodw
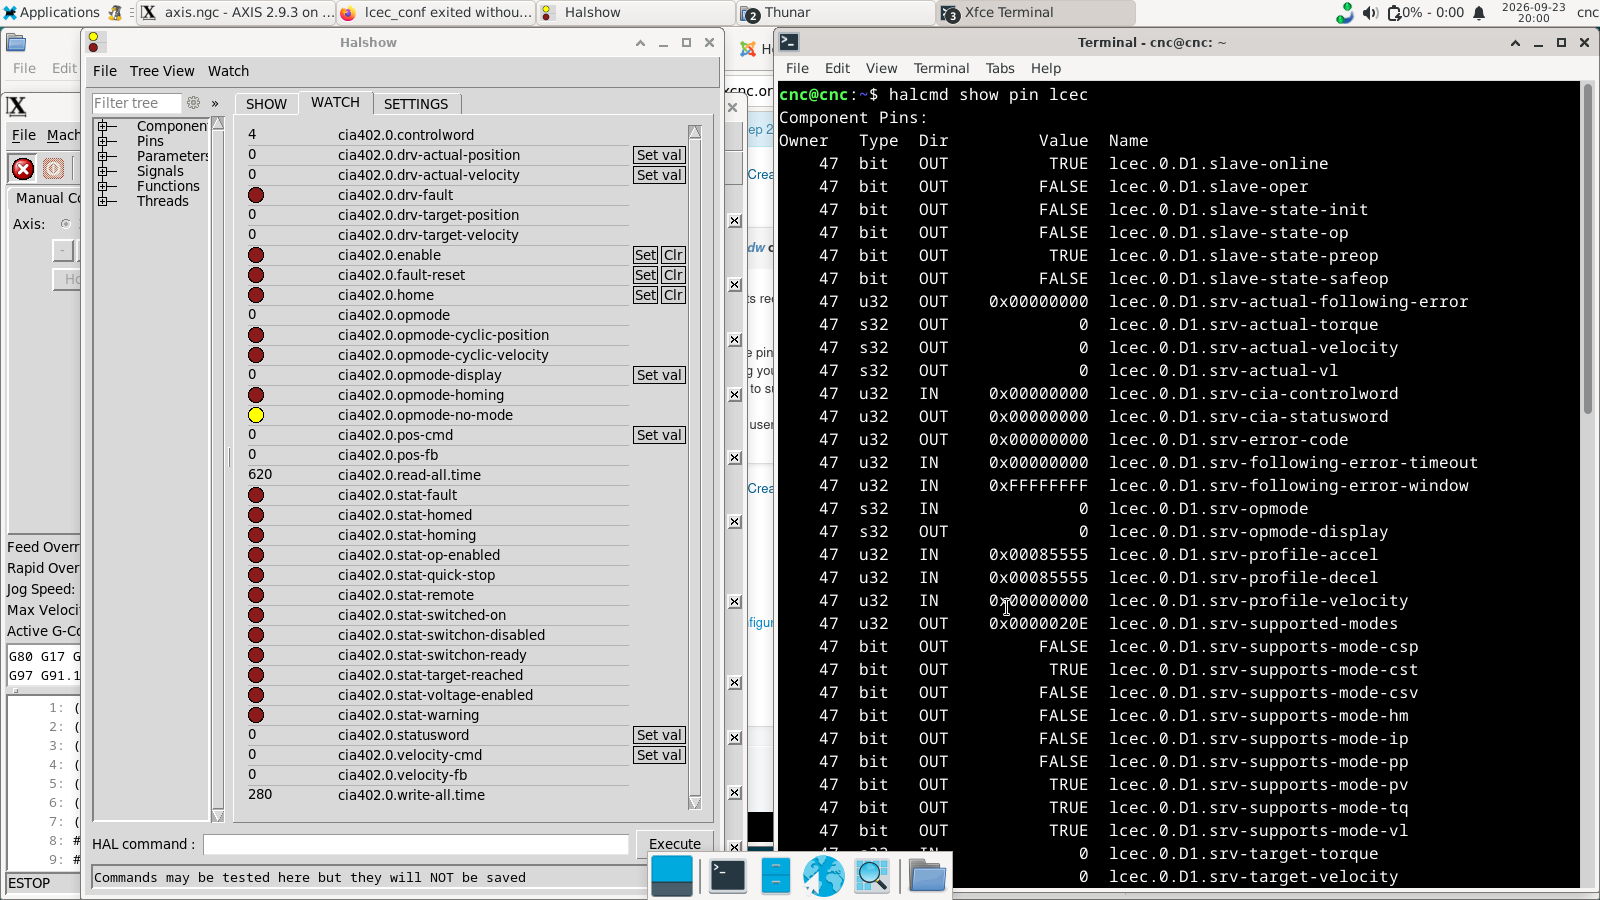
It seems that its recognized as a cia402 device. at this point, with LinuxCNC open, open another window and type: halcmd show pin lcec

This will list the pins they were found. You can use them in your hal file and follow the cia402 templates.
I have a feeling you need to command your drive using a mode not supported by the cia402 component. It will need modifying and rebuilding to support it. But I can't help you there as I have no expereince. Someone else may be able to help.

I do know one user using an abb VFD but they are using MODBUS 485 to avoid buying the FECA-01 interface
The following user(s) said Thank You: viesturs.lacis

Please Log in or Create an account to join the conversation.
More
1 month 1 week ago - 1 month 1 week ago #349812 by viesturs.lacis
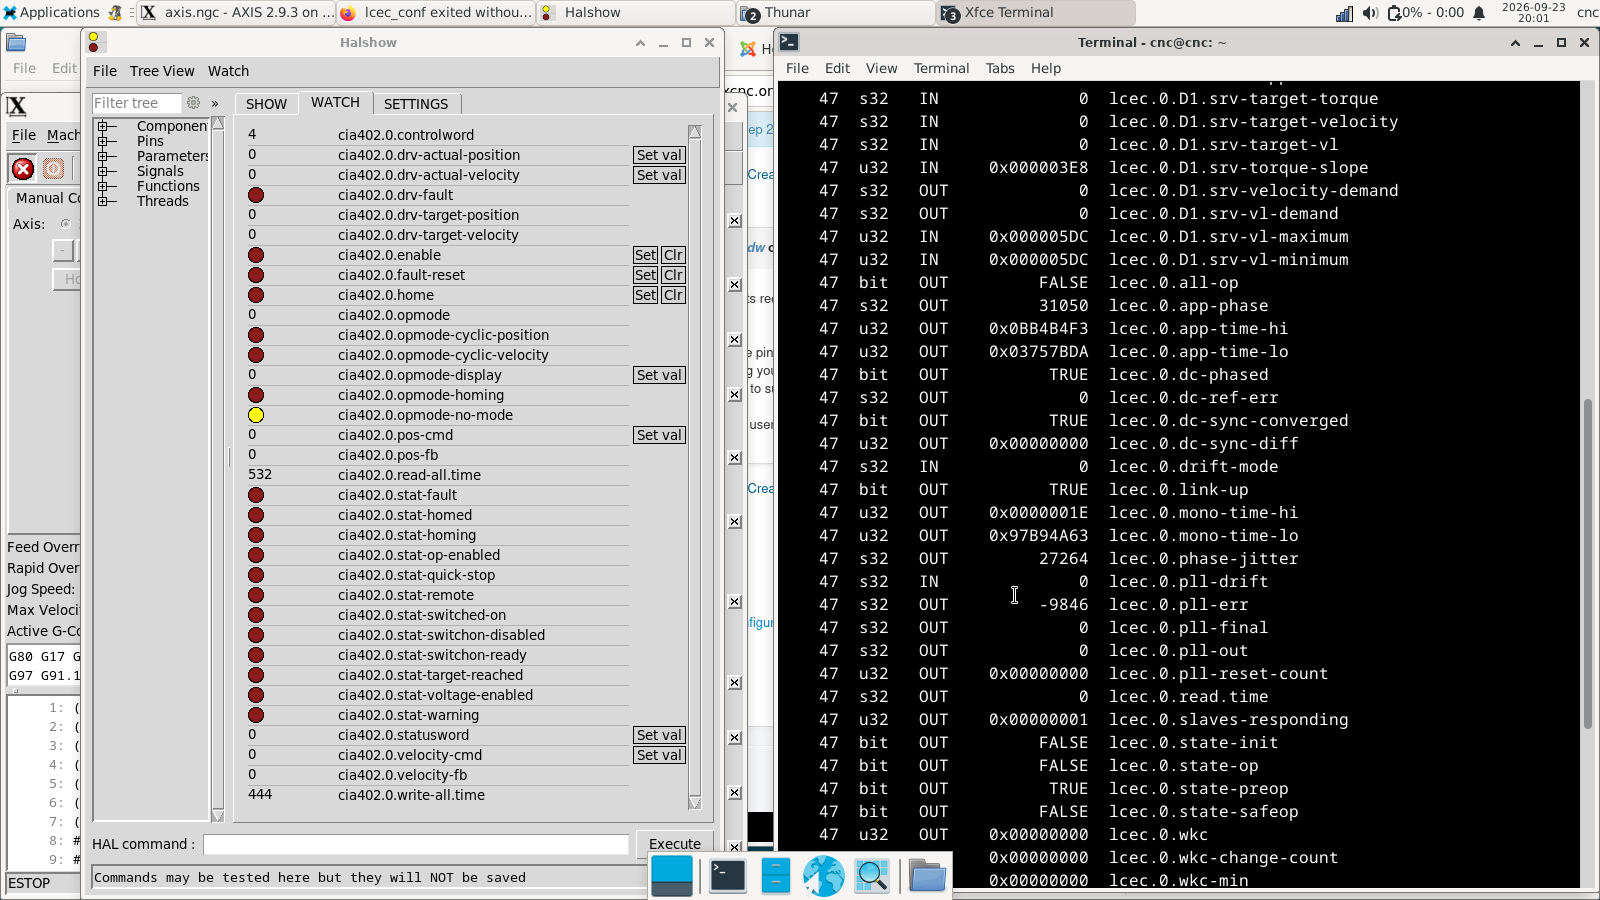
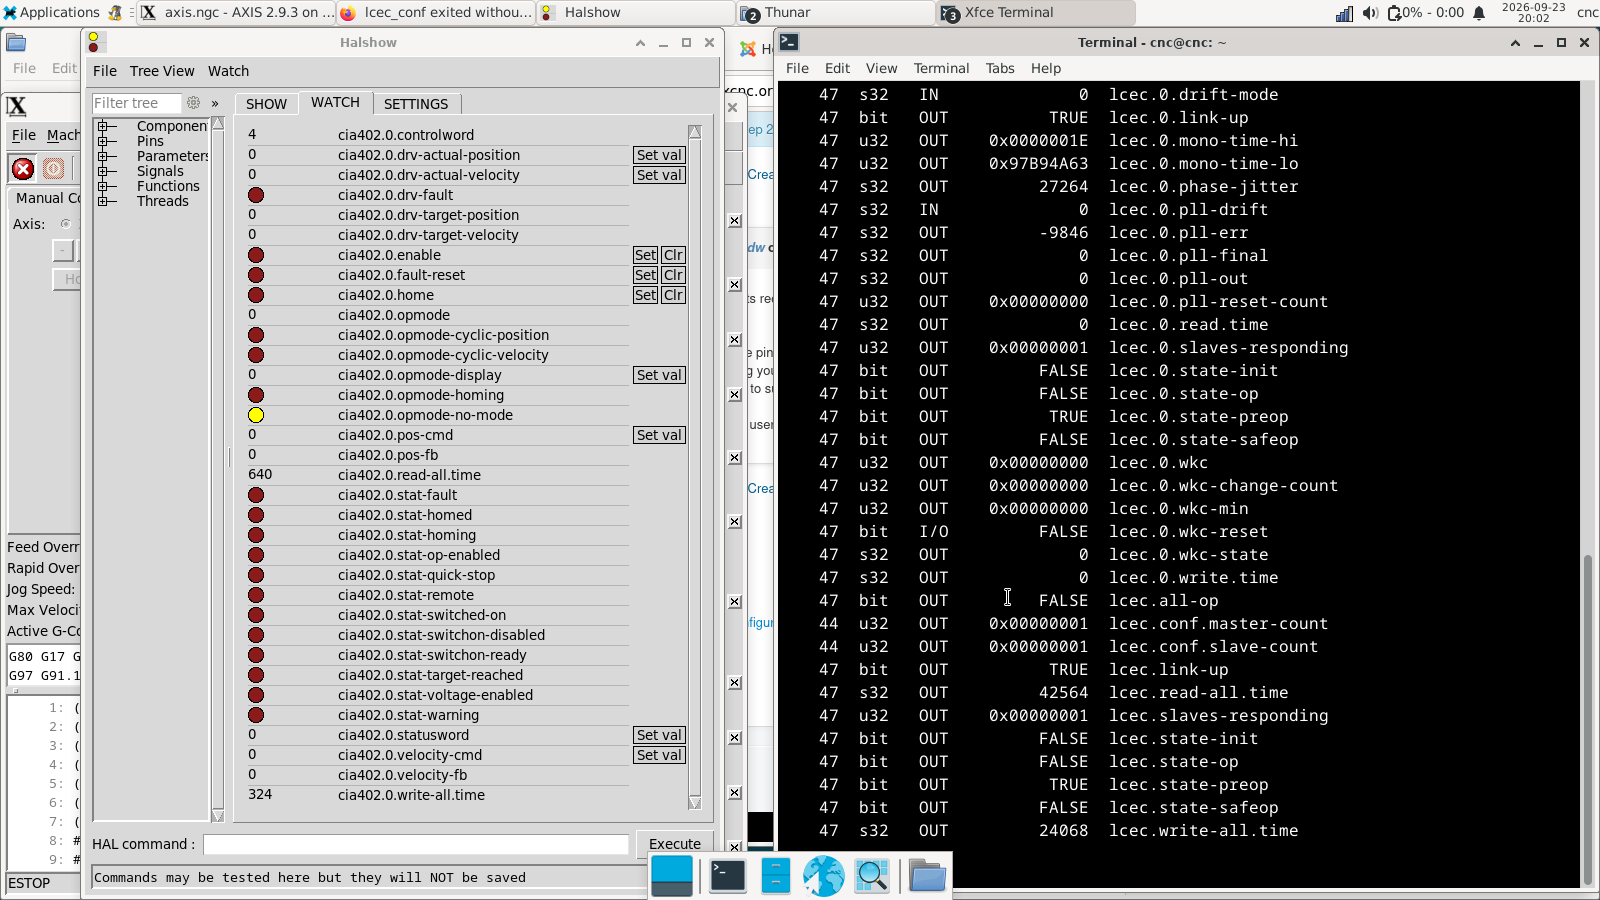
please find attached 3 screenshots - left side are all the pins for cia402 component (they did all fit in screen) and right side is list of lcec pins in terminal. do you have any idea, which of these is "enable" pin? lcec.0.state-preop, lcec.0.state-safeop and lcec.0.state-op seem suspicious to me but then I do not understand why would 3 pins be needed. I would appreciate some hints on which pins should I try for enabling the drive and which would be most suitable candidate for making the motor spin. cia402.0.velocity-cmd would seem like most obvious candidate but is there anything else to add (so far in my experience it would have been 2 pins - one sets velocity, the other would be a bit output for "run/stop")
BTW cia402.0.controlword has value 4, which seem to match instructions in manual to set the parameter 50.04 to 4 (which means that reference is speed). does that help in any way? and since the manual says this:"Ensure the drive profile parameter 51.02 is set to CiA402 (0)" I would like to think that it's all good regarding the suspicion about needing different mode rather than cia402.
could you please share some link where I could see some cia402 templates that you mentioned?
Last edit: 1 month 1 week ago by viesturs.lacis.

Please Log in or Create an account to join the conversation.
More
1 month 1 week ago #349826 by rodw
Take the time to read the cia402.comp source and example. I was wrong, cia492.comp includes a pin to select PV (velocity) mode which is what you want. 

I'd probably edit the name in your XML to be S0 instead of D1. this will make more sense when assiging pins to spindle.0
There are pins for target_velocity and actual_velocity (encoder feedback) so you are getting close. I think that your spindle speed-cmd pin should map to target_velocity and be sure the encoder is properly scaled.
I'm not sure how to map spindle.0.on to enable the motor.
spindle at speed would use the near component between  target_velocity and actual_velocity
to capture a long list of pins you can add > pins.txt to the show pin command to write output to a file
The following user(s) said Thank You: viesturs.lacis

Please Log in or Create an account to join the conversation.

More
1 month 2 days ago #350006 by viesturs.lacis
I just wanted to post a little update - I got to the point where lcec HAL pins reflect parameters saved in VFD drive (min and max velocity) which makes me think that EtherCAT communiction is actually working, but I cannot get the VFD to switch its modes. I was switching cia402.enable pin on and off, controlword value was changing (I had connected cia402.controlword with lcec.0.[some_more_symbols].controlword) but lcec mode pins never changed their value.
On the nameplate of VFD among all the numbers etc there is a letter which according to manual means that the drive was preconfigured when ordering for some (unknown to me) addon module. And drive shows error A7AB which means that the drive does not find the module it has been configured for. And since that is a second-hand drive I have no way of finding out more.
Long story short - I gave up on my attempts to get this drive to work with EtherCAT and already told that to my customer.
Rod thank you for your time and effort helping me on this one!

Please Log in or Create an account to join the conversation.

Time to create page: 0.389 seconds
Powered by Kunena Forum
