Advanced Search

Search Results (Searched for: )

  • Dudelbert
  • Dudelbert
14 Nov 2026 03:09
Replied by Dudelbert on topic I Made a CAM Program for My Lathe (AI Made It)*

I Made a CAM Program for My Lathe (AI Made It)*

Category: CAD CAM

I have decent knowledge of C/C++, mostly from working with embedded systems.

It took me about two full-time weeks of development to get most of the way there, spread over a period of roughly four weeks.

I chose Python because I had heard that AI is particularly good at writing it. After working with it for a while, though, I realised that if I were to start the project again, I would probably choose C++ instead.

The project started as an experiment, so initially I essentially gave Claude a two-sentence explanation of what I wanted and told it to go ham. Needless to say, the results weren't particularly good, although I didn't expect them to be.
What worked much better was giving it a relatively detailed explanation of the idea, letting it explain back how it understood the requirements, and then refining and expanding on that through a few iterations. Once we had a shared understanding of the project, I asked it to write a specification. That approach worked quite well for me.
I created the initial CLAUDE.md file myself, but gave Claude permission to adapt and update it as the project evolved. Sometimes it makes changes that aren't quite right, so I occasionally go in and correct things manually.

Most of the development was done using a single Claude Sonnet 5.5 agent in VS Code.

Radius compensation wasn't particularly difficult. The main challenge was describing the analytical solver for the general toolpath in enough detail. Once that was properly implemented, radius compensation essentially fell out of the solution for free.

I generally use a single agent. I discuss and plan a feature with Claude, let it implement the solution, and then I go into the GUI and test it myself, checking both functionality and usability.
Based on what I find, I give Claude feedback and we iterate on the implementation. I haven't really experimented with more complex multi-agent workflows or orchestration setups yet.
  • dberegovoy
  • dberegovoy
14 Nov 2026 01:29

Retrofitting an old industrial CNC mill with EtherCAT components - MAHO MH400E

Category: EtherCAT
Thank you so much for sharing this information! I really enjoyed reading through your thread. Could you please let me know the exact model and specs of your Lenovo mini PC?
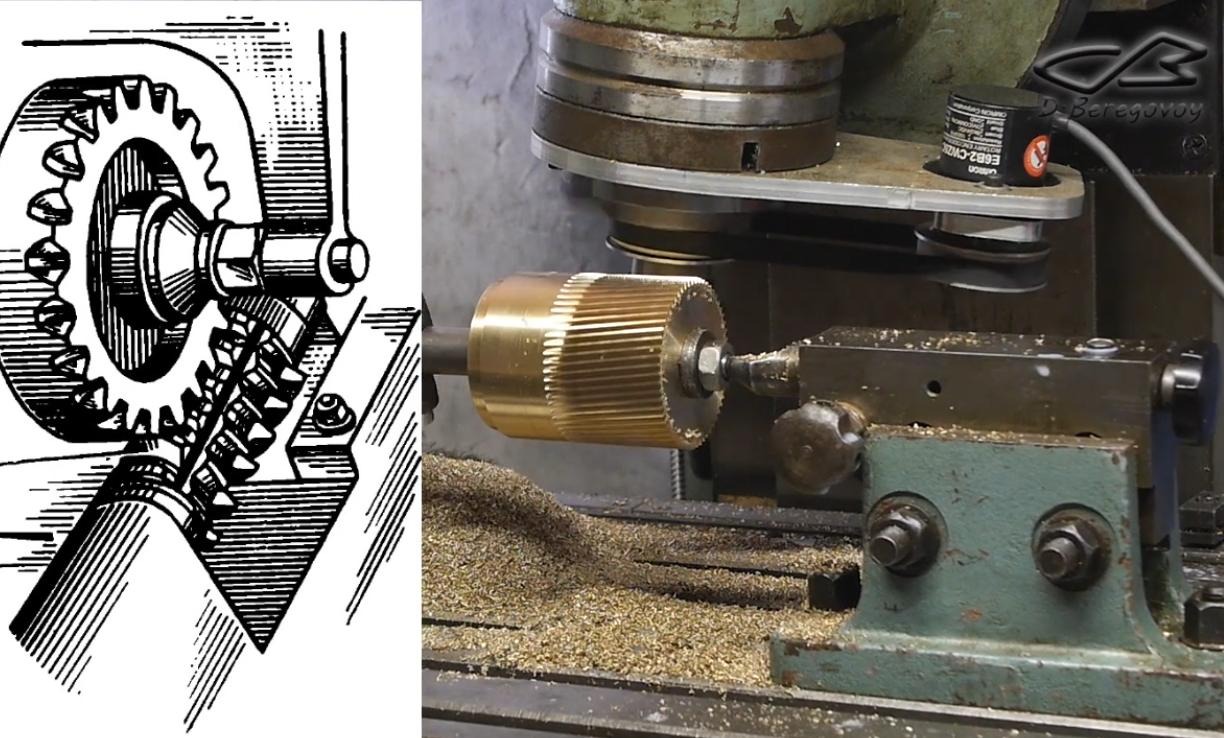
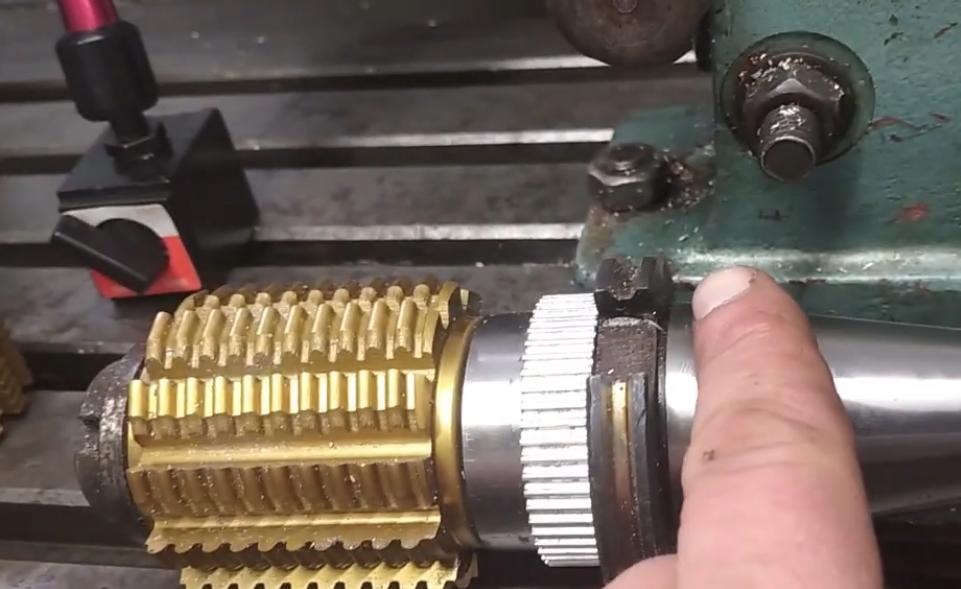
Regarding the encoder—in case anyone is interested in a quick workaround—I once built an electronic dividing head for a manual universal milling machine. The goal was to cut both spur and helical gears using gear hobs (hobbing method).
Since I didn't want the setup to be tied to one specific machine, I mounted a timing pulley directly onto an ISO40 arbor and made a temporary external bracket for the encoder. I fitted a Yaskawa servo motor onto the dividing head, fed the encoder signals straight into the servopack, and simply adjusted the servopack's electronic gearing parameters to match different gear tooth counts. Whenever I needed standard indexing/positioning mode, I just ran it through LinuxCNC.
Here are a few photos (screenshots from my old, abandoned YouTube channel) showing how it was put together:
  • NWE
  • NWE's Avatar
13 Nov 2026 20:10

PancakeSlicer, a Self-hostable and Non-planar 3D Printer Slicer on OrcaSlicer en

Category: Additive Manufacturing

PLA 1.6KG, estimated print time: 9d20h43m, 0.16mm layer height, 0.4mm nozzle. This is with the organic 'tree shaped' supports.
If I completely disable supports it drops to 1.15KG, estimated print time: 4d18h16m.

I got some slicing success with PancakeSlicer, it suggested shorter print times than the above Prusa numbers. Didn't think to grab screenshots, and I have that pc switched off at the moment. I will be trying it out some more and reporting back.
  • andypugh
  • andypugh's Avatar
13 Nov 2026 15:38

carousel - persisting the last state & homing - what is best practice?

Category: General LinuxCNC Questions

If the carousel really _has_ to home then it can't know which way it needs to turn. But I am surprised that a Deckel/Maho carousel doesn't have some sort of absolute position encoding?

To delay the carosel homing until after the other axes have homed, you could interlock in HAL with the homed states of the other axes.
Or, maybe just defer homing until the first programmed toolchange, which ought to be in a safe toolchange position?
  • andypugh
  • andypugh's Avatar
13 Nov 2026 14:13 - 13 Nov 2026 14:13
Replied by andypugh on topic Glade Panel in Axis blocks arrow keys

Glade Panel in Axis blocks arrow keys

Category: AXIS

I have added this bug (and fix) to the issue tracker.
Thanks for your investigations.
github.com/LinuxCNC/linuxcnc/issues/4839
  • Hakan
  • Hakan
13 Nov 2026 13:27
Replied by Hakan on topic New experimental ethercat layer

New experimental ethercat layer

Category: EtherCAT
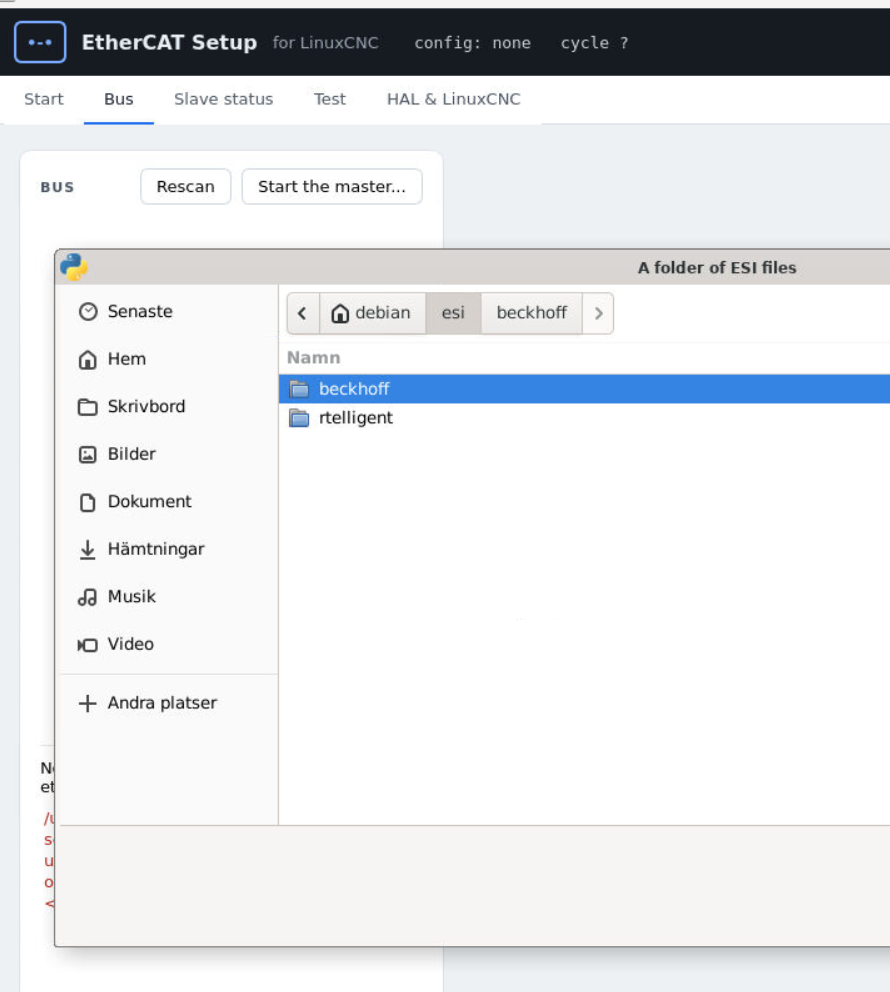
Added functionality to convert an existing lcec/ethercat-conf.xml config to ecat.
This was the missing link. It worked really good for me.

Old and new pin names were recognized and proposed, after looking through the list of affected pin names I pressed one button or maybe two and the config was updated to 2.10 run-in-place and ecat with userspace ethercat master. It started and ran fine, too.
On the way it found the old cia402 component, eliminated it for its' built-in cia402 function.

NOW it's worthwhile testing for those on 2.10.
  • tommylight
  • tommylight's Avatar
13 Nov 2026 12:56

A mill with 3 x 750 W 230 V drive on one phase or every drive on another phase

Category: General LinuxCNC Questions

For 2.2KW of total power, it does not matter at all, single phase is still under it's limit of 3.5KW per socket.
With 3X380V in Europe, you can charge an EV at 11KW without any change to installation, at 22KW if you have an industrial socket around, again no "supercharger" or anything like it.
I can run two plasma cutter at the same time in my shop (total 42KW from two industrial 32A sockets), or another machine at 40KW from a single socket although this complains a bit, but never used for long.
Use good cable, use ferrules, tighten wiring properly, make chips.
  • tommylight
  • tommylight's Avatar
  • Hakan
  • Hakan
13 Nov 2026 11:50
Replied by Hakan on topic New experimental ethercat layer

New experimental ethercat layer

Category: EtherCAT

Pick the folder, go one level up. It reads everything in there and selects the right one based on vid and pid.
I guess you wanted to select a specific one.
 

Pity there with the EL6021. I came up with a way to get access to devices without shipping them.
 
  • Kittifix
  • Kittifix
13 Nov 2026 11:32
Replied by Kittifix on topic New experimental ethercat layer

New experimental ethercat layer

Category: EtherCAT
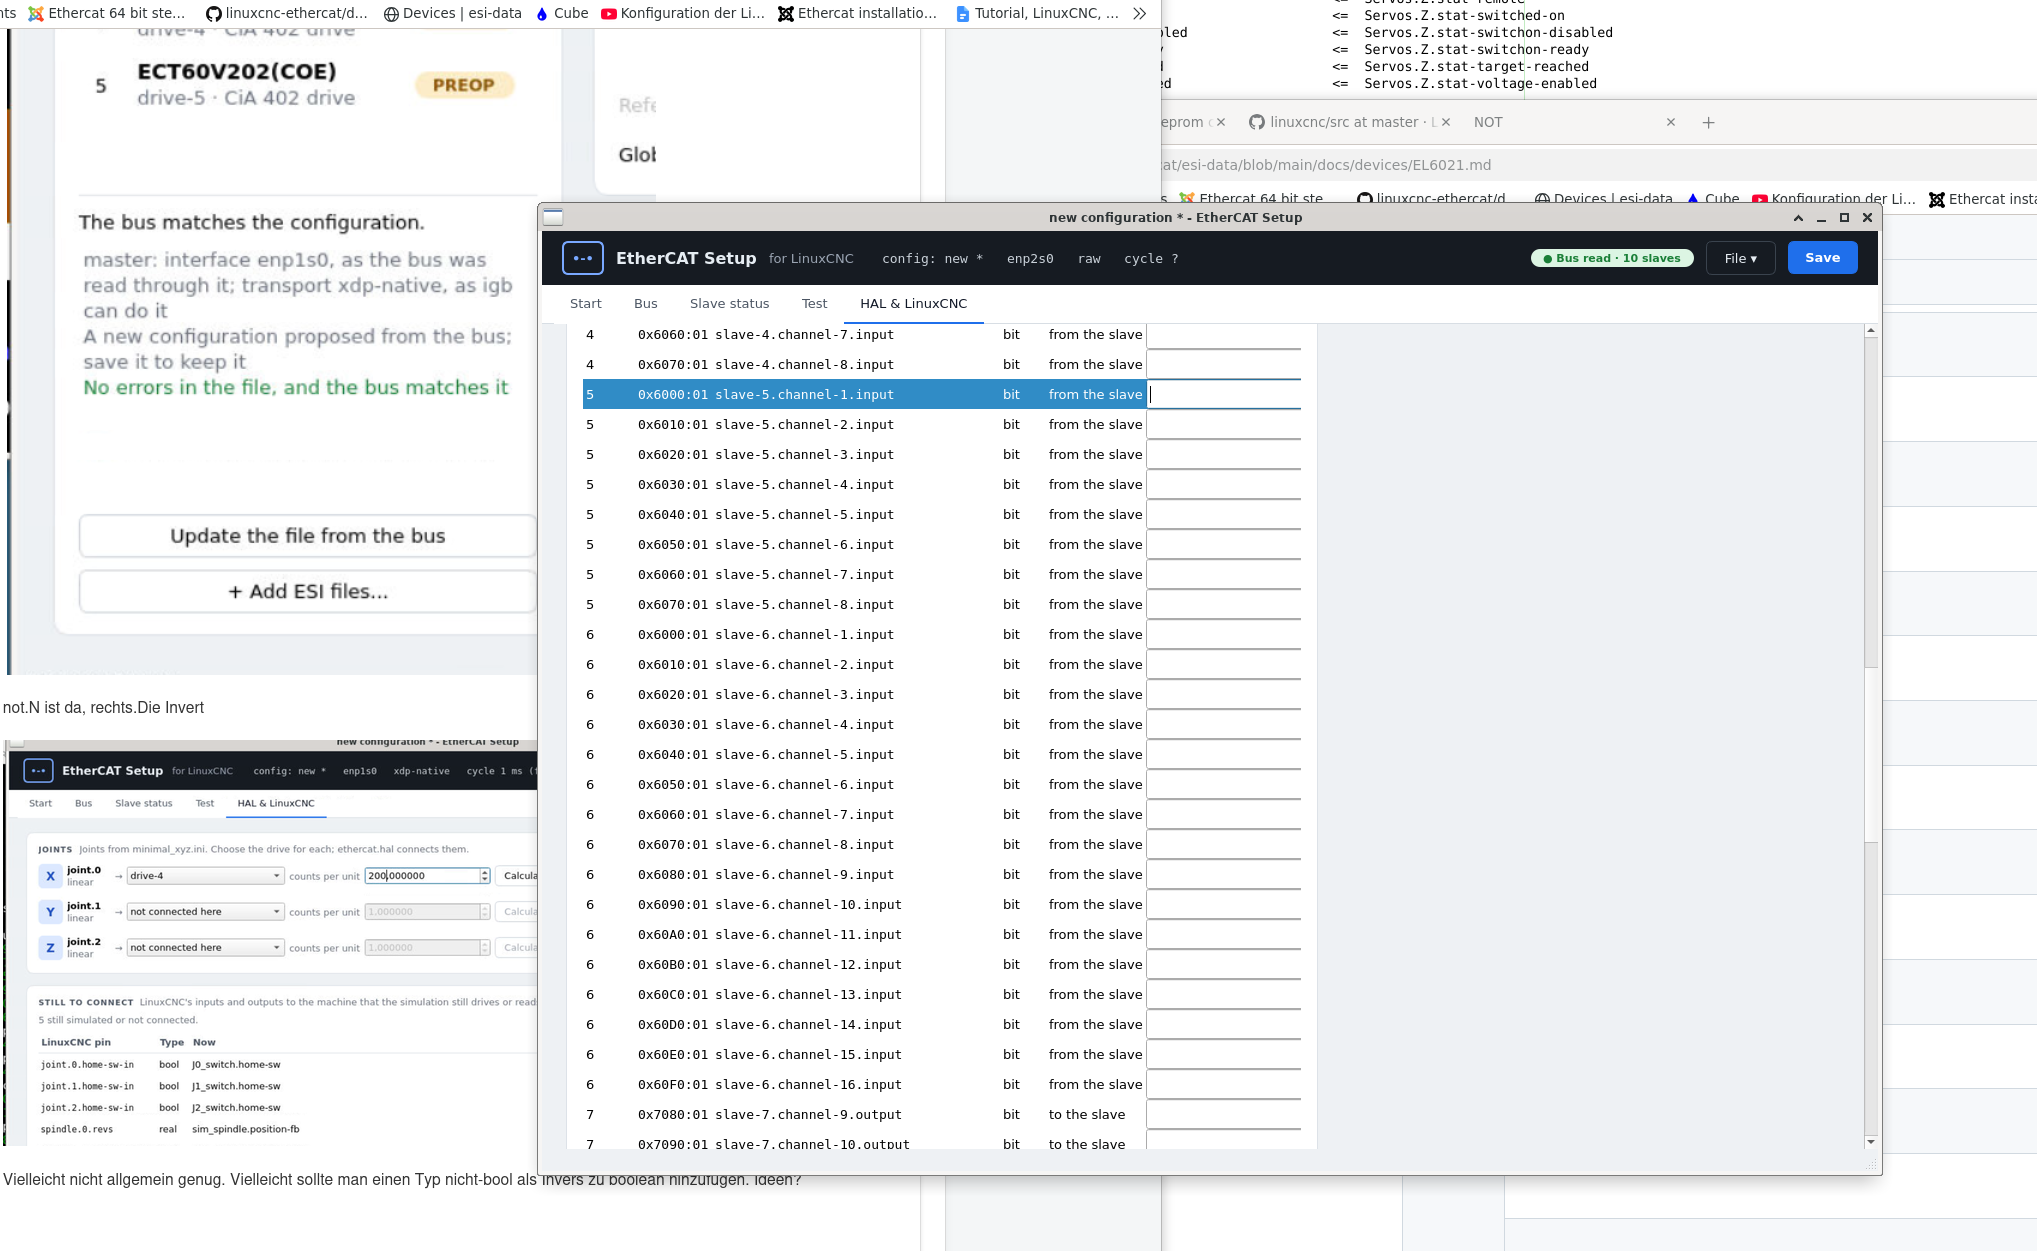
AAAHHH, the inverter was hidden. Then I enlarged the window, and suddenly the button appeared on the right.

I can't open the ESI files, everything is light gray and they can't be selected. chmod didn't change anything about this. 

The control of the VFD via the EL6021 with Modbus is no longer important to me. I got an Omron MX2 with Ethercat at a low price on Ebay. It's also much easier to address all components via Ethercat.


  • NWE
  • NWE's Avatar
13 Nov 2026 10:59

PancakeSlicer, a Self-hostable and Non-planar 3D Printer Slicer on OrcaSlicer en

Category: Additive Manufacturing

This looks like a wonderful idea.
I've been struggling with orienting a large print, depending how I orient it on the plate in Prusa slicer I get one of:
1. Successful print, but top slanted surface is ugly.
2. Nice smooth top surface but very hard to complete the whole print without breaking.

Pancake slicer: this is looking wonderful. But slicing my big part is taking some time, and Pancake error popup claims to have a timeout causing it to give up if slicing takes longer than 15 minutes. Now I am searching for that timeout setting.

This is on a GMKtec mini-pc with Ryzen 7 5825U 8C/16T, up to 4.5GHz boost, 32GB RAM and power limit set to 10W.

At any rate, I will run some small test prints before trying the big one. But I have to wait till the current iteration (sliced on Prusa) is done or breaks. Right now it is at 95 hours print time and 52% complete. It is an electrical enclosure with angled top 380mm x 380mm x 100mm.
  • Maho400P
  • Maho400P
13 Nov 2026 10:48

A mill with 3 x 750 W 230 V drive on one phase or every drive on another phase

Category: General LinuxCNC Questions

Probably the wrong forum but learned that many members are not only good in software, i try this thread.

Building a mill with 3 x 750 W 230 Volt ethercat drives with a power grid [ 3 x 230 volt or 3 x 400 volt/ star triangle

When comparing 1 phase powered servo drives to 3 phase powered servo drives the DC voltage is at one phase motors a little bit noisier.
You could connect all three motors to one phase or every motor to a different phase when having 3 phase power from the net.

What could be the difference on machine performance in the case of situation with one phase compared to the situation with three phases on the noisiness?
The power grid would like the situation with every motor on a different phase but does it produce noise with a higher frequency?

Regards
  • Jokeri
  • Jokeri
13 Nov 2026 10:34

I Made a CAM Program for My Lathe (AI Made It)*

Category: CAD CAM

- What is your experience in coding?
- How long did it take you to get the app to release stage?
- What made you choose python as the coding language?
- What were the first steps that you took when you started developing your app?
- Do you manage claude.md , or do you have the AI to manage it?
- What claude model did you use? what tools did you use?
- What were the difficulties getting the TNRC to work? ( so its calculated to the actual g-code)
- What is your typical claude session? plan ahead then one orchestrator + subagents to implement , plan have the ai to implement plan again repeat , big tasks , small tasks, etc..
-
  • 2tinker
  • 2tinker
13 Nov 2026 09:40

Ich möchte für das Forum-Upgrade spenden – aber wie?

Category: Deutsch

Dem schließe ich mich an.
Ich spende gerne einen kleinen Betrag.
Am liebsten via PayPal.
  • Hakan
  • Hakan
13 Nov 2026 09:10
Replied by Hakan on topic New experimental ethercat layer

New experimental ethercat layer

Category: EtherCAT
So EL6021 is a ... how does that work? serial over EtherCAT or what?
No that's not supported now. It can be, biggest hinder is I don't have one to test with.
This one is so different that tests are needed. There must be direct support in ecat.so for terminal access.
A bit the same as with EoE devices, there is a clear way how to support that. But need a device to test with.

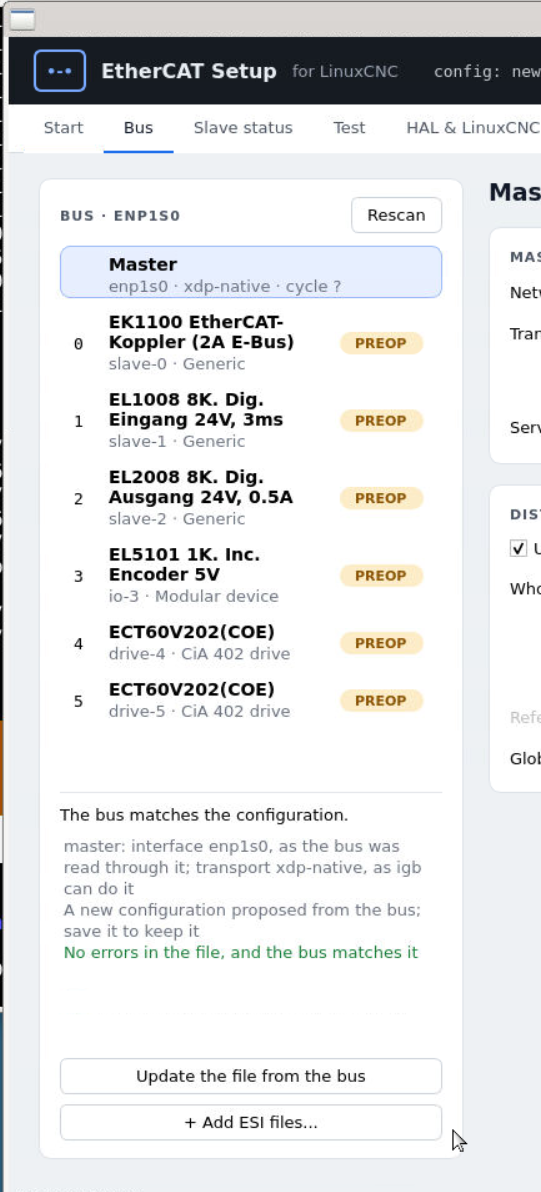
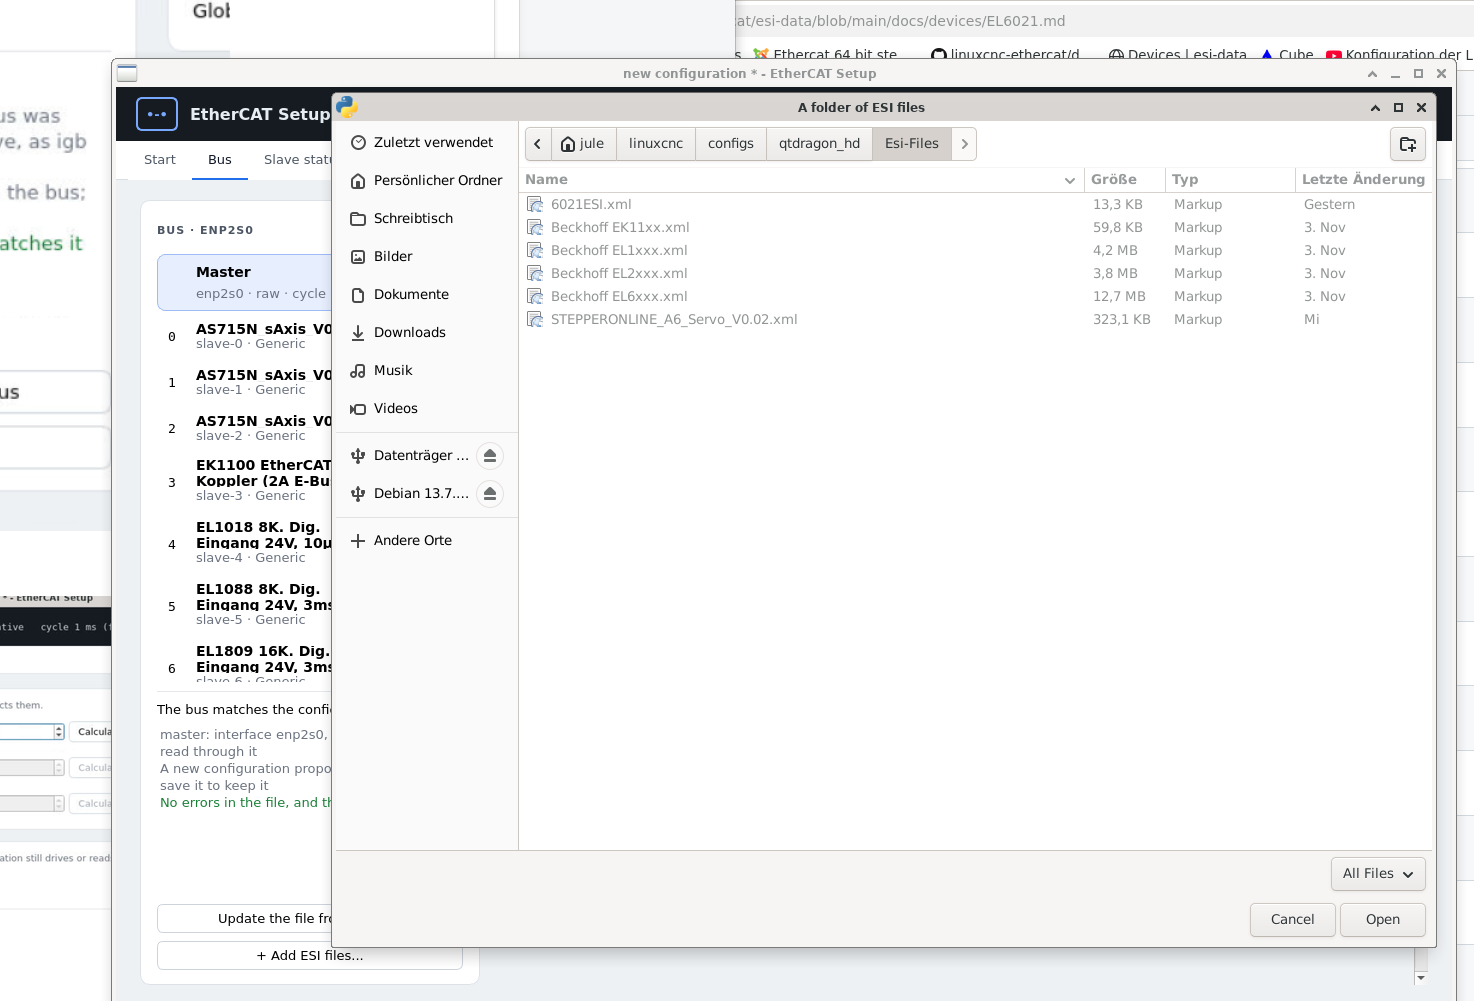
Actually ESI files are supported. 
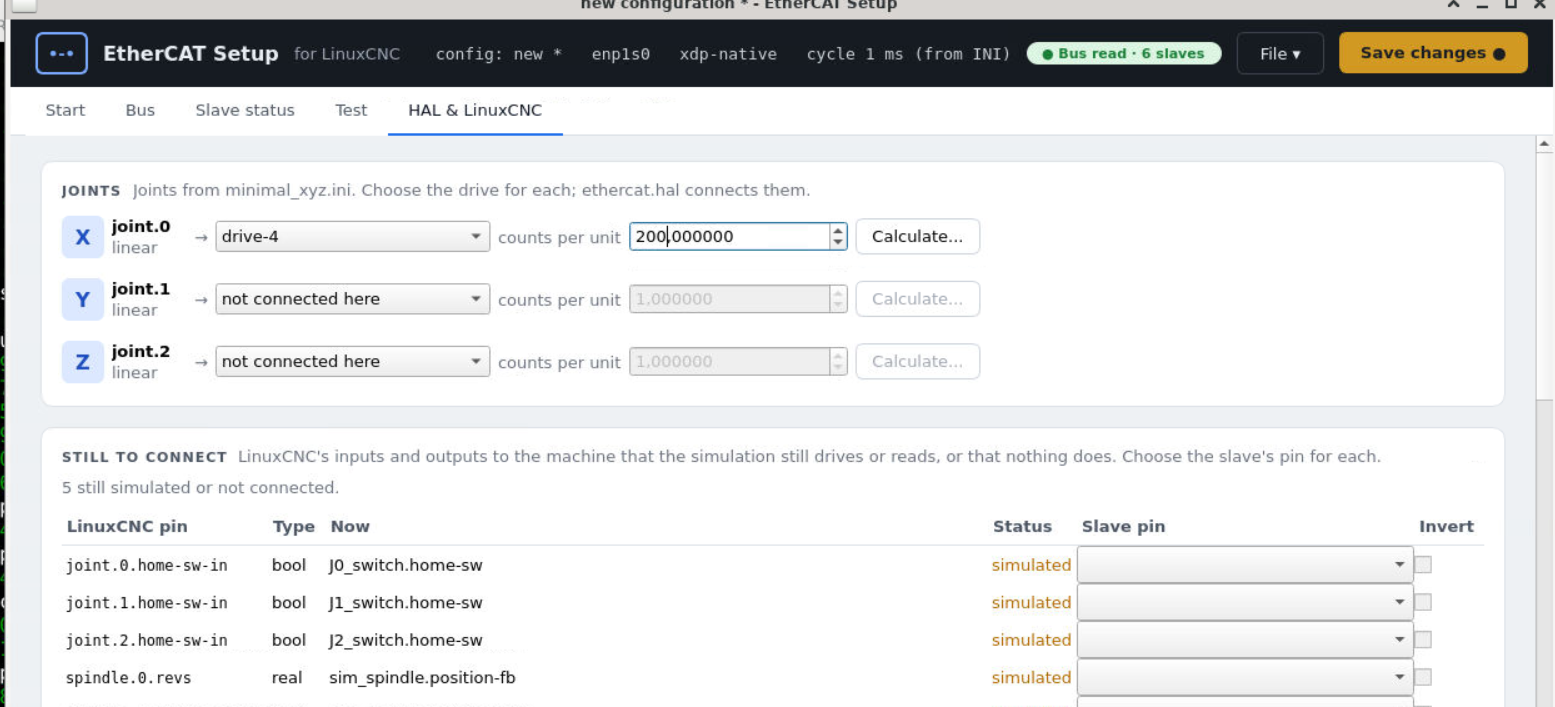
Get all ESI files downloaded from Beckhoff foor example, point to the directory (see at bottom of this figure) and rescan the bus.
 

not.N is there, to the right.The Invert
 

Maybe not general enough. Maybe one should add a type not-bool as an invers to boolean. Ideas?


Displaying 76 - 90 out of 11357 results.
Time to create page: 0.643 seconds
Powered by Kunena Forum