Search Results (Searched for: )

  • alangibson
25 Mar 2026 21:35
Replied by alangibson on topic Review Request for Arc Volt Sensor Schematic
Thanks for the schematic. I wish I had found this a while ago.

I like how you use isolated and regulated voltage. I need to see if I can find a single component that does that.

> The torch is negative, ground is positive.

Ah right. I forgot that. Is that why U4 is inverted?

I took a stab at dissecting your schematic. This is what I got:

Voltage source
5V: Common 5VDC power source
U1: 1W Isolated DC-DC 9V out; Isolation 1.5k VDC/min
C3: Decoupling
U5: 5V LDO voltage regulator
C3: Decoupling
VCC_ISO: Isolated 5VDC

Input stage
R7,R9: Voltage divider, 38:1 ratio
D1: Limit input to max 5V
R6: Current limiting
U4: Voltage buffer (inverted ?)
R8: ?
R5: Current limiting?
C4: Decoupling?
C5: Decoupling?
U3: ADC with 12C output
R4: Pull-up resistor
R5: Pull-up resistor
C2: Decoupling?

Output stage
U2: I2C isolator; Isolation 2.5-kVrms
C1: Decoupling?
R1: Pull-up resistor
R2: Pull-up resistor
  • PCW
25 Mar 2026 21:24 - 26 Mar 2026 01:42
Replied by PCW on topic Connect Spindel with 7i96s
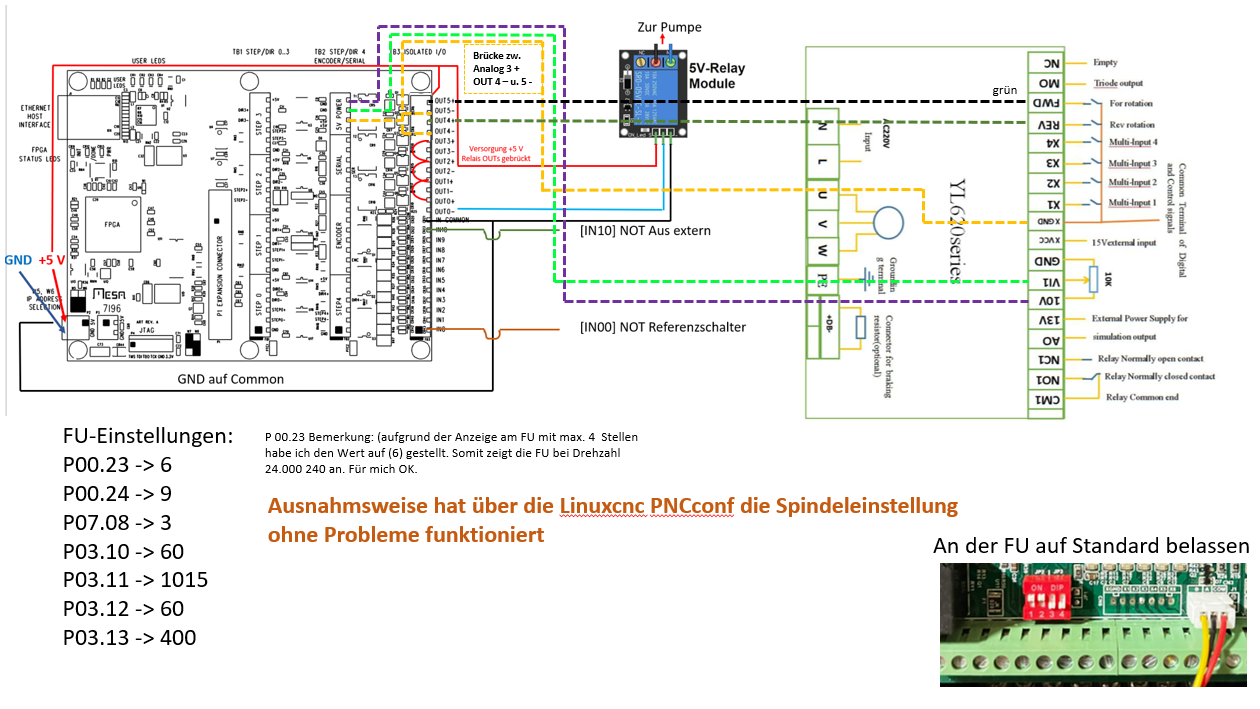
At a first glance, I think you have the wrong GND
connected to  the 7I96S spindle analog SPINDLE- (TB2 pin 22).
It should be the potentiometer GND not the digital input GND.
  • alangibson
25 Mar 2026 20:59
Replied by alangibson on topic Review Request for Arc Volt Sensor Schematic
My intention with the TVS was to limit input voltage to 250V. The ADC expects 0-5V range, and voltage division is 50:1, so anything above 250V is out of range.

In reality 250V is way high for a cutting voltage. I just came up with it by working backwards from the ADC voltage range.

Does that make sense?

Optoisolators are a good idea. I was planning on the TVS limiting the voltage, but I guess it's always possible that someone would hook this board up to a HF start torch.
  • dm17ry
25 Mar 2026 20:51
Replied by dm17ry on topic Mitsubishi MR-J3-XX"A" drive + 7i94 config?
X1 just has 5V power and rs-485 YIO bus...
 
  • rodw
25 Mar 2026 20:40
What CPU do you have? How many cpus does it report?
what does echo $(nproc) say?
Its possible you are trying to isolate a nonexistent core
  • rodw
25 Mar 2026 20:34
Replied by rodw on topic El5101 Config

One would like to have a speed output from the drive but there isn't one.

Should be possible to get rps or rpm in the frequency output
by setting proper scaling factor in frequency-scale. 
Have not tried it, though.
Should be possible
Code:
    65  float OUT             0  lcec.0.El5101.enc-frequency     65  float I/O          0.05  lcec.0.El5101.enc-frequency-scale
  • Tach0
25 Mar 2026 20:25
Connect Spindel with 7i96s was created by Tach0
Hello guys,
im new in Linux CNC i wat to connect Linux CNC with my Spindel+YL620a Frequency Converter
via a 7i96s and failed. I dont understand what im doing wrong.....

I connectet the Components like the Picture.

Added this to the Hal
setp hm2_7i96s.0.pwmgen.00.output-type 1
setp hm2_7i96s.0.pwmgen.00.scale [SPINDLE_0]OUTPUT_SCALE
net spindle-vel-cmd-rpm => hm2_7i96s.0.pwmgen.00.value
net spindle-enable => hm2_7i96s.0.pwmgen.00.enable

Added this to the ini
MAX_OUTPUT = 24000.0
OUTPUT_SCALE = 24000
OUTPUT_MIN_LIMIT = 0
OUTPUT_MAX_LIMIT = 24000

Changed the Frequency Converter Settings like in the Picture.

Im grateful for any help or tips.

Thaks in advance
Tach0
 
  • spumco
25 Mar 2026 20:02
Replied by spumco on topic Lathe C axis homing
I thought I'd added my HAL file, guess not.

The M-code files still have remnants of my first attempt at switching the drive (internally) between velocity and position modes as in @Aciera's example.  That stuff is commented out; just ignore it if you aren't switching your drive.

If you ARE switching your drive internally, you'll probably want stuff like "M66, check for drive mode" in your M-code file.
  • spumco
25 Mar 2026 19:43
Replied by spumco on topic Lathe C axis homing
Good job!

I've renamed my m-codes from the original example, and due to some jitter (servo dithering) when the motor/drive is in position mode I just leave the drive in velocity mode.  LCNC is switched between spindle/orient/positioning. 

My M-codes and main spindle HAL file are attached for your review; maybe they can help.

There is quite a bit commented out, but the gist of it is M254/M255 are used to switch between C-axis and spindle mode, using spindle-orient to realign the spindle before re-connecting the C-axis encoder.

M102 & M103 are 'backstage' M-codes used to adjust stepgen & c-axis PID settings (and disconnect index-enable) in a way you can't (I think) do from inside a normal .ngc g-code file.

Let me know if anything is really unclear.
  • PCW
25 Mar 2026 19:34
That does not look bad but the max servo thread time shows the issue
( 1624528  clocks at 1.7 Ghz is ~.95 ms)

It may be that the CPU/BIOS-Setup are simply not capable of the needed
network performance for a 1 KHz servo thread.

A last ditch is to use a newer kernel as the 6.1 kernel in the LinuxCNC distribution
is fairly bad latency wise.

7.0.0-rc1-rt1 #1 SMP PREEMPT_RT 

Is the current one


  • m0602232
25 Mar 2026 18:43
whoops, sorry about that.
PING 192.168.1.121 (192.168.1.121) 56(84) bytes of data.

--- 192.168.1.121 ping statistics ---
60000 packets transmitted, 60000 received, 0% packet loss, time 60060ms
rtt min/avg/max/mdev = 0.095/0.118/0.250/0.001 ms

The spikes in following error were indeed caused by graphics. It settled down when I removed one of 2 screens I had attached. Realtime delay error persists though.
  • PCW
25 Mar 2026 18:25
Looks like you are pinging the host rather than the 7I97
  • Hakan
25 Mar 2026 17:01
Replied by Hakan on topic El5101 Config
One would like to have a speed output from the drive but there isn't one.

Should be possible to get rps or rpm in the frequency output
by setting proper scaling factor in frequency-scale. 
Have not tried it, though.
  • m0602232
25 Mar 2026 16:29
--- 192.168.1.120 ping statistics ---
60000 packets transmitted, 60000 received, 0% packet loss, time 60060ms
rtt min/avg/max/mdev = 0.017/0.018/0.079/0.001 ms

All power management disabled.
IRQ coalescing disabled.
pinning the Ethernet IRQ to the last processor does not affect, still getting realtime delay message.
Also tried without hm2.read-request.

I just managed to verify the cause for the spikes visible in halscope. They appear to happen the same interval than the pyvcp graphics refresh. I just can't figure out if it's more of a symptom than a cause.
  • jetbadger
25 Mar 2026 16:19
Replied by jetbadger on topic Lathe C axis homing
I found the error on my part just minutes ago. I had set HOME_SEARCH_VEL != 0 and that was the issue. Caused half a day of headache for myself, but now the C axis homes and after a few tweaks responds to commands to some extent, yay :)

I was homing it from the gmocappy GUI and now the homing bit works great! Now the other problem is with the mcodes and remaps. Calling m419/420 causes errors with "ngc file ended with no % sign or program end" and unknown m119/120 code. Will try to figure that out next.

I have to thank you and Aciera as your work let me actually attempt this :)
Displaying 5326 - 5340 out of 11370 results.
Time to create page: 0.147 seconds
Powered by Kunena Forum