Search Results (Searched for: )

  • Finngineering
17 Feb 2026 16:13
Replied by Finngineering on topic XHC WHB04B development?
Regarding the firmware for the pendant, I thought about trying to read it out with glitching or some other technique. But I have not seen the need for it so far. I did read out the firmware from the dongle, but also that was quite much work for what in theory should be simple:
github.com/finngineering/ch55x_firmware_extractor
The reverse engineering I have done for that is with Ghidra. But the dongle is based on the CH554 microprocessor, which is a "8051" type. And the support for that processor is not the best in Ghidra.

I'm not sure what differences you are asking about for the usbhid-dump Hakan. I haven't really checked the source, but I guess it's just polling the interrupt endpoint more or less the same as my test program and the xhc-whb04b-6 component. What would be interesting to know is if there are disconnects with all these program if left running long enough. Say, 1 day or so. Or if that happens only with the xhc-whb04b-6 component (and maybe only while LinuxCNC is running)... I could maybe leave it running overnight myself to check.
  • NWE
17 Feb 2026 16:08
Very good, looks like a win.
  • Looby
17 Feb 2026 15:01
ooook. 

* Repasted CPU cooler.
* Took SSD out and wiped separately
* Reinstalled linuxcnc debian trixie package and did a couple tweaks from the links you posted.  All didnt work for me

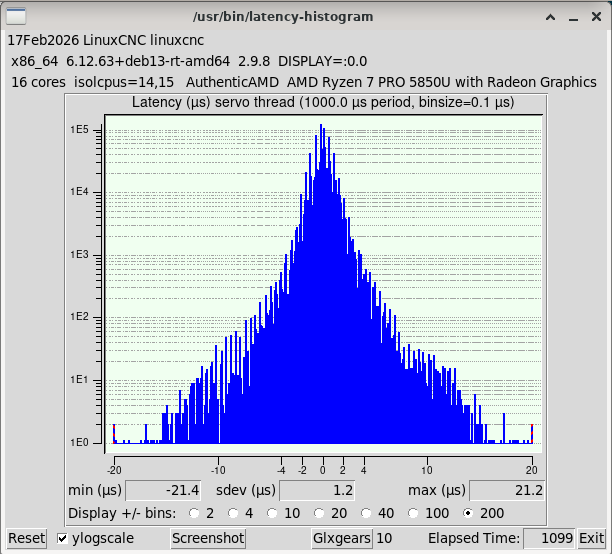
Now im down to 21.2 microseconds in histogram with nobase.  10 glxgears and 4 x 4k youtube videos running.

 
  • andrax
17 Feb 2026 12:14
Hi,
thanks for the feedback.
On the subject of E-Stop.
In CNC machines, E-Stop is triggered to prevent uncontrolled axis movements. 
In automated production machines with axes that move independently of each other, I agree with you. In most cases, an error message is sufficient here.
  • 2tinker
17 Feb 2026 11:52 - 17 Feb 2026 11:54
AMB FME-U 1400 DI was created by 2tinker
Hat jemand Erfahrung mit diesem Fräsmotor?
Eigentlich gefällt mir dieser recht gut.
Sowohl die Montagemöglichkeit als auch das Schnellwechselsystem gefällt mir.
Und mit ca. 1400W sollte da auch Aluminium zerspanbar sein.
Was mich etwas irritiert ist, das es auf YouTube kaum Informationen/Testberichte gibt.
Diejenigen, die einen ähnlichen Motor mal auf ihrer Fräse hatten,
sind auf eine HF-Spindel umgestiegen

Vielleicht gibt es hier ja jemanden, der diesen Fräsmotor im Einsatz hat und mit mir seine Erfahrung teilt

Danke und Grüße
  • tuxcnc
17 Feb 2026 11:20
Replied by tuxcnc on topic EtherCAT driver as simply positioner

So the drive didn't have Profile Position?
 
It has, I suppose, but I have only brief manual in chinese and can't configure driver properly.
I tried use configurations from other manufactures, but no luck.

 
  • Rover20biesse
17 Feb 2026 10:30
Bom dia, eu tenho os procedimentos que vc precisa. Eu estou precisando da pasta C:NC500, poderia me enviar? 
Para carregar o software dele colocar o dip switch 1 a off e 2 a on, depois desliga a Rover. F4 manutenção, F9 inserir a senha 111, F6 backup software.
Após finalizar o carregamento do software que pode durar 10 min, desligar a máquina e colocar o dip switch 1 a in, e o 2 a off. 
giovanermiranda@gmail.com
  • Hakan
17 Feb 2026 10:03
Replied by Hakan on topic XHC WHB04B development?
Found usbhid-dump  github.com/DIGImend/usbhid-dump/tree/master
which already is in the linuxcnc system
Code:
# usbhid-dump --entry=all
also keeps the xhc from disconnecting.
What's the difference vs the component?
The whb04b component uses async transfers, but more?

FWIW, I put the usb dongle in my windows 11 computer. Disconnects/reconnects there also.
  • RotarySMP
17 Feb 2026 09:56
Thanks for that.
  • jarcysgru
17 Feb 2026 08:19
Replied by jarcysgru on topic Brak języka po instalacji Debian 2.9.8 Linuxcnc
Dziękuję działa .
  • Hakan
17 Feb 2026 07:37
Replied by Hakan on topic EtherCAT driver as simply positioner
So the drive didn't have Profile Position?
The trajectory seems a bit crude but as long as it works :)
For higher speeds and if the motor stutters you can try something like this.
Especially the starting and stopping can be smoother.
But don't overdo it, if it works, it works :)
 
  • jarcysgru
17 Feb 2026 07:31
Replied by jarcysgru on topic linuxcnc 2.9.2 (live) on the intel n100 cpu
Witam czy ten komputer nada się dla linuxcnc
pl.aliexpress.com/item/1005010493503938....%7C_p_origin_prod%3A
  • Hakan
17 Feb 2026 07:22 - 17 Feb 2026 08:50
Halfway down in this post rodw describes how to add a udev rule for /dev/EtherCAT0
forum.linuxcnc.org/ethercat/45336-etherc...-how-to-step-by-step

For the interface, there are many ways. I have the following in /etc/network/interfaces for my ethercat interface
It brings the enp2s0 interface up, without IP address
Code:
auto enp2s0 iface enp2s0 inet manual         hardware-irq-coalesce-rx-usecs 0         pre-up /sbin/ip link set dev $IFACE up         post-down /sbin/ip link set dev $IFACE down

Check what's in syslog (sudo dmesg) if there are more problem
  • Jugo2
17 Feb 2026 07:13 - 17 Feb 2026 07:31
Replied by Jugo2 on topic StepperOnline A6 Servo
Hey, sowas in der art hab ich mir schon gedacht…
Dank dir, werde es nachher mal ausprobieren. :)
hast du dann nur DEFAULT_LINEAR_VELOCITY runtergesetzt oder auch noch andere werte und auf welchen wert hast du's runtergesetzt?
 
  • cmorley
17 Feb 2026 06:10
Replied by cmorley on topic qtdragon mod
Did you try this?
Look for the heading : 2.8.2. Handler Patching - Subclassing Builtin Screens
linuxcnc.org/docs/stable/html/gui/qtvcp....cp:modifying-screens

Look for the direction on handler file placement.

Running linuxcnc from the terminal can give more info too.
Displaying 6811 - 6825 out of 11379 results.
Time to create page: 0.291 seconds
Powered by Kunena Forum