Search Results (Searched for: )

  • mwc
26 Oct 2026 22:06
No output from lcec_configgen? was created by mwc
I've trying to create the XML for a Amsamotion EC1A-1016R-AM6 module, but lcec_configgen appears to be doing nothing.
The command appears to be recognised, but gives no output.

ethercat slaves shows my Lichuan CL3-E57H drives and the EC1A-Core, with -v option showing all the expected values, but lcec_configgen appears to do nothing. The terminal simply goes back to the prompt with no output.

This is on 2.9.10.

Anybody have any suggestions?
  • dberegovoy
26 Oct 2026 21:29
Replied by dberegovoy on topic 5i25, 6i25, 7i92, firmware request.
To avoid creating a new thread, I'll ask here.
Could you please tell me if it is physically possible to make a firmware for the 7i92 or 7i92T (I have both) with 8 full A/B/Z encoders? I don't need any stepgens at all, and the remaining free pins can be assigned as PWM.
  • jazzkramer
26 Oct 2026 19:06 - 26 Oct 2026 21:56
It's me or it's a bug? was created by jazzkramer
I searched but I did not find so I write this post.
Hi all! :)

I'm now using the plasma more: QtPlasmaC v 2.9-238.315.

I have some strange behaviours:

1) I'm cutting a shape that I moved to <0, 0> by the conversational (subtracting 0.6 from each axis).
When I start the cut, the 0,0 turn to 0.6, 0.6... I can't measure the real cut position but... finishing the cut it goes back to 0,0 as in this video:
(investigating more, luckily it seams it's a visualization error only)

youtube.com/shorts/QHeixNg3vI8?feature=share

2) I'm cutting one shape, than I'm pressing a custom GO TO X0Y0 button that moves the torch over the last start 0,0 position, than I'm moving the torch by 60mm pressing 6 times the X left arrow (10mm each time), then I pres X0Y0 button to set the new starting position.
Sometimes, randomly, when I click CYCLE START, the Z axis movement is ignored and the shape is "cutted" in the air. To correct this I need to press and switch off the Power button, than switch it on again. I think it's not an electrical problem of my machine because the shape cutting movement occur without waiting the Z movement time... I also move the Z with the arrows befor starting cut cycle... Here the video:

youtube.com/shorts/zjP_dUaLeVU

3) Moving the X axis by arrows, I got to the right limit switch. I remember from previous version, you press OVERRIDE LIMITS in the message and it works to go back inside the limits... now... it seams to be looping in the message and can't go back within the limit because message appears...

youtube.com/shorts/i5hVDSLVbTQ


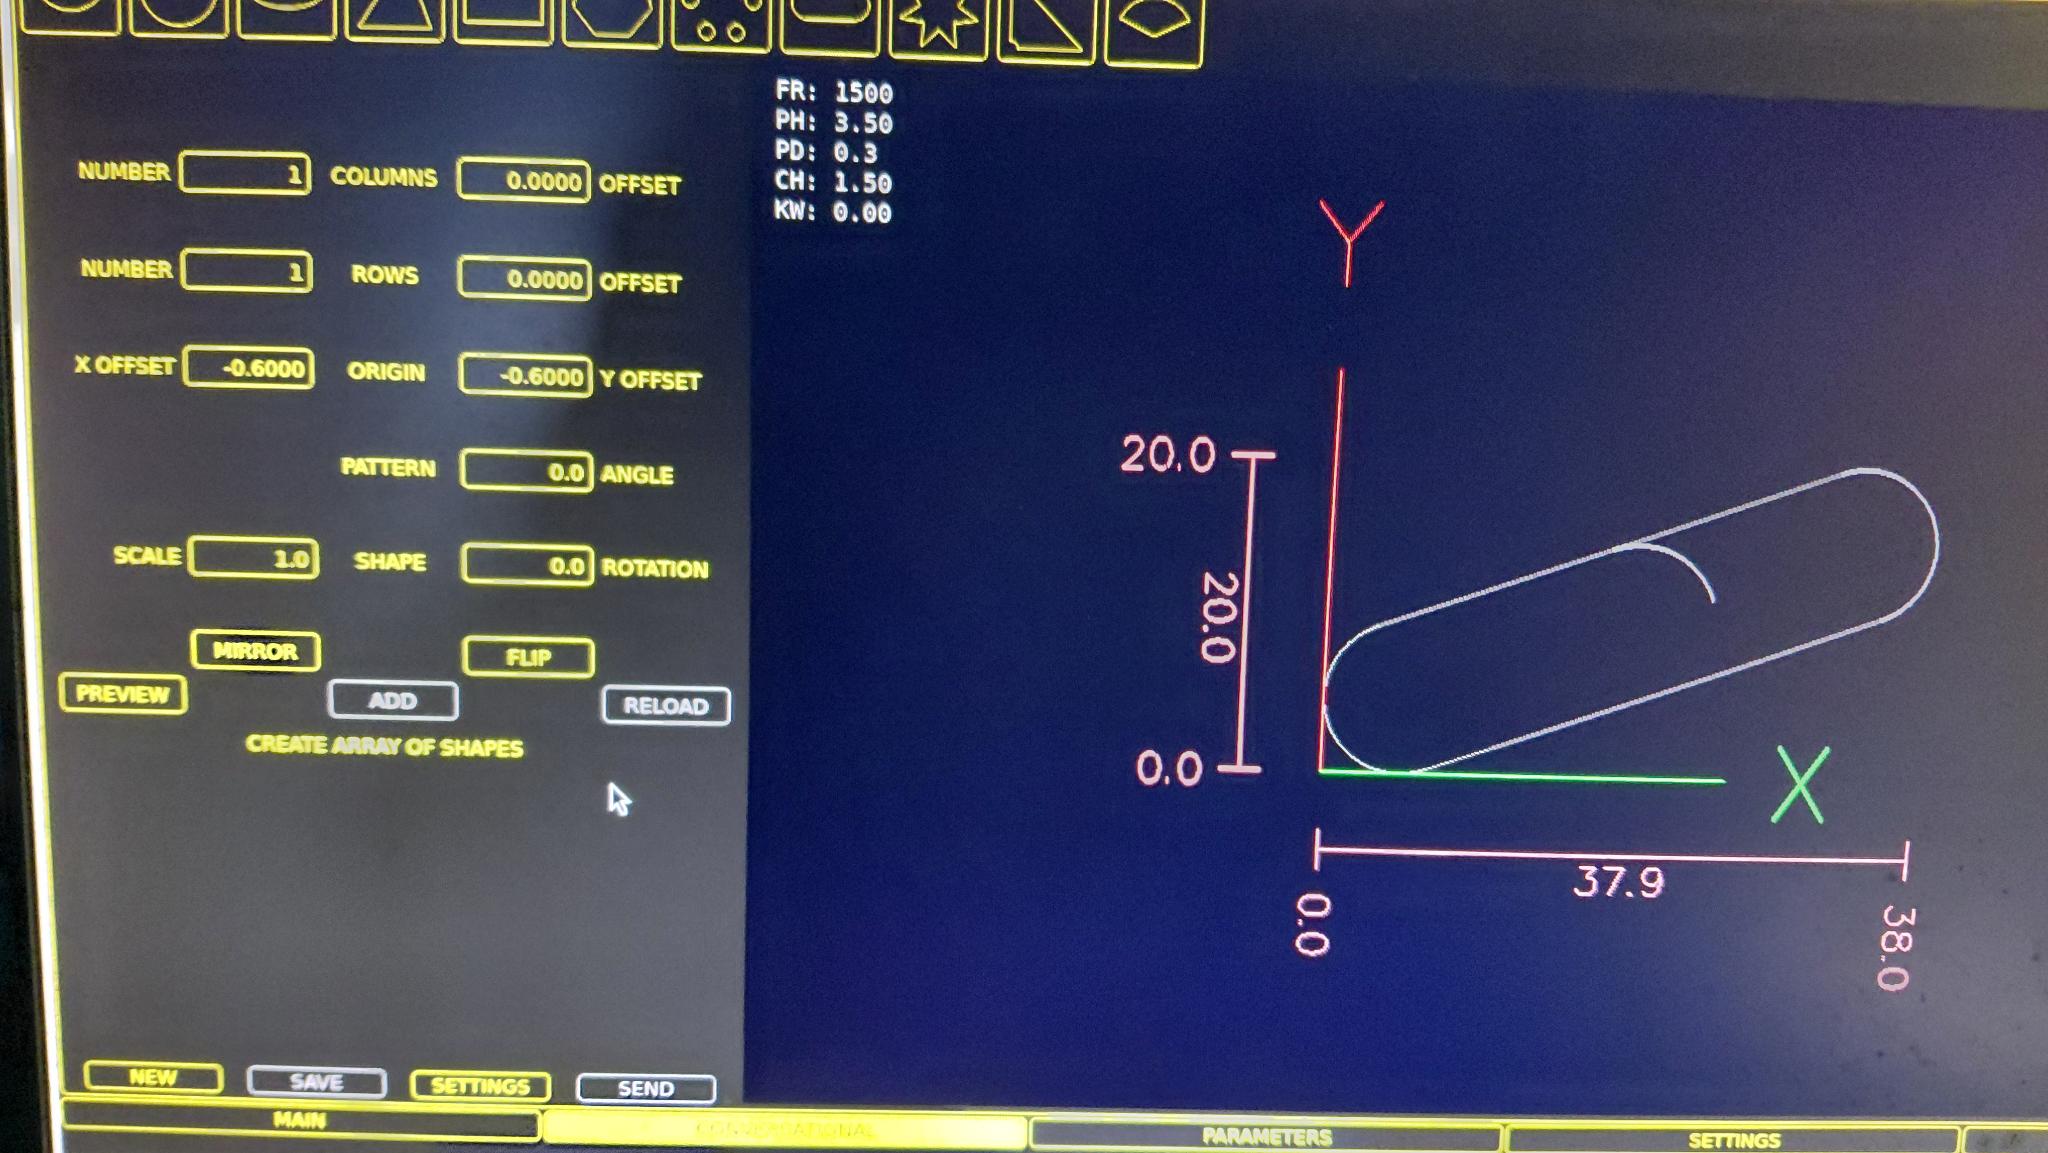
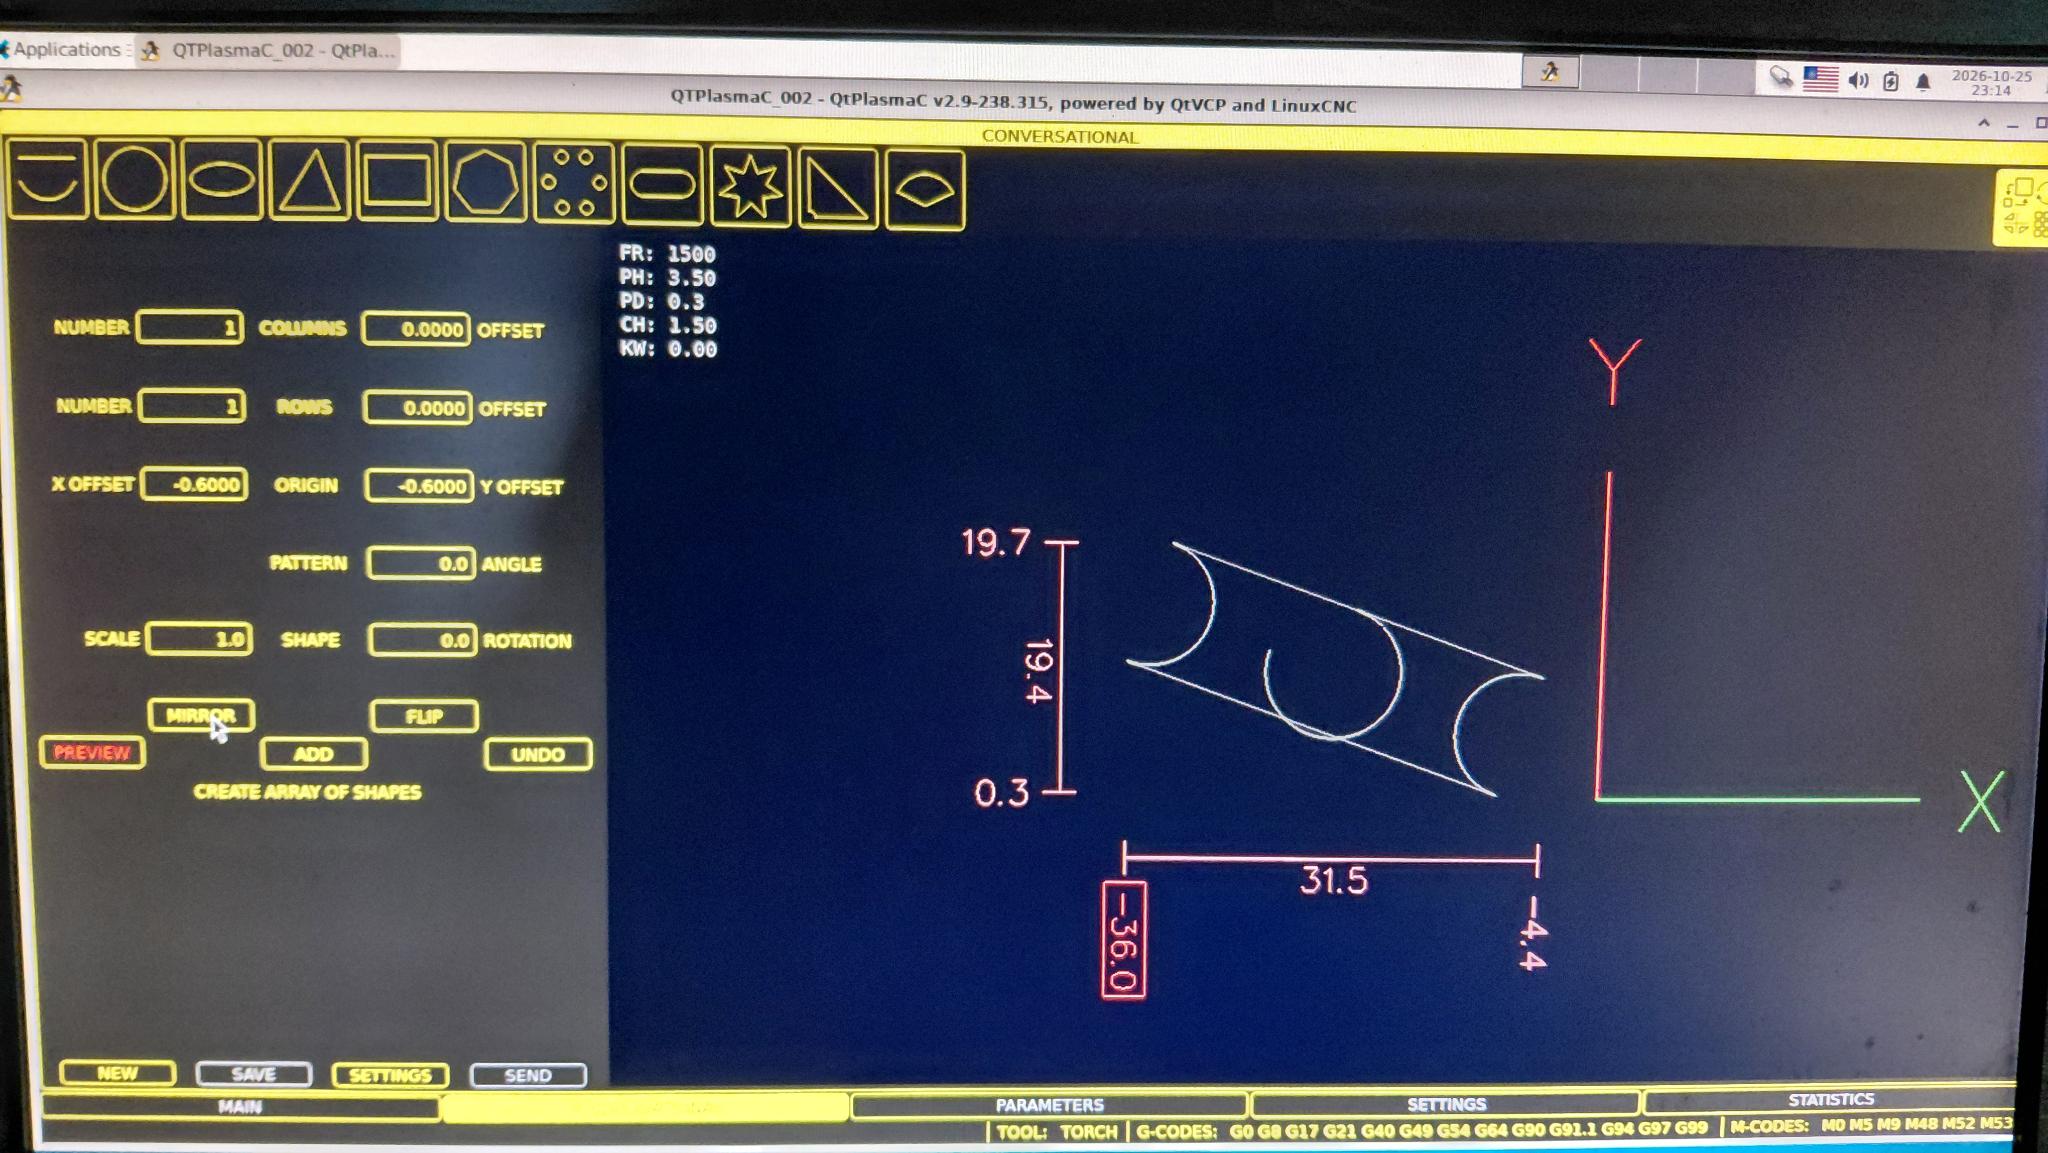
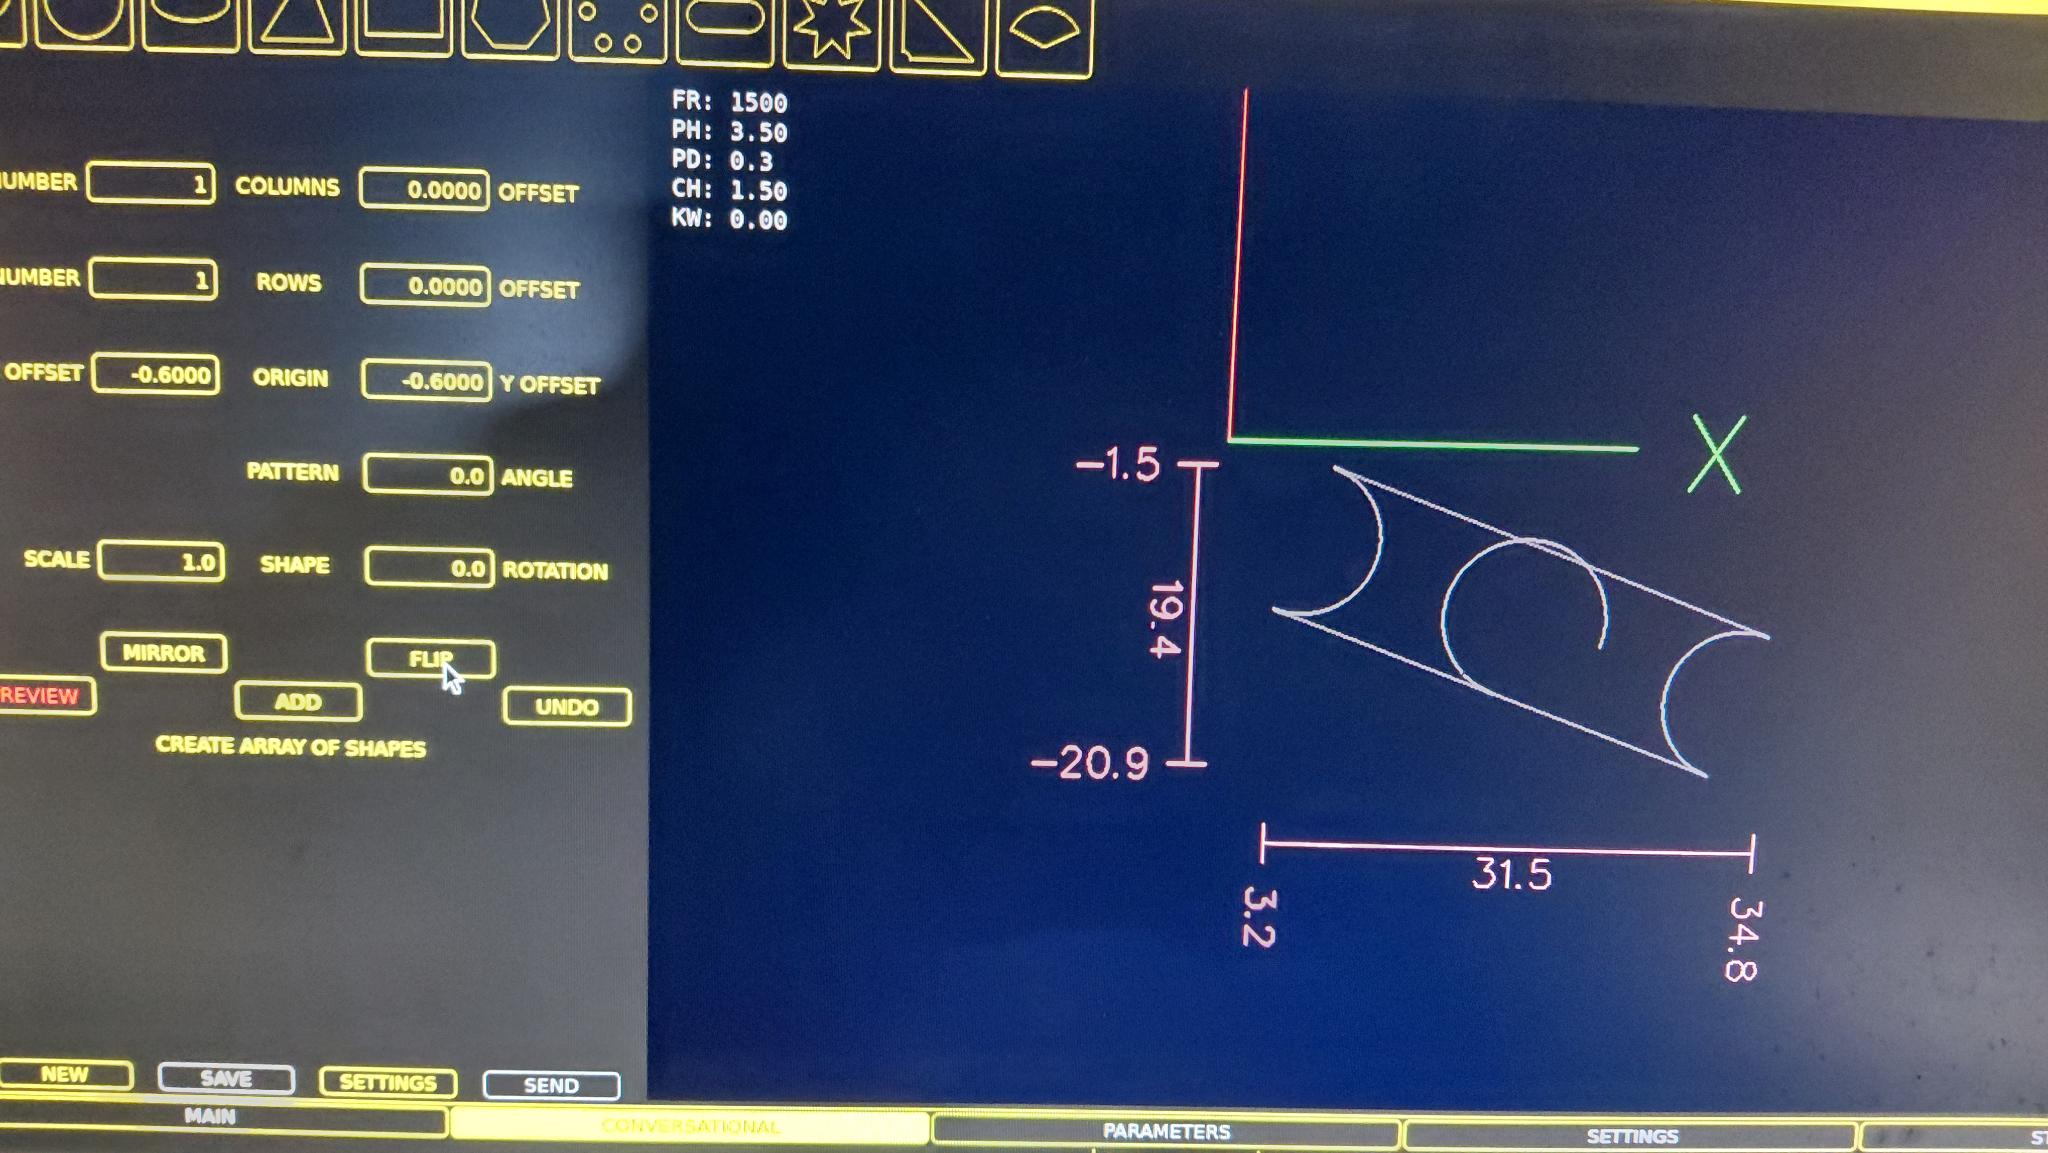
4) AND, I just saw now: is it a flip, is it a mirror?
Original:
 

Mirrored:
 

Flipped:
 

Thanks, for any advice.
These are not blocking errors, I mean, I can live with that! It's just to inform you in case you don't know.
I apologize if they where already posted, I did not find them. And thanks to all developers!! :)

Alberto 
  • JThom
26 Oct 2026 16:07
Thank you! Mesa customer service is outstanding.
  • PCW
26 Oct 2026 15:58 - 26 Oct 2026 16:00
7I96S  + 7I85 with PktUART on 7I96S RS-485 interface

Note that sserial channel numbering on the 7I85 has changed
since old sserial channel 0 on the 7I96S has been replaced by
a PktUART, so sserial channels 0..4 instead of 1..5 are on the 7I85.

Encoder on the 7I96S is encoder 4  (same as normal 7I96S+7I85 configuration)

File Attachment:

File Name: 7i96s_7i85_pktv3d.zip
File Size:307.18 KB

 
  • JThom
26 Oct 2026 14:03
Hello,
I think I need custom firmware/bit-files for my setup.
I have a 7i96s with 7i85 db25 daughter-card, which in turn has 4 encoders, a 7i84u and a 7i73 attached. I want to control my Invertek ODE-3 spindle vfd with modbus from rs485 on the 7i96s. 

Unless I'm mistaken, the standard 7i96s_7i85d files don't feature PktUART for modbus on the 7i96s. Everything else seems to be working with them. 

It's a 4 axis mill, so if possible, I also wish to retain the encoder input on the 7i96s for a spindle encoder - (if i understand correctly there can be complications there due to muxed vs unmuxed?).

I've had a look for existing firmware, but don't notice a suitable option in the standard 7i96s package. 
I also read the below linked thread, but don't see links for bit/pin files there.
www.forum.linuxcnc.org/27-driver-boards/...dbus-pkt-pin?start=0

Would this be possible please? Any other information needed?
  • tuxcnc
26 Oct 2026 13:28
Gentlemen, you’ve made a real mess of things...
The topic at hand is that my EtherCAT configuration cannot be made to work on LinuxCNC 2.10-pre2.
First, there was an issue with `lcec_conf` throwing an error; then, it was claimed that this had been fixed (which isn't entirely true, though version 1.45 of the linuxcnc-ethercat from the `getset` branch seems to work correctly); and finally, the discussion turned to the inability to install `cia402.comp`.
I use the `cia402.comp` from the rodw's repository, as it has worked for me so far (the one from github.com/dbraun1981/hal-cia402 is five years old and has never worked for me anywhere).
I have no interest in internal drive homing, as I have no use for it.
I want to migrate my machine working well at LinuxCNC 2.10-pre1 to 2.10-pre2.
  • rodw
26 Oct 2026 12:03

I'm sorry, you lost me. Versions 1.45, 1.46 and 1.47 of what software?

Ok, I looked at the page you linked to of the comp of Rodw, and I'm not sure it is even necessary. The same function could be probably achieved with just a few lines of hal logic using ordinary hal components, rather than writing a custom comp. Simply use a mux hal component to connect the commanded position to the feedback while the homing pin is true. (But there could be an issue if there is a large step in the FB position when homing is completed. I don't think that will happen but...)

Some of these guys get a little carried away writing custom hal comps for their nich uses when existing standard components are more than adequate. Which is fine and good for their own personal uses. But I don't always agree with them posting their "this is how it has to be done" tutorials and linking to their custom comp that is out of tree, which doesn't follow updates of the main system that may break them.
Homecomps are part of the LinuxCNC design and are intended to avoid (complex) custom coding in homing.c. The code in question is not designed for general use and has not been tested. But the changes made by the developers  in 2.10 has broken every out of tree component. There is a lot of pain across many users to come......
  • rodw
26 Oct 2026 11:45
Replied by rodw on topic Jogging a 2nd Spindle
I was wrong. It defaults to spindle $0 which does not really make sense.
  • Todd Zuercher
26 Oct 2026 10:33
Replied by Todd Zuercher on topic lcec_conf error (newest lcnc 2.10 and debian 13)
I'm sorry, you lost me. Versions 1.45, 1.46 and 1.47 of what software?

Ok, I looked at the page you linked to of the comp of Rodw, and I'm not sure it is even necessary. The same function could be probably achieved with just a few lines of hal logic using ordinary hal components, rather than writing a custom comp. Simply use a mux hal component to connect the commanded position to the feedback while the homing pin is true. (But there could be an issue if there is a large step in the FB position when homing is completed. I don't think that will happen but...)

Some of these guys get a little carried away writing custom hal comps for their nich uses when existing standard components are more than adequate. Which is fine and good for their own personal uses. But I don't always agree with them posting their "this is how it has to be done" tutorials and linking to their custom comp that is out of tree, which doesn't follow updates of the main system that may break them.
  • superhola
26 Oct 2026 08:17
a {
text-decoration: none;
color: #464feb;
}
tr th, tr td {
border: 1px solid #e6e6e6;
}
tr th {
background-color: #f5f5f5;
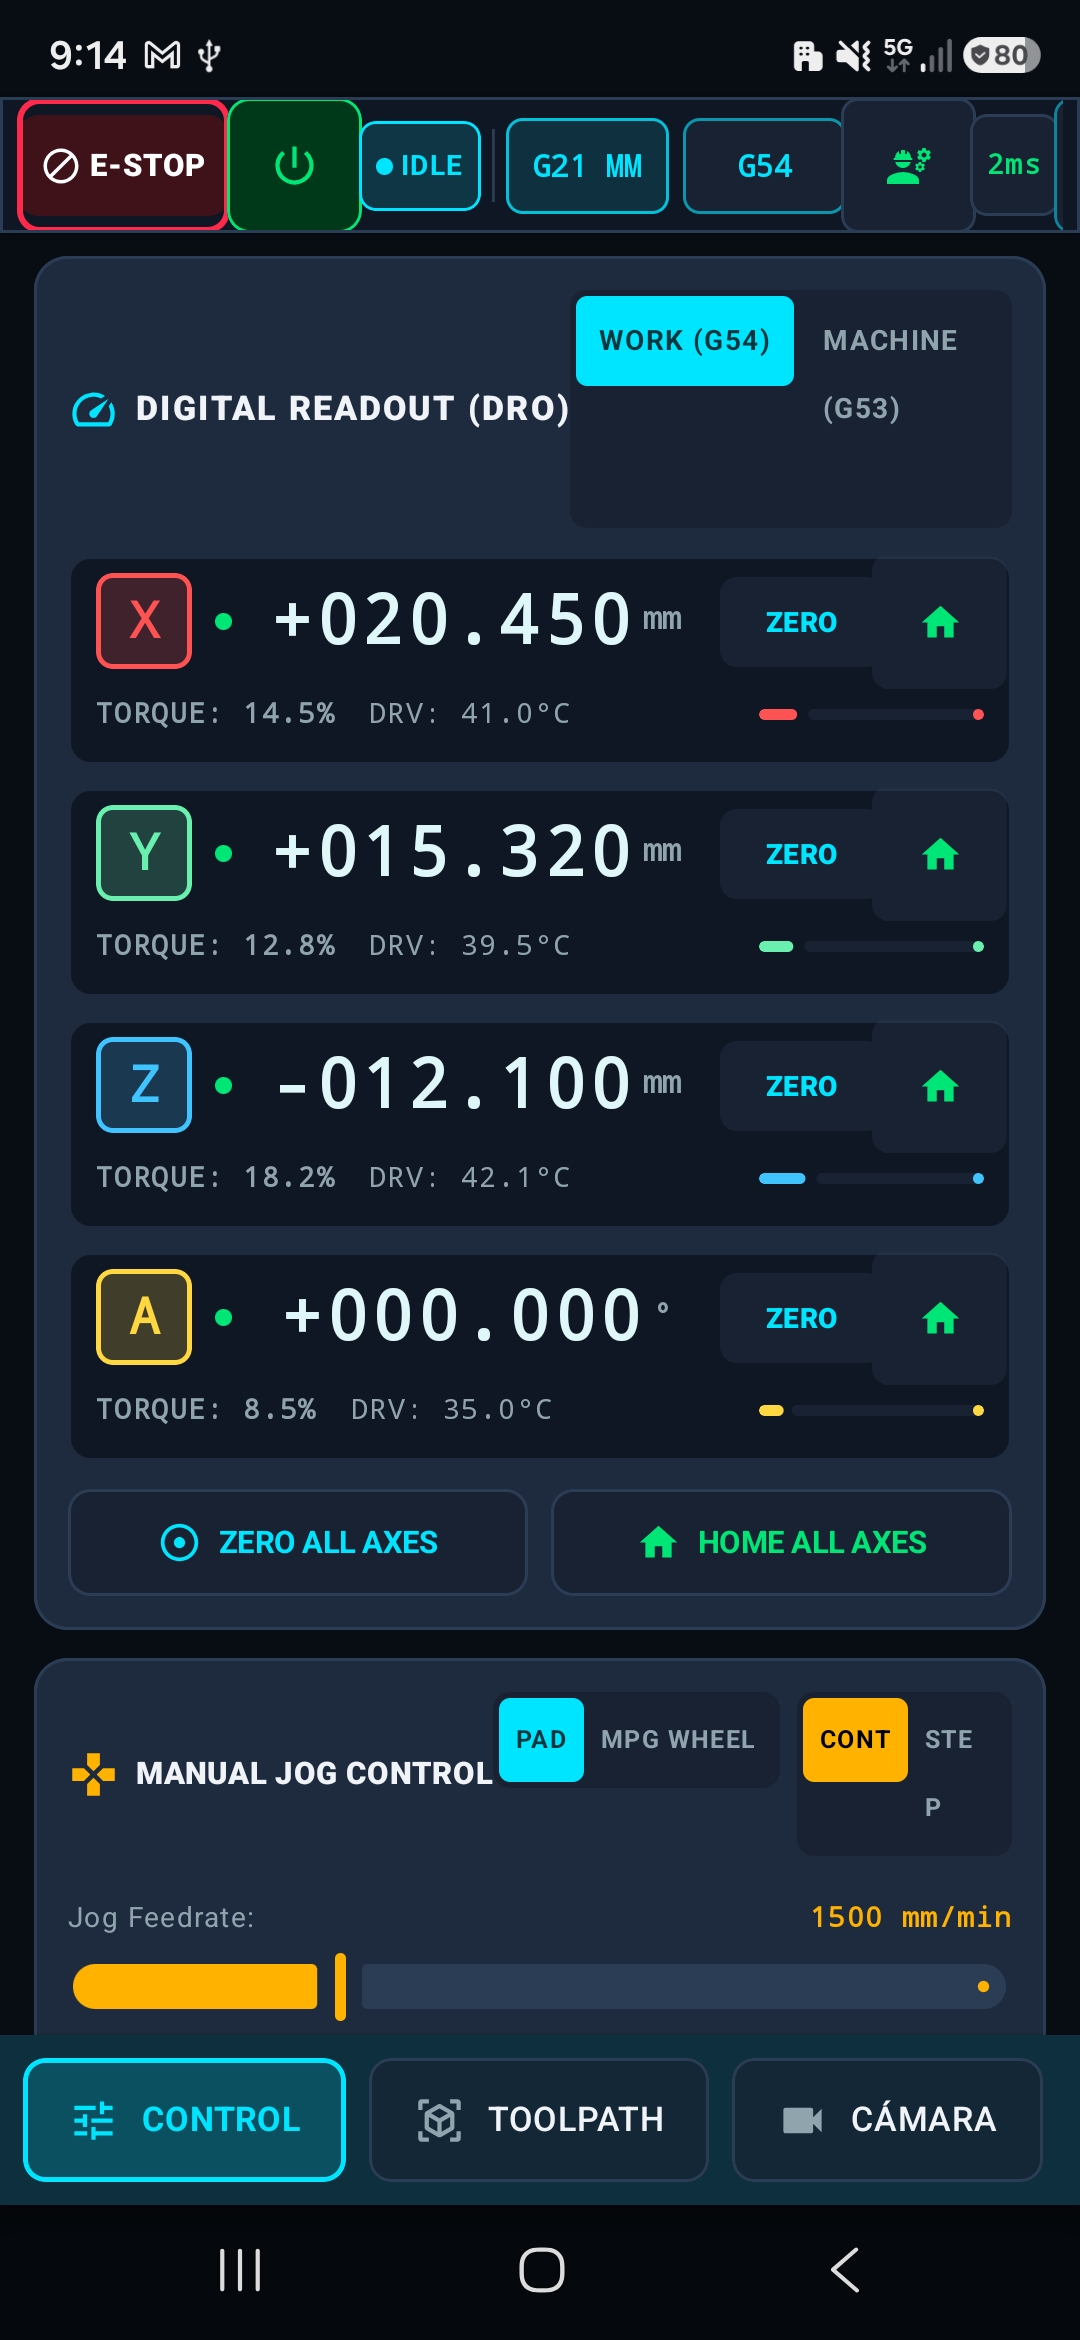
}I’m currently developing this application, but I haven’t yet been able to publish it on the Play Store as an open test. I’m looking for users who can try it out, share their feedback, and help identify any bugs or issues that may still be present.Most of my current testers don’t have access to this type of device, so their testing opportunities are somewhat limited. If you’re interested in evaluating the app, I’d be happy to invite you. Just send me your email address, and I’ll provide you with the Play Store testing link.Thank you for your time and willingness to help improve the app. Your feedback would be greatly appreciated.
   
LinuxCncDroid is a high-fidelity, touch-optimized industrial Human-Machine Interface (HMI) built for monitoring, controlling, optical centering, and metrology calibration of CNC machine tools powered by LinuxCNC and Machinekit.Crafted natively in Kotlin using Jetpack Compose and Material 3 Industrial Design, LinuxCncDroid provides out-of-the-box support for industry-standard fieldbus topologies (Mesa FPGA, EtherCAT, and Parallel Port), featuring real-time telemetry, a haptic Virtual MPG Handwheel, an interactive 3D G-Code Toolpath visualizer, 3D probing routines, live camera crosshairs, reactive Metric (G21 mm) / Imperial (G20 inch) switching, and an ISO 230-2 metrology calibration wizard.
  • retrofitcenter
26 Oct 2026 02:40
Hi Andy,

I actually discussed this idea with Michael Haberler about 15 years ago, and I left it alone for a long time because of the complexity involved.

When I finally took it on, it required a substantial amount of reworking across the existing code. It took several attempts and a few changes in direction before I found an architecture that worked for what I wanted to achieve.

The shared HAL approach is an interesting option. In my case, finding a workable overall concept was a major part of the effort.

It’s good to hear that this is being discussed at the meet-ups as well!
  • retrofitcenter
26 Oct 2026 02:35
Hi Rob,

Thanks for your message and your offer to help with testing and development! Your Citizen L16 sounds like a great candidate, and your experience with sliding head lathes would be very valuable.

I’m currently in California and will be back in Europe on 13 November. Given the complexity of the project, I’d suggest a video or phone call to discuss the machine, its existing hardware, and the requirements for the retrofit.

I’d be happy to support you with integrating the new system into your Citizen L16. Testing it on a real machine and getting your feedback would also help us develop and refine the functions needed in practice.

Let’s arrange a suitable time for a call.

Best regards,
Daniel
  • fsabbatini
26 Oct 2026 01:19 - 26 Oct 2026 01:20
Goooood morning/afternoon/night!
So after tons of hours of working with colleges we had to drop linuxcnc core because of hundreds of limitations and we have to write eveything from scratch. I can explain why and how this soft is done if you are intereset but for now some pictures and a video of the whole new parser, 90% $iemns compatible (also ISO mode compatible), HMI is based on same UI for operator familiarity but i added several "always i wanted" features.

Here we go: jerk controlled movements, feed blending, PLC codesys based making a toolbox, up to 31 axis (why? because i just wanted to..cpu and ram makes the limit), hmi can run on separate pc if more power is needed, multithreaded realtime subsystem running in xenomai (migrating to jailhouse soon) (actually rtapi from linux cnc has a huge design problem, it only runs on one cpu core and each thread has less priority than the previous initialized, that was the weakest point found to make as drop it completely), work offsets, tool offsets, machine data with access protection, multichannel (up to 10 right now, why? because i wanted to.. again, cpu is the only limit) with synchronization (waitm commands plus others), up to 10 mode groups (several channel can group in different mode groups so, going to jog mode makes all channel from same group change to jog, same for mdi, auto, etc..)


youtube.com/shorts/kW06KXbYc_0

Best regards, enjoy!


  • +Jan+
25 Oct 2026 20:50 - 25 Oct 2026 20:51
Replied by +Jan+ on topic GladeVCP and key behavior
I think I've found a solution to this odd behaviour:

Link to old topic...

I would be grateful if someone could test and
replicate the solution.

Best wishes, Jan
Displaying 91 - 105 out of 11914 results.
Time to create page: 0.340 seconds
Powered by Kunena Forum