Challenges Tuning Servos on Brother TC-225 Retrofit

More
7 years 1 month ago #144004 by Type_Zero_Design
Ok I will take a look at that. Waiting out to see if we are going to get wrecked by this hurricane tomorrow.

Please Log in or Create an account to join the conversation.
More
7 years 1 month ago #145790 by Type_Zero_Design
PCW,

I don't see anything in my Hal or Ini files that matches up with what you were saying here:

You might try running open loop = pid feedback from stepgen but still feeding the encoders to motions feedback pin


I understand what your saying, just not 100% on what I need to change in my Ini and Hal that I posted to accomplish that.

Please Log in or Create an account to join the conversation.
More
7 years 1 month ago #145792 by PCW
What I am saying is the the stepgens take the joint commanded position and the PID takes the stepgen feedback position (like a non encoder stepgen setup) but you feed the encoder position back to motion

that is:

motion joint position command --> PID command
stepgen feedback position -- >PID feedback

(which is standard open loop stepgen setup)

but

motion joint position feedback <-- encoder position
rather than from stepgen position feedback

This means that any actual following error will be calculated
and can cause a fault

Please Log in or Create an account to join the conversation.

More
6 years 3 months ago - 6 years 3 months ago #175099 by Type_Zero_Design
PCW,

Its been about a year since I have been working on this, life happens.... I spent the evening getting caught up on where i was and I wanted to pick your brain on this.

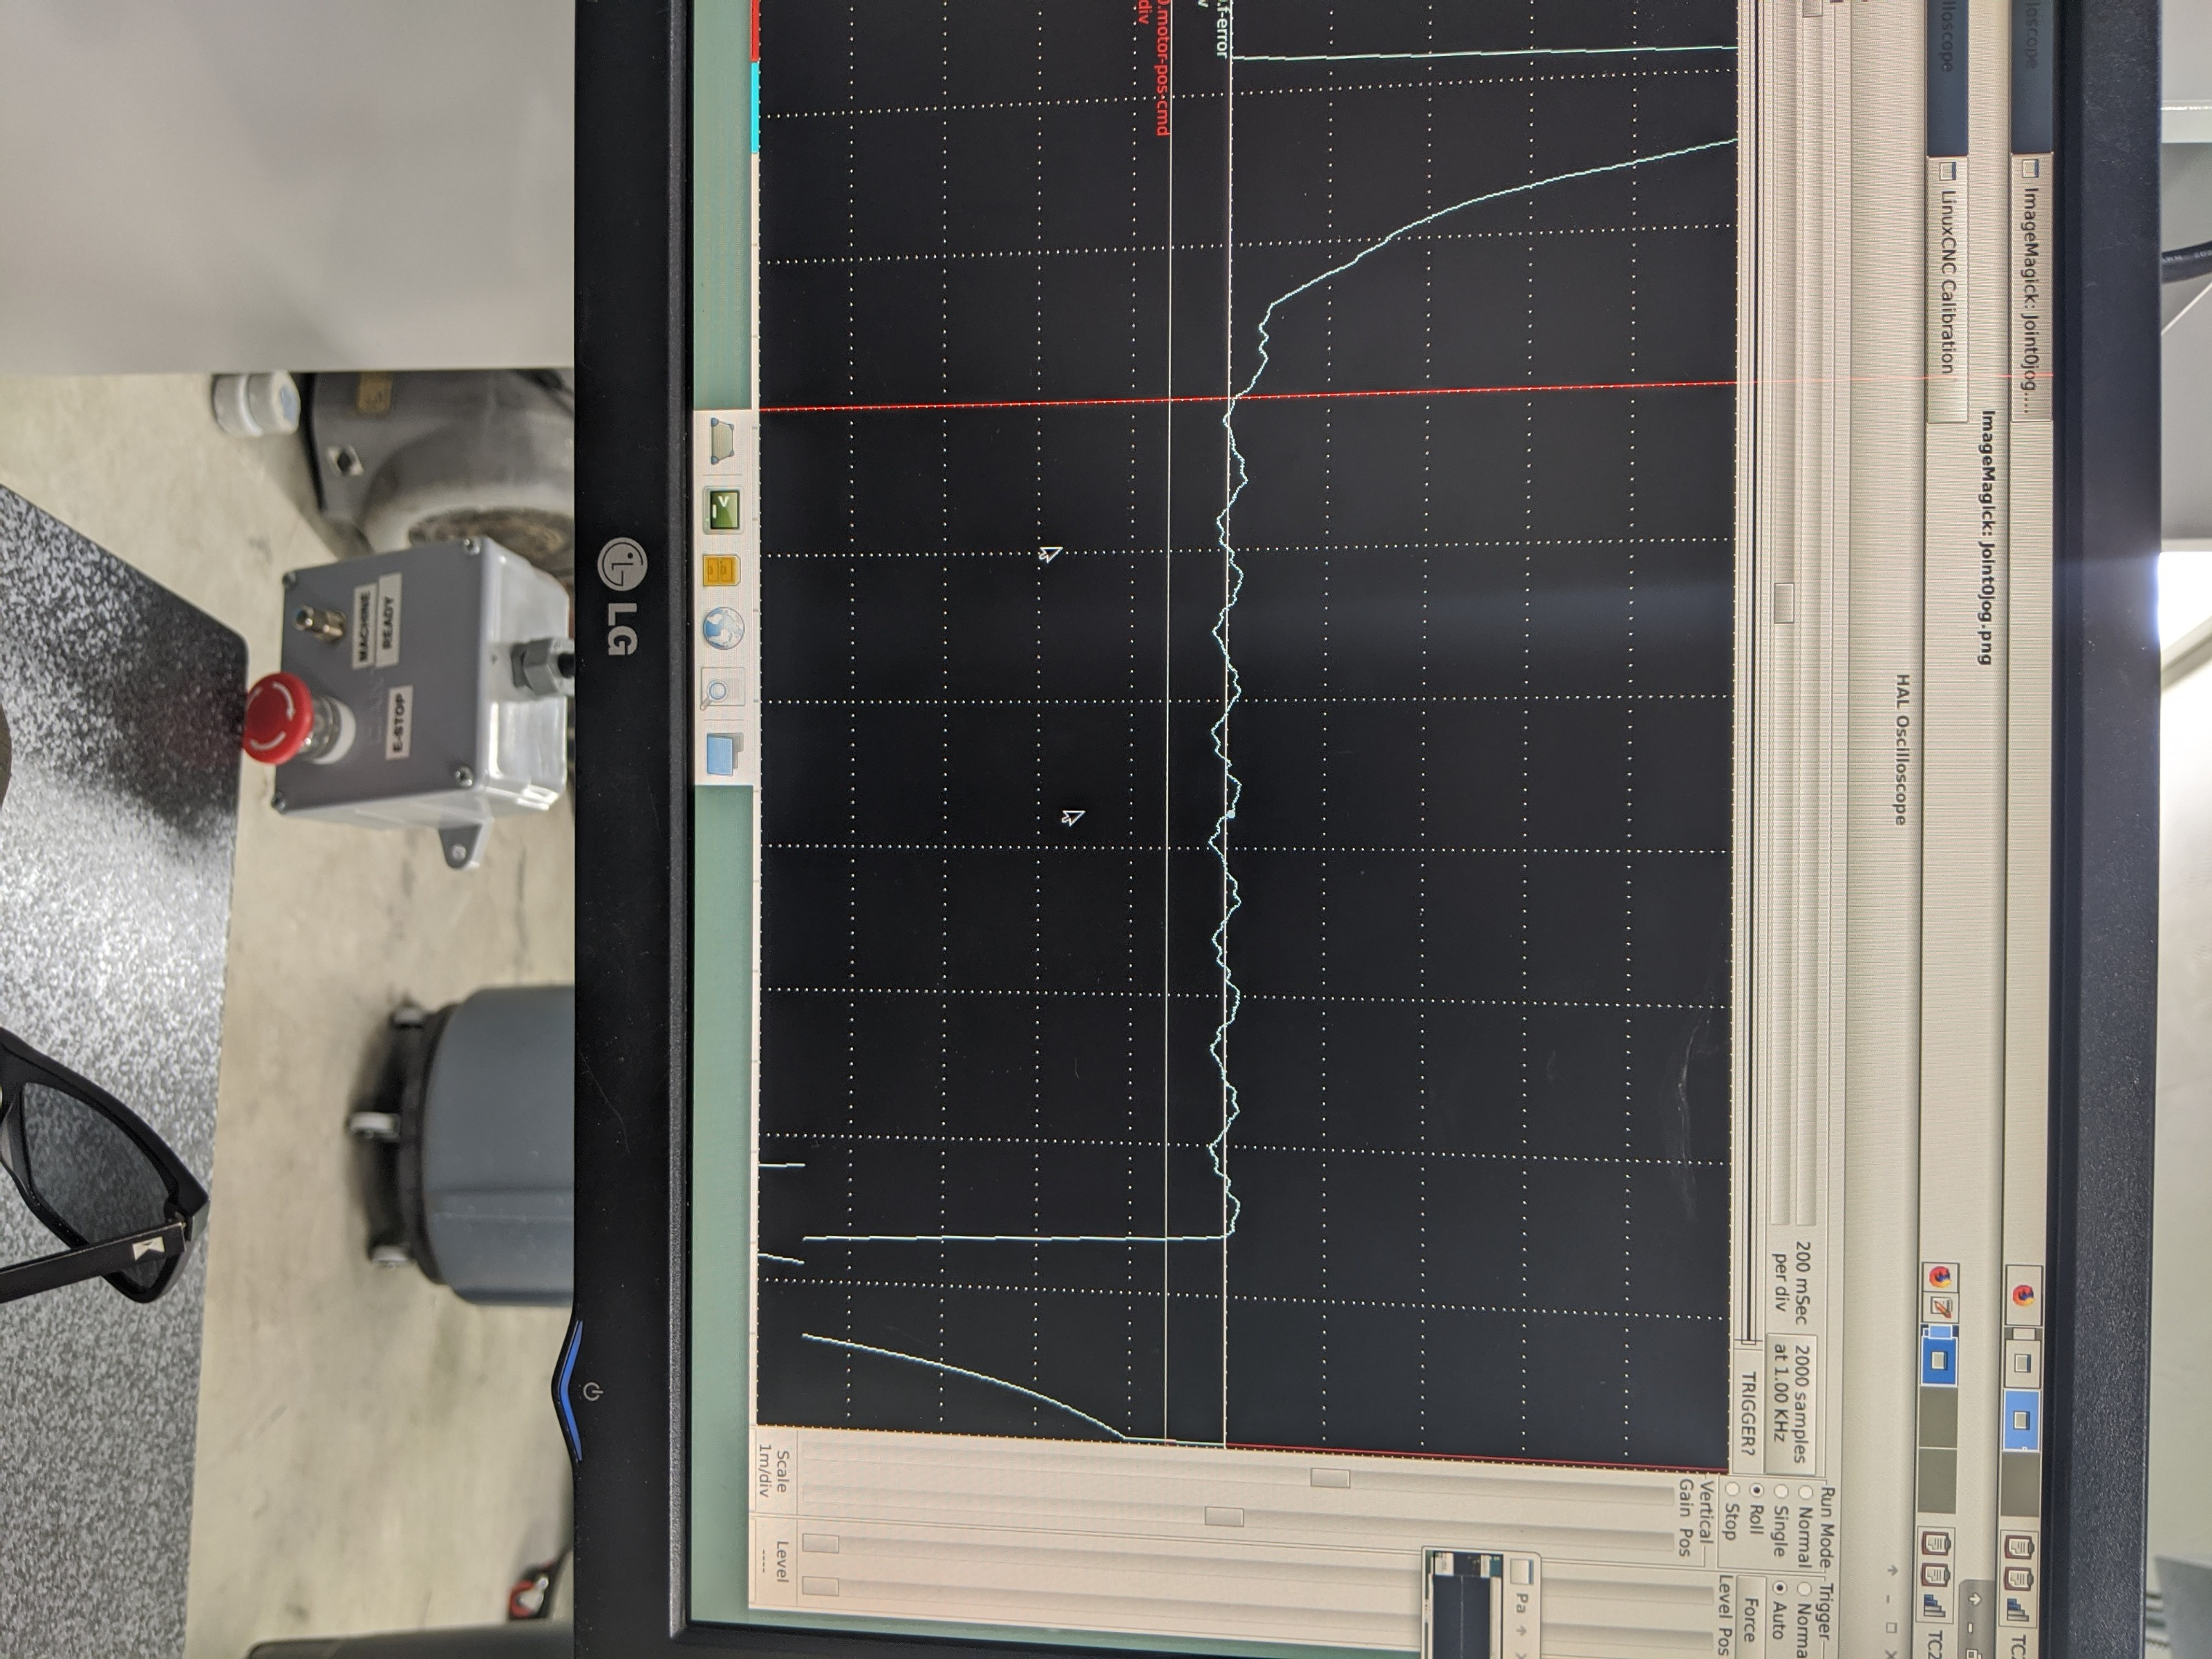
Here is a quick screen shot of the current scope im getting on joint 0.


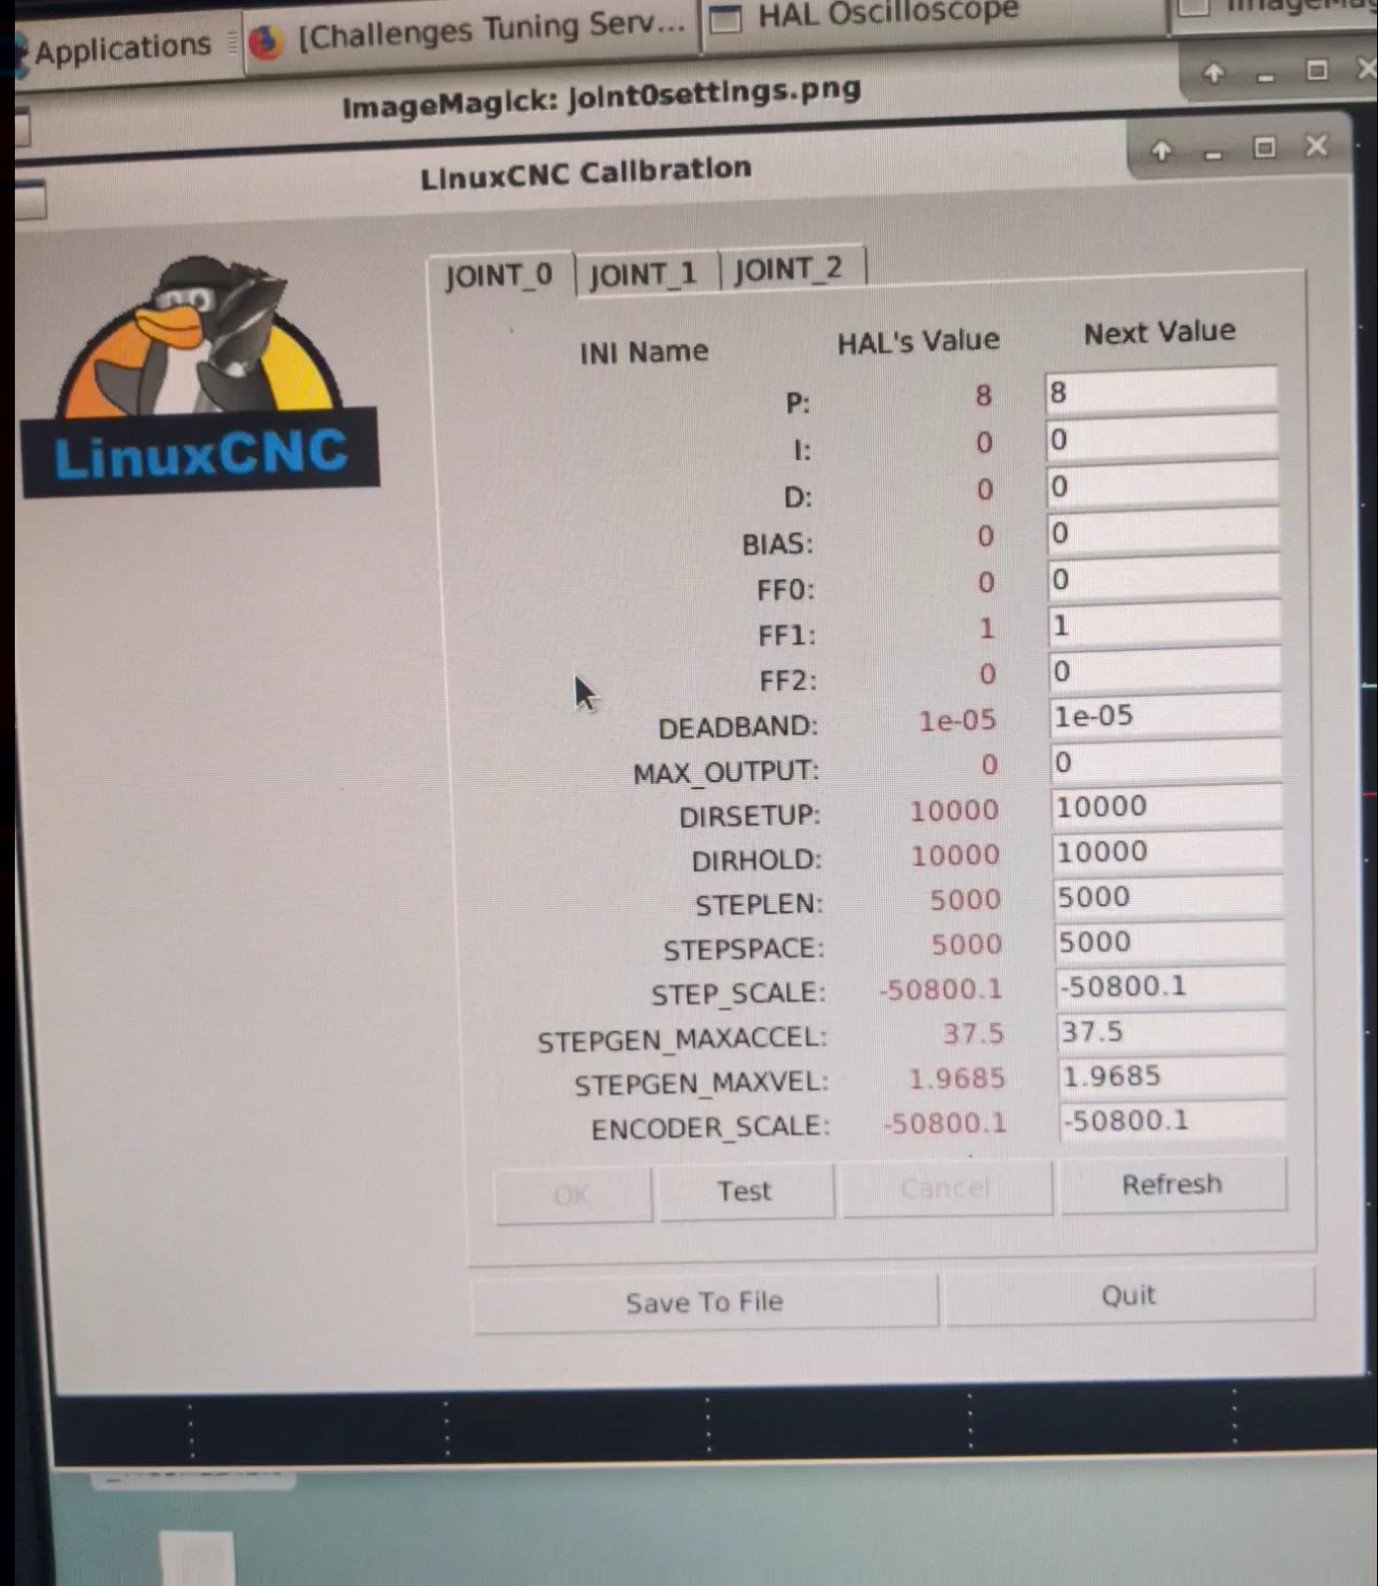
Here is a shot of my settings for Joint 0


Based on your last post I know that you were suggesting that I change a few things in my HAL file to try to verify the tune of the actual servo drive. Unfortunately looking through my HAL file i don't find anything that quite matches what you are describing. If its possible that you could take a look at the attached HAL file and copy the lines in that I should change and what to that would be immensely helpful.

I appreciate everyone on heres support and look forward to getting my machine up and running!

File Attachment:

File Name: TC225_2020-07-18.hal
File Size:11.16 KB

File Attachment:

File Name: TC225_2020-07-18.ini
File Size:4.27 KB
Last edit: 6 years 3 months ago by Type_Zero_Design.

Please Log in or Create an account to join the conversation.

More
6 years 3 months ago #175108 by PCW
It looks to me like the drive is limiting the acceleration
Did you check your drive manual for setting that may either filter
input or limit the acceleration?


To try open loop you would change (X axis for example)

net x-pos-fb <= hm2_7i76e.0.encoder.00.position
to
net x-pos-fb <= hm2_7i76e.0.stepgen.00.position-fb

(note that P should be 1000 for open loop and FF1=1)

Please Log in or Create an account to join the conversation.

More
6 years 3 months ago #175147 by Type_Zero_Design
PCW

I went through the manual and found these two parameters that might fall in line with what you were discussing. Do either one seem like something that I should look into? If so what kind of adjustment do you recommend?


Thanks for the help, I will report back my open loop results in a few.

Please Log in or Create an account to join the conversation.

Time to create page: 0.235 seconds
Powered by Kunena Forum
