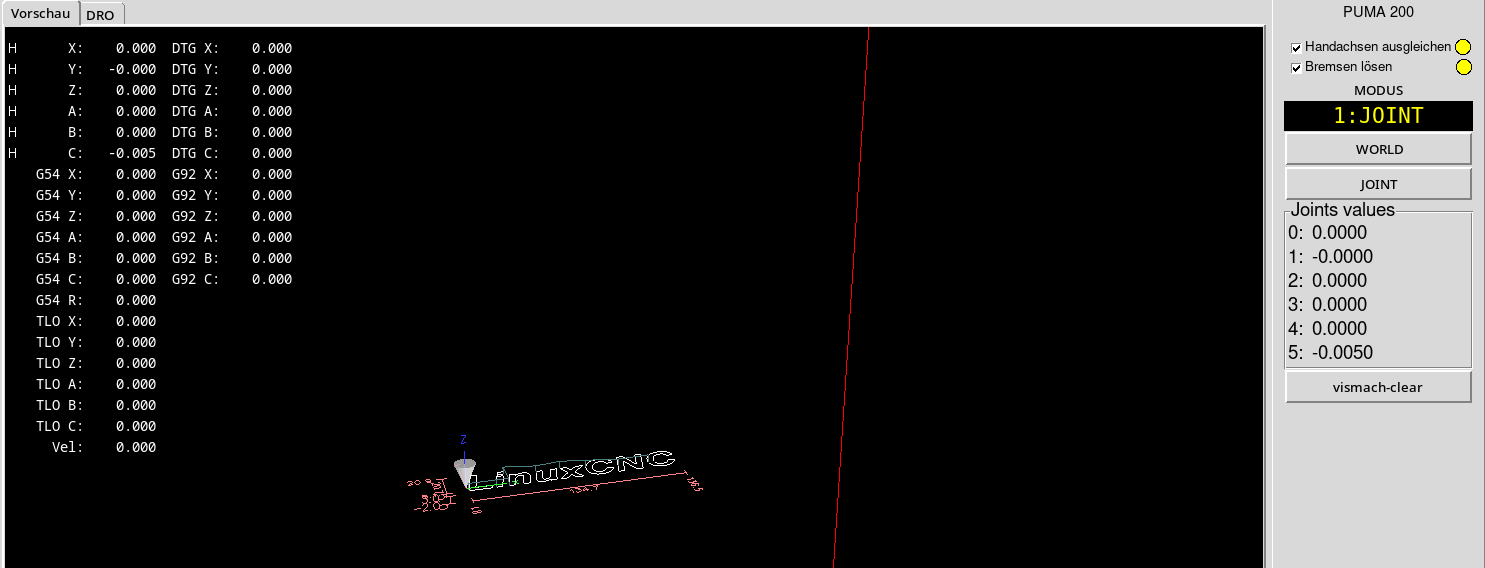
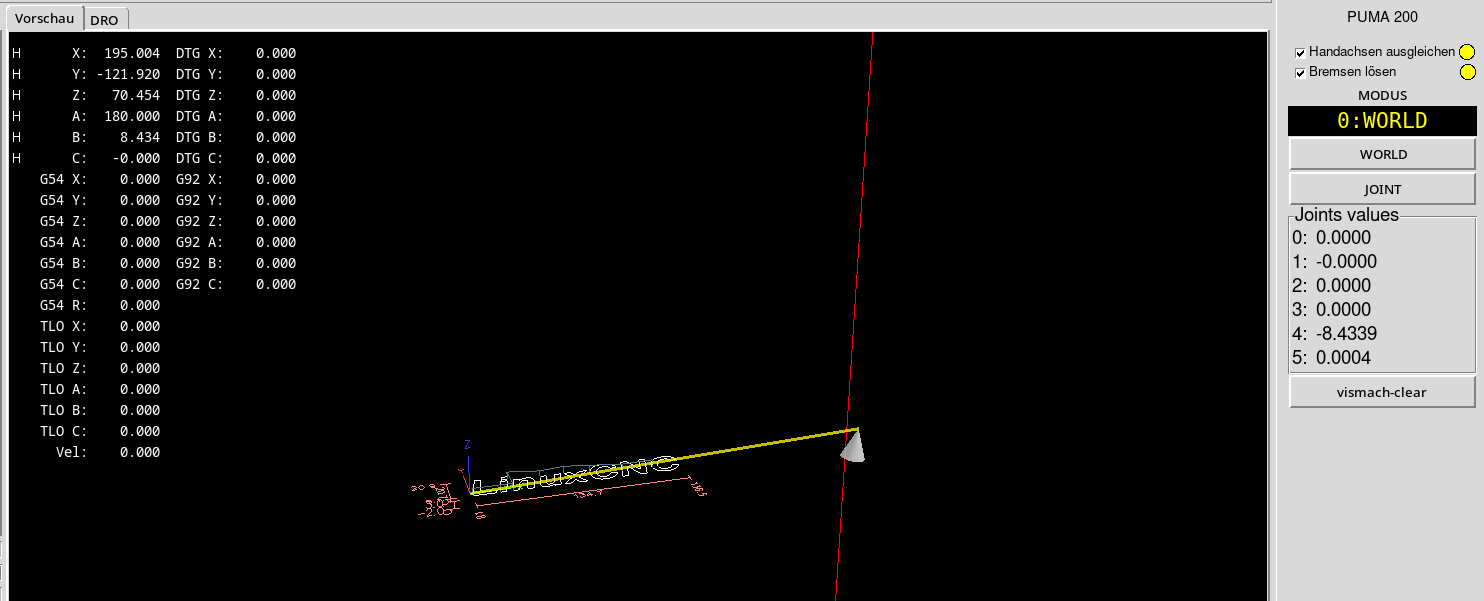
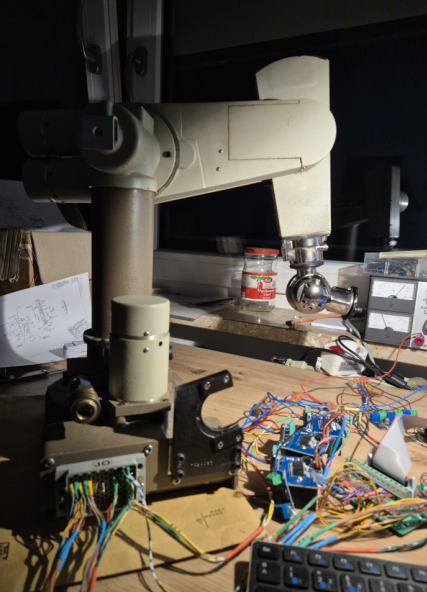
ok the first pose is what i wish... arm is on the right side from the " tower" this means there is a -Y correct.
i played a little bit arround...
what i found: some failures are "softlimit positiv reached 500" i open the min max limits to 750 - 750... still for play more arround. after this message i get position error... but ich can manual jog in jooint mode many more deg. and all speeds are slow!
you wrote :
Lets verify your home pose:
1. Home the arm
2. Activate 'Identity' mode
3. Remove all offsets (MDI: g10 l2 p0 x0 y0 z0 a0 b0 c0)
4. Move all joints except joint_4 to zero (MDI: g0 x0 y0 z0 a0 b0 c0)
5. Take a screenshot of the axis gui window
6. Take a picture from the side (ie the Y direction) of your robot
7. Post the two images
i do the g00 x0y0z0 a0b0c0.. but correct would be without a0?
i have really issues with the right hand rule and rotate and flip the coordinatesystem.. i must build something with toothpicks and a cheese cube..

...
homeing : i need on joint 4 or 5 ( joints here not linuxcnc.. i men robot) a 1deg. offset..if i dont have it.. kinematic errors came after homing... like in the example.. but with the puma560 genser simulator.. i can rebuild the existing failures....
if i throw in the ini the line in:
RS274NGC_STARTUP_CODE = G21 G10L2P0 x19.2 y5.5 z9.4 a90 b0 c90 (debug, ini: startup offsets1 set)
this line is from the gesner kins puma 560 example
it works better on my real puma