I think I have the system in control now, and have reached the point where I want to add an encoder to the spindle for rigid tapping and better speed control.
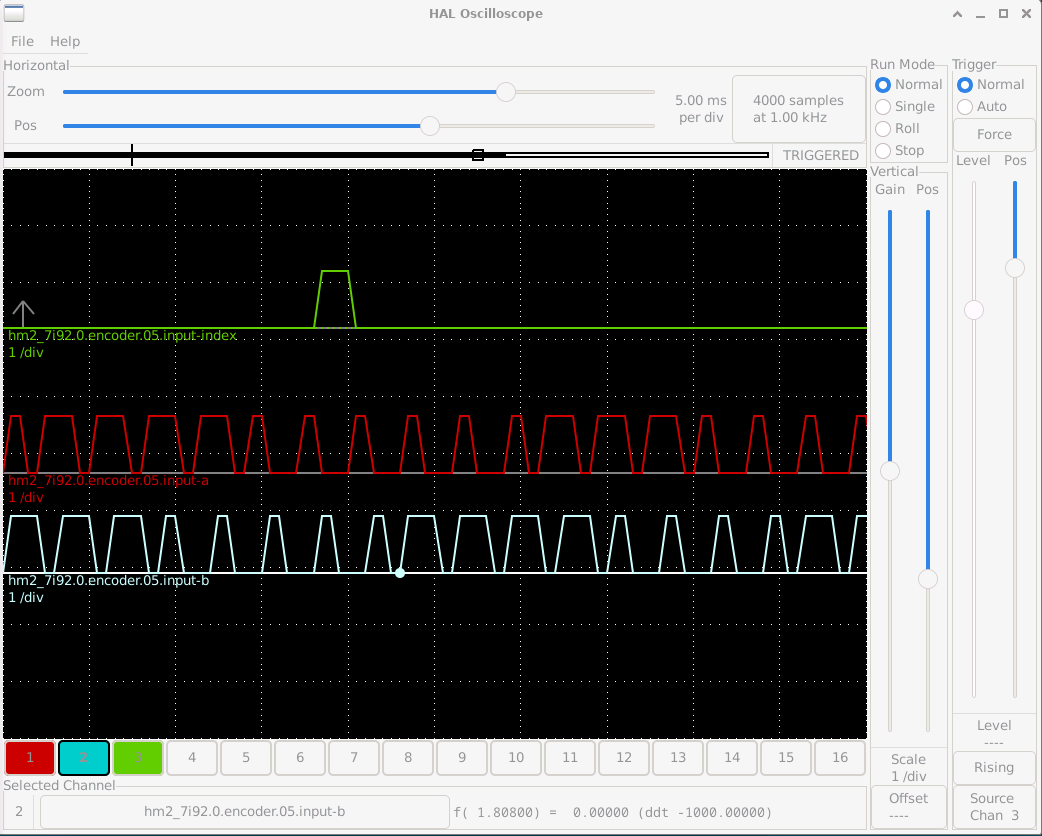
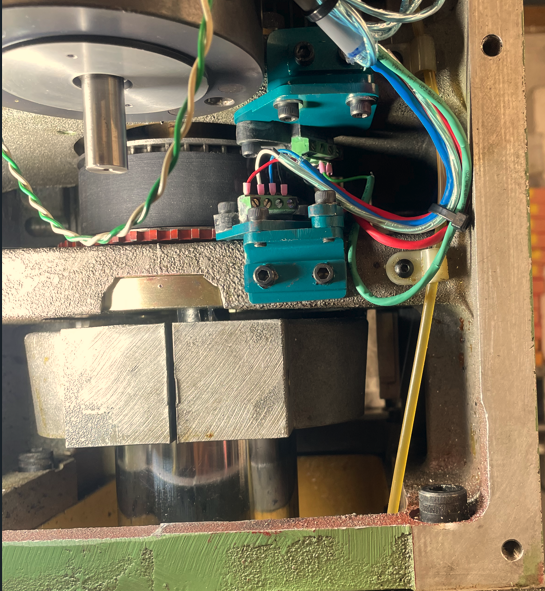
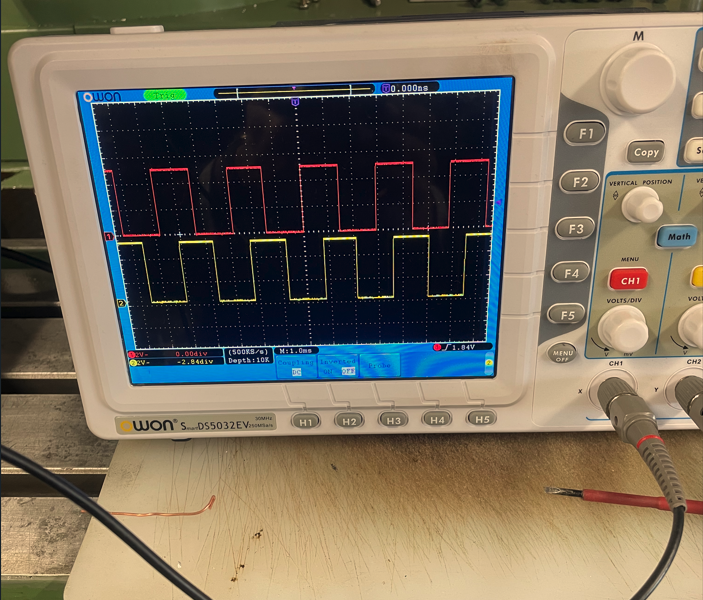
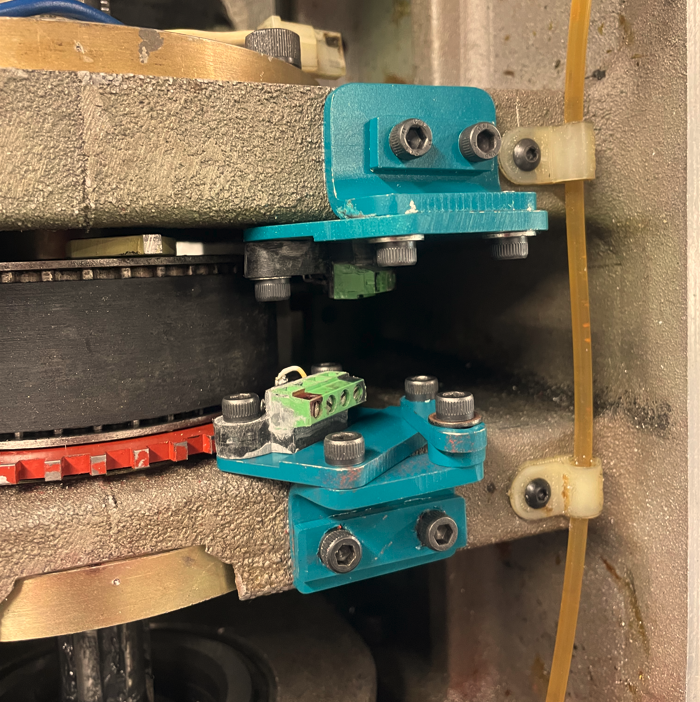
My plan had been to add a toothed wheel with a pair of hall effect sensors, one a few teeth away, but half a cycle out of phase for quadrature, and a third for an index. Then connect these directly into the 7i77 channel 5 encoder inputs. (some biasing resistors maybe required also)
The maximum spindle rpm is 3500. I was proposing 40 teeth, but on say an M6 thread with 1mm pitch, I think that's a possible pitch error of .00625mm, which is pretty small, but I guess 100 would be better. I'd appreciate others opinions on this choice please.
Secondly, because of the belt run and lack of clearance around the belt pulley, putting the index tooth on is a much bigger mission than I was expecting.
Can I simply delete it and use a missing tooth, or pair of missing teeth as the index?
What looks to me like it might not so simply work is the encoder quadrature when it reaches the missing tooth, or am I over thinking this?
Thanks