LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)

More
2 years 2 months ago #307226 by Cant do this anymore bye all
Optos driving optos, people copying other designs with no real knowledge. Or “it’s what someone on cnczone recommended”.
re UDP, it’s simple to setup, proven by years of implementation and works.
I think what would be great, is that the FPGA reports it’s capabilities to the driver so the driver doesn’t require rebuilding. Tho it would make things way more complicated to implement.
Regarding isolated drivers that topic did come up a little while ago maybe 12 ish months, so it is something that has discussed.
Oh yeah common grounds with optos, that’s something I just can’t fathom. Maybe there is a reason in some applications, but for the most common application, providing isolation, I don’t get it.

These could be an idea for output
www.icbase.com/File/PDF/ONS/ONS56621412.pdf
The following user(s) said Thank You: Mecanix

Please Log in or Create an account to join the conversation.
More
2 years 2 months ago #307227 by Mecanix

Also possible with W5500 on Mac level
 
No Thank You Very Much. Interesting none the less. 

What we currently have is STUPID FAST and high performance already. Unless a mysterious someone has a requirement for an hypersonic motion machine-tool, nobody here (in our star system anyway) will be able to ceiling the perf of RIO as-is on any parts/processes level. 

Not sure what you did but after updating the git today I'm clocking this x2 speed of what it was a few days ago. Used to be 2.5ms, now down to little more than a millisecond. Impressive stuff, Olivier. 

Please Log in or Create an account to join the conversation.

More
2 years 2 months ago #307230 by Mecanix
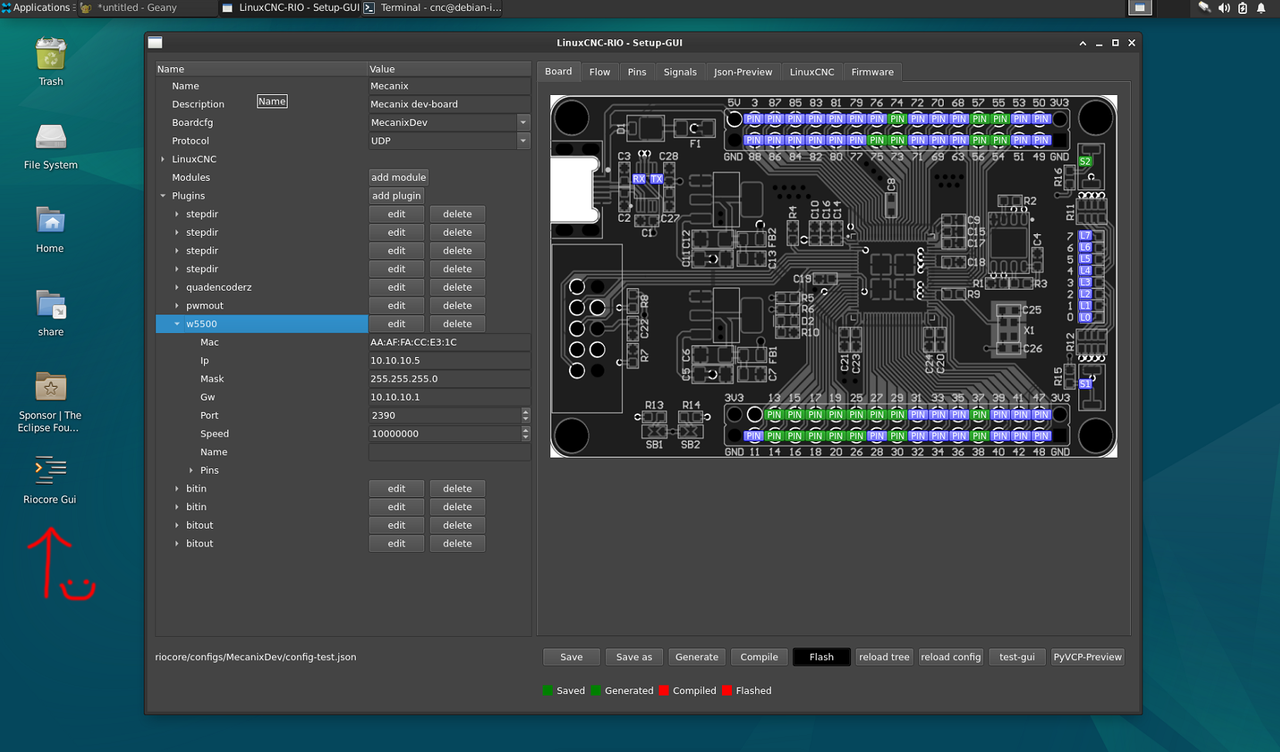
Finally got my Riocore Gui desktop icon working. No more cmd/cli endless keyboard input required. Just double click desktop ico, change stuff, save, generate!!

Change Exec= /to your paths/, save file on your desktop as type "Riocore Gui.desktop"
Code:
[Desktop Entry] Name=Riocore Gui Comment=Riocore Gui Exec=bash -i -c "cd ~/rio/riocore; source ~/rio/riocore/bin/activate; PYTHONPATH=. bin/rio-setup riocore/configs/MecanixDev/config-test.json" Icon=format-indent-less-rtl Type=Application Path= Terminal=false StartupNotify=false
 

Please Log in or Create an account to join the conversation.

More
2 years 2 months ago #307231 by Mecanix
And yet another post!! Because, well, I can and and and and because it's "LinuxCNC-RIO Week!!!"

The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.

More
2 years 2 months ago #307242 by meister

Also possible with W5500 on Mac level
 
No Thank You Very Much. Interesting none the less. 

What we currently have is STUPID FAST and high performance already. Unless a mysterious someone has a requirement for an hypersonic motion machine-tool, nobody here (in our star system anyway) will be able to ceiling the perf of RIO as-is on any parts/processes level. 

Not sure what you did but after updating the git today I'm clocking this x2 speed of what it was a few days ago. Used to be 2.5ms, now down to little more than a millisecond. Impressive stuff, Olivier. 

160890 == 0.16ms
all over 1ms would be to slow because we have 1Khz servo-thread

 
The following user(s) said Thank You: Mecanix

Please Log in or Create an account to join the conversation.

More
2 years 2 months ago #307266 by meister
sooo, small WARNING, I have now tidied up the boards and configs.
renamed a lot of things and removed all my test files.
if you are missing something, please let me know, i still have everything :)

i will shortly merge the dev branch into the main and then also remove the riogui repository (everything is in the riocore)


The following user(s) said Thank You: tommylight, Clive S, Mecanix

Please Log in or Create an account to join the conversation.

Time to create page: 1.285 seconds
Powered by Kunena Forum
