Closed loop with linear encoders but still backlash?

More
6 years 9 months ago #155568 by Gnevko
Today I had time to make some more additional tests on my machine. And of course as usual I am a little bit confused. The test is very simple:

1) to take a parallel with exactly 20.00 mm wide and set X axis to zero on the left side:


2) after that navigate to the right side of the parallel and read the value from DRO.


I expected to see something about 20.00mm (+- 0.01) but as you can see it is only 19.945mm
With is also very strange - the encoder position is not the same as stepgen.position-fb.

HAL Configuration for X:
Code:
#******************* # AXIS X JOINT 0 #******************* setp pid.x.Pgain [JOINT_0]P setp pid.x.Igain [JOINT_0]I setp pid.x.Dgain [JOINT_0]D setp pid.x.bias [JOINT_0]BIAS setp pid.x.FF0 [JOINT_0]FF0 setp pid.x.FF1 [JOINT_0]FF1 setp pid.x.FF2 [JOINT_0]FF2 setp pid.x.deadband [JOINT_0]DEADBAND setp pid.x.maxoutput [JOINT_0]MAX_OUTPUT setp pid.x.error-previous-target true setp pid.x.maxerror .000 # Step Gen signals/setup setp hm2_7i95.0.stepgen.00.dirsetup [JOINT_0]DIRSETUP setp hm2_7i95.0.stepgen.00.dirhold [JOINT_0]DIRHOLD setp hm2_7i95.0.stepgen.00.steplen [JOINT_0]STEPLEN setp hm2_7i95.0.stepgen.00.stepspace [JOINT_0]STEPSPACE setp hm2_7i95.0.stepgen.00.position-scale [JOINT_0]STEP_SCALE setp hm2_7i95.0.stepgen.00.step_type 0 setp hm2_7i95.0.stepgen.00.control-type 1 setp hm2_7i95.0.stepgen.00.maxaccel [JOINT_0]STEPGEN_MAXACCEL setp hm2_7i95.0.stepgen.00.maxvel [JOINT_0]STEPGEN_MAXVEL # ---Encoder feedback signals/setup--- setp hm2_7i95.0.encoder.00.counter-mode 0 setp hm2_7i95.0.encoder.00.filter 1 setp hm2_7i95.0.encoder.00.index-invert 0 setp hm2_7i95.0.encoder.00.index-mask 0 setp hm2_7i95.0.encoder.00.index-mask-invert 0 setp hm2_7i95.0.encoder.00.scale [JOINT_0]ENCODER_SCALE # ---closedloop stepper signals--- net x-pos-cmd <= joint.0.motor-pos-cmd net x-vel-cmd <= joint.0.vel-cmd net x-output => hm2_7i95.0.stepgen.00.velocity-cmd net x-pos-fb <= hm2_7i95.0.encoder.00.position net x-pos-fb => joint.0.motor-pos-fb net x-enable <= joint.0.amp-enable-out net x-enable => hm2_7i95.0.stepgen.00.enable #net x-index-enable <=> pid.x.index-enable net x-enable => pid.x.enable net x-pos-cmd => pid.x.command net x-pos-fb => pid.x.feedback net x-output <= pid.x.output # ---setup home / limit switch signals--- net min-home-x hm2_7i95.0.inmux.00.input-00 joint.0.home-sw-in joint.0.neg-lim-sw-in

MPG Configuration (because I made the navigation with it):
Code:
# Connect axis position related signals net pdnt.halui.axis.0.pos-feedback halui.axis.x.pos-feedback whb.halui.axis.0.pos-feedback net pdnt.halui.axis.1.pos-feedback halui.axis.y.pos-feedback whb.halui.axis.1.pos-feedback net pdnt.halui.axis.2.pos-feedback halui.axis.z.pos-feedback whb.halui.axis.2.pos-feedback net pdnt.halui.axis.0.pos-relative halui.axis.x.pos-relative whb.halui.axis.0.pos-relative net pdnt.halui.axis.1.pos-relative halui.axis.y.pos-relative whb.halui.axis.1.pos-relative net pdnt.halui.axis.2.pos-relative halui.axis.z.pos-relative whb.halui.axis.2.pos-relative

Please Log in or Create an account to join the conversation.

More
6 years 9 months ago #155570 by Todd Zuercher
What was your following error on the X axis at both those points? The PID may need more tuning.

2nd how much do you trust your edge finder gauge? It might be informative to find one side of an edge, then turn the spindle 180 degrees and check the gauge again.

Please Log in or Create an account to join the conversation.

More
6 years 9 months ago #155572 by Gnevko

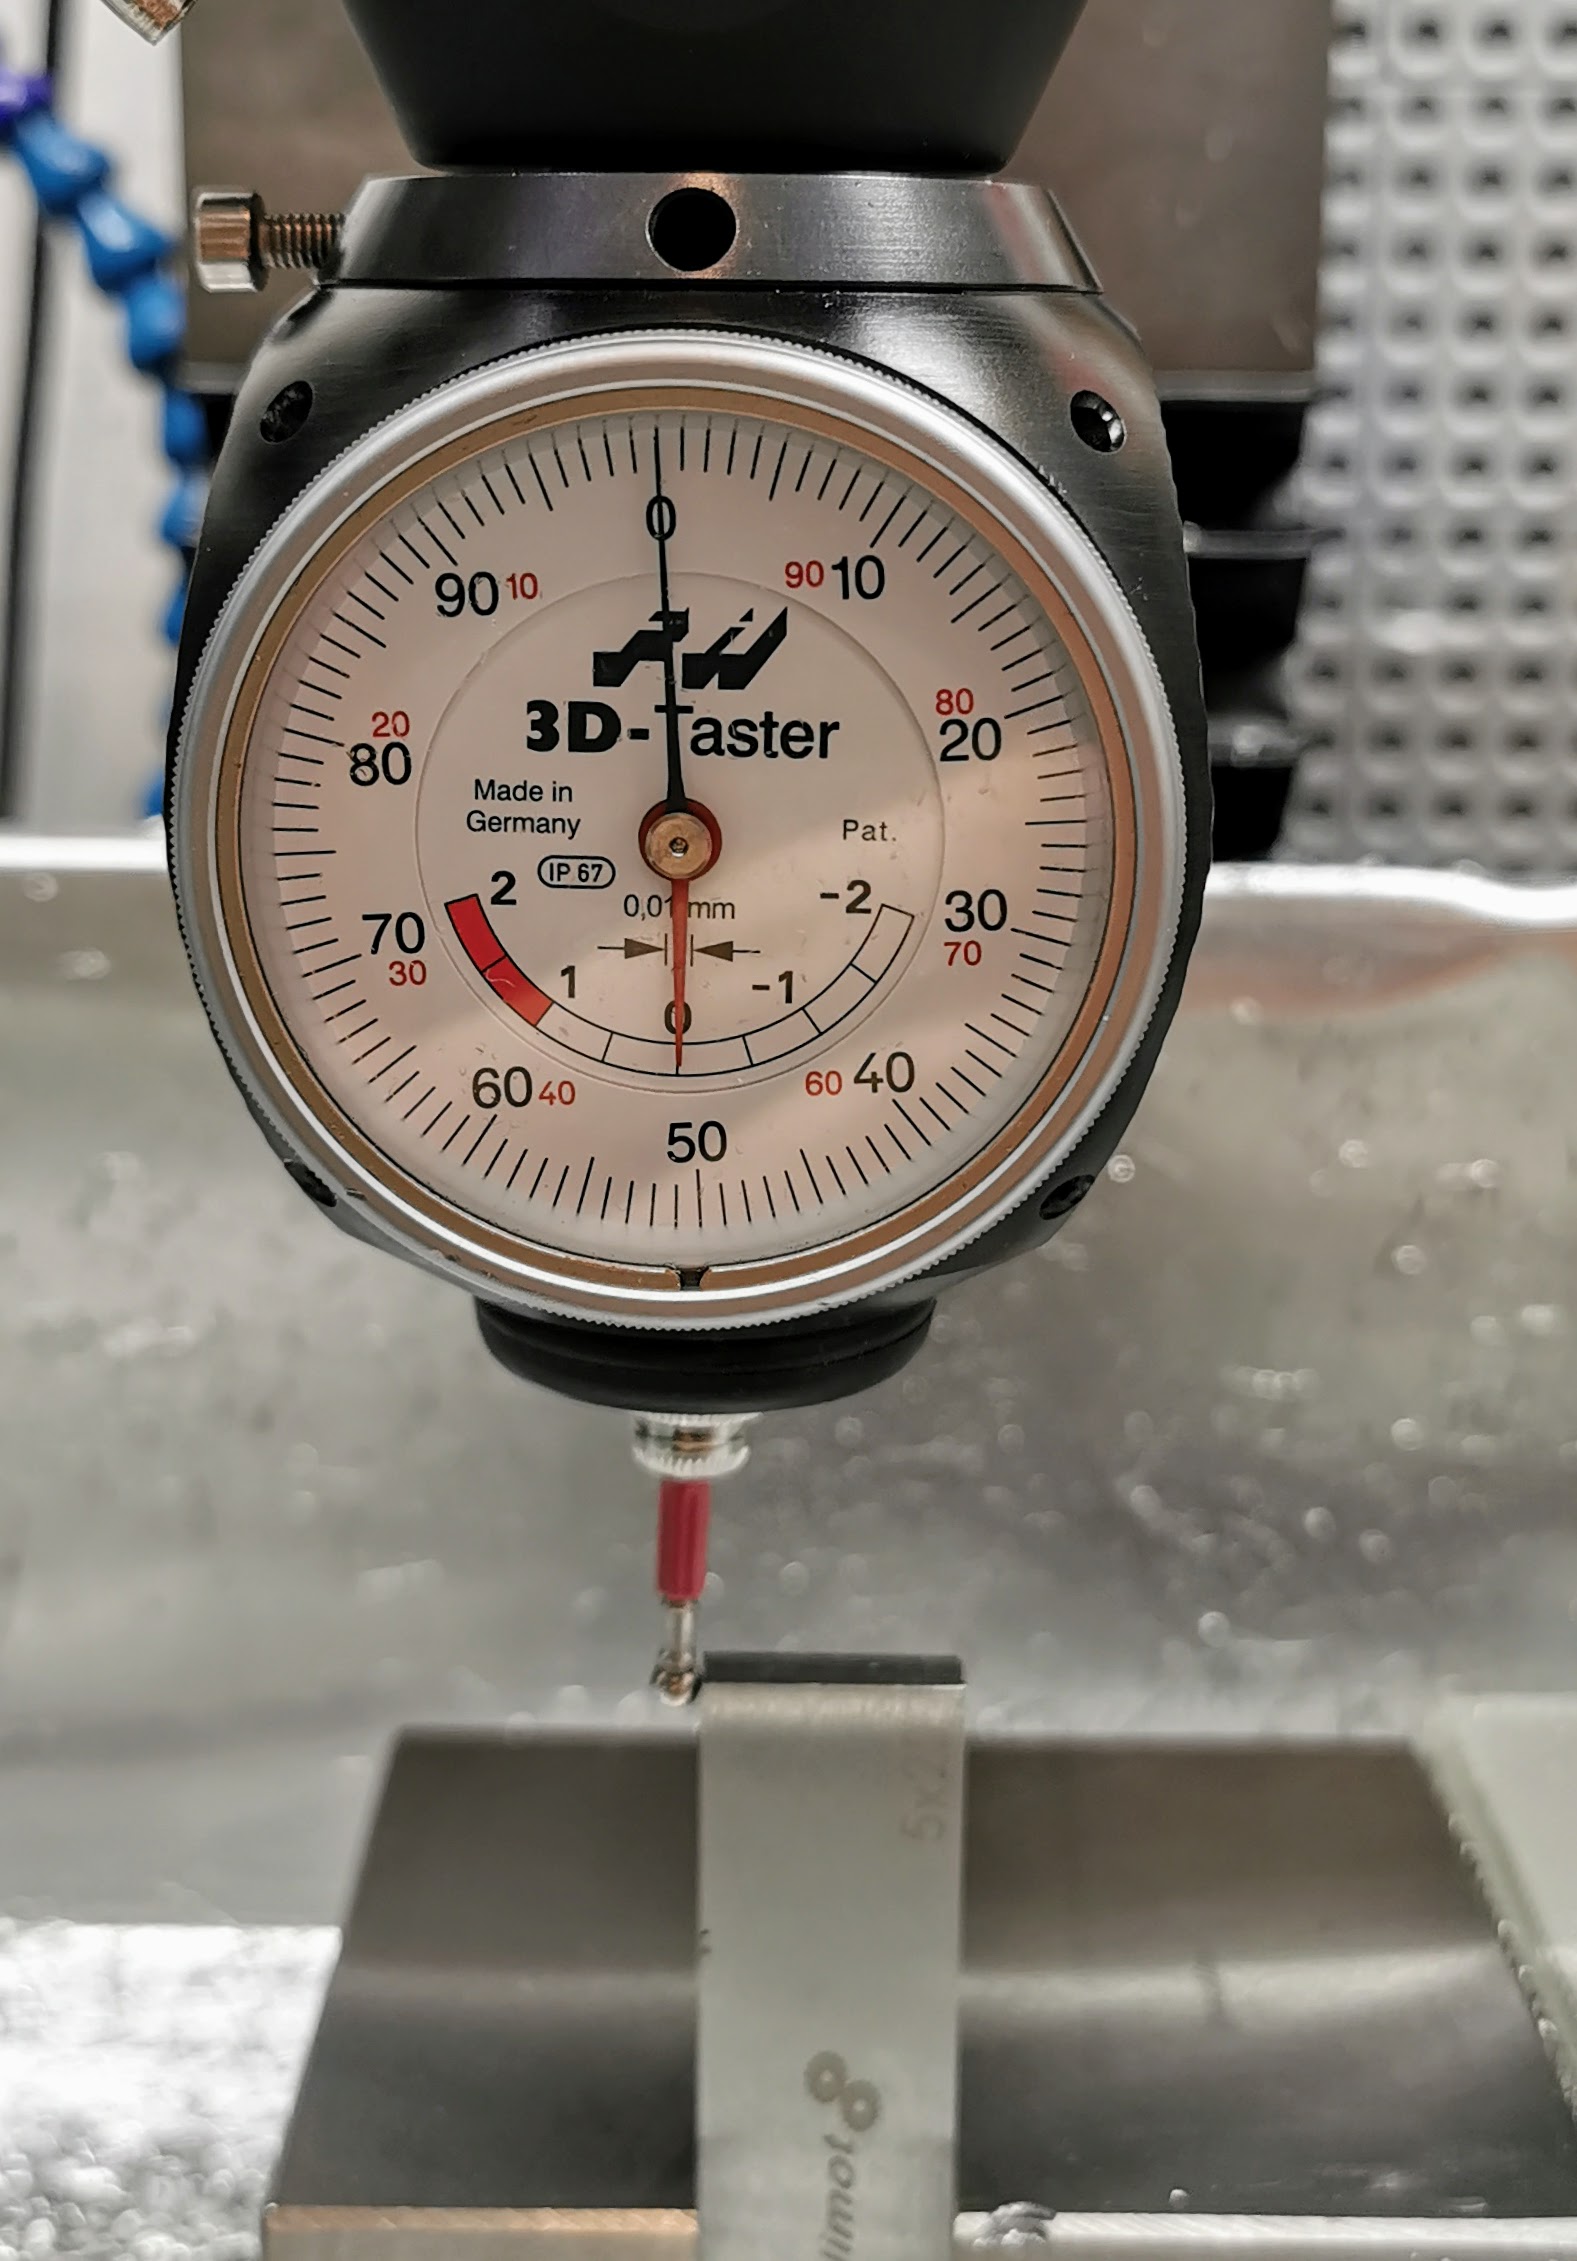
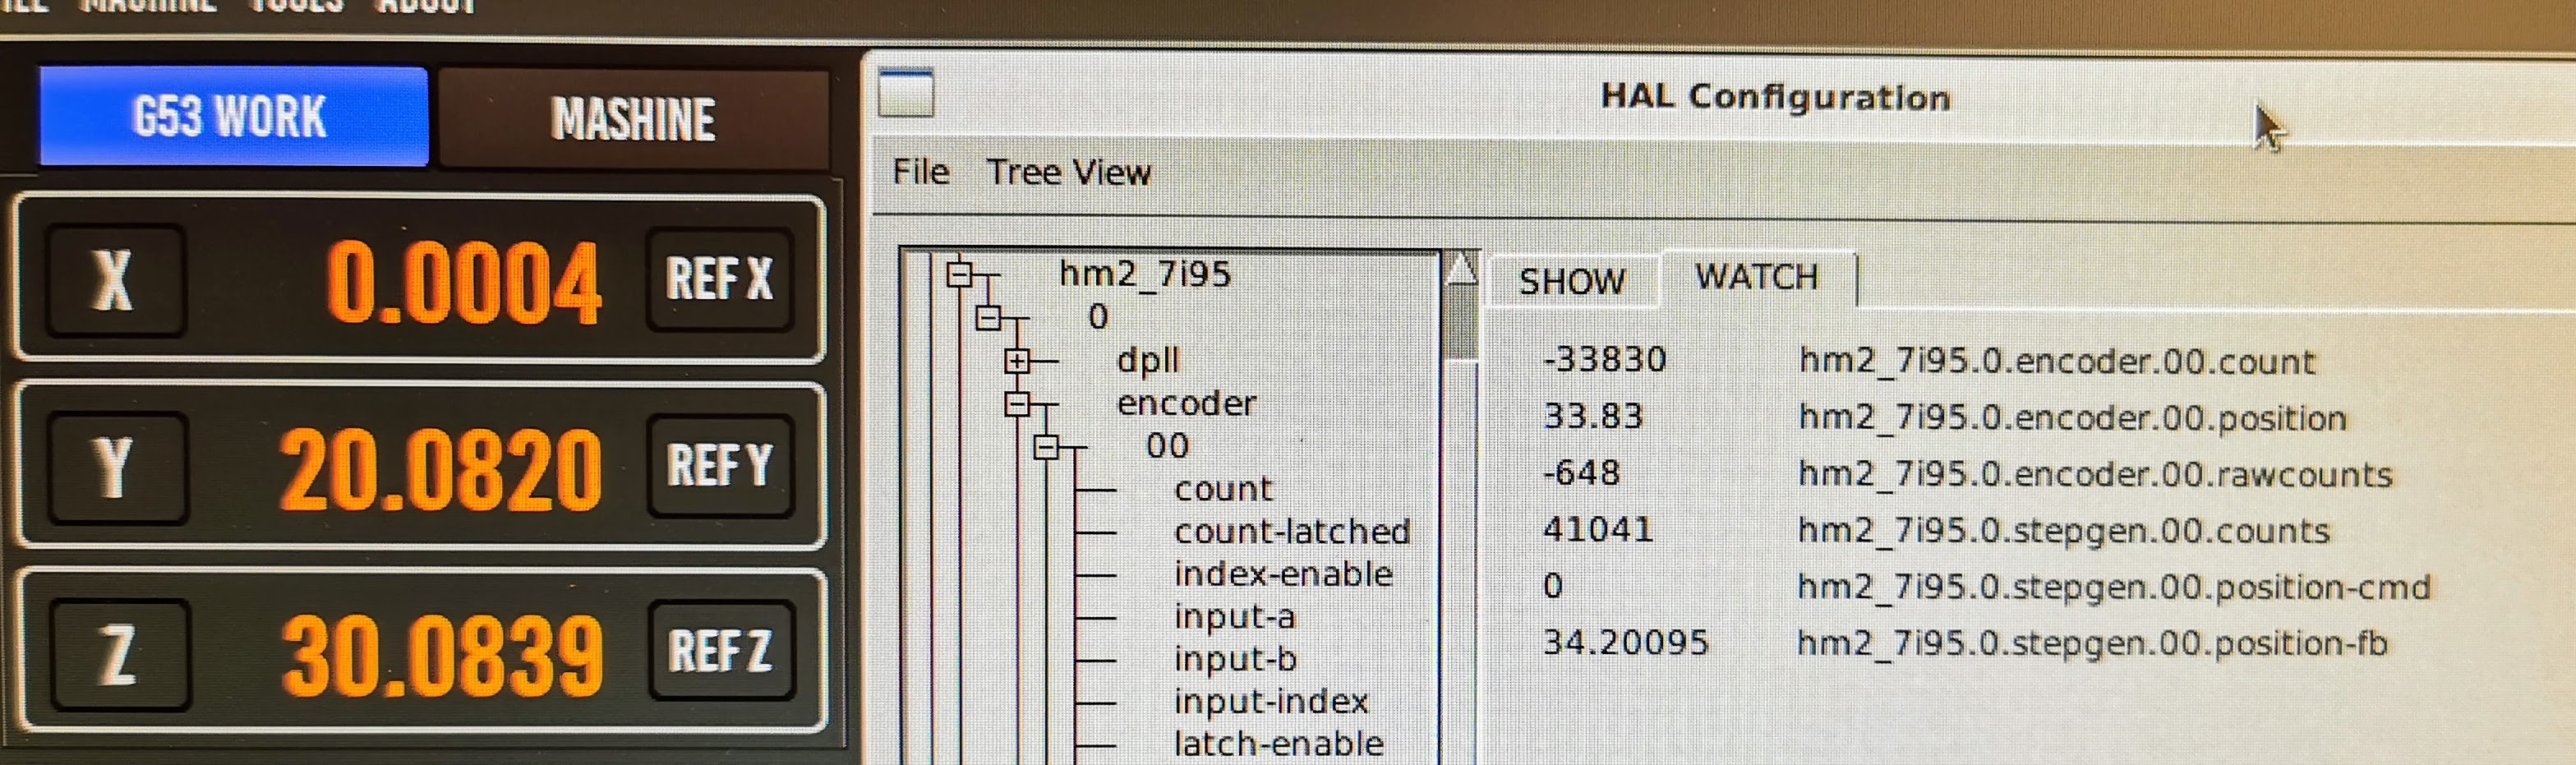
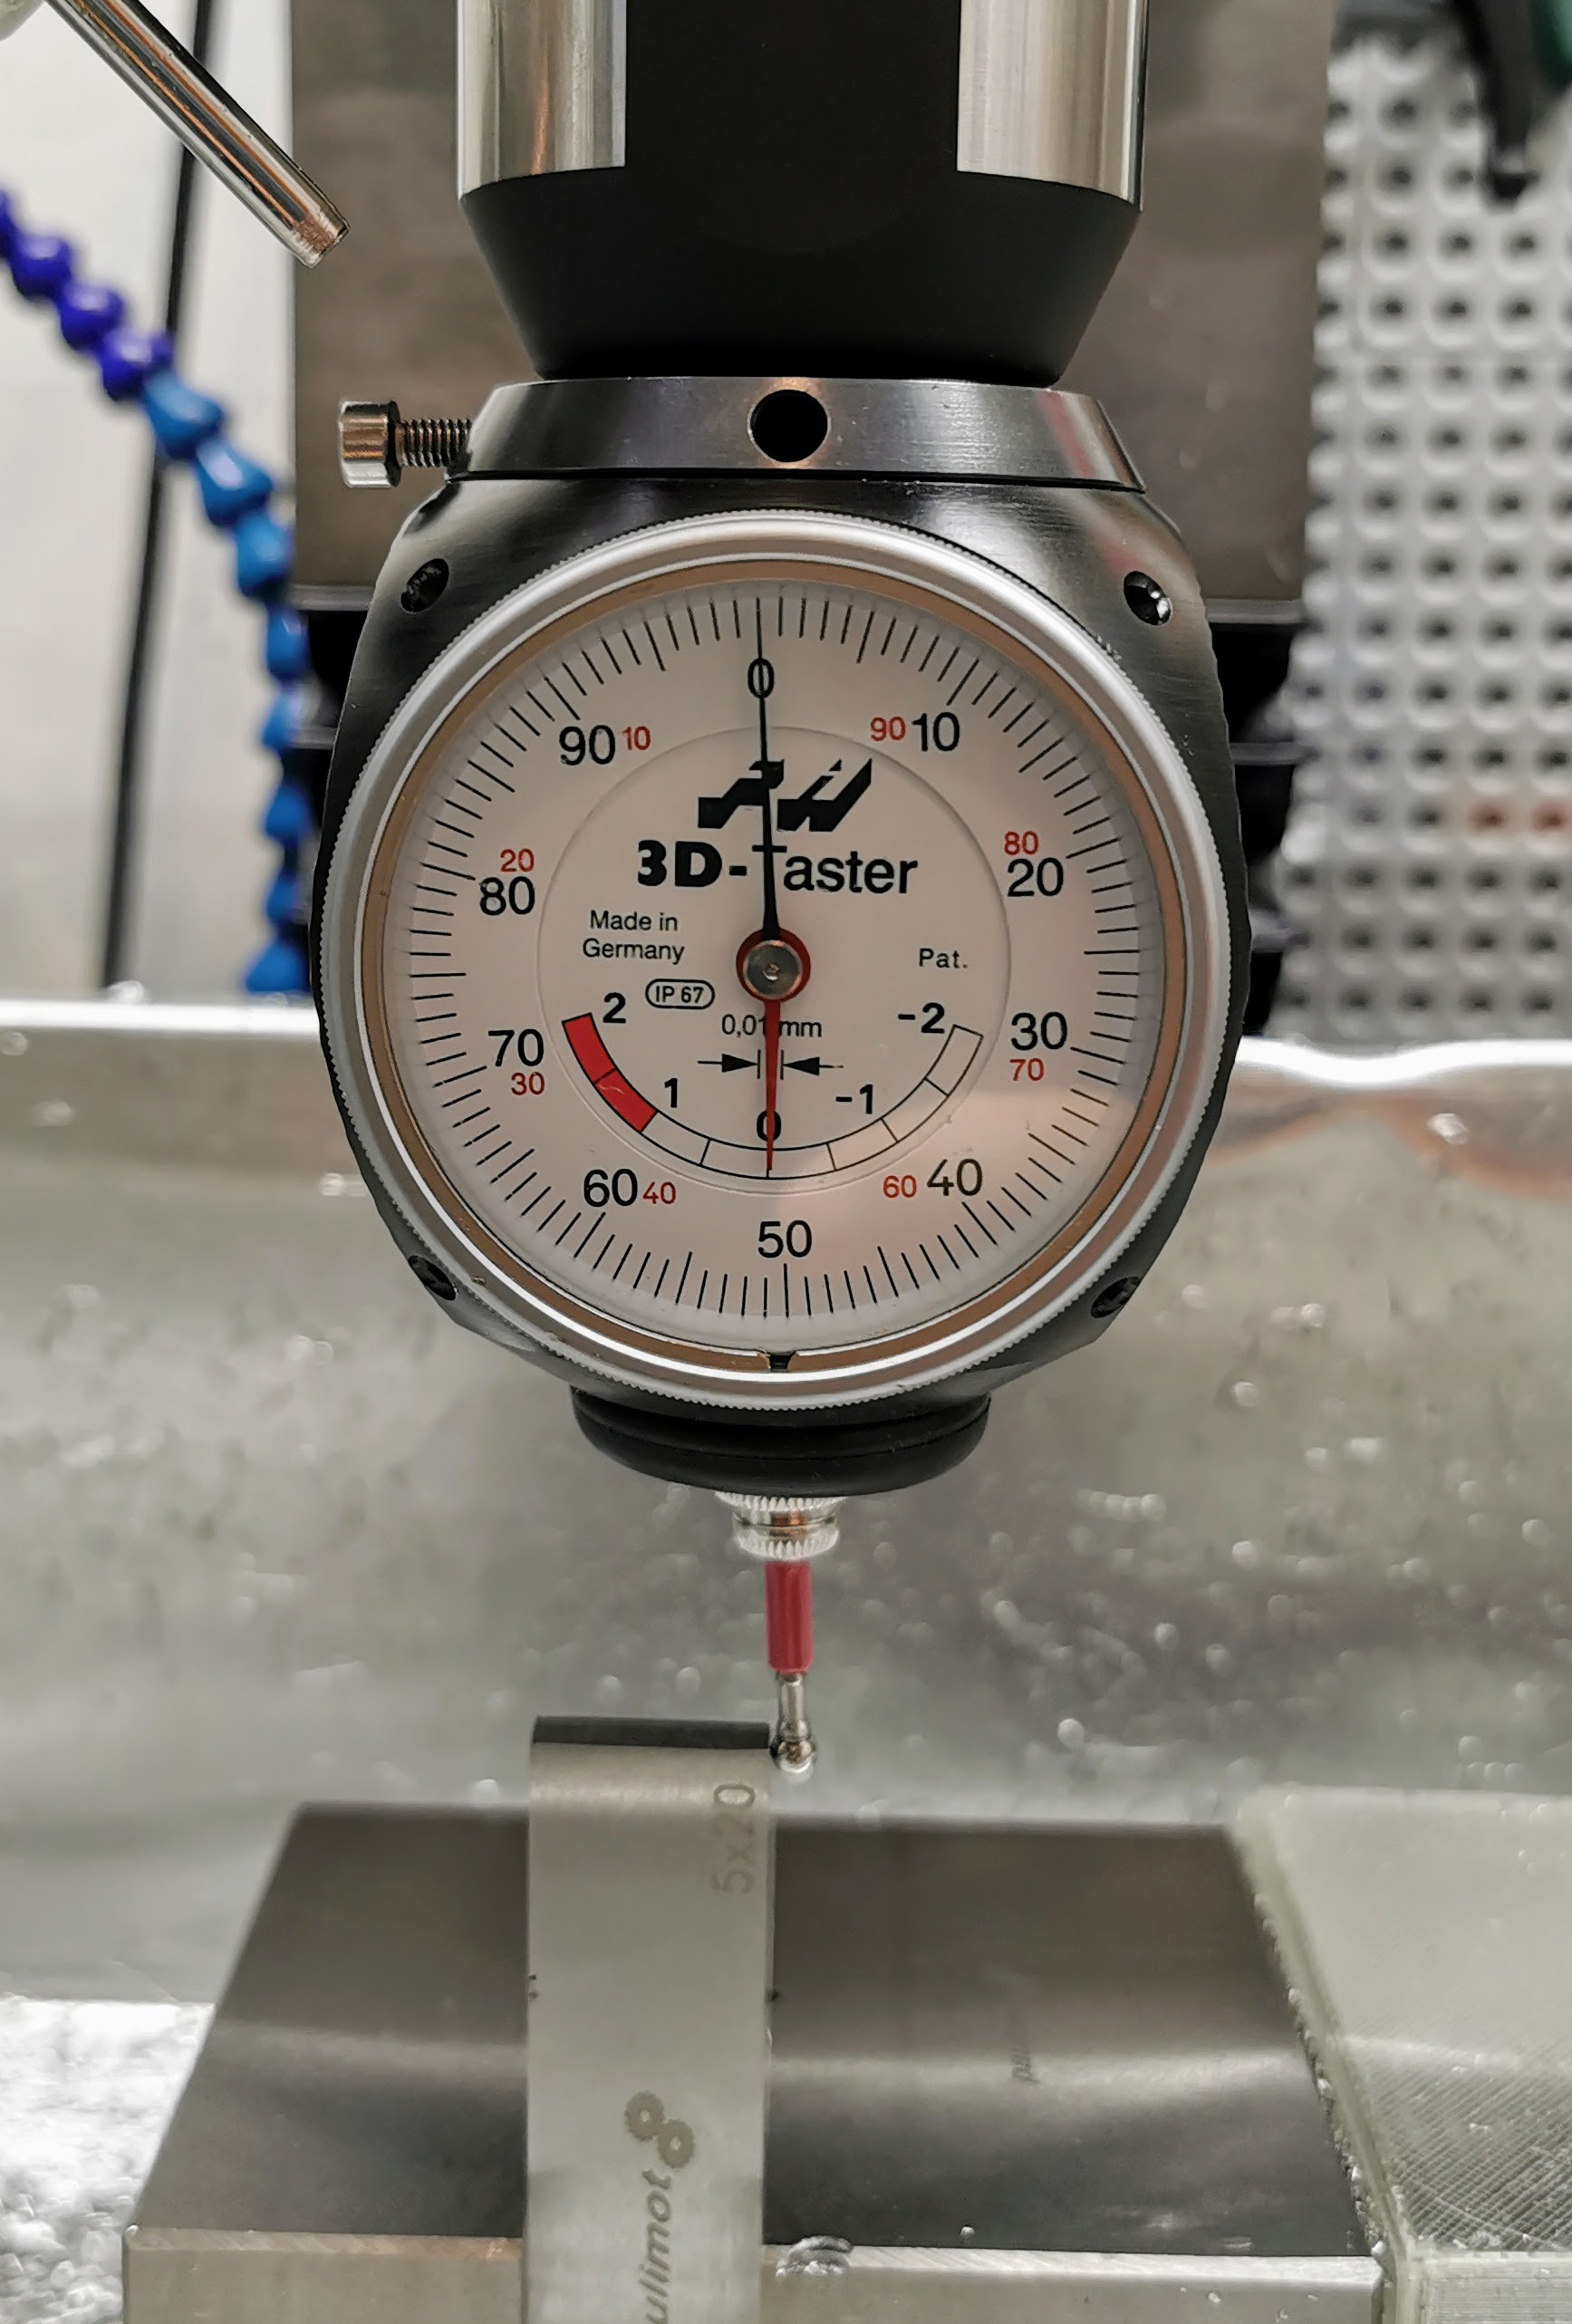
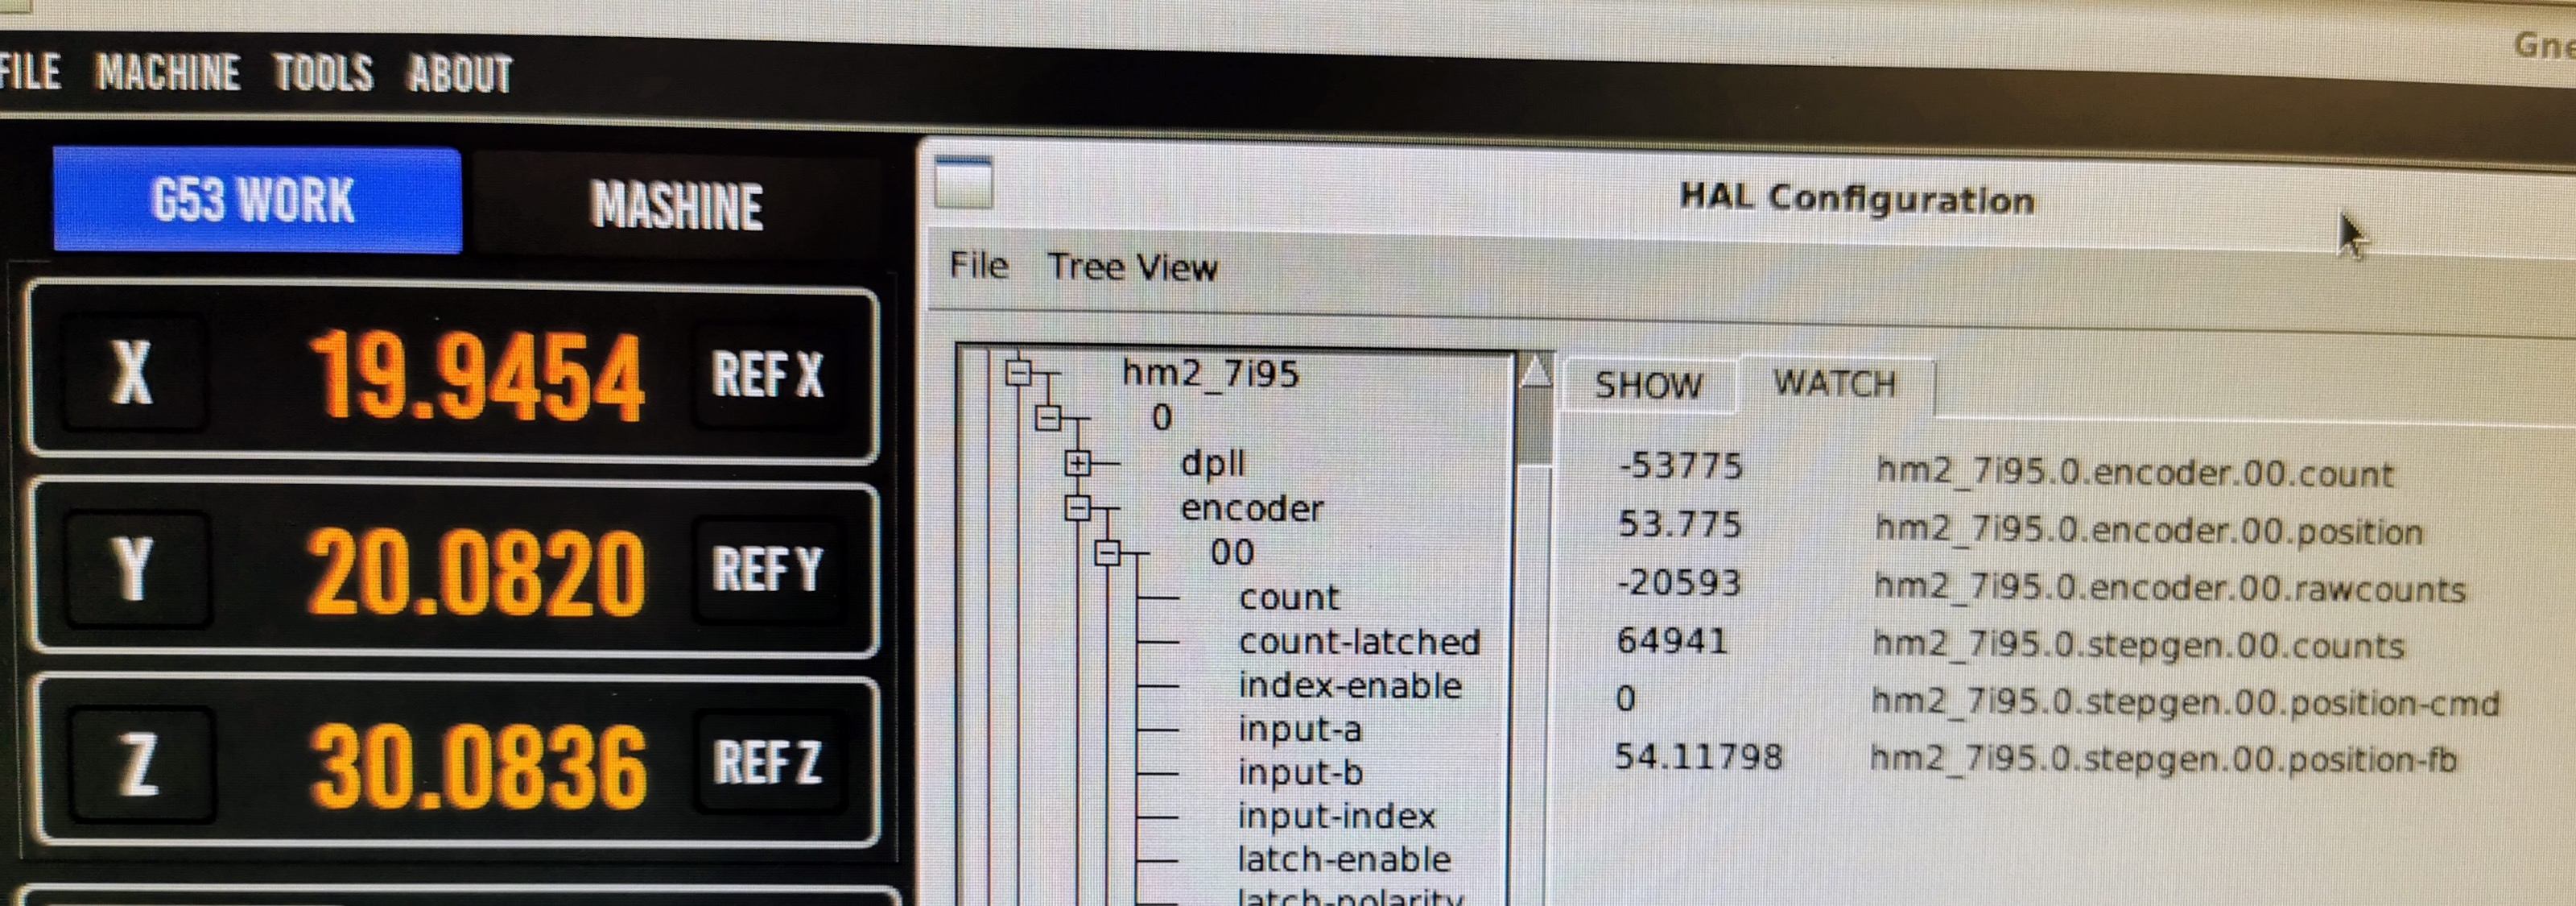
Todd Zuercher wrote: What was your following error on the X axis at both those points? The PID may need more tuning.
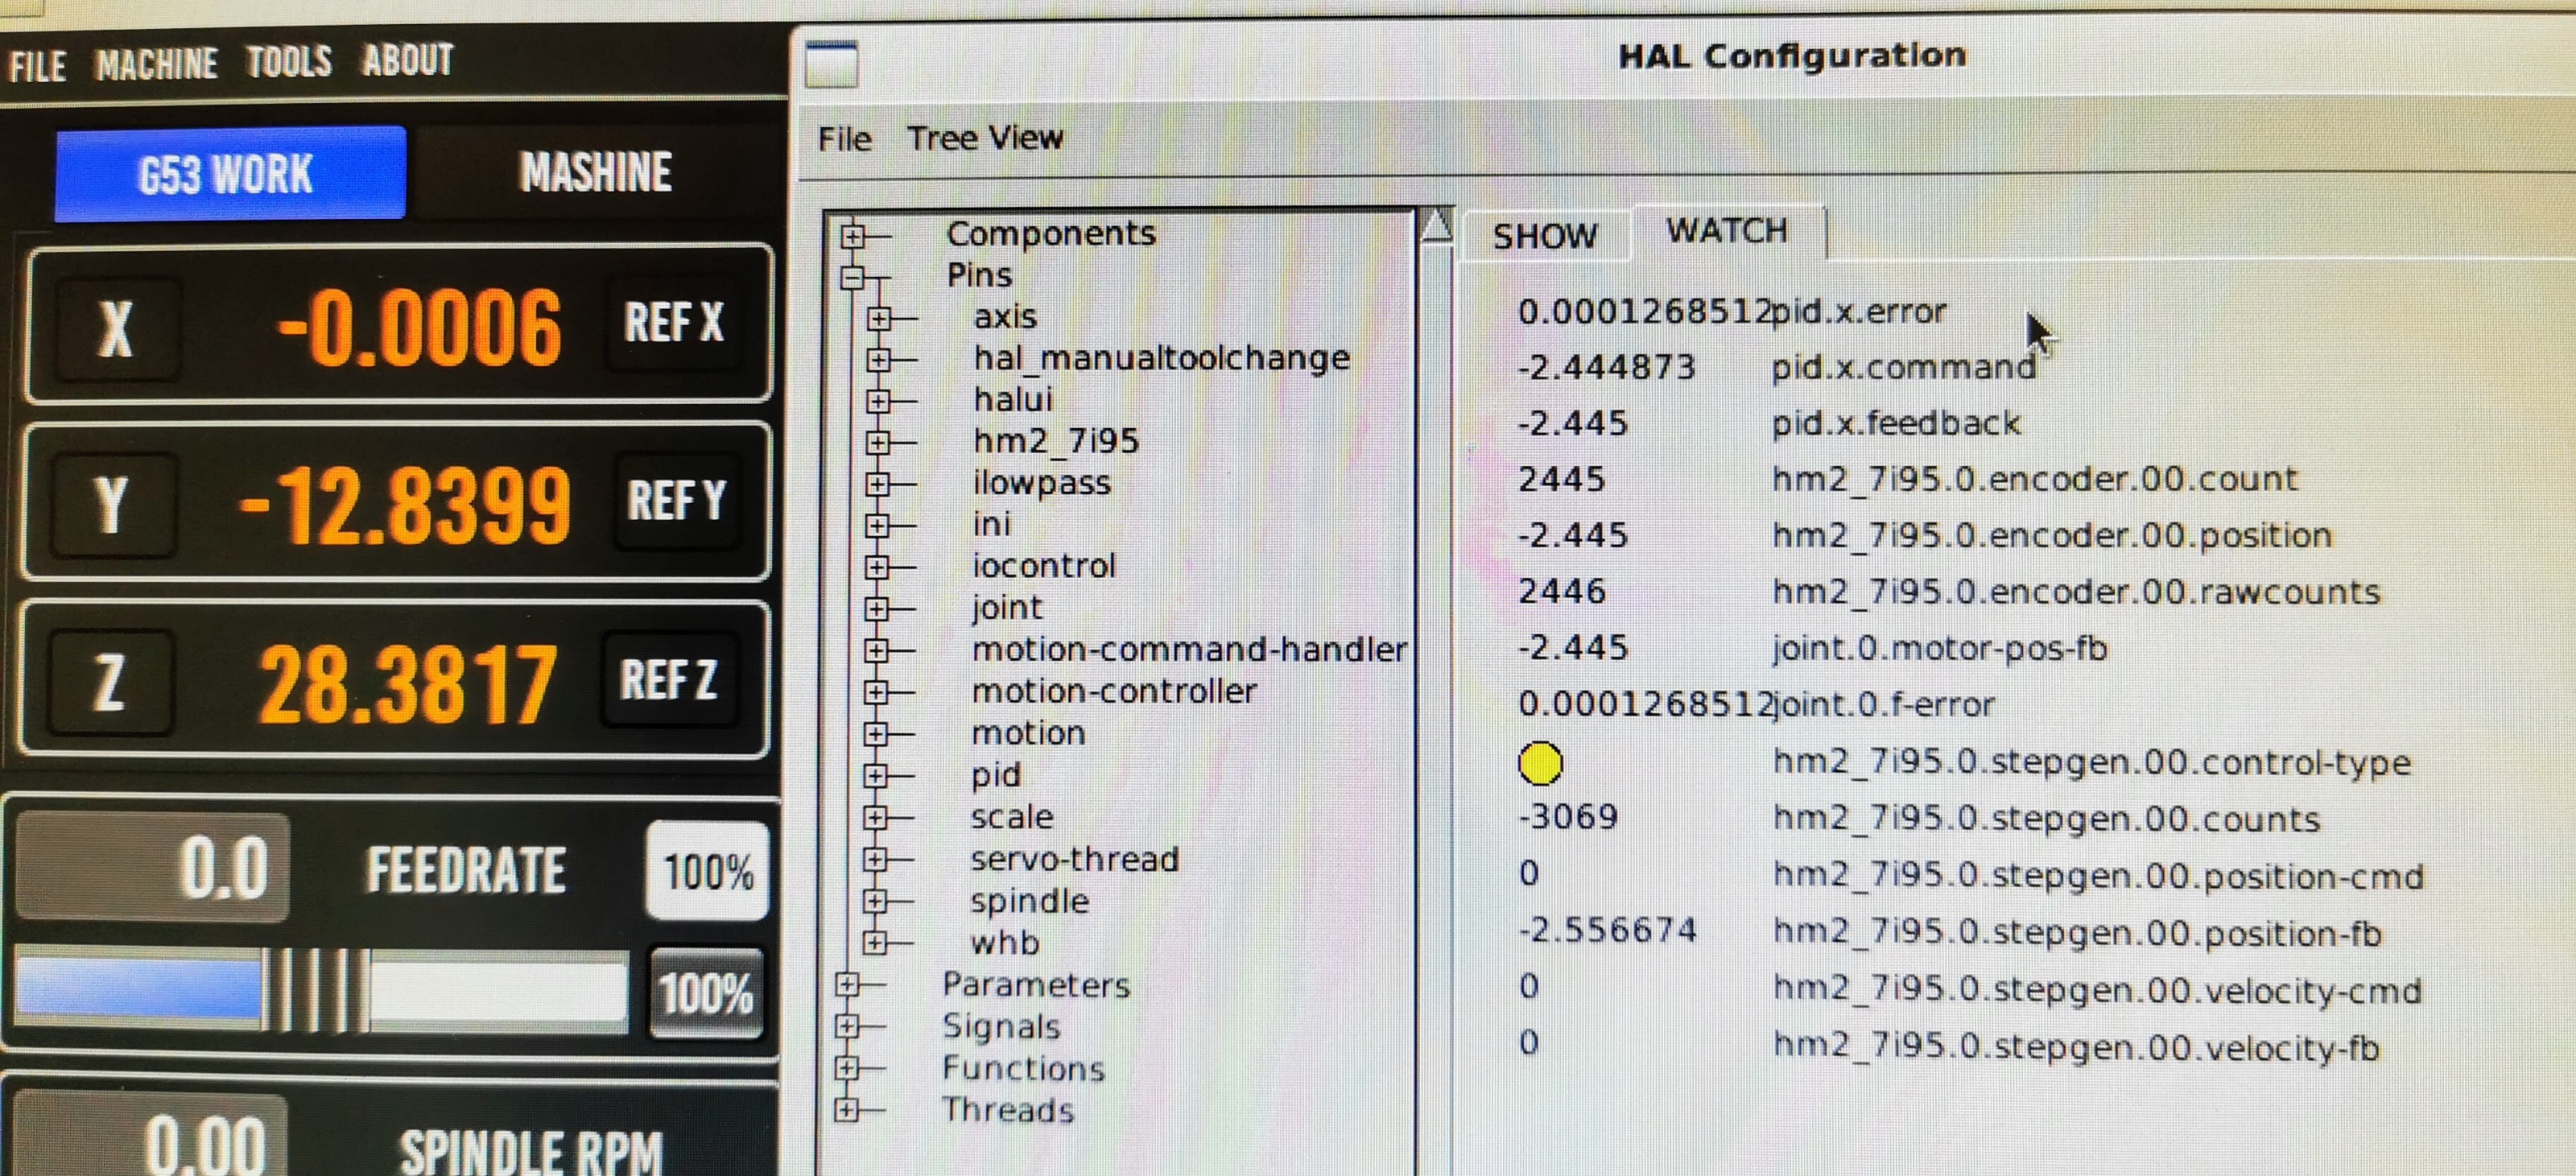

Position 1


Position 2

Todd Zuercher wrote: 2nd how much do you trust your edge finder gauge? It might be informative to find one side of an edge, then turn the spindle 180 degrees and check the gauge again.


I made this test already more times :) Deviation is something under 0.01mm and not only for 180 degrees, but also for 90 and 270 degrees.

Please Log in or Create an account to join the conversation.

More
6 years 9 months ago #155576 by Todd Zuercher
Make sure you don't have backlash compensation enabled.

Double check your encoder scale is correct.

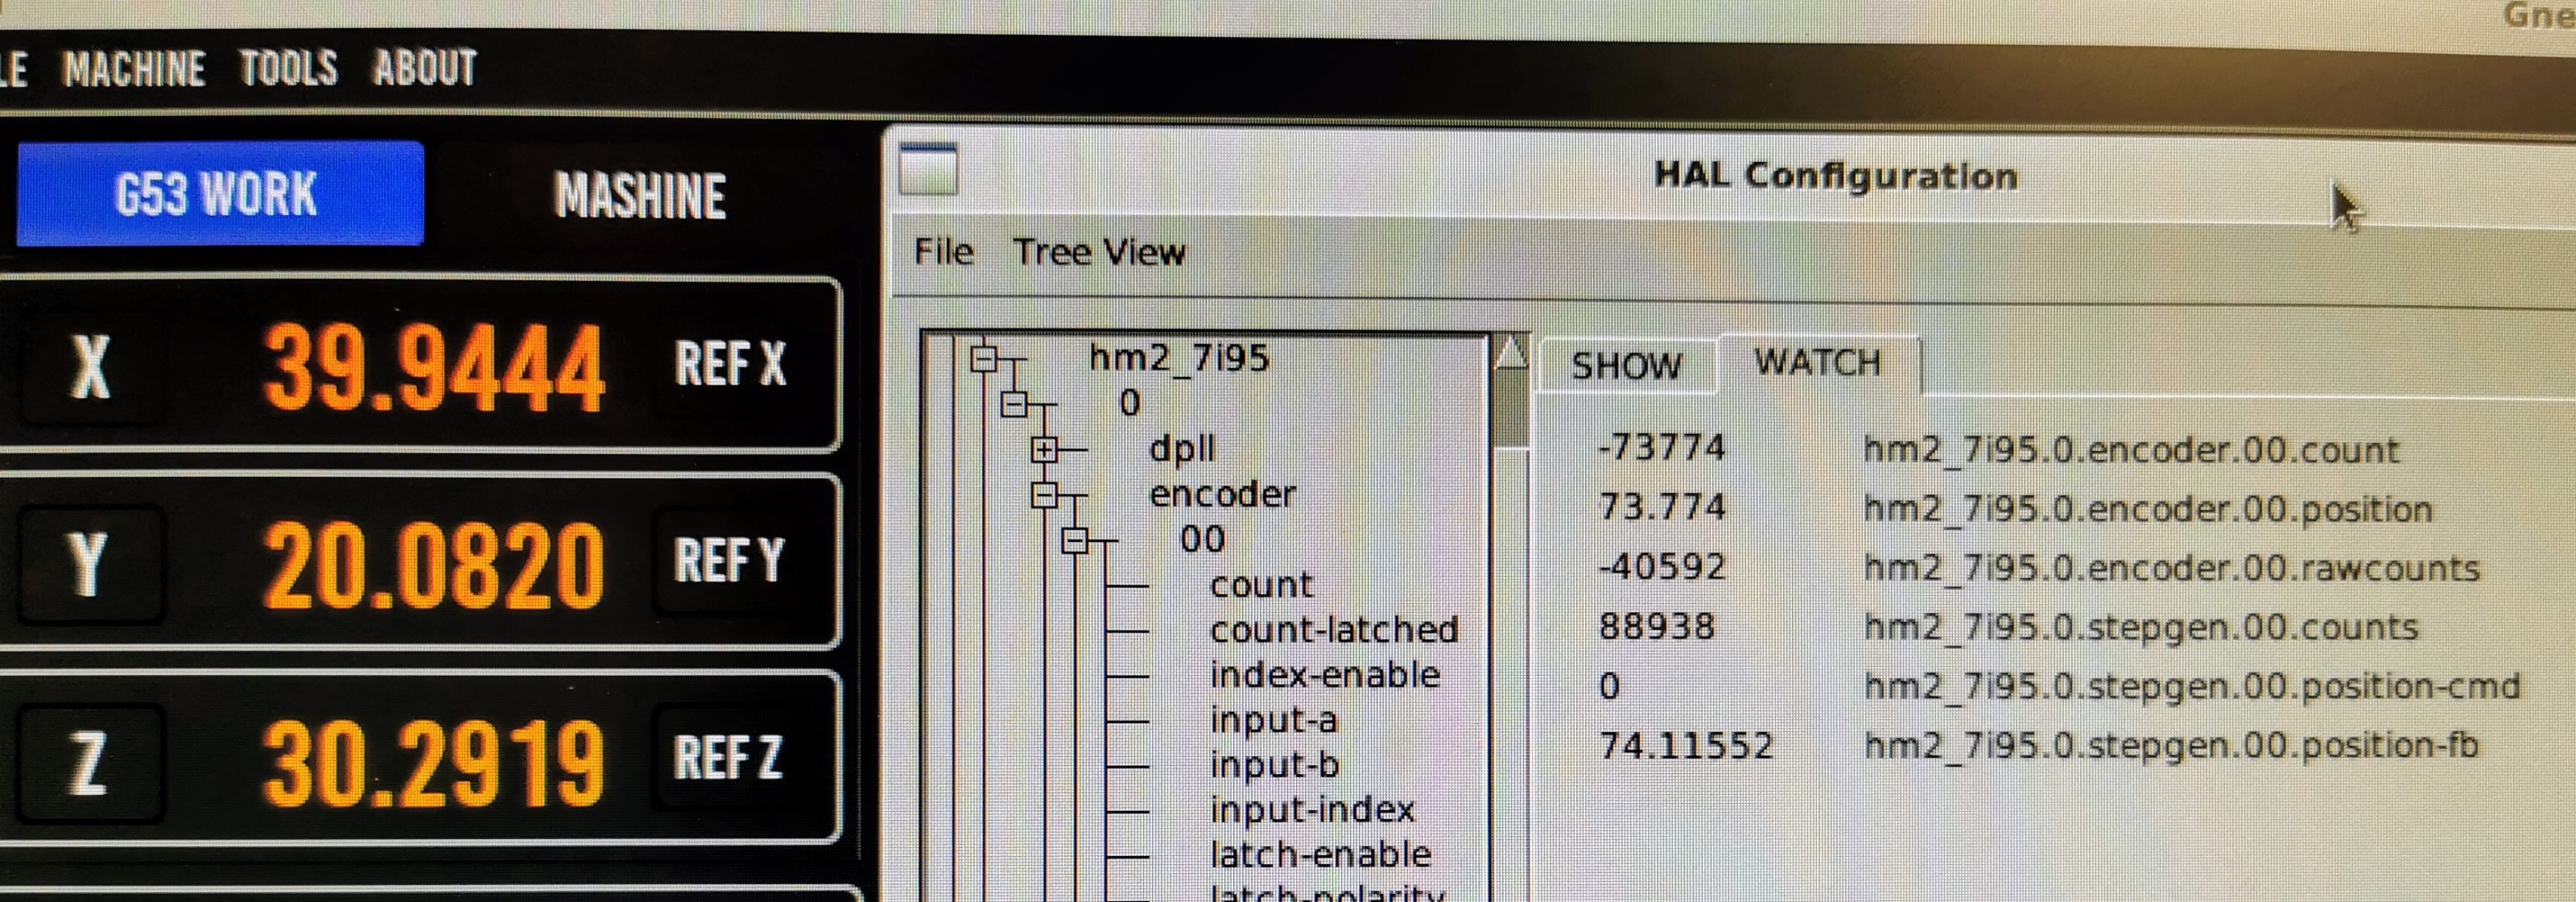
It looks like your stepgen position feedback is closer to correct than your linear scale.

Can you measure some other sizes to see if the error is static or linear or something else? (Does the error get twice as large for double the length or is it the same?)

Please Log in or Create an account to join the conversation.

More
6 years 9 months ago - 6 years 9 months ago #155633 by Gnevko

Todd Zuercher wrote: Make sure you don't have backlash compensation enabled.


I have BACKLASH = 0 in the config ini file for the X and Y joints.

Todd Zuercher wrote: Double check your encoder scale is correct.


The encoders have 0.001 resolution, 1000 counts per 1 mm and it seams to be correct.

It looks like your stepgen position feedback is closer to correct than your linear scale.

Todd Zuercher wrote: Can you measure some other sizes to see if the error is static or linear or something else? (Does the error get twice as large for double the length or is it the same?)

Of course I checked it too: just added second 20.00mm parallel:


and as you can see, the error is the same, not double.

Some additional observation: I know that the machine has physically ca 0.06 mm backlash. I move an axis with MPG (0,01 mm steps) in one direction and can see that the value on edge finder gauge also change. Then I reverse the direction of moving and ... encoder.counter value reacts immediately on it but the value on edge finder gauge - not (ca first three steps). But how it could be? If I move the encoder per hand it reacts also linuxcnc really reads the correct value from it.
Last edit: 6 years 9 months ago by Gnevko.

Please Log in or Create an account to join the conversation.

More
6 years 9 months ago #155652 by PCW
Can you measure the motion near the encoder?
it sounds like lost motion in the linear mechanics
(loose gibs etc)
The following user(s) said Thank You: Gnevko

Please Log in or Create an account to join the conversation.

Time to create page: 0.070 seconds
Powered by Kunena Forum