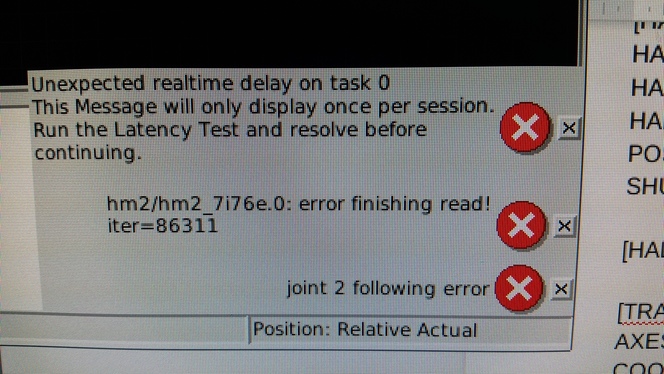
Basically, I run PncConf with default, but for "lathe" and Mesa 7i76e board.
Then for test, I connected one stepperdriver and NEMA17 motor, just for test.
The lathe which is going to be converted is in another city, I would like to get the configuration right on the "test-bench", before heading there.
I run thee gcode that is loaded at startup and measured with a scope where the step and dir signals resided.
Those happen on TB2.
My board doesn't have pin numbers near those connectors, but in the manual I only see a black dot at the bottom, when holding the Ethernet connector to the left-top side (board in landscape).
For now I assume numbering starts from the bottom.
So I connected just one cheap Chinese (open-loop) stepperdriver to TB2
www.aliexpress.com/item/TB6600-4A-9-42V-...xes/32702091551.html
Step on pins 8 and 9
Dir on pins 10 and 11
The signals also appear on pins 2, 3, 4,, and 5. For the there are two axis: X and Z, right?
Though, I didn't find where those pins are configured in the hal or ini file, that's why I used a oscilloscope, to find out.
You see I'm totally new on LinuxCNC, and having a bit hard time to advance.
I have to study it much more, before giving up on it.
Maybe we can get things right,
There are no step timings stated for this stepper driver. But since I do not use any movement feedback, that probably doesn't matter, as long as the motor turns reliable, which it seems to me.
The board would if I connected a stepper driver to one of its outputs I guess.
In the hal file I can make up we have joint 0 and joint 2, and only those seem to give errors.
I don't know what joints are, yet.
The I7i76e does not seem to have a WiFi on-board, as far as I can see, and the manual doesn't talk about WiFi.
Because I didn't configure WiFi, it shouldn't be the problem, right?
After 5 minutes of running the latency test, the bold values are:
Servo thread (1ms) 78998607
Base thread (25us): 123410
Attached the ini and hal file.