
- Posts: 19899
- Thank you received: 4655
Okuma lathe conversion.
- andypugh
- Offline
- Moderator
-

Less
More
11 years 3 weeks ago #63521
by andypugh
The drives probably take a +/- 10V input, and handle the encoder internally. If they do, then you may be (almost) home and dry.
Replied by andypugh on topic Okuma lathe conversion.
timewarp wrote: If I could figure out how to reuse the servos, either with the drives or with different drives that would my first choice.
The drives probably take a +/- 10V input, and handle the encoder internally. If they do, then you may be (almost) home and dry.
Please Log in or Create an account to join the conversation.
- timewarp
- Offline
- Junior Member
-

Less
More
- Posts: 21
- Thank you received: 1
11 years 3 weeks ago #63524
by timewarp
Replied by timewarp on topic Okuma lathe conversion.
Here is a page from the wiring manual, does it help?

Please Log in or Create an account to join the conversation.
- andypugh
- Offline
- Moderator
-
Less
More
- Posts: 19899
- Thank you received: 4655
11 years 3 weeks ago #63533
by andypugh
Replied by andypugh on topic Okuma lathe conversion.
It is starting to look not 100% trivial...
It looks like sin/cos encoders converted to a serial data format by the OSP700L board. That also seems to create 3 commutation signals (COMA1, COMB1, COMC1)
That diagram doesn't seem to show where the motion controller connects to the servo amplifier?
It looks like sin/cos encoders converted to a serial data format by the OSP700L board. That also seems to create 3 commutation signals (COMA1, COMB1, COMC1)
That diagram doesn't seem to show where the motion controller connects to the servo amplifier?
Please Log in or Create an account to join the conversation.
- timewarp
- Offline
- Junior Member
-
Less
More
- Posts: 21
- Thank you received: 1
11 years 3 weeks ago #63555
by timewarp
Replied by timewarp on topic Okuma lathe conversion.
I think I am going to look for new servos with usable encoders as the motors and drives probably have some value.
Is there a standard for servo motor mounts (Nema?) Bolt pattern looks to be about 150mm.
Are all Fanuc Red cap motors usable with the pico adapter?
Here is the Servo I have.
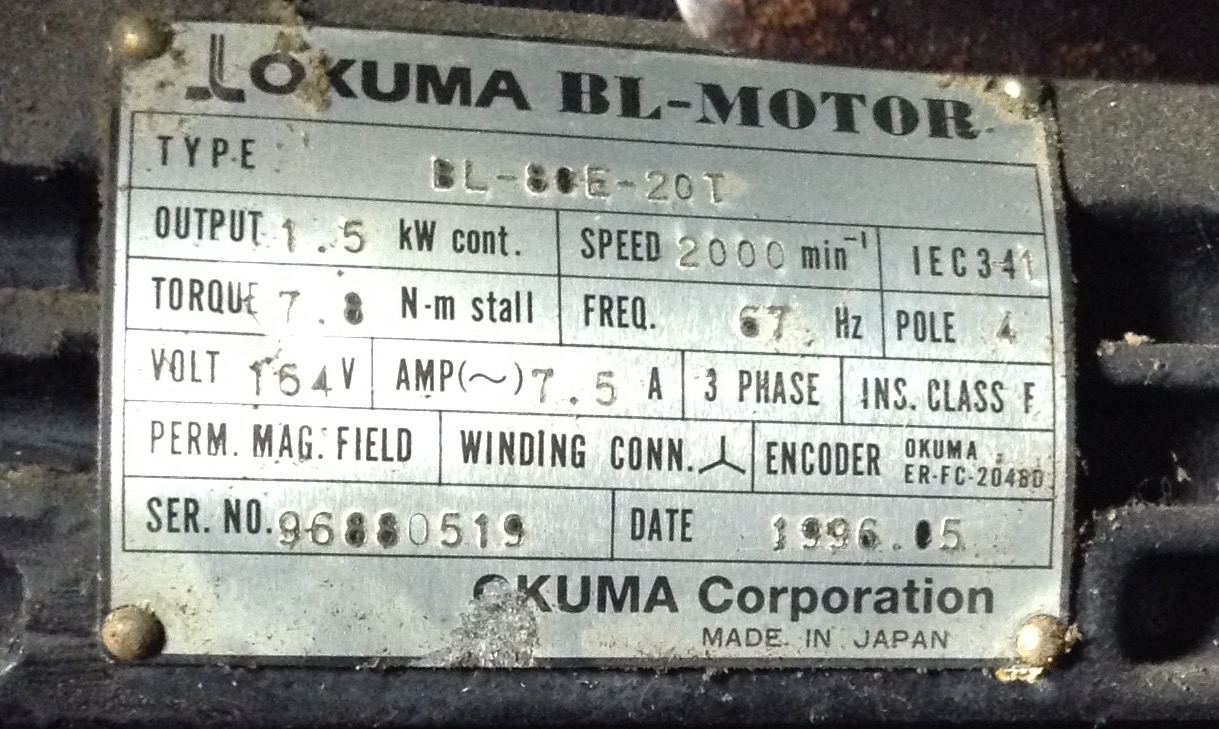
When looking for a new servo What is the most important to look for? Output,torque,rpm?
Just ordered some mesa cards - 5i25, 7i77, 7i69
Thanks again, Paul
Is there a standard for servo motor mounts (Nema?) Bolt pattern looks to be about 150mm.
Are all Fanuc Red cap motors usable with the pico adapter?
Here is the Servo I have.
When looking for a new servo What is the most important to look for? Output,torque,rpm?
Just ordered some mesa cards - 5i25, 7i77, 7i69
Thanks again, Paul
Please Log in or Create an account to join the conversation.
- andypugh
- Offline
- Moderator
-
Less
More
- Posts: 19899
- Thank you received: 4655
11 years 3 weeks ago #63564
by andypugh
Replied by andypugh on topic Okuma lathe conversion.
It would be much more satisfying to work out how to interface the original encoders.
However the combination of data / strobe / clock seems a bit unusual. It is possible that it is SPI, though, and I think I would try connecting to a Mesa BSPI channel to see what comes out.
Have you seen this?
s3.amazonaws.com/Icarus/DOCUMENTS/Okuma_Manuals_614.pdf
However the combination of data / strobe / clock seems a bit unusual. It is possible that it is SPI, though, and I think I would try connecting to a Mesa BSPI channel to see what comes out.
Have you seen this?
s3.amazonaws.com/Icarus/DOCUMENTS/Okuma_Manuals_614.pdf
The following user(s) said Thank You: Henk
Please Log in or Create an account to join the conversation.
- timewarp
- Offline
- Junior Member
-
Less
More
- Posts: 21
- Thank you received: 1
11 years 3 weeks ago #63592
by timewarp
Replied by timewarp on topic Okuma lathe conversion.
Thamks Andy, Yes I have that manual. I think figuring the encoders might be beyond my skill level. At this point I am going to look for replacement servos. I might already have some drives that could work. Just bought a 15hp vfd for the spindle.
Please Log in or Create an account to join the conversation.
Time to create page: 1.756 seconds